Skip to content · ⁨Bỏ qua nội dung⁩
Subjects · ⁨Môn học⁩

AP Physics C: Mechanics · ⁨AP Vật lý C: Cơ học⁩

Tips · ⁨Mẹo⁩

AP Physics C: Mechanics is the calculus-based version: kinematics, forces, work, energy and power, momentum, torque and rotation, and oscillations. It covers less ground than Physics 1 but goes much deeper, and calculus is not decoration — it is how the results are derived and how the exam expects them to be used.

In practice: integrate to get a total from a varying quantity, and differentiate from position to velocity to acceleration, comfortably and without being prompted.

Rotational dynamics is where time goes, because moments of inertia must be set up as integrals rather than recalled.

The notes take each unit in CED order with the calculus set out in full. Released past papers and scoring guidelines sit in the library. Because so many marks ride on the setup rather than the arithmetic, the worked examples deliberately show the integral being built before it is evaluated.

  • 1

    Kinematics · ⁨Chuyển động học⁩

    Watch lesson · ⁨Xem bài học⁩
    1.1

    Scalars and Vectors

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 1.1.A: Describe a scalar or vector quantity using magnitude and direction, as appropriate.

    • 1.1.A.1 Scalars are quantities described by magnitude only; vectors are quantities described by both magnitude and direction.
    • 1.1.A.2 Vectors can be visually modeled as arrows with appropriate direction and lengths proportional to their magnitude.
    • 1.1.A.3 Distance and speed are examples of scalar quantities, while position, displacement, velocity, and acceleration are examples of vector quantities.
    • 1.1.A.4 Vectors can be expressed in unit vector notation or as a magnitude and a direction.
      • 1.1.A.4.i Unit vector notation can be used to represent vectors as the sum of their constituent components in the $x$-, $y$-, and $z$-directions, denoted by $\hat{i}$, $\hat{j}$, and $\hat{k}$, respectively.
        • Equation: $\vec{r} = \left( A\hat{i} + B\hat{j} + C\hat{k} \right)$
      • 1.1.A.4.ii The position vector of a point is given by $\vec{r}$, and the unit vector in the direction of the position vector is denoted $\hat{r}$.
      • 1.1.A.4.iii A resultant vector is the vector sum of the addend vectors' components.
        • Equation: $\vec{C} = \vec{A} + \vec{B}$
        • Equation: $\vec{C} = \left( A_x + B_x \right)\hat{i} + \left( A_y + B_y \right)\hat{j}$
    • 1.1.A.5 In a given one-dimensional coordinate system, opposite directions are denoted by opposite signs.
    Tiếng Việt

    Mục tiêu học tập 1.1.A: Mô tả một đại lượng vô hướng hoặc vectơ sử dụng độ lớn và phương hướng, tùy thuộc vào từng loại.

    • 1.1.A.1 Đại lượng vô hướng chỉ được mô tả bằng độ lớn; đại lượng vectơ được mô tả bằng cả độ lớn và phương hướng.
    • 1.1.A.2 Vectơ có thể được mô hình hóa trực quan dưới dạng các mũi tên có phương hướng phù hợp và độ dài tỷ lệ thuận với độ lớn của chúng.
    • 1.1.A.3 Khoảng cách và tốc độ là ví dụ về các đại lượng vô hướng, trong khi vị trí, độ dịch chuyển, vận tốc và gia tốc là ví dụ về các đại lượng vectơ.
    • 1.1.A.4 Các vector có thể được biểu diễn dưới dạng ký hiệu vector đơn vị hoặc dưới dạng độ lớn và hướng.
      • 1.1.A.4.i Ký hiệu vector đơn vị có thể được sử dụng để biểu diễn các vector dưới dạng tổng các thành phần cấu tạo của chúng theo các hướng $x$-, $y$- và $z$-, được ký hiệu lần lượt là $\hat{i}$, $\hat{j}$ và $\hat{k}$.
        • Phương trình: $\vec{r} = \left( A\hat{i} + B\hat{j} + C\hat{k} \right)$
      • 1.1.A.4.ii Vector vị trí của một điểm được cho bởi $\vec{r}$, và vector đơn vị theo hướng của vector vị trí được ký hiệu là $\hat{r}$.
      • 1.1.A.4.iii Vector kết quả là tổng vector của các thành phần của các vector cộng.
        • Phương trình: $\vec{C} = \vec{A} + \vec{B}$
        • Phương trình: $\vec{C} = \left( A_x + B_x \right)\hat{i} + \left( A_y + B_y \right)\hat{j}$
    • 1.1.A.5 Trong một hệ tọa độ một chiều cho trước, các hướng ngược nhau được ký hiệu bằng các dấu相反的.
    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Kinematics 运动学 describes motion. Two kinds of quantity:
    • A scalar 标量 has only size (magnitude 大小): distance, speed, mass, time.
    • A vector 矢量 has magnitude and direction: displacement, velocity, acceleration, force.

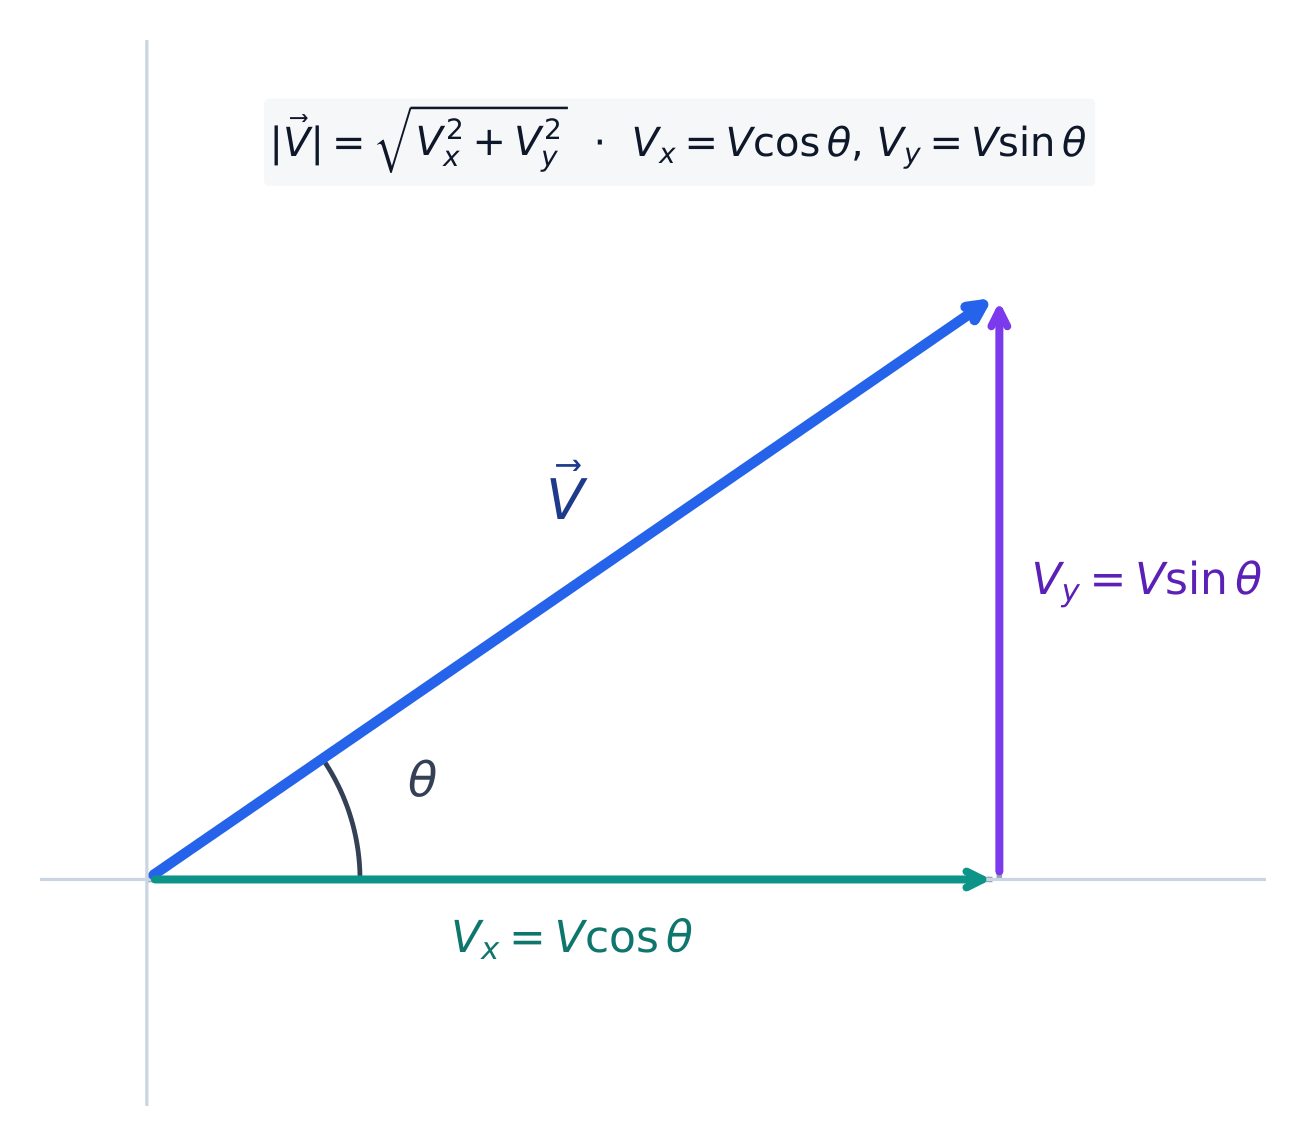
    In this calculus-based course you resolve vectors into components 分量 and add them component by component; a vector's magnitude is $\sqrt{v_x^2+v_y^2+\cdots}$. Physics C also writes vectors with unit vectors 单位矢量: $\vec{v}=v_x\hat{i}+v_y\hat{j}$, where $\hat{i}$ and $\hat{j}$ are directions of length one along $x$ and $y$ – handy because calculus can then act on each component separately.

    Resolving a vector into its x and y components
    Resolving a vector into its x and y components
    A car speedometer: speed is the magnitude of velocity — a scalar rate of motion
    A car speedometer: speed is the magnitude of velocity — a scalar rate of motion
    Explore · ⁨Khám phá⁩

    Explore the dot product · ⁨Khám phá tích vô hướng⁩

    Drag the components of $\vec{A}$ and $\vec{B}$. The dot product $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ reaches zero exactly when the two vectors are perpendicular — the geometry behind $\cos\theta$. · ⁨Kéo các thành phần của $\vec{A}$ và $\vec{B}$. Tích vô hướng $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ đạt không chính xác khi hai vectơ vuông góc — đây là cơ sở hình học của $\cos\theta$.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Kinematics/ˌkɪnɪˈmætɪks/ Chuyển động học
    scalar/ˈskeɪlə/ vô hướng
    magnitude/ˈmæɡnɪtjuːd/ độ lớn
    vector/ˈvektə/ vector
    components/kəmˈpəʊnənts/ thành phần
    unit vectors/ˈjuːnɪt ˈvektəz/ Vector đơn vị
    1.2

    Displacement, Velocity, and Acceleration

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 1.2.A: Describe a change in an object's position.

    • 1.2.A.1 When using the object model, the size, shape, and internal configuration are ignored. The object may be treated as a single point with extensive properties such as mass and charge.
    • 1.2.A.2 Displacement is the change in an object's position.
      • Equation: $\Delta x = x - x_0$

    Learning Objective 1.2.B: Describe the average velocity and acceleration of an object.

    • 1.2.B.1 Averages of velocity and acceleration are calculated considering the initial and final states of an object over an interval of time.
    • 1.2.B.2 Average velocity is the displacement of an object divided by the interval of time in which that displacement occurs.
      • Equation: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
    • 1.2.B.3 Average acceleration is the change in velocity divided by the interval of time in which that change in velocity occurs.
      • Equation: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
    • 1.2.B.4 An object is accelerating if either the magnitude and/or direction of the object's velocity are changing.
    • 1.2.B.5 Calculating average velocity or average acceleration over a very small time interval yields a value that is very close to the instantaneous velocity or instantaneous acceleration.

    Learning Objective 1.2.C: Describe the instantaneous position, velocity, and acceleration of an object as a function of time.

    • 1.2.C.1 As the time interval used to calculate the average value of a quantity approaches zero, the average value of that quantity approaches the value of the quantity at that instant, called the instantaneous value.
      • 1.2.C.1.i Instantaneous velocity is the rate of change of the object's position, which is equal to the derivative of position with respect to time.
        • Equation: $\vec{v} = \dfrac{d\vec{r}}{dt}$
        • Equation: $v_x = \dfrac{dx}{dt}$
      • 1.2.C.1.ii Instantaneous acceleration is the rate of change of the object's velocity, which is equal to the derivative of velocity with respect to time.
        • Equation: $\vec{a} = \dfrac{d\vec{v}}{dt}$
        • Equation: $a_x = \dfrac{dv_x}{dt}$
    • 1.2.C.2 Time-dependent functions and instantaneous values of position, velocity, and acceleration can be determined using differentiation and integration.
    Tiếng Việt

    Mục tiêu học tập 1.2.A: Mô tả sự thay đổi vị trí của một vật.

    • 1.2.A.1 Khi sử dụng mô hình vật, kích thước, hình dạng và cấu trúc bên trong bị bỏ qua. Vật có thể được coi là một điểm đơn với các thuộc tính mở rộng như khối lượng và điện tích.
    • 1.2.A.2 Độ dịch chuyển là sự thay đổi vị trí của một vật.
      • Phương trình: $\Delta x = x - x_0$

    Mục tiêu học tập 1.2.B: Mô tả vận tốc trung bình và gia tốc trung bình của một vật.

    • 1.2.B.1 Vận tốc trung bình và gia tốc trung bình được tính toán dựa trên trạng thái ban đầu và trạng thái cuối cùng của vật thể trong một khoảng thời gian.
    • 1.2.B.2 Vận tốc trung bình là độ dịch chuyển của vật chia cho khoảng thời gian mà độ dịch chuyển đó xảy ra.
      • Phương trình: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
    • 1.2.B.3 Gia tốc trung bình là sự thay đổi vận tốc chia cho khoảng thời gian mà sự thay đổi vận tốc đó xảy ra.
      • Phương trình: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
    • 1.2.B.4 Một vật đang gia tốc nếu cả độ lớn và/hoặc hướng vận tốc của vật đang thay đổi.
    • 1.2.B.5 Việc tính vận tốc trung bình hoặc gia tốc trung bình trong một khoảng thời gian rất nhỏ sẽ cho ra một giá trị rất gần với vận tốc tức thời hoặc gia tốc tức thời.

    Mục tiêu học tập 1.2.C: Mô tả vị trí tức thời, vận tốc và gia tốc của một vật theo thời gian.

    • 1.2.C.1 Khi khoảng thời gian dùng để tính giá trị trung bình của một đại lượng tiến tới không, giá trị trung bình của đại lượng đó tiến tới giá trị của đại lượng tại thời điểm đó, được gọi là giá trị tức thời.
      • 1.2.C.1.i Vận tốc tức thời là tốc độ biến thiên vị trí của vật, bằng đạo hàm của vị trí theo thời gian.
        • Phương trình: $\vec{v} = \dfrac{d\vec{r}}{dt}$
        • Phương trình: $v_x = \dfrac{dx}{dt}$
      • 1.2.C.1.ii Gia tốc tức thời là tốc độ biến thiên vận tốc của vật, bằng đạo hàm của vận tốc theo thời gian.
        • Phương trình: $\vec{a} = \dfrac{d\vec{v}}{dt}$
        • Phương trình: $a_x = \dfrac{dv_x}{dt}$
    • 1.2.C.2 Các hàm phụ thuộc thời gian và các giá trị tức thời của vị trí, vận tốc và gia tốc có thể xác định được thông qua vi phân và tích phân.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Projectile motion is two independent motions

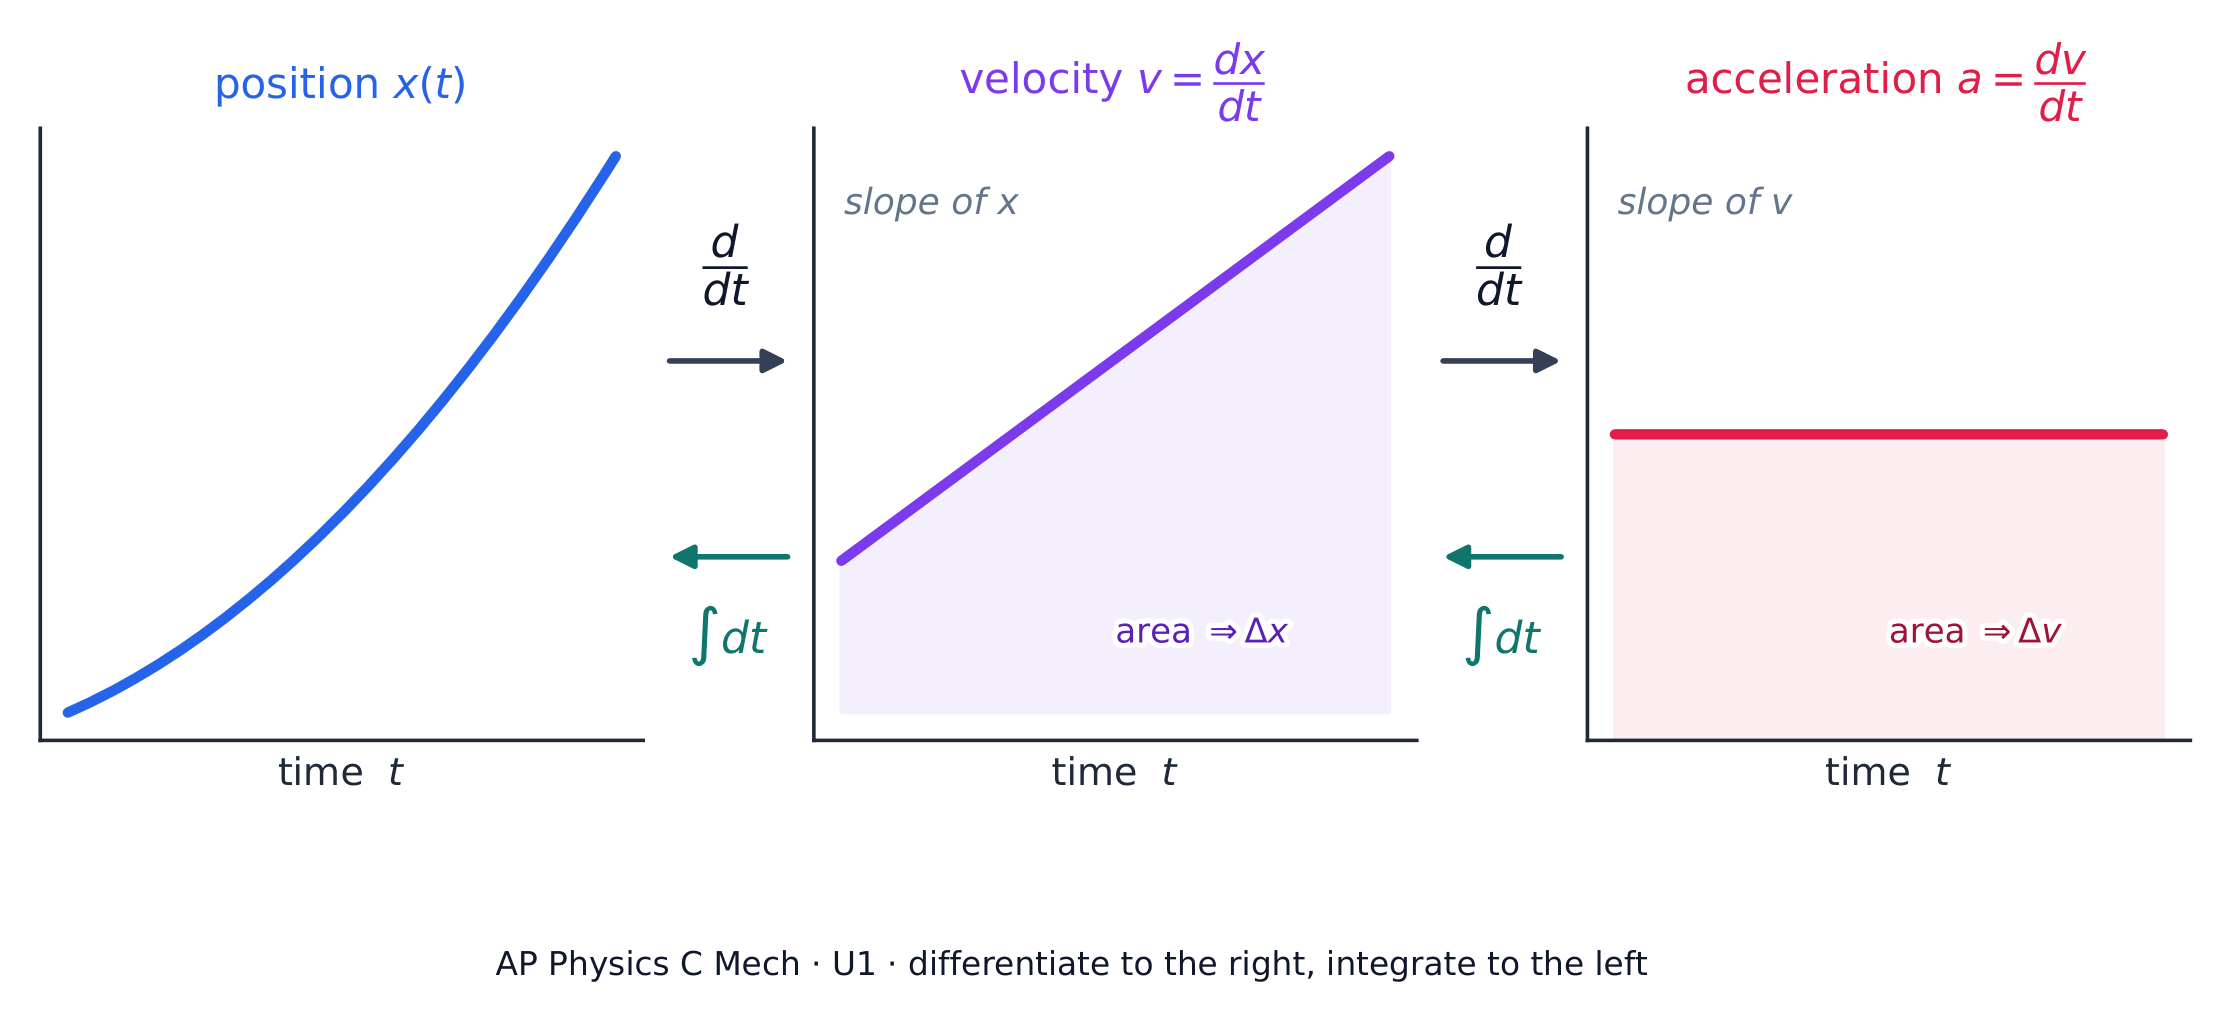
    Because motion can change continuously, define the rates as derivatives 导数:

    $$v=\frac{dx}{dt},\qquad a=\frac{dv}{dt}=\frac{d^2x}{dt^2}.$$
    Reversing this, integrate to recover velocity and position:
    $$v(t)=v_0+\int_0^t a\,dt,\qquad x(t)=x_0+\int_0^t v\,dt.$$
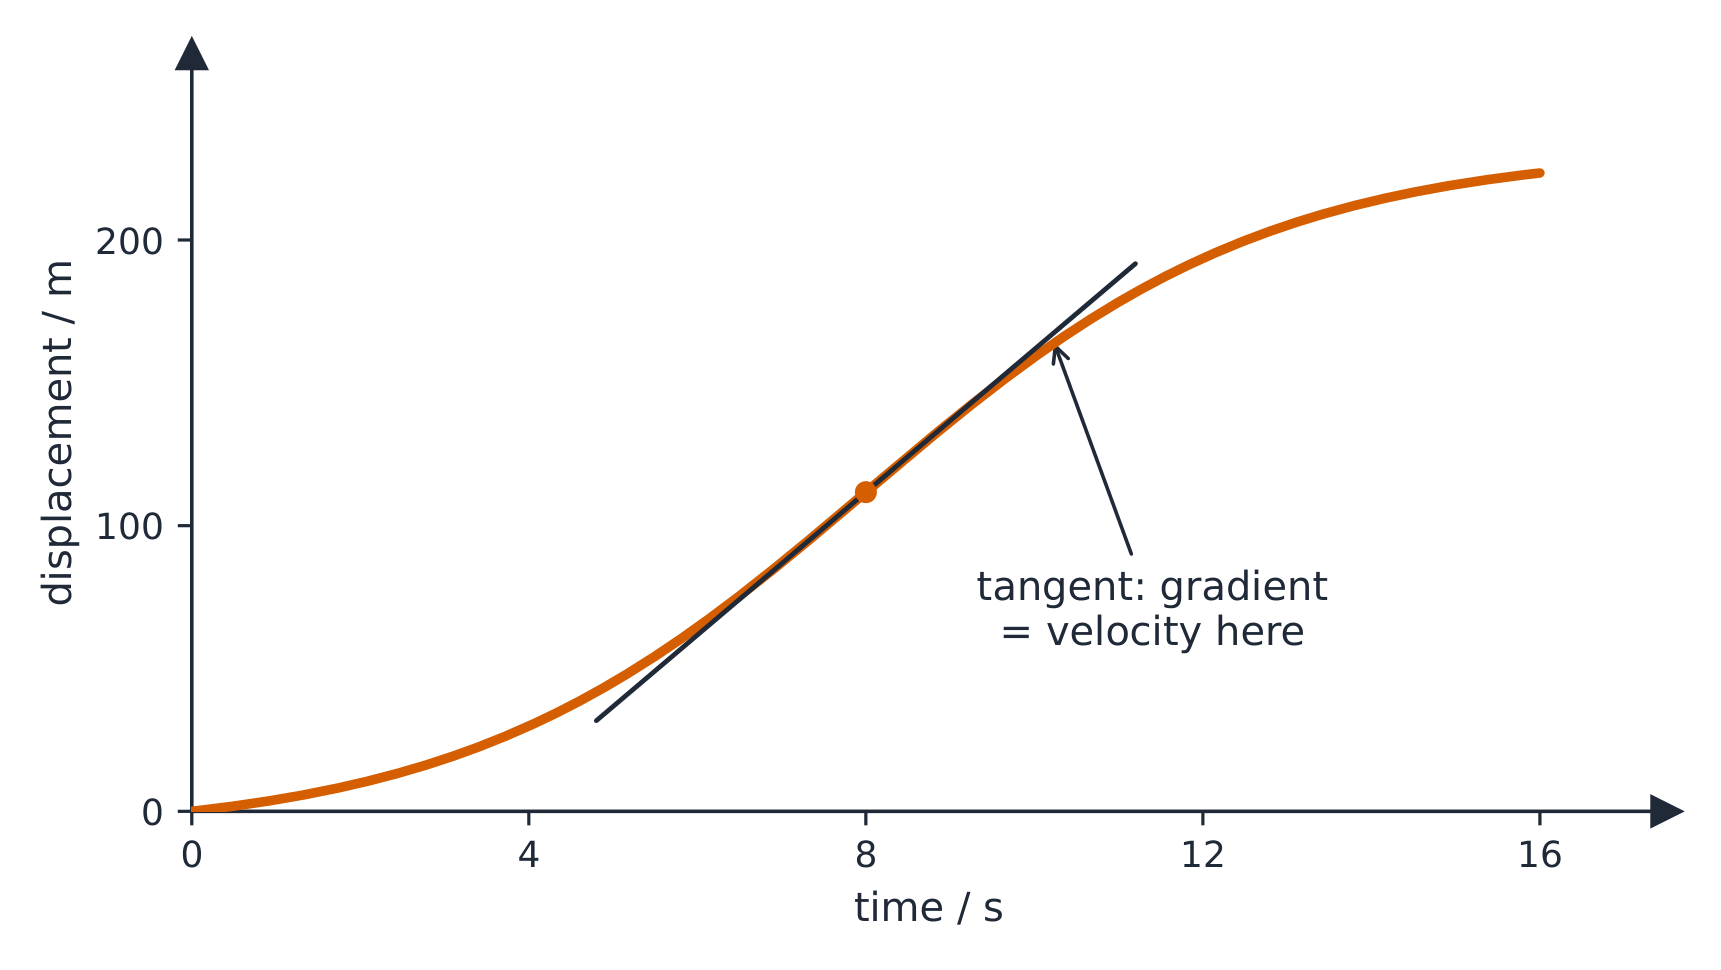
    Distinguish the average from the instantaneous: average velocity 平均速度 is $\Delta x/\Delta t$ over an interval, while instantaneous velocity 瞬时速度 is the derivative at one moment – the slope of the tangent line, and what a speedometer shows.

    For constant acceleration these give the familiar kinematic equations ($v=v_0+at$, $x=x_0+v_0t+\tfrac12at^2$, $v^2=v_0^2+2a\,\Delta x$). The most important constant-$a$ case is free fall 自由落体: near Earth's surface every object, heavy or light, accelerates downward at $g=9.8\ \text{m/s}^2$ once air resistance is negligible. When $a$ or $v$ varies with time, use the integrals directly.

    Worked example. A particle moves with $x(t)=2t^3-3t^2$ (metres). Differentiate for velocity and acceleration:

    $$v=\frac{dx}{dt}=6t^2-6t,\qquad a=\frac{dv}{dt}=12t-6.$$
    At $t=2\ \text{s}$, $v=24-12=12\ \text{m/s}$ and $a=24-6=18\ \text{m/s}^2$. This calculus link – not just the constant-$a$ formulas – is what distinguishes Physics C.

    Worked example. A particle starts from rest at the origin with $a(t)=6t$. Integrate: $v=\int 6t\,dt=3t^2$ and $x=\int 3t^2\,dt=t^3$. At $t=2\ \text{s}$, $v=12\ \text{m/s}$ and $x=8\ \text{m}$.

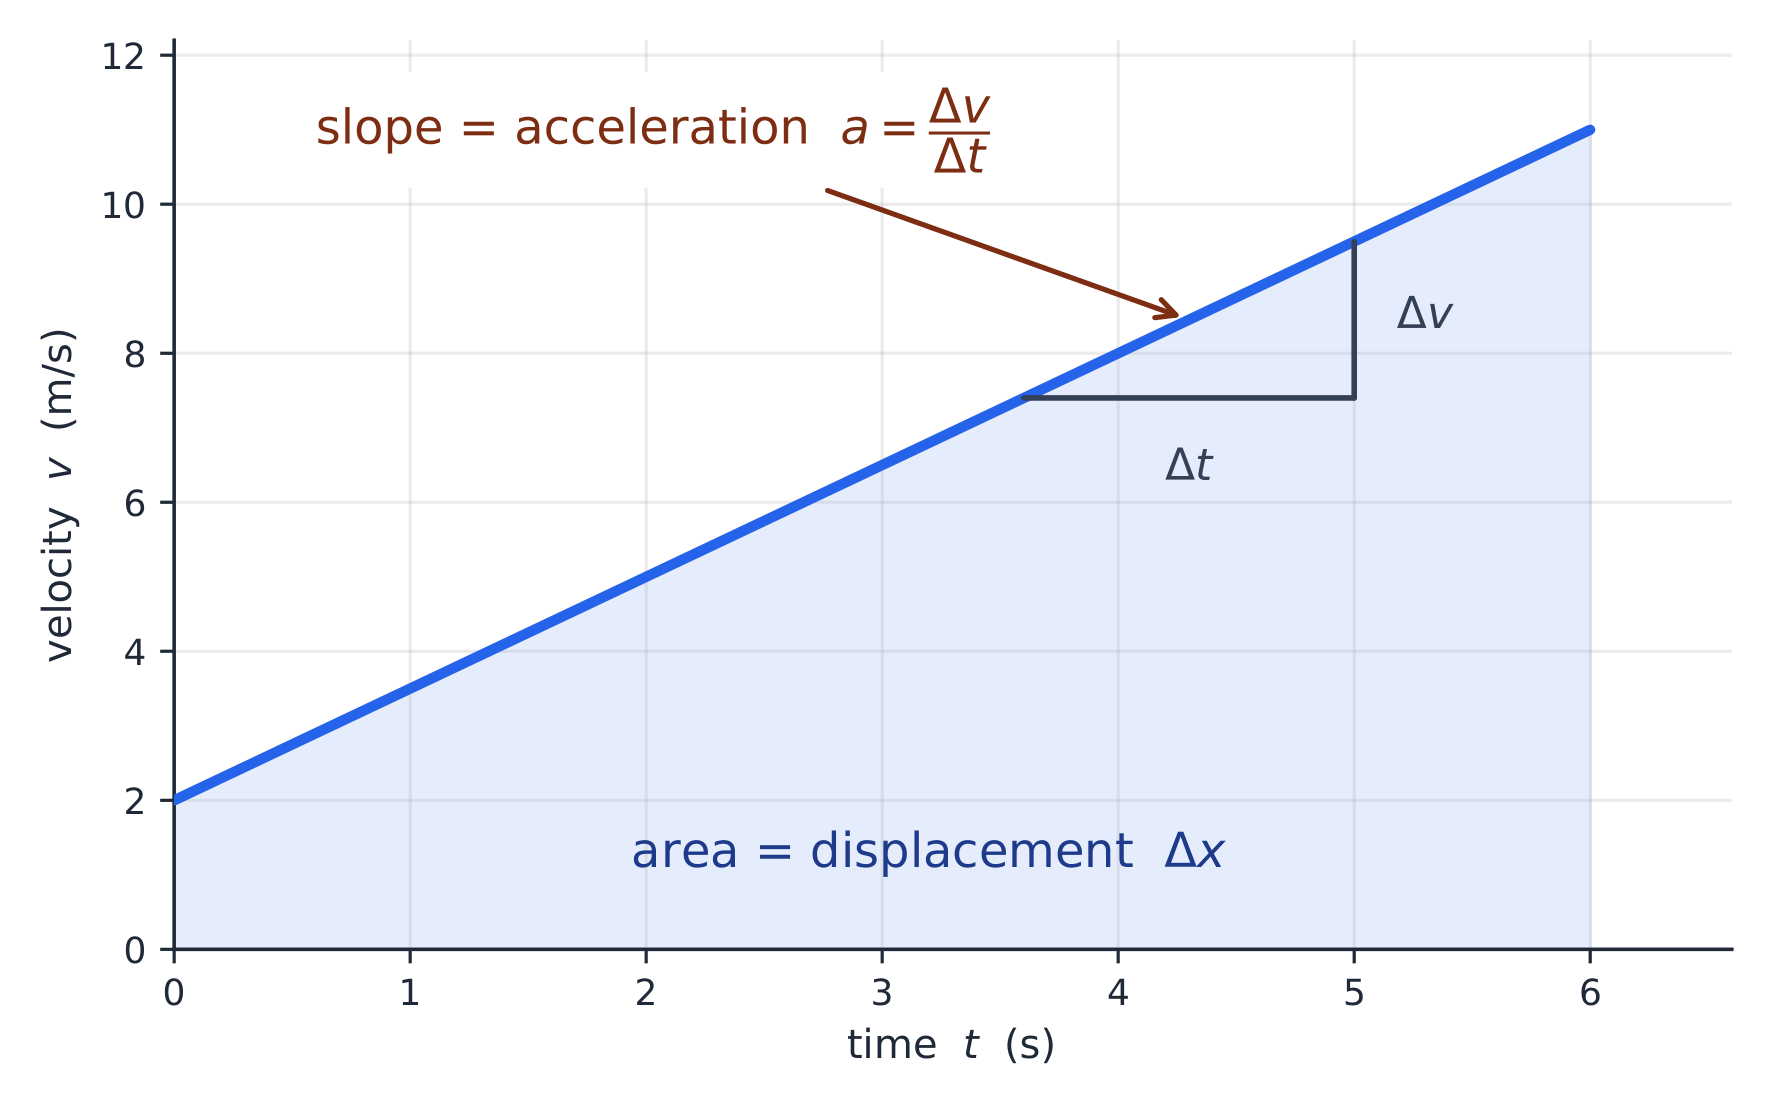
    On a velocity-time graph the gradient is the acceleration and the area is the displacement
    On a velocity-time graph the gradient is the acceleration and the area is the displacement
    A high-speed train: kinematics describes displacement, velocity and acceleration over time
    A high-speed train: kinematics describes displacement, velocity and acceleration over time
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    derivatives/dɪˈrɪvətɪvz/ đạo hàm của nó
    average velocity/ˈævrɪdʒ vəˈlɒsɪti/ vận tốc trung bình
    instantaneous velocity/ˌɪnstənˈteɪnɪəs vəˈlɒsɪti/ vận tốc tức thời
    free fall/friː fɔːl/ chuyển động rơi tự do
    1.3

    Representing Motion

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 1.3.A: Describe the position, velocity, and acceleration of an object using representations of that object's motion.

    • 1.3.A.1 Motion can be represented by motion diagrams, figures, graphs, equations, and narrative descriptions.
    • 1.3.A.2 For constant acceleration, three kinematic equations can be used to describe instantaneous linear motion in one dimension:
      • Equation: $v_x = v_{x0} + a_x t$
      • Equation: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
      • Equation: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
      • Note: The equations above are written to indicate motion in the $x$-direction, but these equations can be used in any single dimension as appropriate.
    • 1.3.A.3 Near the surface of Earth, the vertical acceleration caused by the force of gravity is downward, constant, and has a measured value approximately equal to
      • Equation: $a_g = g \approx 10 \ \text{m/s}^2$.
    • 1.3.A.4 Graphs of position, velocity, and acceleration as functions of time can be used to find the relationships between those quantities.
      • 1.3.A.4.i An object's instantaneous velocity is the rate of change of the object's position, which is equal to the slope of a line tangent to a point on a graph of the object's position as a function of time.
        • Equation: $v_x = \dfrac{dx}{dt}$
      • 1.3.A.4.ii An object's instantaneous acceleration is the rate of change of the object's velocity, which is equal to the slope of a line tangent to a point on a graph of the object's velocity as a function of time.
        • Equation: $a_x = \dfrac{dv_x}{dt}$
      • 1.3.A.4.iii The displacement of an object during a time interval is equal to the area under the curve of a graph of the object's velocity as a function of time (i.e., the area bounded by the function and the horizontal axis for the appropriate interval).
        • Equation: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
      • 1.3.A.4.iv The change in velocity of an object during a time interval is equal to the area under the curve of a graph of the acceleration of the object as a function of time.
        • Equation: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$

    Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism expects that for all situations in which a numerical quantity is required for g, the value $g \approx 10 \ \text{m/s}^2$ will be used. However, students will not be penalized for correctly using the more precise commonly accepted values of $g = 9.81 \ \text{m/s}^2$ or $g = 9.8 \ \text{m/s}^2$.

    Tiếng Việt

    Mục tiêu học tập 1.3.A: Mô tả vị trí, vận tốc và gia tốc của một vật thông qua các biểu diễn chuyển động của vật đó.

    • 1.3.A.1 Chuyển động có thể được biểu diễn bằng sơ đồ chuyển động, hình vẽ, đồ thị, phương trình và mô tả bằng văn bản.
    • 1.3.A.2 Đối với gia tốc không đổi, ba phương trình động học có thể được sử dụng để mô tả chuyển động tuyến tính tức thời trong một chiều:
      • Phương trình: $v_x = v_{x0} + a_x t$
      • Phương trình: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
      • Phương trình: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
      • Lưu ý: Các phương trình trên được viết để biểu diễn chuyển động theo hướng $x$, nhưng các phương trình này có thể áp dụng cho bất kỳ chiều đơn nào tùy tình huống.
    • 1.3.A.3 Gần bề mặt Trái Đất, gia tốc dọc gây ra bởi trọng lực có hướng xuống dưới, không đổi và có giá trị đo được xấp xỉ bằng
      • Phương trình: $a_g = g \approx 10 \ \text{m/s}^2$.
    • 1.3.A.4 Đồ thị vị trí, vận tốc và gia tốc theo hàm của thời gian có thể được sử dụng để tìm mối quan hệ giữa các đại lượng đó.
      • 1.3.A.4.i Vận tốc tức thời của vật là tốc độ thay đổi vị trí của vật, bằng với độ dốc của đường tiếp tuyến tại một điểm trên đồ thị vị trí của vật theo hàm của thời gian.
        • Phương trình: $v_x = \dfrac{dx}{dt}$
      • 1.3.A.4.ii Gia tốc tức thời của vật là tốc độ thay đổi vận tốc của vật, bằng với độ dốc của đường tiếp tuyến tại một điểm trên đồ thị vận tốc của vật theo hàm của thời gian.
        • Phương trình: $a_x = \dfrac{dv_x}{dt}$
      • 1.3.A.4.iii Độ dịch chuyển của vật trong một khoảng thời gian bằng với diện tích nằm dưới đường cong của đồ thị vận tốc của vật theo hàm của thời gian (tức là diện tích giới hạn bởi hàm số và trục hoành trong khoảng thời gian phù hợp).
        • Phương trình: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
      • 1.3.A.4.iv Sự biến thiên vận tốc của vật trong một khoảng thời gian bằng với diện tích nằm dưới đường cong của đồ thị gia tốc của vật theo hàm của thời gian.
        • Phương trình: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$

    Câu Boundary: AP Physics C: Cơ học và AP Physics C: Điện từ yêu cầu rằng trong mọi trường hợp cần số liệu cụ thể cho g, giá trị $g \approx 10 \ \text{m/s}^2$ sẽ được sử dụng. Tuy nhiên, học sinh sẽ không bị trừ điểm nếu sử dụng đúng các giá trị phổ biến chính xác hơn của $g = 9.81 \ \text{m/s}^2$ hoặc $g = 9.8 \ \text{m/s}^2$.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Move fluently between description, graph, table, and equation:

    A displacement-time graph: the slope at any instant is the velocity
    A displacement-time graph: the slope at any instant is the velocity
    • On a position–time graph, the slope ($dx/dt$) is velocity.
    • On a velocity–time graph, the slope is acceleration and the area ($\int v\,dt$) is displacement.
    • On an acceleration–time graph, the area ($\int a\,dt$) is the change in velocity.

    Slopes are derivatives; areas are integrals – the two are inverse operations here.

    Position, velocity, and acceleration are linked by differentiation
    Position, velocity, and acceleration are linked by differentiation
    Explore · ⁨Khám phá⁩

    Explore the velocity–time graph

    Change the start velocity and acceleration. The slope of a $v$–$t$ line is the acceleration $a=\tfrac{dv}{dt}$, and the area underneath is the displacement $\Delta x=\int v\,dt$ — slope and area are the graphical faces of the derivative and the integral. · ⁨Thay đổi vận tốc ban đầu và gia tốc. Độ dốc của đồ thị $v$–$t$ là gia tốc $a=\tfrac{dv}{dt}$, và diện tích phía dưới là độ dịch chuyển $\Delta x=\int v\,dt$ — độ dốc và diện tích là mặt biểu diễn đồ thị của đạo hàm và nguyên hàm.⁩

    1.4

    Reference Frames and Relative Motion

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 1.4.A: Describe the reference frame of a given observer.

    • 1.4.A.1 The choice of reference frame will determine the direction and magnitude of quantities measured by an observer in that reference frame.

    Learning Objective 1.4.B: Describe the motion of objects as measured by observers in different inertial reference frames.

    • 1.4.B.1 Measurements from a given reference frame may be converted to measurements from another reference frame.
    • 1.4.B.2 The observed velocity of an object results from the combination of the object's velocity and the velocity of the observer's reference frame.
      • 1.4.B.2.i Combining the motion of an object and the motion of an observer in a given reference frame involves the addition or subtraction of vectors.
      • 1.4.B.2.ii The acceleration of any object is the same as measured from all inertial reference frames.

    Boundary statement: Unless otherwise stated, the frame of reference of any problem may be assumed to be inertial.

    Tiếng Việt

    Mục tiêu học tập 1.4.A: Mô tả khung tham chiếu của một người quan sát đã cho.

    • 1.4.A.1 Việc chọn hệ quy chiếu sẽ xác định phương và độ lớn của các đại lượng được quan sát viên đo đạc trong hệ quy chiếu đó.

    Mục tiêu học tập 1.4.B: Mô tả chuyển động của vật thể như được đo bởi các quan sát viên trong các hệ quy chiếu quán tính khác nhau.

    • 1.4.B.1 Các phép đo từ một hệ quy chiếu nhất định có thể được chuyển đổi thành các phép đo từ một hệ quy chiếu khác.
    • 1.4.B.2 Vận tốc quan sát được của một vật thể là kết quả của sự tổng hợp vận tốc của vật thể và vận tốc của hệ quy chiếu mà quan sát viên đang đứng.
      • 1.4.B.2.i Sự kết hợp chuyển động của một vật thể và chuyển động của quan sát viên trong một hệ quy chiếu nhất định liên quan đến việc cộng hoặc trừ các vectơ.
      • 1.4.B.2.ii Gia tốc của bất kỳ vật thể nào đều giống hệt nhau khi được đo từ tất cả các hệ quy chiếu quán tính.

    Phát biểu giới hạn: Trừ khi có quy định khác, hệ quy chiếu của bất kỳ bài toán nào cũng có thể được giả định là hệ quy chiếu quán tính.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    All motion is relative to a reference frame 参考系. Combine velocities by vector addition: $\vec{v}_{A/C}=\vec{v}_{A/B}+\vec{v}_{B/C}$. This handles boats crossing rivers and passengers on moving vehicles – relative motion 相对运动 problems. Read the subscripts as a chain: "A relative to B" plus "B relative to C" gives "A relative to C".

    Worked example. A boat that moves at $4.0\ \text{m/s}$ in still water heads straight across a river flowing at $3.0\ \text{m/s}$. Relative to the ground the boat moves at $\sqrt{4.0^2+3.0^2}=5.0\ \text{m/s}$, angled downstream. If the river is $80\ \text{m}$ wide, the crossing still takes $t=\dfrac{80}{4.0}=20\ \text{s}$ – only the across-stream component crosses the river; the current just carries the boat $60\ \text{m}$ downstream.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    reference frame/ˈrefrəns freɪm/ hệ quy chiếu
    relative motion/ˈrelətɪv ˈməʊʃn/ Chuyển động tương đối
    1.5

    Motion in Two or Three Dimensions

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 1.5.A: Describe the motion of an object moving in two or three dimensions.

    • 1.5.A.1 Motion in two or three dimensions can be analyzed using one-dimensional kinematic relationships if the motion is separated into components.
    • 1.5.A.2 Velocity and acceleration may be different in each dimension and may be nonuniform.
    • 1.5.A.3 Motion in one dimension may be changed without causing a change in a perpendicular dimension.
    • 1.5.A.4 Projectile motion is a special case of two-dimensional motion that has zero acceleration in one dimension and constant, nonzero acceleration in the second dimension.

    Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze the motion of an object in two dimensions. AP Physics C: Electricity and Magnetism expects students to also qualitatively describe the motion of a particle in three dimensions.

    Tiếng Việt

    Mục tiêu Học tập 1.5.A: Mô tả chuyển động của một vật di chuyển trong hai hoặc ba chiều.

    • 1.5.A.1 Chuyển động trong hai hoặc ba chiều có thể phân tích bằng các mối quan hệ động học một chiều nếu chuyển động được tách thành các thành phần.
    • 1.5.A.2 Vận tốc và gia tốc có thể khác nhau ở mỗi chiều và có thể không đồng đều.
    • 1.5.A.3 Chuyển động trong một chiều có thể thay đổi mà không gây ra sự thay đổi ở chiều vuông góc với nó.
    • 1.5.A.4 Chuyển động ném xiên là một trường hợp đặc biệt của chuyển động hai chiều có gia tốc bằng không ở một chiều và gia tốc không đổi, khác không ở chiều thứ hai.

    Câu Boundary: AP Physics C: Cơ học chỉ yêu cầu học sinh phân tích định lượng chuyển động của vật trong hai chiều. AP Physics C: Điện từ yêu cầu học sinh cũng mô tả định tính chuyển động của hạt trong ba chiều.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    In two or three dimensions, position is a vector $\vec{r}(t)=\langle x(t),y(t),z(t)\rangle$, and velocity and acceleration are its successive derivatives – each component handled independently.

    Worked example. $\vec{r}(t)=\big(2t^2\big)\hat{i}+\big(4t-t^3\big)\hat{j}$ (metres). Differentiating each component: $\vec{v}=4t\,\hat{i}+(4-3t^2)\,\hat{j}$ and $\vec{a}=4\,\hat{i}-6t\,\hat{j}$. At $t=1\ \text{s}$: $\vec{v}=4\hat{i}+1\hat{j}$, so the speed is $\sqrt{17}\approx4.1\ \text{m/s}$ – no new physics, just one derivative per component.

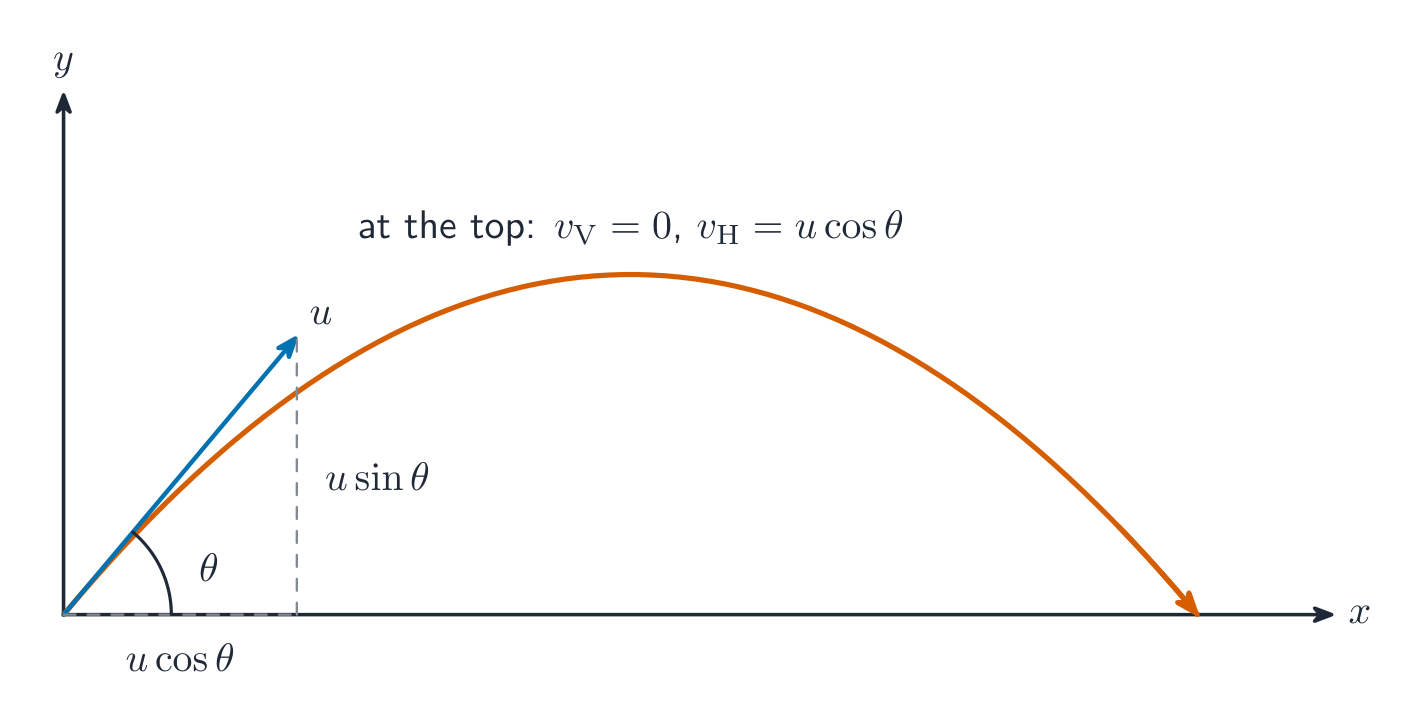
    A projectile launched at an angle: the horizontal and vertical motions are independent
    A projectile launched at an angle: the horizontal and vertical motions are independent

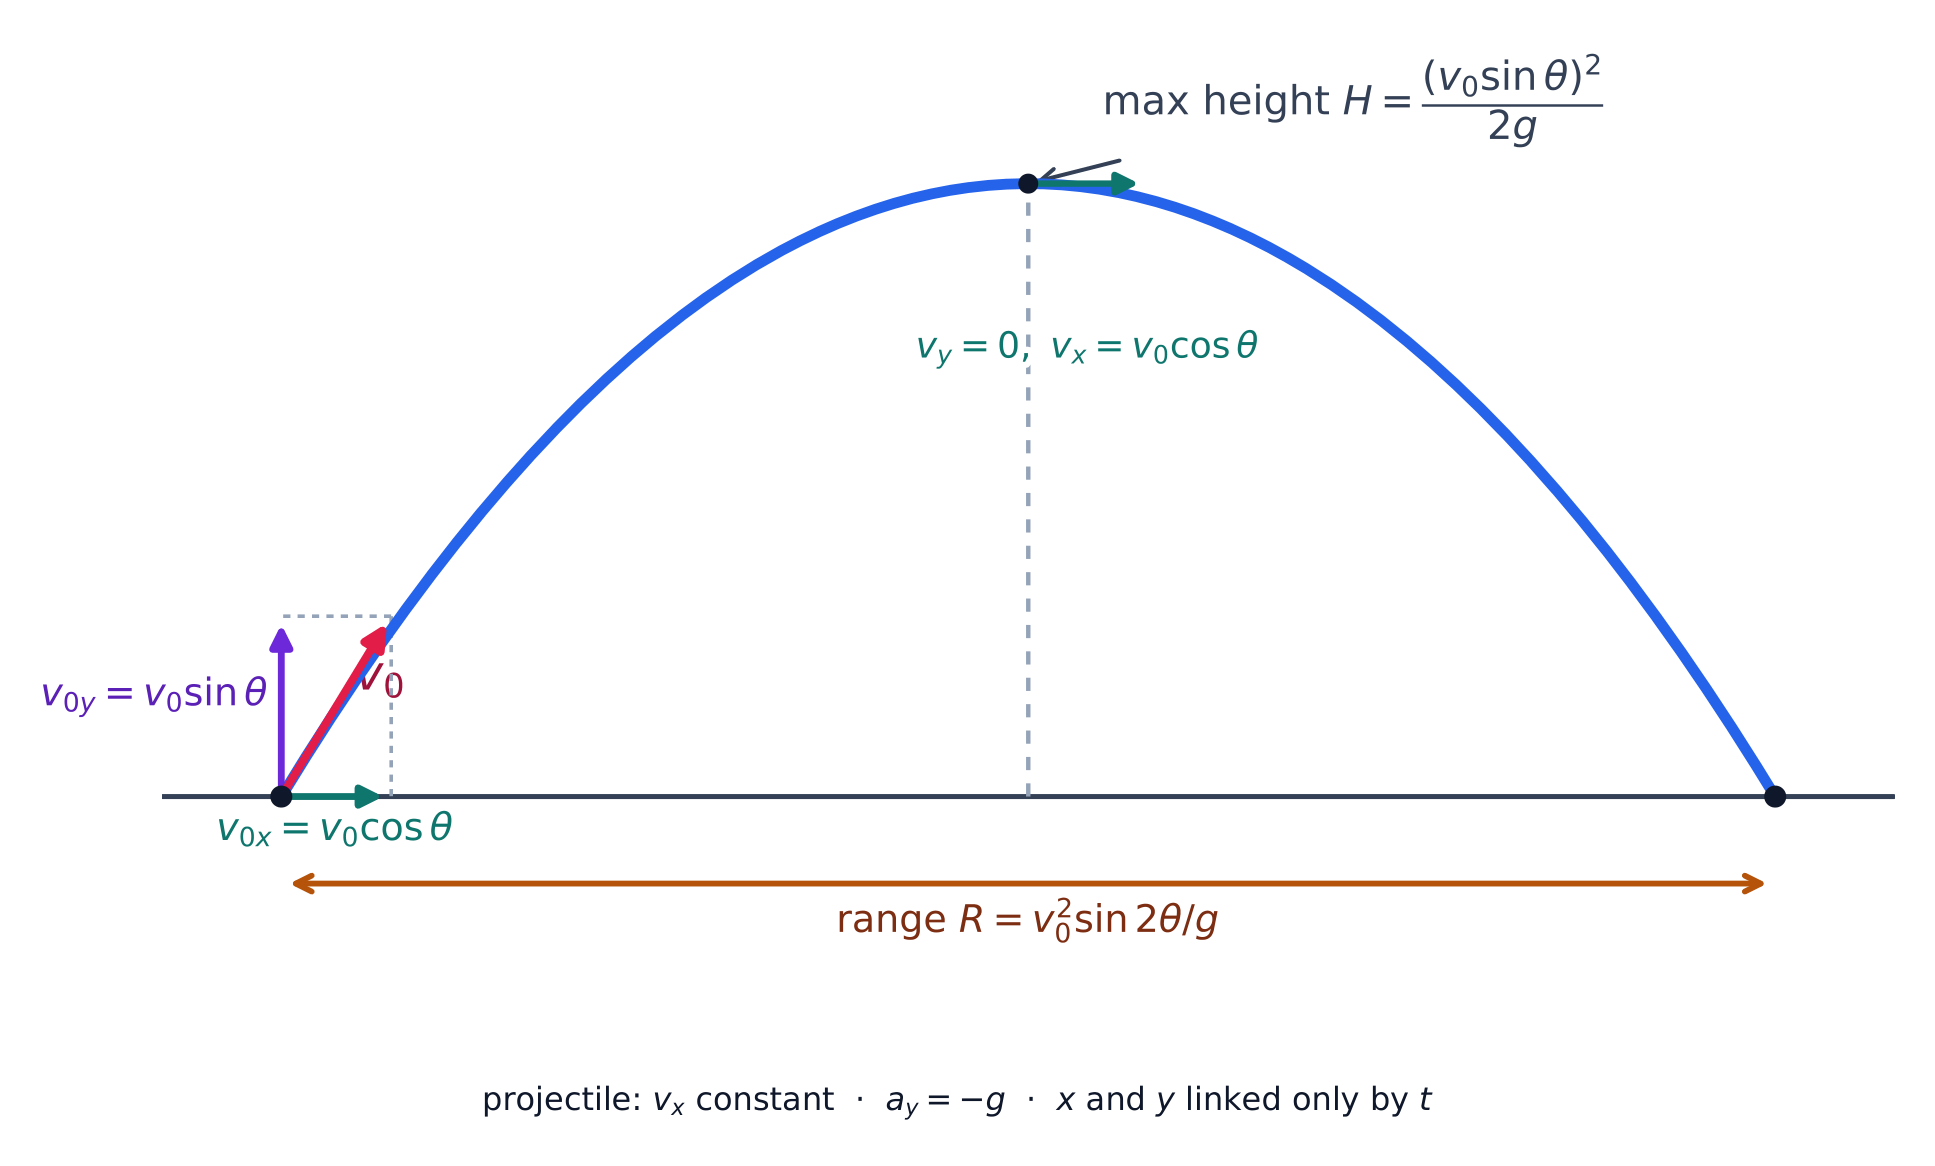
    For projectile motion 抛体运动, horizontal and vertical motions are independent, linked only by time $t$: horizontally $a_x=0$ (constant velocity), vertically $a_y=-g$. The path is a parabola. This component method extends to any two-dimensional motion where the accelerations along each axis are known.

    Worked example. A ball is launched at $20\ \text{m/s}$, $30^{\circ}$ above the horizontal ($g=9.8\ \text{m/s}^2$). The components are $v_{0x}=20\cos30^{\circ}=17.3\ \text{m/s}$ and $v_{0y}=20\sin30^{\circ}=10\ \text{m/s}$. The vertical motion sets the time: total flight $=\dfrac{2v_{0y}}{g}=\dfrac{20}{9.8}=2.0\ \text{s}$, maximum height $=\dfrac{v_{0y}^2}{2g}=5.1\ \text{m}$, and range $=v_{0x}\times2.0=35\ \text{m}$.

    A projectile launched at an angle: velocity components, maximum height, and range
    A projectile launched at an angle: velocity components, maximum height, and range
    Explore · ⁨Khám phá⁩

    Explore projectile motion

    Fire the projectile, then vary the angle and speed. The horizontal motion is steady while gravity acts only downward — together they trace a parabola. Find the angle that gives the greatest range (it peaks near $45^\circ$), and try the Moon. · ⁨Bắn vật bay, sau đó thay đổi góc và tốc độ. Chuyển động ngang ổn định trong khi trọng lực chỉ tác dụng xuống dưới — kết hợp chúng tạo thành đường parabol. Tìm góc cho phạm vi lớn nhất (đạt cực đại gần $45^\circ$), và thử trên Mặt Trăng.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    projectile motion/prəˈdʒektaɪl ˈməʊʃn/ chuyển động ném xiên
    1.5

    Exam tips

    • Resolve every vector into components before adding — never add magnitudes at an angle directly.
    • On Physics C you are expected to use calculus: velocity is $\vec v=\tfrac{d\vec r}{dt}$ and acceleration $\vec a=\tfrac{d\vec v}{dt}$; reverse with integration.
    • Carry and check units and treat direction with signs (choose a positive axis and stick to it).
    • Use the dot product for work-type quantities and the cross product for torque and angular momentum.
    • Sketch the vectors — a diagram catches sign and direction errors the algebra hides.
  • 2

    Force and Translational Dynamics · ⁨Lực và động học tịnh tiến⁩

    Watch lesson · ⁨Xem bài học⁩
    2.1

    Systems and Center of Mass

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.1.A: Describe the properties and interactions of a system.

    • 2.1.A.1 System properties are determined by the interactions between objects within the system.
    • 2.1.A.2 If the properties or interactions of the constituent objects within a system are not important in modeling the behavior of the macroscopic system, the system can itself be treated as a single object.
    • 2.1.A.3 Systems may allow interactions between constituent parts of the system and the environment, which may result in the transfer of energy or mass.
    • 2.1.A.4 Individual objects within a chosen system may behave differently from each other as well as from the system as a whole.
    • 2.1.A.5 The internal structure of a system affects the analysis of that system.
    • 2.1.A.6 As variables external to a system are changed, the system's substructure may change.

    Learning Objective 2.1.B: Describe the location of a system's center of mass with respect to the system's constituent parts.

    • 2.1.B.1 For objects or systems with symmetrical mass distributions, the center of mass is located on lines of symmetry.
    • 2.1.B.2 The location of a system's center of mass along a given axis can be calculated using the equation
      • Equation: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
    • 2.1.B.3 For a nonuniform solid that can be considered as a collection of differential masses, $dm$, the solid's center of mass can be calculated using the equation
      • Equation: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
      • 2.1.B.3.i The linear mass density of a rod or other linear rigid body is the derivative of the rod's mass with respect to the position of the differential mass element on the rigid body.
        • Equation: $\lambda = \dfrac{d}{d\ell} m(\ell)$
      • 2.1.B.3.ii If a function of mass density is given for a solid, the total mass can be determined by integrating the mass density over the length (one dimension), area (two dimensions), or volume (three dimensions) of the solid. For example:
        • Equation: $M_{\text{total}} = \int \rho(r)\, dV$
    • 2.1.B.4 A system can be modeled as a singular object that is located at the system's center of mass.
    Tiếng Việt

    Mục tiêu học tập 2.1.A: Mô tả các tính chất và tương tác của một hệ vật.

    • 2.1.A.1 Tính chất của hệ vật được xác định bởi các tương tác giữa các vật nằm bên trong hệ vật.
    • 2.1.A.2 Nếu các tính chất hoặc tương tác của các vật thành phần bên trong hệ vật không quan trọng trong việc mô hình hóa hành vi của hệ vật vĩ mô, thì bản thân hệ vật có thể được coi là một vật đơn lẻ.
    • 2.1.A.3 Hệ vật có thể cho phép tương tác giữa các bộ phận thành phần của hệ vật và môi trường, điều này có thể dẫn đến sự truyền năng lượng hoặc khối lượng.
    • 2.1.A.4 Các vật đơn lẻ bên trong một hệ vật đã chọn có thể có hành vi khác nhau so với nhau cũng như khác so với hệ vật như một toàn thể.
    • 2.1.A.5 Cấu trúc nội tại của hệ vật ảnh hưởng đến việc phân tích hệ vật đó.
    • 2.1.A.6 Khi các biến bên ngoài hệ vật thay đổi, cấu trúc con của hệ vật có thể thay đổi.

    Mục tiêu học tập 2.1.B: Mô tả vị trí trọng tâm của hệ vật so với các bộ phận thành phần của hệ vật.

    • 2.1.B.1 Đối với vật hoặc hệ có phân bố khối lượng đối xứng, tâm khối lượng nằm trên các đường đối xứng.
    • 2.1.B.2 Vị trí trọng tâm của hệ vật dọc theo một trục nhất định có thể được tính toán bằng phương trình
      • Phương trình: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
    • 2.1.B.3 Đối với vật rắn không đồng nhất có thể xem như một tập hợp các khối lượng vi phân, $dm$, tâm khối lượng của vật rắn có thể tính bằng phương trình
      • Phương trình: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
      • 2.1.B.3.i Mật độ khối lượng tuyến tính của thanh hoặc vật cứng dạng khác là đạo hàm của khối lượng thanh theo vị trí của phần tử khối lượng vi phân trên vật cứng.
        • Phương trình: $\lambda = \dfrac{d}{d\ell} m(\ell)$
      • 2.1.B.3.ii Nếu cho một hàm mật độ khối lượng của vật rắn, khối lượng tổng cộng có thể xác định bằng cách lấy tích phân mật độ khối lượng trên chiều dài (một chiều), diện tích (hai chiều) hoặc thể tích (ba chiều) của vật rắn. Ví dụ:
        • Phương trình: $M_{\text{total}} = \int \rho(r)\, dV$
    • 2.1.B.4 Một hệ có thể được mô hình hóa như một vật duy nhất nằm ở tâm khối lượng của hệ.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    A system 系统 is the object or objects you analyze, treated as a point at its center of mass 质心. For a set of masses, $x_{\text{cm}}=\dfrac{\sum m_i x_i}{\sum m_i}$; for a continuous body, $x_{\text{cm}}=\dfrac{1}{M}\int x\,dm$. Only external forces move the center of mass.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    system/ˈsɪstəm/ hệ
    center of mass/ˈsentə ɒv mæs/ trọng tâm
    2.2

    Forces and Free-Body Diagrams

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.2.A: Describe a force as an interaction between two objects or systems

    • 2.2.A.1 Forces are vector quantities that describe the interactions between objects or systems.
      • 2.2.A.1.i A force exerted on an object or system is always due to the interaction of that object or system with another object or system.
      • 2.2.A.1.ii An object or system cannot exert a net force on itself.
    • 2.2.A.2 Contact forces describe the interaction of an object or system touching another object or system and are macroscopic effects of interatomic electric forces.

    Learning Objective 2.2.B: Describe the forces exerted on an object or system using a free-body diagram.

    • 2.2.B.1 Free-body diagrams are useful tools for visualizing forces being exerted on a single object or system and for determining the equations that represent a physical situation.
    • 2.2.B.2 The free-body diagram of an object or system shows each of the forces exerted on the object or system by the environment.
    • 2.2.B.3 Forces exerted on an object or system are represented as vectors originating from the representation of the center of mass, such as a dot. A system is treated as though all of its mass is located at the center of mass.
    • 2.2.B.4 A coordinate system with one axis parallel to the direction of acceleration of the object or system simplifies the translation from free-body diagram to algebraic representation. For example, in a free-body diagram of an object on an inclined plane, it is useful to set one axis parallel to the surface of the incline.

    Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism only expect students to depict the forces exerted on objects, not the force components on free-body diagrams. On the AP Physics exams, individual forces represented on a free-body diagram must be drawn as individual straight arrows, originating on the dot and pointing in the direction of the force. Individual forces that are in the same direction must be drawn side by side, not overlapping.

    Tiếng Việt

    Mục tiêu học tập 2.2.A: Mô tả lực như một tương tác giữa hai vật thể hoặc hai hệ thống

    • 2.2.A.1 Lực là các đại lượng vectơ mô tả các tương tác giữa các vật hoặc các hệ vật.
      • 2.2.A.1.i Một lực tác dụng lên một vật thể hoặc hệ thống luôn là kết quả của sự tương tác giữa vật thể hoặc hệ thống đó với một vật thể hoặc hệ thống khác.
      • 2.2.A.1.ii Một vật hoặc hệ vật không thể tự tạo ra lực hợp tác dụng lên chính nó.
    • 2.2.A.2 Lực tiếp xúc mô tả sự tương tác của một vật hoặc hệ vật chạm vào một vật hoặc hệ vật khác và là hiệu ứng vĩ mô của các lực điện giữa các nguyên tử.

    Mục tiêu học tập 2.2.B: Mô tả các lực tác dụng lên một vật hoặc hệ vật bằng sơ đồ vật tự do.

    • 2.2.B.1 Sơ đồ vật tự do là công cụ hữu ích để trực quan hóa các lực đang tác dụng lên một vật hoặc hệ vật đơn lẻ và để xác định các phương trình đại diện cho tình huống vật lý.
    • 2.2.B.2 Sơ đồ lực tự do (free-body diagram) của một vật thể hoặc hệ thống hiển thị từng lực tác dụng lên vật thể hoặc hệ thống đó từ môi trường bên ngoài.
    • 2.2.B.3 Các lực tác dụng lên một vật hoặc hệ vật được biểu diễn dưới dạng các vectơ bắt đầu từ biểu diễn của trọng tâm, chẳng hạn như một chấm. Một hệ vật được xem xét như thể toàn bộ khối lượng của nó nằm ở trọng tâm.
    • 2.2.B.4 Một hệ tọa độ có một trục song song với hướng gia tốc của vật hoặc hệ vật sẽ đơn giản hóa quá trình chuyển đổi từ sơ đồ vật tự do sang biểu thức đại số. Ví dụ, trong sơ đồ vật tự do của một vật trên mặt phẳng nghiêng, việc thiết lập một trục song song với bề mặt mặt phẳng nghiêng là hữu ích.

    Tuyên bố giới hạn: AP Physics C: Cơ học và AP Physics C: Điện từ chỉ yêu cầu học sinh biểu diễn các lực tác dụng lên vật, không yêu cầu biểu diễn các thành phần lực trên sơ đồ lực tự do. Trong các kỳ thi AP Physics, mỗi lực riêng lẻ được biểu diễn trên sơ đồ lực tự do phải được vẽ dưới dạng mũi tên thẳng riêng biệt, bắt đầu từ điểm chấm và chỉ theo hướng của lực. Các lực riêng lẻ cùng hướng phải được vẽ cạnh nhau, không chồng lên nhau.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

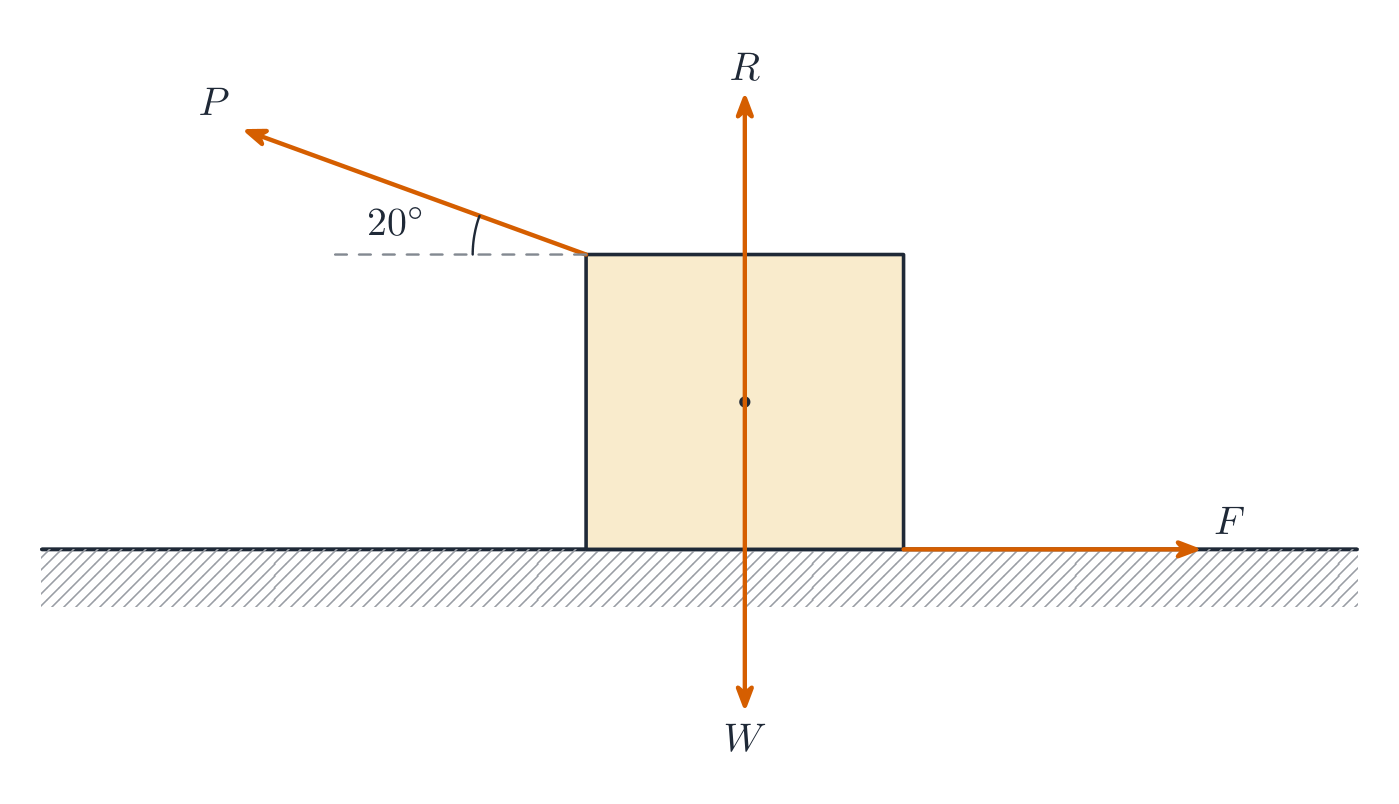
    A force 力 is a push or pull (a vector, in newtons). A free-body diagram 受力图 draws one object with an arrow for every force on it – weight, normal, tension, friction, applied, drag. Draw it first; it sets up every dynamics equation.

    A free-body diagram shows every force acting on one object
    A free-body diagram shows every force acting on one object
    Explore · ⁨Khám phá⁩

    Balance the forces on a free-body diagram

    A free-body diagram shows every force on one object as an arrow. The object accelerates only if the forces don't cancel — the net force sets $a=F/m$.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    force/fɔːs/ lực
    free-body diagram/friː ˈbɒdi ˈdaɪəɡræm/ sơ đồ vật thể tự do
    2.3

    Newton's Third Law

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.3.A: Describe the interaction of two objects or systems using Newton's third law and a representation of paired forces exerted on each object or system.

    • 2.3.A.1 Newton's third law describes the interaction of two objects or systems in terms of the paired forces that each exerts on the other.
      • Equation: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
    • 2.3.A.2 Interactions between objects within a system (internal forces) do not influence the motion of a system's center of mass.
    • 2.3.A.3 Tension is the macroscopic net result of forces that infinitesimal segments of a string, cable, chain, or similar system exert on each other in response to an external force.
      • 2.3.A.3.i An ideal string has negligible mass and does not stretch when under tension.
      • 2.3.A.3.ii The tension in an ideal string is the same at all points within the string.
      • 2.3.A.3.iii In a string with nonnegligible mass, tension may not be the same at all points within the string.
      • 2.3.A.3.iv An ideal pulley is a pulley that has negligible mass and rotates about an axle through its center of mass with negligible friction.
    Tiếng Việt

    Mục tiêu học tập 2.3.A: Mô tả tương tác giữa hai vật thể hoặc hệ thống bằng định luật Newton thứ ba và biểu diễn các cặp lực tác dụng lên mỗi vật thể hoặc hệ thống.

    • 2.3.A.1 Định luật Newton thứ ba mô tả tương tác giữa hai vật thể hoặc hệ thống thông qua các cặp lực mà mỗi bên tác dụng lên bên kia.
      • Phương trình: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
    • 2.3.A.2 Các tương tác giữa các vật thể bên trong một hệ (lực nội) không ảnh hưởng đến chuyển động của trọng tâm hệ.
    • 2.3.A.3 Lực căng (tension) là kết quả tổng hợp vĩ mô của các lực mà các phân đoạn vô cùng nhỏ của dây, cáp, xích hoặc hệ thống tương tự tác dụng lên nhau để phản ứng lại với một ngoại lực.
      • 2.3.A.3.i Dây lý tưởng có khối lượng không đáng kể và không bị giãn khi chịu lực căng.
      • 2.3.A.3.ii Lực căng trong dây lý tưởng là như nhau tại mọi điểm trong dây.
      • 2.3.A.3.iii Trong dây có khối lượng không nhỏ, lực căng có thể không bằng nhau tại mọi điểm trong dây.
      • 2.3.A.3.iv Ròng rọc lý tưởng là ròng rọc có khối lượng không đáng kể và quay quanh trục đi qua trọng tâm với ma sát không đáng kể.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

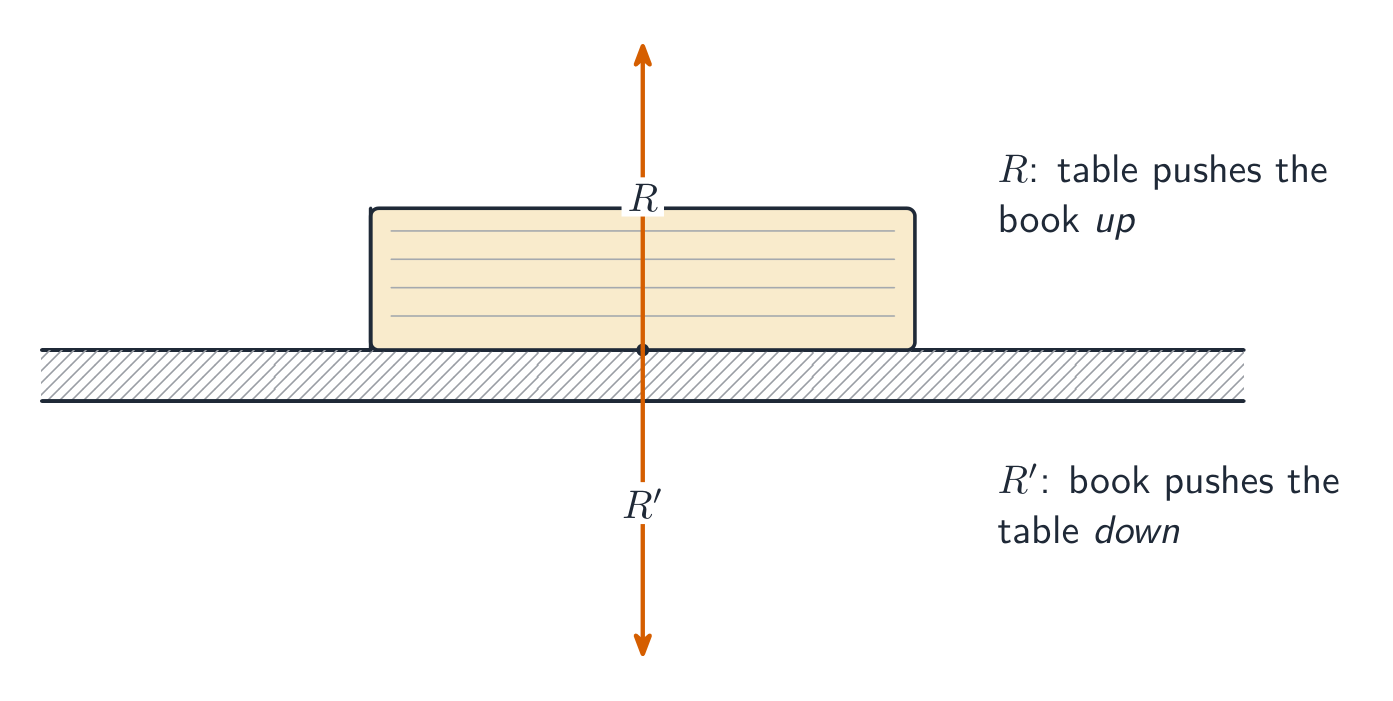
    Newton's third law 牛顿第三定律: A pushes B, B pushes back equally and oppositely. The pair acts on different objects, so it never cancels within one free-body diagram.

    A Newton's third-law pair: equal and opposite forces on two different objects
    A Newton's third-law pair: equal and opposite forces on two different objects
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Newton's third law/ˈnjuːtnz θɜːd lɔː/ định luật Newton thứ ba
    2.4

    Newton's First Law

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.4.A: Describe the conditions under which a system's velocity remains constant.

    • 2.4.A.1 The net force on a system is the vector sum of all forces exerted on the system.
    • 2.4.A.2 Translational equilibrium is the configuration of forces such that the net force exerted on a system is zero.
      • Derived equation: $\sum \vec{F}_i = 0$
    • 2.4.A.3 Newton's first law states that if the net force exerted on a system is zero, the velocity of that system will remain constant.
    • 2.4.A.4 Forces may be balanced in one dimension but unbalanced in another. The system's velocity will change only in the direction of the unbalanced force.
    • 2.4.A.5 An inertial reference frame is one from which an observer would verify Newton's first law of motion.
    Tiếng Việt

    Mục tiêu học tập 2.4.A: Mô tả các điều kiện để vận tốc của một hệ không đổi.

    • 2.4.A.1 Hợp lực tác dụng lên một hệ là tổng vectơ của tất cả các lực tác dụng lên hệ đó.
    • 2.4.A.2 Cân bằng tịnh tiến là trạng thái của lực sao cho lực tổng hợp tác dụng lên một hệ thống bằng không.
      • Phương trình suy ra: $\sum \vec{F}_i = 0$
    • 2.4.A.3 Định luật thứ nhất của Newton phát biểu rằng nếu hợp lực tác dụng lên một hệ bằng không, thì vận tốc của hệ đó sẽ không đổi.
    • 2.4.A.4 Các lực có thể cân bằng theo một chiều nhưng không cân bằng theo chiều khác. Vận tốc của hệ chỉ thay đổi theo hướng của lực không cân bằng.
    • 2.4.A.5 Hệ quy chiếu quán tính là hệ quy chiếu mà từ đó một quan sát viên có thể xác minh được định luật thứ nhất về chuyển động của Newton.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Newton's first law (inertia 惯性): with zero net force 合力, velocity stays constant – the object is in translational equilibrium 平动平衡.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    inertia/ɪˈnɜːʃə/ quán tính
    net force/net fɔːs/ lực hợp
    translational equilibrium/trænˈsleɪʃənl ˌiːkwɪˈlɪbrɪəm/ cân bằng tịnh tiến
    2.5

    Newton's Second Law

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.5.A: Describe the conditions under which a system's velocity changes.

    • 2.5.A.1 Unbalanced forces are a configuration of forces such that the net force exerted on a system is not equal to zero.
    • 2.5.A.2 Newton's second law of motion states that the acceleration of a system's center of mass has a magnitude proportional to the magnitude of the net force exerted on the system and is in the same direction as that net force.
      • Equation: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
    • 2.5.A.3 The velocity of a system's center of mass will only change if a nonzero net external force is exerted on that system.
    Tiếng Việt

    Mục tiêu học tập 2.5.A: Mô tả các điều kiện để vận tốc của một hệ thay đổi.

    • 2.5.A.1 Các lực không cân bằng là cấu hình lực sao cho hợp lực tác dụng lên hệ khác không.
    • 2.5.A.2 Định luật thứ hai của Newton phát biểu rằng gia tốc của trọng tâm hệ có độ lớn tỷ lệ thuận với độ lớn của hợp lực tác dụng lên hệ và cùng hướng với hợp lực đó.
      • Phương trình: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
    • 2.5.A.3 Vận tốc của trọng tâm hệ chỉ thay đổi khi có một hợp lực ngoài khác không tác dụng lên hệ.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    The general form uses momentum:

    $$\sum\vec{F}=\frac{d\vec{p}}{dt}=m\vec{a}\ \ (\text{for constant mass}).$$
    Apply it one axis at a time. When forces depend on velocity or position, this becomes a differential equation 微分方程 to solve.

    Worked example. A $2.0\ \text{kg}$ block slides down a frictionless incline 斜面 at $30^{\circ}$. Only the along-ramp component of gravity drives it, so $a=g\sin30^{\circ}=9.8(0.5)=4.9\ \text{m/s}^2$, independent of the mass.

    Worked example (two bodies). A $6.0\ \text{kg}$ cart on a frictionless table is pulled by a string over a light pulley to a hanging $2.0\ \text{kg}$ mass. Treat the pair as one system: only the hanging weight drives it, so $a=\dfrac{2.0(9.8)}{8.0}=2.45\ \text{m/s}^2$. Then isolate the cart alone to find the string tension 张力: $T=6.0(2.45)\approx15\ \text{N}$. System first for $a$, single body for internal forces – that two-step is the standard pattern.

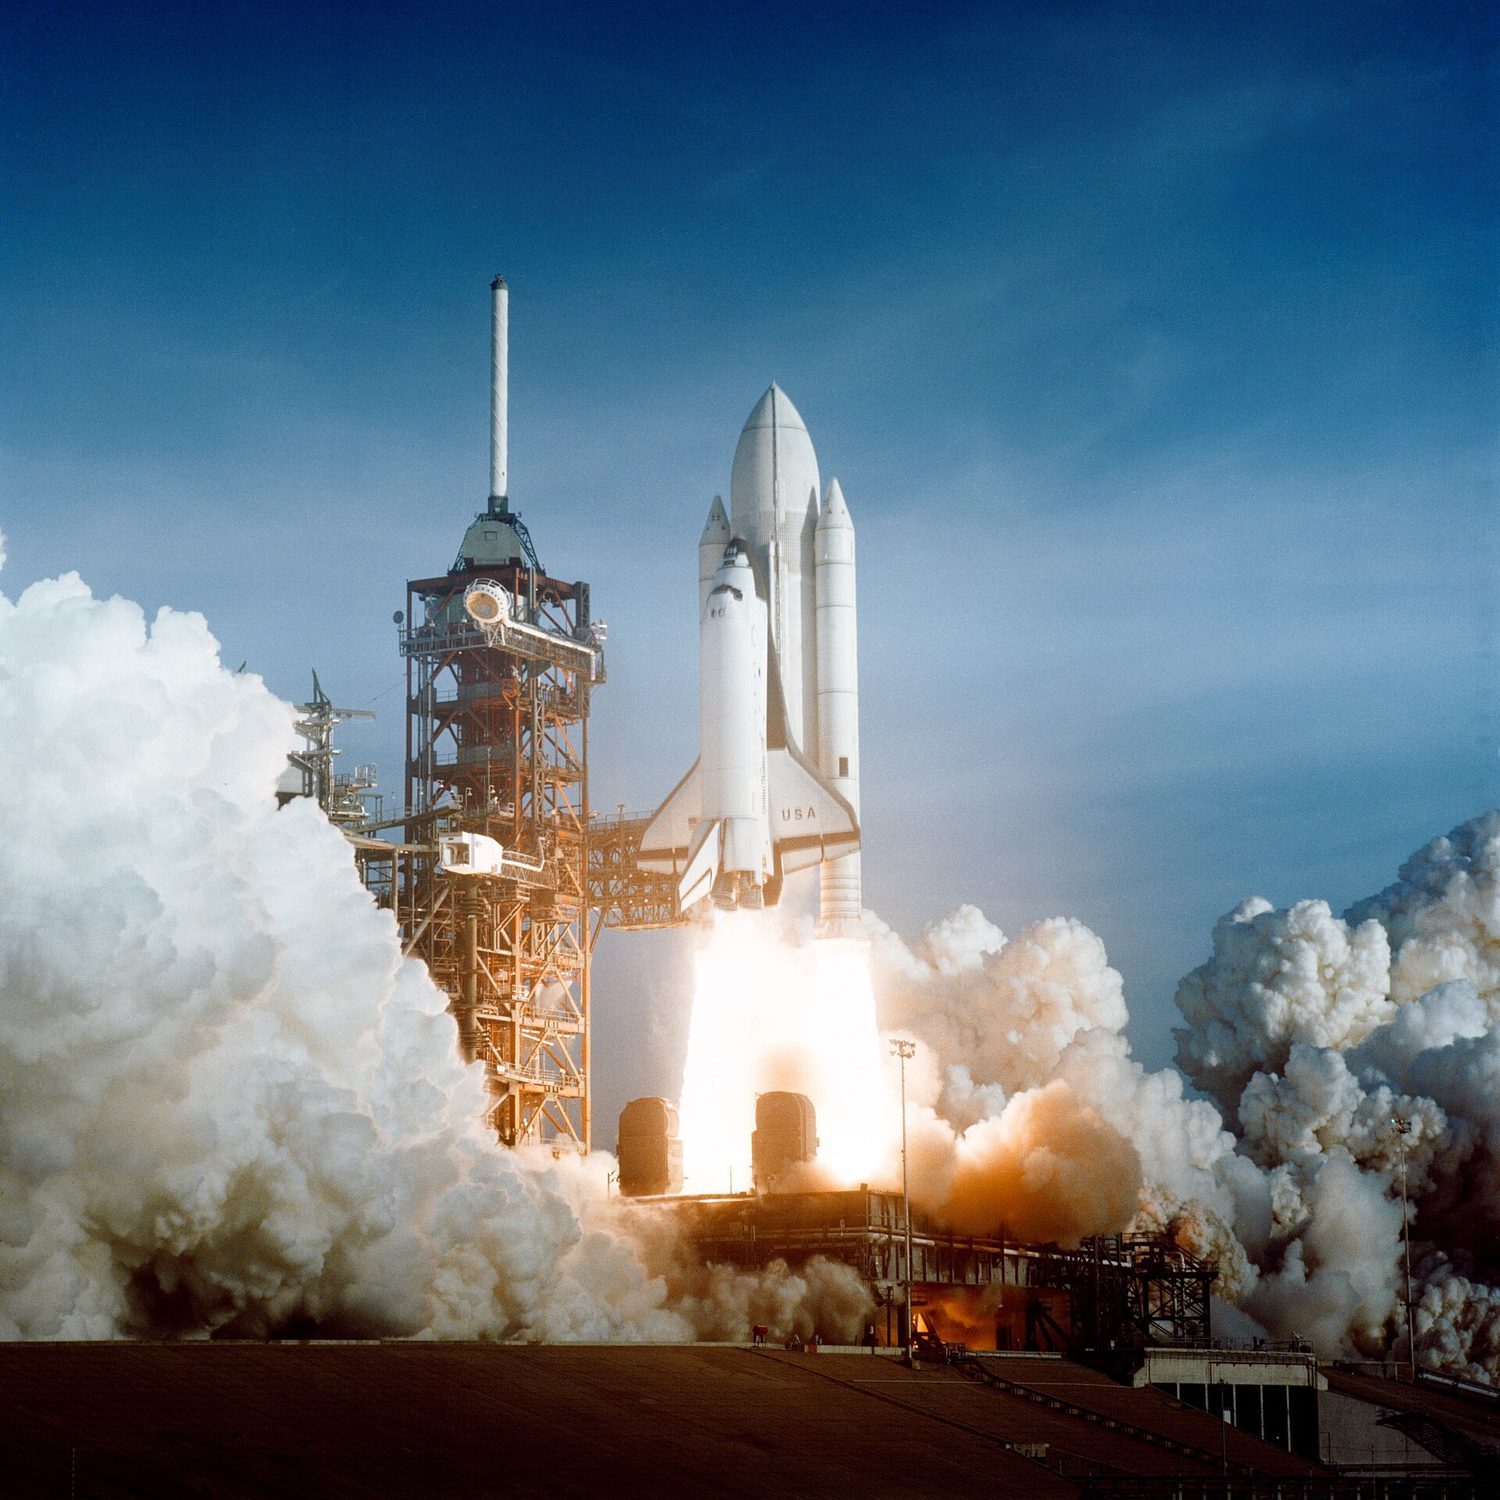
    A rocket launch: net force changes momentum — F_net = ma for translational dynamics
    A rocket launch: net force changes momentum — F_net = ma for translational dynamics
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ phương trình vi phân
    incline/ɪnˈklaɪn/ Mặt nghiêng
    tension/ˈtenʃn/ lực căng
    2.6

    Gravitational Force

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.6.A: Describe the gravitational interaction between two objects or systems with mass.

    • 2.6.A.1 Newton's law of universal gravitation describes the gravitational force between two objects or systems as directly proportional to each of their masses and inversely proportional to the square of the distance between the systems' centers of mass.
      • Equation: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
      • 2.6.A.1.i The gravitational force is attractive.
      • 2.6.A.1.ii The gravitational force is always exerted along the line connecting the center of mass of the two interacting systems.
      • 2.6.A.1.iii The gravitational force on a system can be considered to be exerted on the system's center of mass.
    • 2.6.A.2 A field models the effects of a noncontact force exerted on an object at various positions in space.
      • 2.6.A.2.i The magnitude of the gravitational field created by a system of mass $M$ at a point in space is equal to the ratio of the gravitational force exerted by the system on a test object of mass $m$ to the mass of the test object.
        • Derived equation: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
      • 2.6.A.2.ii If the gravitational force is the only force exerted on an object, the observed acceleration of the object (in $\text{m/s}^2$) is numerically equal to the magnitude of the gravitational field strength (in $\text{N/kg}$) at that location.
    • 2.6.A.3 The gravitational force exerted by an astronomical body on a relatively small nearby object is called weight.
      • Derived equation: $\text{Weight} = F_g = mg$

    Learning Objective 2.6.B: Describe situations in which the gravitational force can be considered constant.

    • 2.6.B.1 If the gravitational force between two systems' centers of mass has a negligible change as the relative position of the two systems changes, the gravitational force can be considered constant at all points between the initial and final positions of the systems.
    • 2.6.B.2 Near the surface of Earth, the strength of the gravitational field is
      • Equation: $g \approx 10\ \text{N/kg}$

    Learning Objective 2.6.C: Describe the conditions under which the magnitude of a system's apparent weight is different from the magnitude of the gravitational force exerted on that system.

    • 2.6.C.1 The magnitude of the apparent weight of a system is the magnitude of the normal force exerted on the system.
    • 2.6.C.2 If the system is accelerating, the apparent weight of the system is not equal to the magnitude of the gravitational force exerted on the system.
    • 2.6.C.3 A system appears weightless when there are no forces exerted on the system or when the force of gravity is the only force exerted on the system.
    • 2.6.C.4 The equivalence principle states that an observer in a noninertial reference frame is unable to distinguish between an object's apparent weight and the gravitational force exerted on the object by a gravitational field.

    Learning Objective 2.6.D: Describe inertial and gravitational mass.

    • 2.6.D.1 Objects have inertial mass, or inertia, a property that determines how much an object's motion resists changes when interacting with another object.
    • 2.6.D.2 Gravitational mass is related to the force of attraction between two systems with mass.
    • 2.6.D.3 Inertial mass and gravitational mass have been experimentally verified to be equivalent.

    Learning Objective 2.6.E: Describe the gravitational force exerted on an object by a uniform spherical distribution of mass.

    • 2.6.E.1 The net gravitational force exerted on an object by a uniform spherical distribution of mass is the sum of the individual forces from small differential masses that comprise the distribution.
    • 2.6.E.2 Newton's shell theorem describes the net gravitational force exerted on an object by a uniform spherical shell of mass.
      • 2.6.E.2.i The net gravitational force exerted on an object inside a thin spherical shell is zero.
      • 2.6.E.2.ii The net gravitational force exerted on an object outside a thin spherical shell can be determined by treating the shell as a single massive object located at the center of the shell.
      • 2.6.E.2.iii An object inside a sphere of uniform density experiences a net gravitational force from only a partial mass of the sphere.
      • 2.6.E.2.iv The partial mass of a sphere that contributes to the net gravitational force exerted on an object within that sphere is the portion of the sphere's mass located a distance less than or equal to the object's distance from the center of the sphere and can be calculated using the density of the sphere.
        • Derived equation: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
    • 2.6.E.3 The gravitational force exerted on an object within a uniform sphere can be shown to be proportional to the object's distance from the sphere's center.
      • Derived equation: $F_{g,\text{partial}} = -k r_{\text{partial}}$

    Boundary statement: AP Physics C: Mechanics does not expect students to mathematically prove or derive Newton's shell theorem.

    Tiếng Việt

    Mục tiêu học tập 2.6.A: Mô tả sự tương tác hấp dẫn giữa hai vật thể hoặc hệ có khối lượng.

    • 2.6.A.1 Định luật vạn vật hấp dẫn của Newton mô tả lực hấp dẫn giữa hai vật thể hoặc hệ tỷ lệ thuận trực tiếp với mỗi khối lượng của chúng và tỷ lệ nghịch với bình phương khoảng cách giữa các trọng tâm của hệ.
      • Phương trình: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
      • 2.6.A.1.i Lực hấp dẫn là lực hút.
      • 2.6.A.1.ii Lực hấp dẫn luôn được tác dụng dọc theo đường nối tâm khối lượng của hai hệ thống tương tác.
      • 2.6.A.1.iii Lực hấp dẫn tác dụng lên một hệ có thể được xem là tác dụng lên trọng tâm của hệ đó.
    • 2.6.A.2 Trường lực mô phỏng tác dụng của một lực không tiếp xúc tác dụng lên một vật ở các vị trí khác nhau trong không gian.
      • 2.6.A.2.i Độ lớn của trường hấp dẫn tạo bởi một hệ có khối lượng $M$ tại một điểm trong không gian bằng tỷ số giữa lực hấp dẫn do hệ tác dụng lên vật thử có khối lượng $m$ và khối lượng của vật thử.
        • Phương trình suy ra: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
      • 2.6.A.2.ii Nếu lực hấp dẫn là lực duy nhất tác dụng lên một vật, gia tốc quan sát được của vật (trong $\text{m/s}^2$) có giá trị tuyệt đối bằng độ lớn của cường độ trường hấp dẫn (trong $\text{N/kg}$) tại vị trí đó.
    • 2.6.A.3 Lực hấp dẫn do một thiên thể tác dụng lên một vật nhỏ gần đó được gọi là trọng lượng.
      • Phương trình suy ra: $\text{Weight} = F_g = mg$

    Mục tiêu học tập 2.6.B: Mô tả các tình huống trong đó lực hấp dẫn có thể được coi là không đổi.

    • 2.6.B.1 Nếu sự thay đổi của lực hấp dẫn giữa các trọng tâm của hai hệ là không đáng kể khi vị trí tương đối của hai hệ thay đổi, thì lực hấp dẫn có thể được coi là không đổi tại mọi điểm giữa vị trí ban đầu và cuối cùng của hệ.
    • 2.6.B.2 Gần bề mặt Trái Đất, độ lớn của trường hấp dẫn là
      • Phương trình: $g \approx 10\ \text{N/kg}$

    Mục tiêu học tập 2.6.C: Mô tả các điều kiện để độ lớn của trọng lượng biểu kiến của một hệ khác với độ lớn của lực hấp dẫn tác dụng lên hệ đó.

    • 2.6.C.1 Độ lớn của trọng lượng biểu kiến của một hệ là độ lớn của lực pháp tuyến tác dụng lên hệ.
    • 2.6.C.2 Nếu hệ đang gia tốc, trọng lượng biểu kiến của hệ không bằng độ lớn của lực hấp dẫn tác dụng lên hệ.
    • 2.6.C.3 Một hệ trông như mất trọng lượng khi không có lực nào tác dụng lên hệ hoặc khi lực hấp dẫn là lực duy nhất tác dụng lên hệ.
    • 2.6.C.4 Nguyên lý tương đương phát biểu rằng một quan sát viên trong hệ quy chiếu phi quán tính không thể phân biệt được giữa trọng lượng biểu kiến của một vật và lực hấp dẫn do trường hấp dẫn tác dụng lên vật đó.

    Mục tiêu học tập 2.6.D: Mô tả khối lượng quán tính và khối lượng hấp dẫn.

    • 2.6.D.1 Các vật có khối lượng quán tính, hay quán tính, là thuộc tính quyết định mức độ chuyển động của vật chống lại sự thay đổi khi tương tác với một vật khác.
    • 2.6.D.2 Khối lượng hấp dẫn liên quan đến lực hút giữa hai hệ có khối lượng.
    • 2.6.D.3 Khối lượng quán tính và khối lượng hấp dẫn đã được xác minh bằng thực nghiệm là tương đương nhau.

    Mục tiêu học tập 2.6.E: Mô tả lực hấp dẫn tác dụng lên một vật bởi một phân bố khối lượng hình cầu đồng đều.

    • 2.6.E.1 Lực hấp dẫn tổng hợp tác dụng lên một vật bởi một phân bố khối lượng hình cầu đồng đều là tổng của các lực riêng lẻ từ các phần khối lượng vi phân nhỏ cấu thành nên phân bố đó.
    • 2.6.E.2 Định lý vỏ cầu của Newton mô tả lực hấp dẫn tổng hợp tác dụng lên một vật bởi một vỏ cầu hình cầu có khối lượng đồng đều.
      • 2.6.E.2.i Lực hấp dẫn tổng hợp tác dụng lên một vật nằm bên trong một vỏ cầu mỏng bằng không.
      • 2.6.E.2.ii Lực hấp dẫn tổng hợp tác dụng lên một vật nằm bên ngoài một vỏ cầu mỏng có thể được xác định bằng cách coi vỏ cầu như một vật thể khối lượng đơn lẻ đặt tại tâm của vỏ cầu.
      • 2.6.E.2.iii Một vật nằm bên trong một khối cầu có mật độ đồng đều chịu một lực hấp dẫn tổng hợp chỉ đến từ một phần khối lượng của khối cầu đó.
      • 2.6.E.2.iv Phần khối lượng của khối cầu đóng góp vào lực hấp dẫn tổng hợp tác dụng lên một vật nằm bên trong khối cầu đó là phần khối lượng của khối cầu nằm ở khoảng cách nhỏ hơn hoặc bằng khoảng cách từ vật đến tâm khối cầu, và có thể được tính toán sử dụng mật độ của khối cầu.
        • Phương trình suy ra: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
    • 2.6.E.3 Có thể chứng minh rằng lực hấp dẫn tác dụng lên một vật nằm bên trong một khối cầu đồng đều tỷ lệ thuận với khoảng cách của vật đến tâm khối cầu.
      • Phương trình suy ra: $F_{g,\text{partial}} = -k r_{\text{partial}}$

    Tuyên bố giới hạn: AP Physics C: Cơ học không yêu cầu học sinh phải chứng minh bằng toán học hoặc suy diễn định lý vỏ cầu của Newton.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

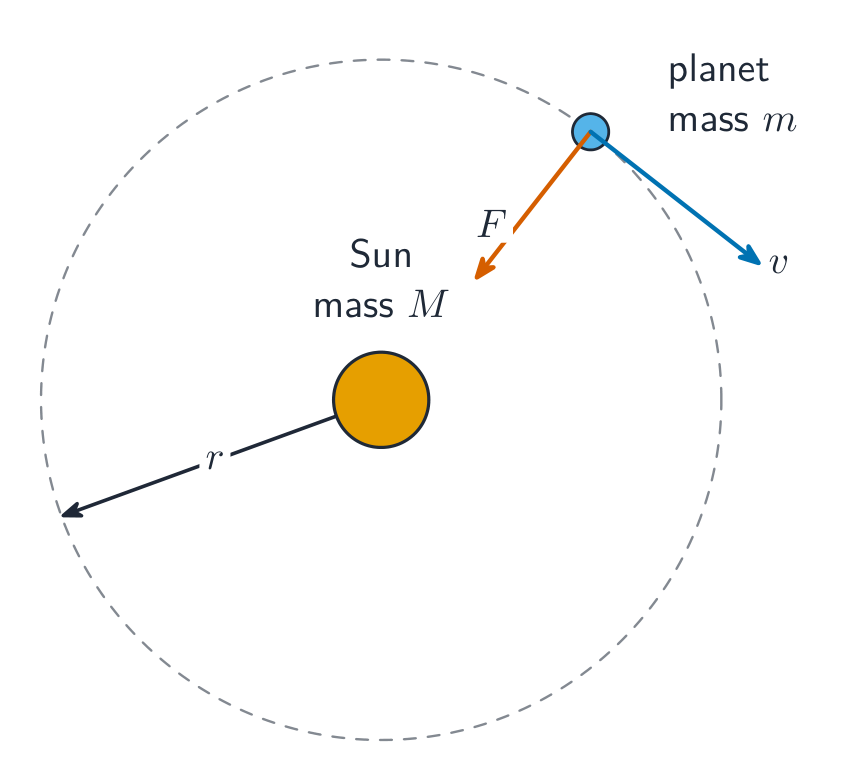
    Orbital motion (Kepler's 2nd law)

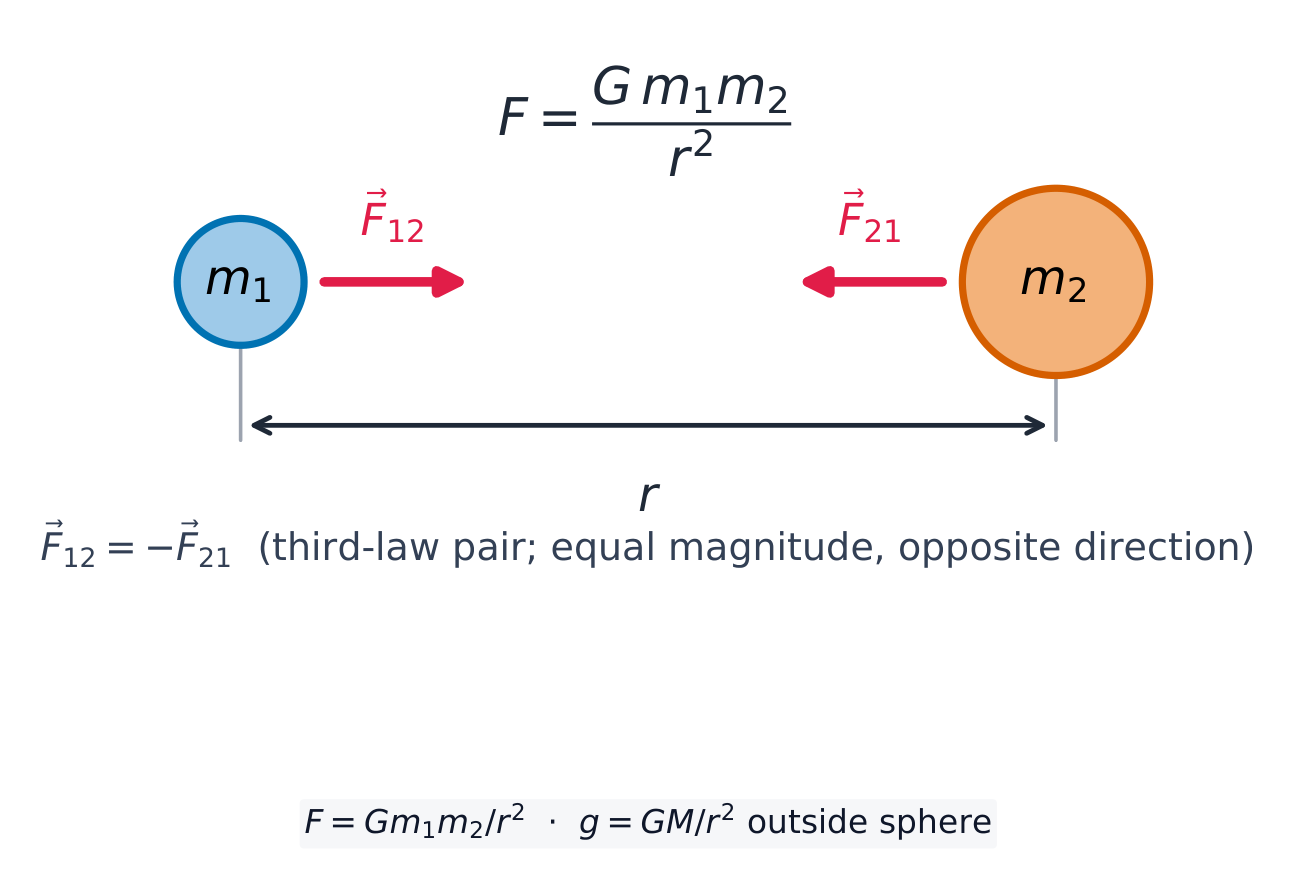
    Near a surface, weight is $F_g=mg$. In general, Newton's law of gravitation 万有引力定律:

    $$F_g=\frac{Gm_1m_2}{r^2},$$
    attractive and inverse-square. The gravitational field is $g=\dfrac{GM}{r^2}$.

    Two masses attract each other with equal, opposite, inverse-square forces along the line joining them
    Two masses attract each other with equal, opposite, inverse-square forces along the line joining them
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Newton's law of gravitation/ˈnjuːtnz lɔː ɒv ˌɡrævɪˈteɪʃn/ Định luật vạn vật hấp dẫn của Newton
    2.7

    Kinetic and Static Friction

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.7.A: Describe kinetic friction between two surfaces.

    • 2.7.A.1 Kinetic friction occurs when two surfaces in contact move relative to each other.
      • 2.7.A.1.i The kinetic friction force is exerted in a direction opposite the motion of each surface relative to the other surface.
      • 2.7.A.1.ii The force of friction between two surfaces does not depend on the size of the surface area of contact.
    • 2.7.A.2 The magnitude of the kinetic friction force exerted on an object is the product of the normal force the surface exerts on the object and the coefficient of kinetic friction.
      • Equation: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
      • 2.7.A.2.i The coefficient of kinetic friction depends on the material properties of the surfaces that are in contact.
      • 2.7.A.2.ii Normal force is the perpendicular component of the force exerted on an object by the surface with which it is in contact; it is directed away from the surface.

    Learning Objective 2.7.B: Describe static friction between two surfaces.

    • 2.7.B.1 Static friction may occur between the contacting surfaces of two objects that are not moving relative to each other.
    • 2.7.B.2 Static friction adopts the value and direction required to prevent an object from slipping or sliding on a surface.
      • Equation: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
      • 2.7.B.2.i Slipping and sliding refer to situations in which two surfaces are moving relative to each other.
      • 2.7.B.2.ii There exists a maximum value for which static friction will prevent an object from slipping on a given surface.
        • Derived equation: $F_{f,s,\text{max}} = \mu_s F_N$
    • 2.7.B.3 The coefficient of static friction is typically greater than the coefficient of kinetic friction for a given pair of surfaces.
    Tiếng Việt

    Mục tiêu học tập 2.7.A: Mô tả ma sát trượt giữa hai bề mặt.

    • 2.7.A.1 Ma sát động xảy ra khi hai bề mặt tiếp xúc chuyển động tương đối với nhau.
      • 2.7.A.1.i Lực ma sát trượt được tác dụng theo hướng ngược lại với chuyển động của mỗi bề mặt so với bề mặt còn lại.
      • 2.7.A.1.ii Độ lớn lực ma sát giữa hai bề mặt không phụ thuộc vào diện tích bề mặt tiếp xúc.
    • 2.7.A.2 Độ lớn của lực ma sát động tác dụng lên một vật bằng tích của lực pháp tuyến mà bề mặt tác dụng lên vật và hệ số ma sát động.
      • Phương trình: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
      • 2.7.A.2.i Hệ số ma sát động phụ thuộc vào các đặc tính vật liệu của các bề mặt tiếp xúc.
      • 2.7.A.2.ii Lực pháp tuyến là thành phần vuông góc của lực tác dụng lên vật bởi bề mặt tiếp xúc; nó hướng ra khỏi bề mặt.

    Mục tiêu học tập 2.7.B: Mô tả ma sát tĩnh giữa hai bề mặt.

    • 2.7.B.1 Ma sát tĩnh có thể xuất hiện giữa các bề mặt tiếp xúc của hai vật đang đứng yên tương đối với nhau.
    • 2.7.B.2 Ma sát tĩnh nhận giá trị và hướng cần thiết để ngăn vật trượt hoặc trượt trên bề mặt.
      • Phương trình: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
      • 2.7.B.2.i Trượt và trượt refer đến các tình huống trong đó hai bề mặt chuyển động tương đối với nhau.
      • 2.7.B.2.ii Tồn tại một giá trị cực đại mà tại đó ma sát tĩnh sẽ ngăn vật trượt trên một bề mặt cho trước.
        • Phương trình suy ra: $F_{f,s,\text{max}} = \mu_s F_N$
    • 2.7.B.3 Hệ số ma sát tĩnh thường lớn hơn hệ số ma sát động đối với một cặp bề mặt cho trước.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Friction 摩擦力 opposes sliding along a surface: kinetic 动摩擦 $f_k=\mu_k N$ while sliding, and static 静摩擦 $f_s\le\mu_s N$ up to a maximum before sliding. $N$ is the normal force 法向力. Note the inequality: static friction is only as large as it needs to be, and $\mu_s N$ is its ceiling, not its value.

    Worked example. The same block on the same $30^{\circ}$ incline, now with $\mu_k=0.20$. Perpendicular to the ramp: $N=mg\cos30^{\circ}$. Along the ramp: $ma=mg\sin30^{\circ}-\mu_k mg\cos30^{\circ}$, so $a=g(\sin30^{\circ}-0.20\cos30^{\circ})=9.8(0.500-0.173)=3.2\ \text{m/s}^2$ – the mass cancels again.

    Explore · ⁨Khám phá⁩

    Slide a block down a slope with friction

    Friction opposes motion up to a maximum $\mu N$. Tilt the slope until gravity's pull along it beats static friction and the block starts to slide.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Friction/ˈfrɪkʃn/ Ma sát
    kinetic/kɪˈnetɪk/ động
    static/ˈstætɪk/ bất biến
    normal force/ˈnɔːml fɔːs/ lực pháp tuyến
    2.8

    Spring Forces

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.8.A: Describe the force exerted on an object by an ideal spring.

    • 2.8.A.1 An ideal spring has negligible mass and exerts a force that is proportional to the change in its length as measured from its relaxed length. A nonideal spring either has nonnegligible mass or exerts a force that is not proportional to the change in its length as measured from its relaxed length.
    • 2.8.A.2 The magnitude of the force exerted by an ideal spring on an object is given by Hooke's law:
      • Equation: $\vec{F}_s = -k \Delta \vec{x}$
    • 2.8.A.3 The force exerted on an object by a spring is always directed toward the equilibrium position of the object–spring system.

    Learning Objective 2.8.B: Describe the equivalent spring constant of a combination of springs exerting forces on an object.

    • 2.8.B.1 A collection of springs that exert forces on an object may behave as though they were a single spring with an equivalent spring constant $k_{\text{eq}}$.
      • 2.8.B.1.i The inverse of the equivalent spring constant of a set of springs in series is equal to the sum of the inverses of the individual spring constants.
        • Derived equation: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
      • 2.8.B.1.ii The equivalent spring constant of a set of springs arranged in series is smaller than the smallest constituent spring constant.
      • 2.8.B.1.iii The equivalent spring constant of a set of springs arranged in parallel is the sum of the individual spring constants.
        • Derived equation: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$

    Boundary statement: AP Physics C: Mechanics only expects students to find the effective spring constant of systems of springs that are arranged either in series or in parallel and does not expect students to find the effective spring constant of a system in which springs are arranged in both series and parallel.

    Tiếng Việt

    Mục tiêu học tập 2.8.A: Mô tả lực tác dụng lên một vật bởi một lò xo lý tưởng.

    • 2.8.A.1 Một lò xo lý tưởng có khối lượng không đáng kể và tác dụng một lực tỷ lệ thuận với độ biến dạng (thay đổi chiều dài) của nó khi đo từ chiều dài tự nhiên. Một lò xo phi lý tưởng hoặc có khối lượng không thể bỏ qua hoặc tác dụng một lực không tỷ lệ thuận với độ biến dạng của nó khi đo từ chiều dài tự nhiên.
    • 2.8.A.2 Độ lớn của lực do lò xo lý tưởng tác dụng lên một vật được cho bởi định luật Hooke:
      • Phương trình: $\vec{F}_s = -k \Delta \vec{x}$
    • 2.8.A.3 Lực do lò xo tác dụng lên vật luôn hướng về vị trí cân bằng của hệ vật-lò xo.

    Mục tiêu học tập 2.8.B: Mô tả hằng số lò xo tương đương của một tổ hợp lò xo tác dụng lực lên một vật.

    • 2.8.B.1 Một tập hợp các lò xo tác dụng lực lên một vật có thể hoạt động như thể chúng là một lò xo đơn với hằng số lò xo tương đương $k_{\text{eq}}$.
      • 2.8.B.1.i nghịch đảo của hằng số lò xo tương đương của một bộ lò xo mắc nối tiếp bằng tổng các nghịch đảo của các hằng số lò xo riêng lẻ.
        • Phương trình suy ra: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
      • 2.8.B.1.ii Hằng số lò xo tương đương của một bộ lò xo mắc nối tiếp nhỏ hơn hằng số lò xo thành phần nhỏ nhất.
      • 2.8.B.1.iii Hằng số lò xo tương đương của một bộ lò xo mắc song song bằng tổng các hằng số lò xo riêng lẻ.
        • Phương trình suy ra: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$

    Tuyên bố giới hạn: AP Physics C: Cơ học chỉ yêu cầu học sinh tìm hằng số lò xo hiệu dụng của các hệ thống lò xo mắc nối tiếp hoặc mắc song song và không yêu cầu học sinh tìm hằng số lò xo hiệu dụng của hệ thống mà trong đó các lò xo được mắc cả nối tiếp lẫn song song.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Hooke's law & the elastic limit

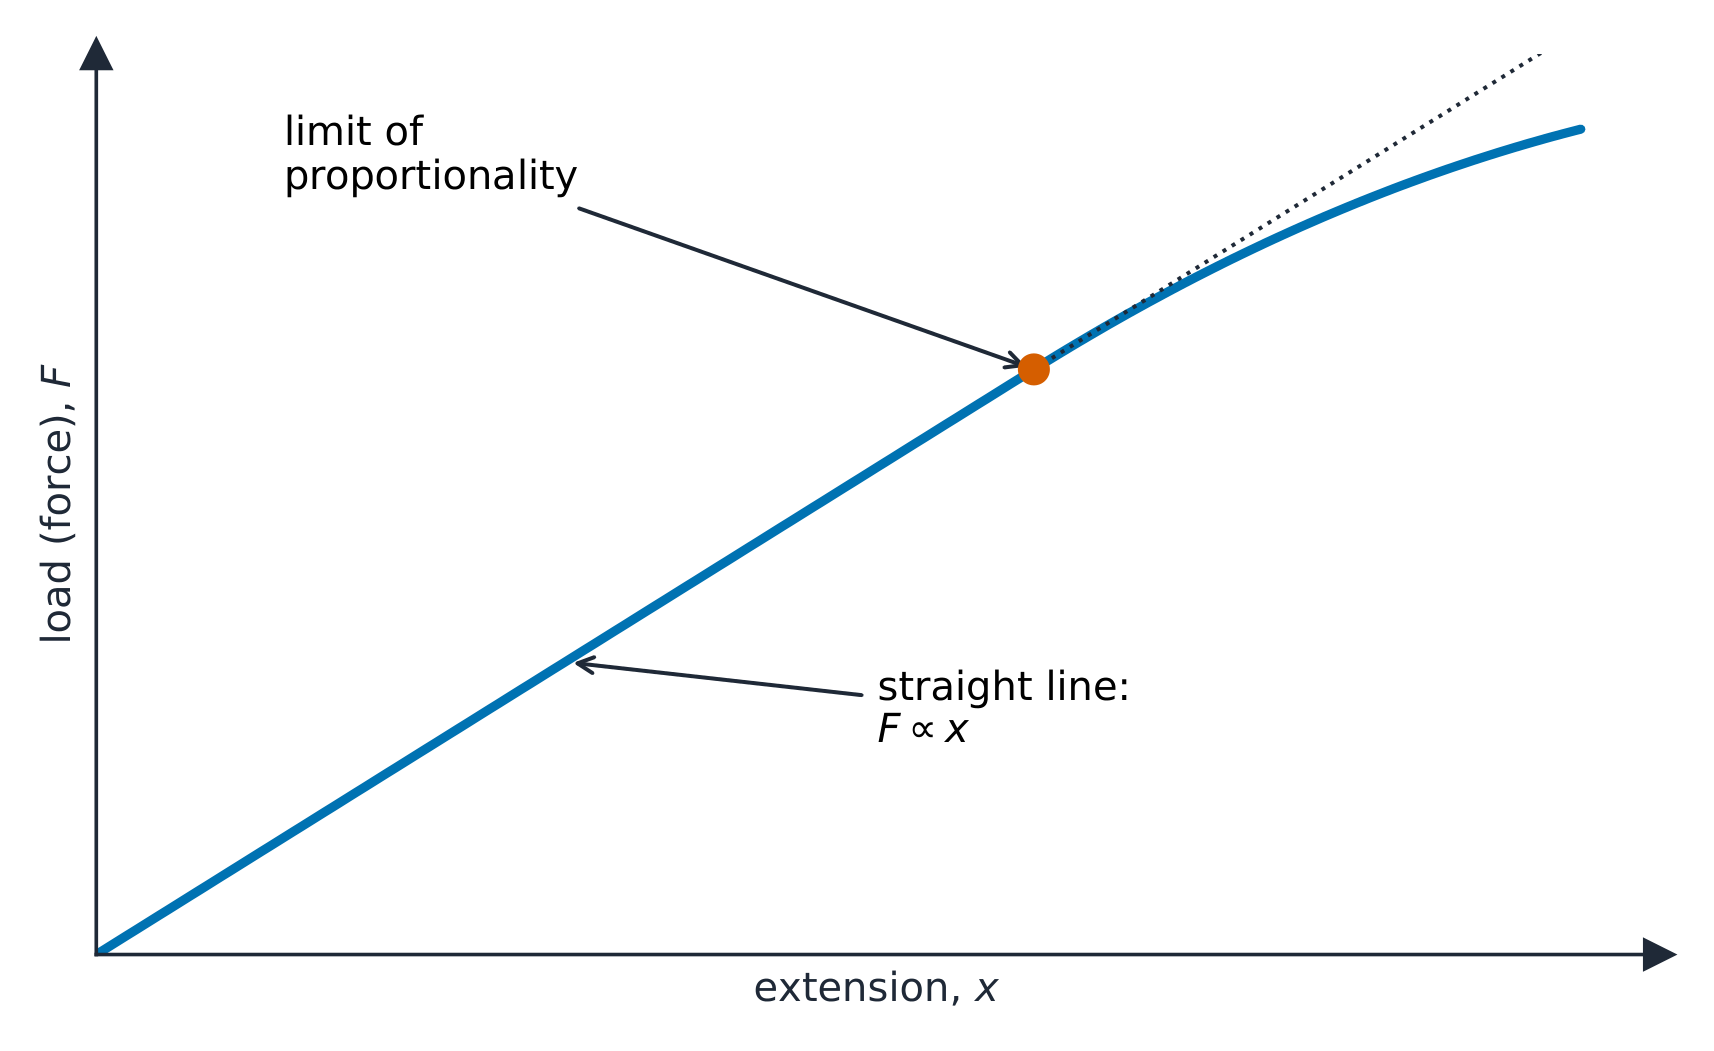
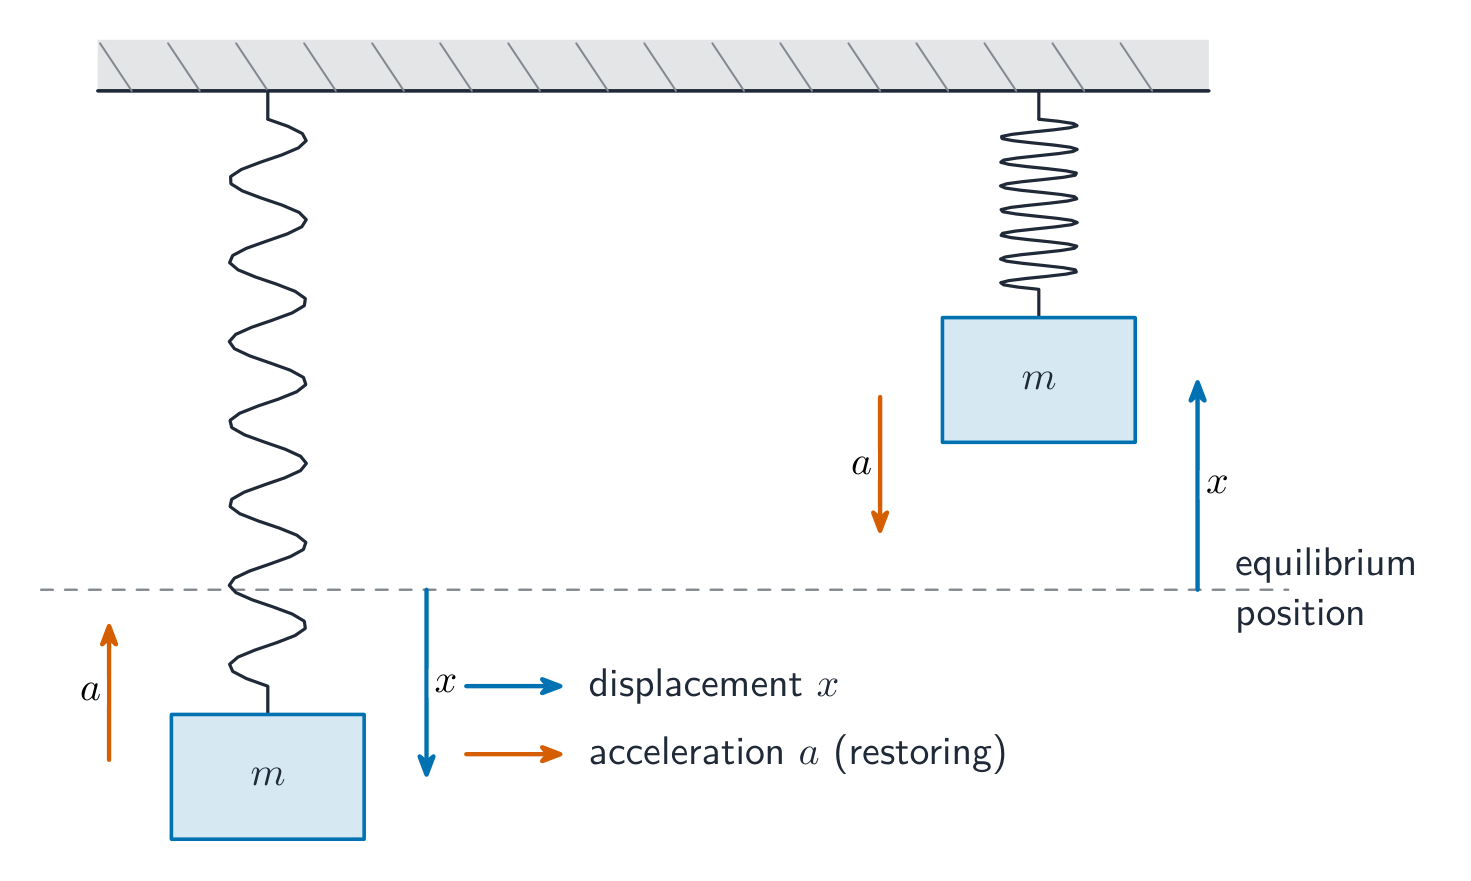
    An ideal spring obeys Hooke's law 胡克定律 $F_s=-kx$, a restoring force set by the spring constant 弹簧劲度系数 $k$. Its stored energy is $U=\tfrac12 kx^2$.

    Hooke's law: extension is proportional to load up to the limit of proportionality
    Hooke's law: extension is proportional to load up to the limit of proportionality

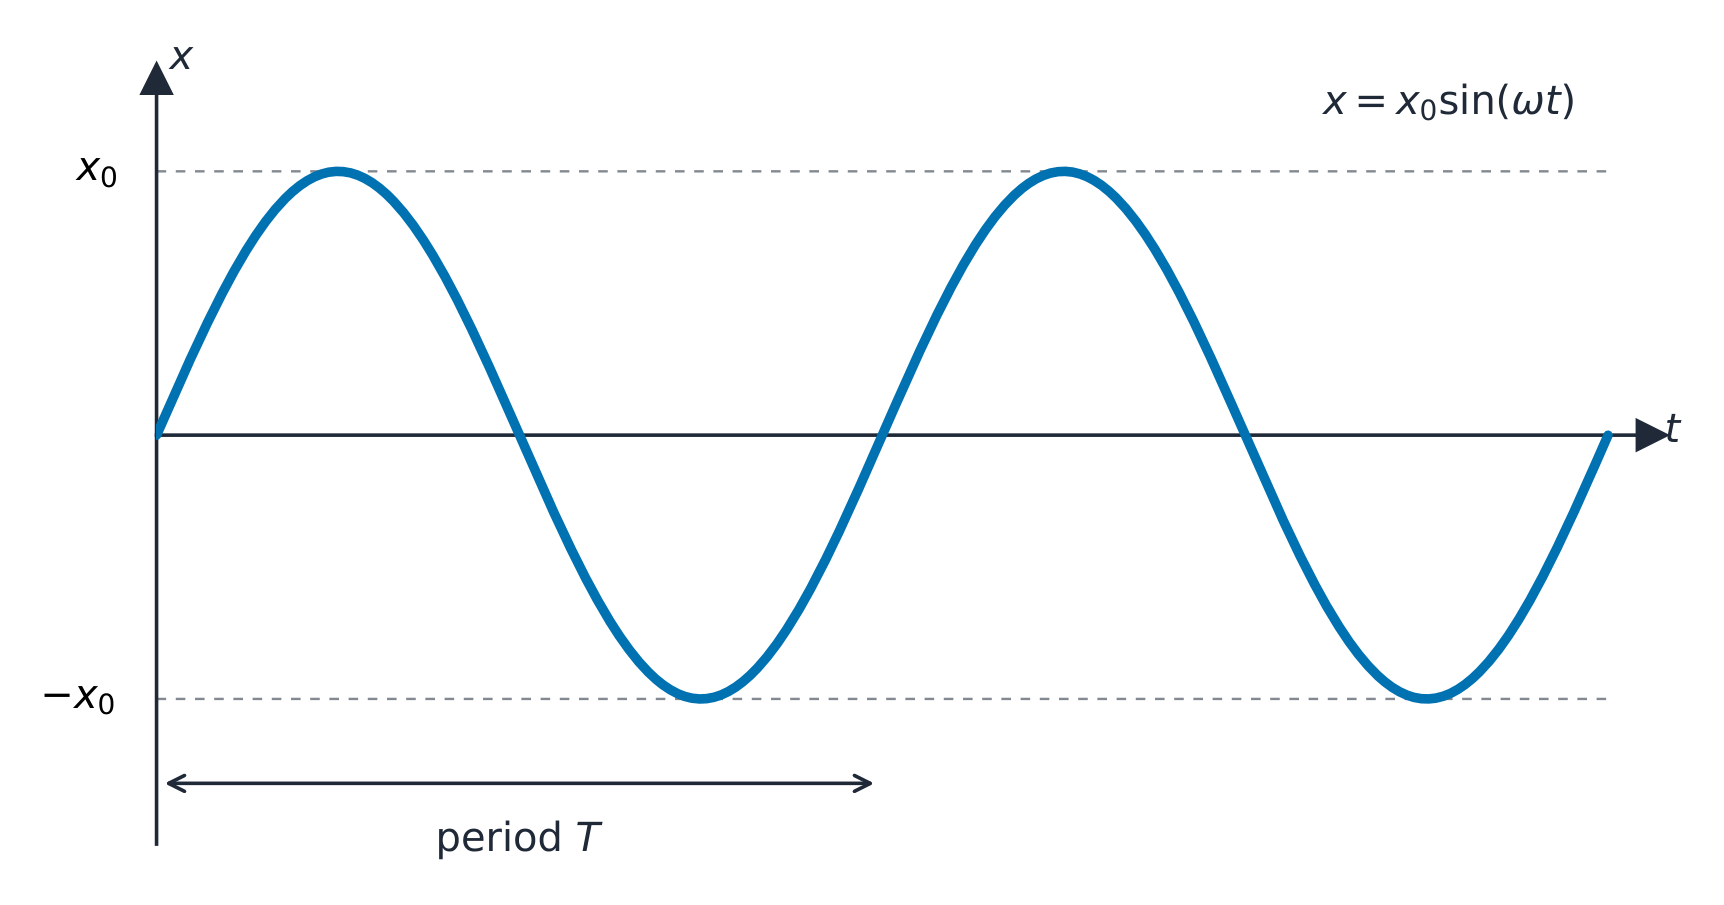
    Combined springs act as one equivalent spring of constant $k_{\text{eq}}$. In parallel (side by side, sharing the load) the constants add, $k_{\text{eq}}=k_1+k_2$ – stiffer than either. In series (end to end) they combine as $\dfrac{1}{k_{\text{eq}}}=\dfrac{1}{k_1}+\dfrac{1}{k_2}$ – softer than the softest one. Two springs pulling a mass from opposite sides also act in parallel, giving a restoring constant $k_1+k_2$. Whichever you have, the SHM period uses $k_{\text{eq}}$: $T=2\pi\sqrt{m/k_{\text{eq}}}$.

    Explore · ⁨Khám phá⁩

    Stretch a spring (Hooke's law)

    A spring's force is proportional to its extension, $F=kx$ (Hooke's law). Pull harder and the extension grows in step — until the spring's limit.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Hooke's law/hʊks lɔː/ định luật Hooke
    spring constant/sprɪŋ ˈkɒnstənt/ hằng số lò xo
    2.9

    Resistive Forces

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.9.A: Describe the motion of an object subject to a resistive force.

    • 2.9.A.1 A resistive force is defined as a velocity-dependent force in the opposite direction of an object's velocity, for example:
      • Equation: $\vec{F}_r = -k\vec{v}$
    • 2.9.A.2 Applying Newton's second law to an object upon which a resistive force is exerted results in a differential equation for velocity.
      • 2.9.A.2.i Using the method of separation of variables, the velocity can be determined by integrating over the proper limits of integration.
      • 2.9.A.2.ii The acceleration or position of a moving object that is subject to a velocity-dependent force may be determined using initial conditions of the object and methods of calculus, once a function for velocity is determined.
      • 2.9.A.2.iii The position, velocity, and acceleration as functions of time of an object under the influence of a resistive force of the form $\vec{F}_r = -k\vec{v}$ are exponential and have asymptotes that are determined by the initial conditions of the object and the forces exerted on the object.
    • 2.9.A.3 Terminal velocity is defined as the maximum speed achieved by an object moving under the influence of a constant force and a resistive force that are exerted on the object in opposite directions. The terminal condition is reached when the net force exerted on the object is zero.
    Tiếng Việt

    Mục tiêu học tập 2.9.A: Mô tả chuyển động của một vật chịu tác dụng của lực cản.

    • 2.9.A.1 Lực cản được định nghĩa là lực phụ thuộc vận tốc theo hướng ngược lại với vận tốc của vật, ví dụ:
      • Phương trình: $\vec{F}_r = -k\vec{v}$
    • 2.9.A.2 Áp dụng định luật II Newton cho một vật chịu tác dụng của lực cản dẫn đến phương trình vi phân cho vận tốc.
      • 2.9.A.2.i Sử dụng phương pháp tách biến, vận tốc có thể được xác định bằng cách tích phân với các cận thích hợp.
      • 2.9.A.2.ii Gia tốc hoặc vị trí của một vật chuyển động chịu tác dụng của lực phụ thuộc vào vận tốc có thể được xác định bằng điều kiện ban đầu của vật và các phương pháp giải tích, sau khi đã xác định được hàm vận tốc.
      • 2.9.A.2.iii Vị trí, vận tốc và gia tốc theo thời gian của một vật chịu tác dụng của lực cản có dạng $\vec{F}_r = -k\vec{v}$ là các hàm mũ và có tiệm cận được xác định bởi điều kiện ban đầu của vật và các lực tác dụng lên vật.
    • 2.9.A.3 Vận tốc giới hạn (vận tốc cuối) được định nghĩa là vận tốc tối đa mà vật đạt được khi chuyển động dưới tác dụng của một lực không đổi và một lực cản tác dụng lên vật theo hai hướng ngược nhau. Điều kiện vận tốc giới hạn đạt được khi tổng lực tác dụng lên vật bằng không.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

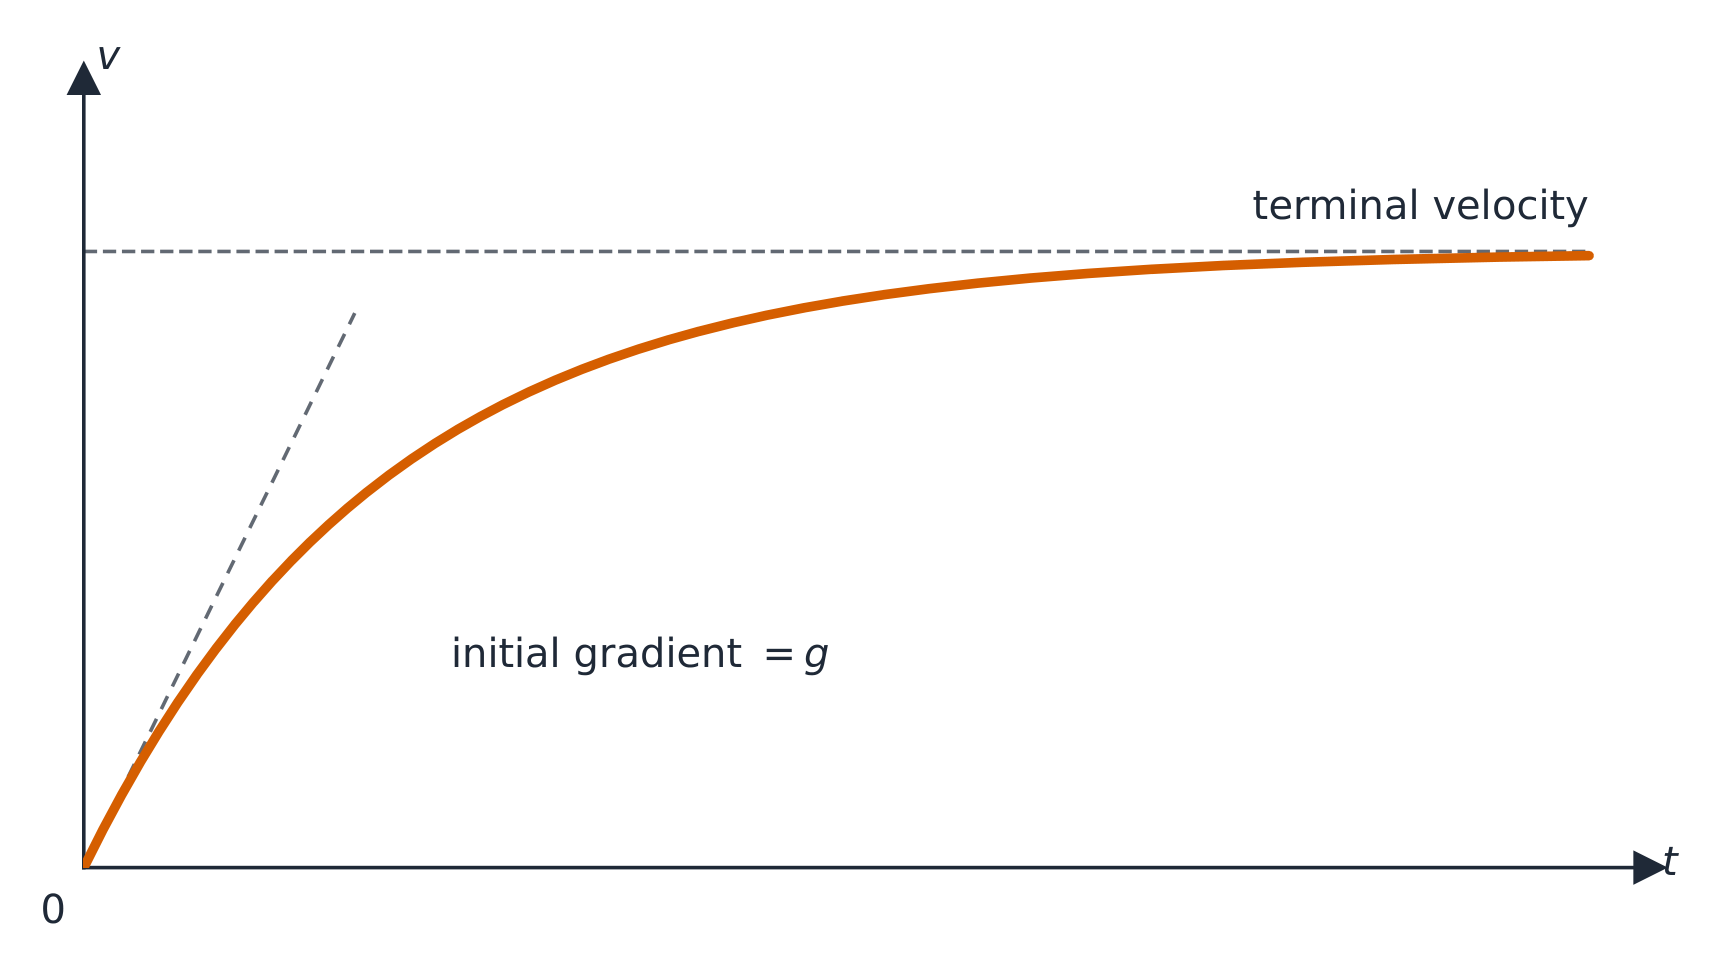
    A resistive force 阻力 (drag) opposes motion through a fluid and grows with speed, often modeled as $F=-bv$ or $F=-cv^2$. Newton's second law then gives a differential equation, e.g. $m\dfrac{dv}{dt}=mg-bv$ for a falling object. As speed rises, drag builds until it balances the driving force; the object then stops accelerating and moves at a constant terminal velocity 终极速度, found by setting the net force (and $dv/dt$) to zero.

    Worked example. For a falling object with $m\dfrac{dv}{dt}=mg-bv$, the terminal velocity is where $\dfrac{dv}{dt}=0$: $mg=bv_T$, so $v_T=\dfrac{mg}{b}$. With $m=0.10\ \text{kg}$ and $b=0.50\ \text{kg/s}$, $v_T=\dfrac{0.10(9.8)}{0.50}=2.0\ \text{m/s}$.

    To get the full motion $v(t)$, separate the variables 分离变量 and integrate from rest:

    $$\int_0^{v}\frac{dv'}{mg-bv'}=\int_0^{t}\frac{dt'}{m}\;\Rightarrow\;-\frac{1}{b}\ln\!\frac{mg-bv}{mg}=\frac{t}{m},$$
    which rearranges to $v(t)=v_T\left(1-e^{-bt/m}\right)$ – the speed rising exponentially toward $v_T$. Showing this integration is the calculus skill a Physics C free-response rewards, not just quoting the final formula.

    An object falling through a fluid speeds up to a terminal velocity
    An object falling through a fluid speeds up to a terminal velocity
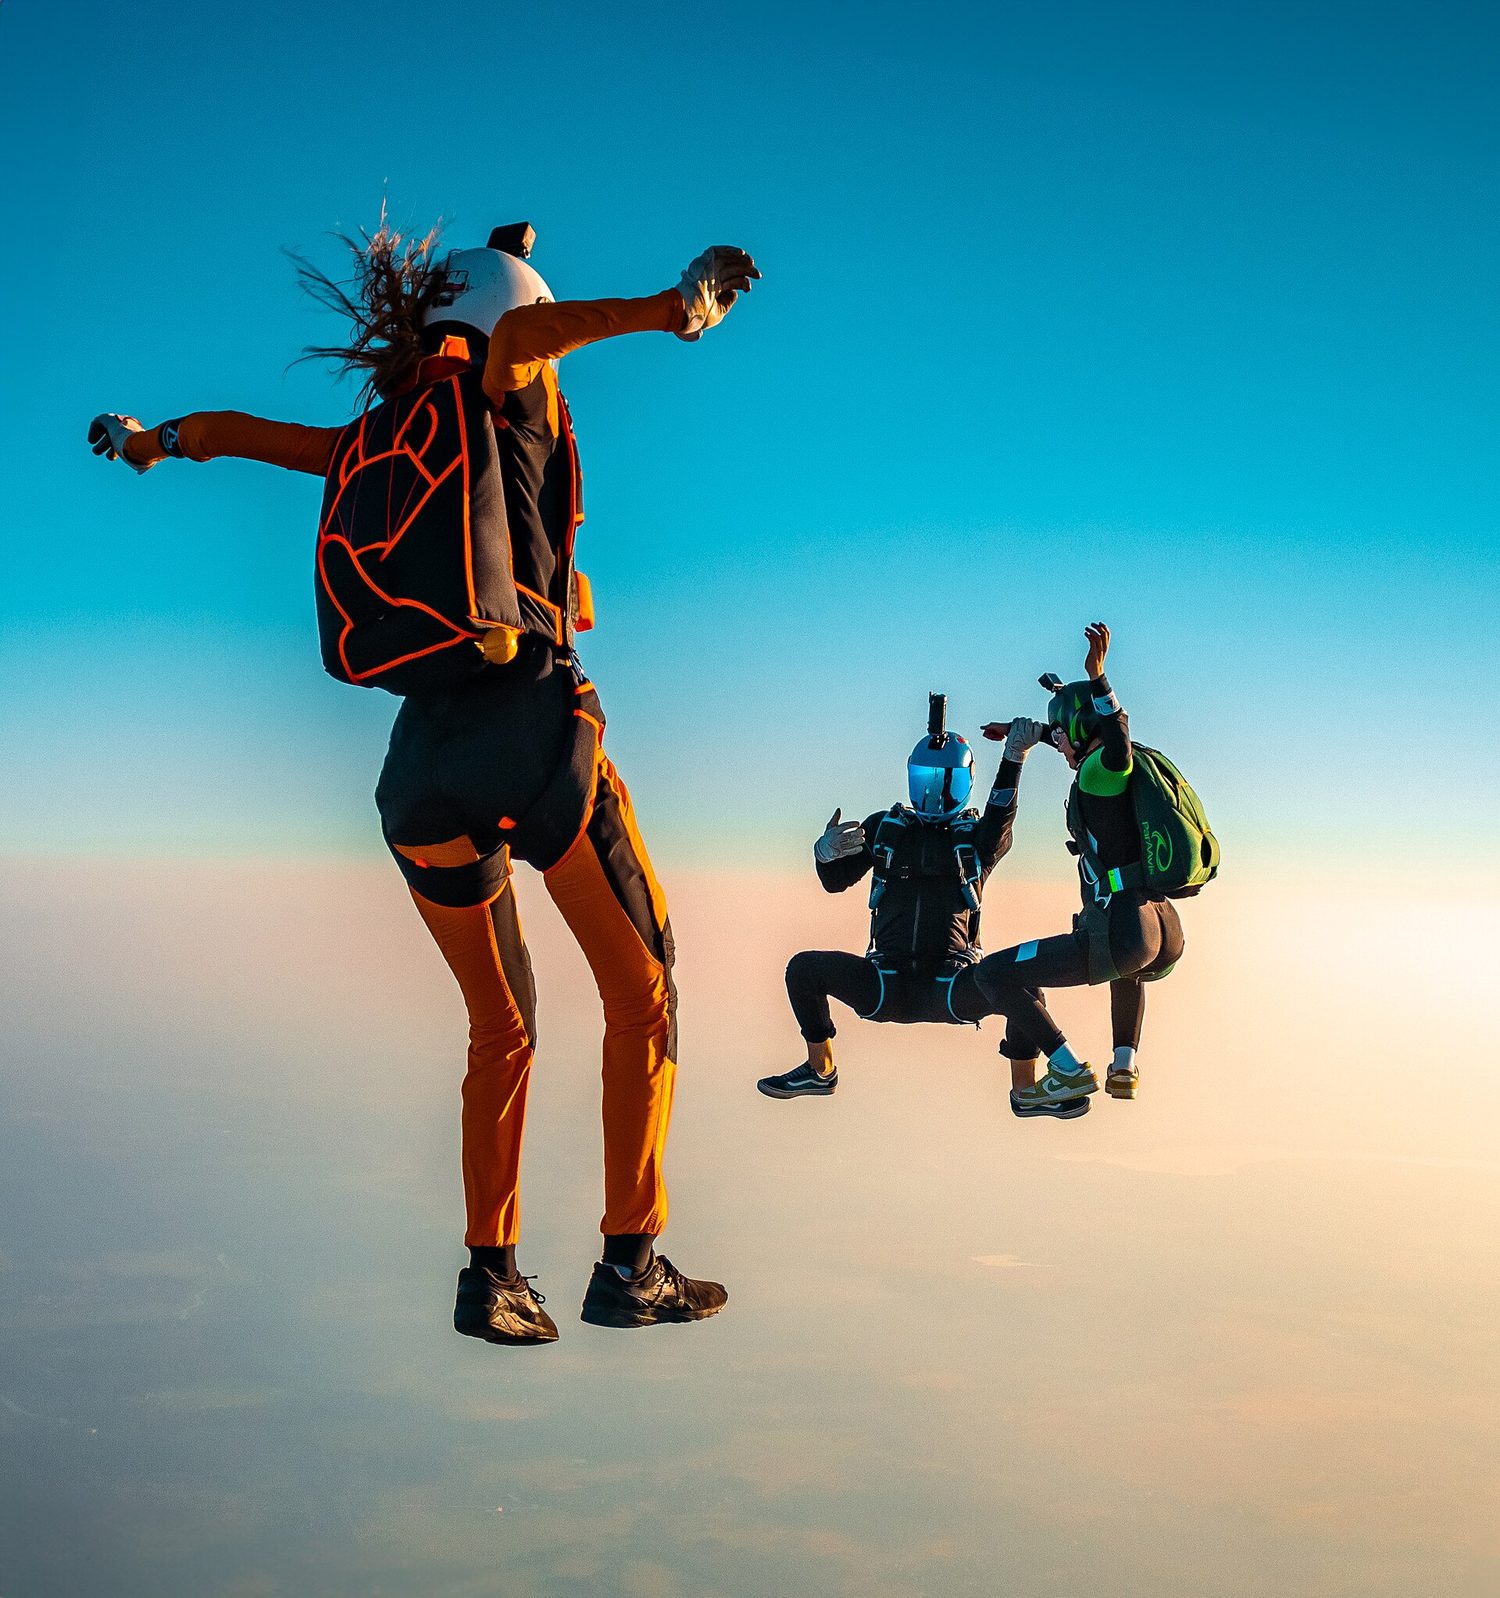
    Skydivers in freefall: drag grows with speed until it balances weight at terminal velocity
    Skydivers in freefall: drag grows with speed until it balances weight at terminal velocity
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    resistive force/rɪˈzɪstɪv fɔːs/ lực cản
    terminal velocity/ˈtɜːmɪnl vəˈlɒsɪti/ tốc độ cuối
    separate the variables/ˈseprət ðə ˈveərɪəblz/ Tách biến số
    2.10

    Circular Motion

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 2.10.A: Describe the motion of an object traveling in a circular path.

    • 2.10.A.1 Centripetal acceleration is the component of an object's acceleration directed toward the center of the object's circular path.
      • 2.10.A.1.i The magnitude of centripetal acceleration for an object moving in a circular path is the ratio of the object's tangential speed squared to the radius of the circular path.
        • Equation: $a_c = \dfrac{v^2}{r}$
      • 2.10.A.1.ii Centripetal acceleration is directed toward the center of an object's circular path.
    • 2.10.A.2 Centripetal acceleration can result from a single force, more than one force, or components of forces that are exerted on an object in circular motion.
      • 2.10.A.2.i At the top of a vertical, circular loop, an object requires a minimum speed to maintain circular motion. At this point, and with this minimum velocity, the gravitational force is the only force that causes the centripetal acceleration.
        • Derived equation: $v = \sqrt{gr}$
      • 2.10.A.2.ii Components of the static friction force and the normal force can contribute to the net force producing centripetal acceleration of an object traveling in a circle on a banked surface.
      • 2.10.A.2.iii A component of tension contributes to the net force producing centripetal acceleration experienced by a conical pendulum.
    • 2.10.A.3 Tangential acceleration is the rate at which an object's speed changes and is directed tangent to the object's circular path.
    • 2.10.A.4 The net acceleration of an object moving in a circle is the vector sum of the centripetal acceleration and tangential acceleration.
    • 2.10.A.5 The revolution of an object traveling in a circular path at a constant speed (uniform circular motion) can be described using period and frequency.
      • 2.10.A.5.i The time to complete one full circular path, one full rotation, or a full cycle of oscillatory motion is defined as period, $T$.
      • 2.10.A.5.ii The rate at which an object is completing revolutions is defined as frequency, $f$.
        • Equation: $T = \dfrac{1}{f}$
      • 2.10.A.5.iii For an object traveling at a constant speed in a circular path, the period is given by the derived equation
        • Derived equation: $T = \dfrac{2\pi r}{v}$

    Learning Objective 2.10.B: Describe circular orbits using Kepler's third law.

    • 2.10.B.1 For a satellite in circular orbit around a central body, the satellite's centripetal acceleration is caused only by gravitational attraction. The period and radius of the circular orbit are related to the mass of the central body.
      • Derived equation: $T^2 = \dfrac{4\pi^2}{GM} R^3$

    Boundary statement: AP Physics C: Mechanics does not expect students to know Kepler's first or second laws of planetary motion.

    Tiếng Việt

    Mục tiêu Học tập 2.10.A: Mô tả chuyển động của vật di chuyển theo quỹ đạo tròn.

    • 2.10.A.1 Gia tốc hướng tâm là thành phần gia tốc của vật có hướng về phía tâm của quỹ đạo tròn của vật.
      • 2.10.A.1.i Độ lớn gia tốc hướng tâm của vật chuyển động theo quỹ đạo tròn bằng tỷ số giữa bình phương vận tốc tiếp tuyến của vật với bán kính quỹ đạo tròn.
        • Phương trình: $a_c = \dfrac{v^2}{r}$
      • 2.10.A.1.ii Gia tốc hướng tâm có hướng về phía tâm của quỹ đạo tròn của vật.
    • 2.10.A.2 Gia tốc hướng tâm có thể xuất phát từ một lực đơn lẻ, nhiều hơn một lực, hoặc các thành phần của các lực tác dụng lên vật đang chuyển động tròn.
      • 2.10.A.2.i Tại đỉnh vòng tròn đứng, vật cần vận tốc tối thiểu để duy trì chuyển động tròn. Tại điểm này, và với vận tốc tối thiểu này, lực hấp dẫn là lực duy nhất gây ra gia tốc hướng tâm.
        • Phương trình suy ra: $v = \sqrt{gr}$
      • 2.10.A.2.ii Các thành phần của lực ma sát tĩnh và lực pháp tuyến có thể đóng góp vào lực hợp tạo ra gia tốc hướng tâm của vật di chuyển trên bề mặt dốc.
      • 2.10.A.2.iii Một thành phần của lực căng dây đóng góp vào lực hợp tạo ra gia tốc hướng tâm mà con lắc hình nón trải qua.
    • 2.10.A.3 Gia tốc tiếp tuyến là tốc độ thay đổi vận tốc của vật và có hướng tiếp tuyến với quỹ đạo tròn của vật.
    • 2.10.A.4 Gia tốc hợp của vật chuyển động theo đường tròn là tổng vectơ của gia tốc hướng tâm và gia tốc tiếp tuyến.
    • 2.10.A.5 Sự quay của vật di chuyển theo quỹ đạo tròn với vận tốc không đổi (chuyển động tròn đều) có thể được mô tả bằng chu kỳ và tần số.
      • 2.10.A.5.i Thời gian để hoàn thành một vòng tròn đầy đủ, một vòng quay đầy đủ, hoặc một chu kỳ dao động đầy đủ được định nghĩa là chu kỳ, $T$.
      • 2.10.A.5.ii Tốc độ mà vật hoàn thành các vòng quay được định nghĩa là tần số, $f$.
        • Phương trình: $T = \dfrac{1}{f}$
      • 2.10.A.5.iii Đối với vật di chuyển với vận tốc không đổi theo quỹ đạo tròn, chu kỳ được cho bởi phương trình suy ra
        • Phương trình suy ra: $T = \dfrac{2\pi r}{v}$

    Mục tiêu Học tập 2.10.B: Mô tả quỹ đạo tròn bằng định luật Kepler thứ ba.

    • 2.10.B.1 Đối với vệ tinh trong quỹ đạo tròn quanh một thiên thể trung tâm, gia tốc hướng tâm của vệ tinh chỉ do lực hút hấp dẫn gây ra. Chu kỳ và bán kính quỹ đạo tròn liên hệ với khối lượng của thiên thể trung tâm.
      • Phương trình suy ra: $T^2 = \dfrac{4\pi^2}{GM} R^3$

    Tuyên bố giới hạn: AP Physics C: Cơ học không yêu cầu học sinh phải biết định luật Kepler thứ nhất hay thứ hai về chuyển động hành tinh.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Uniform circular motion

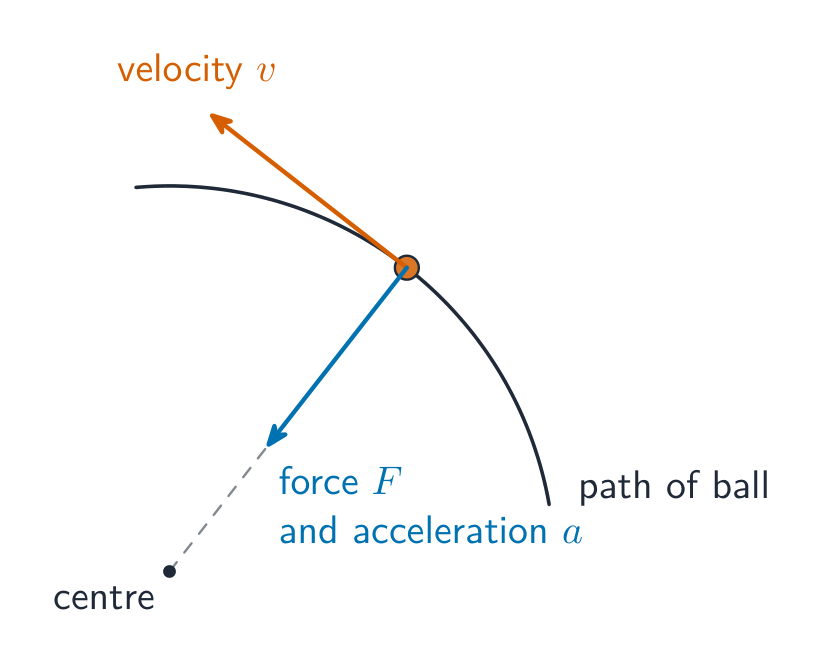
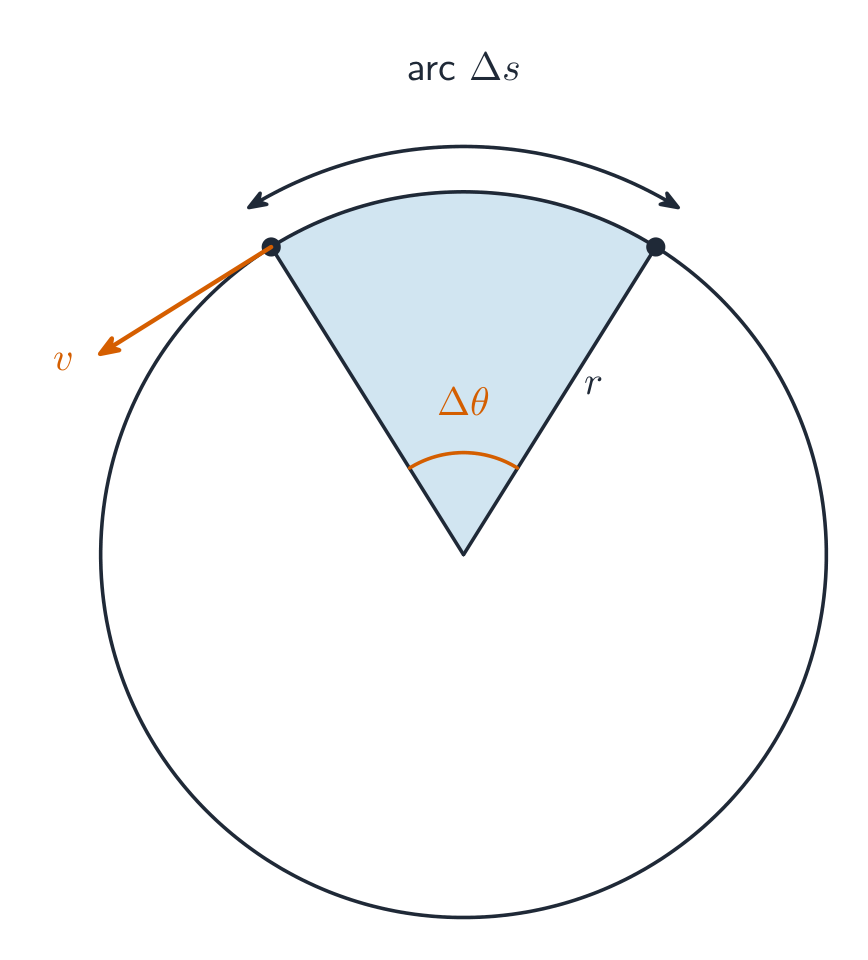
    Uniform circular motion has a centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}$ pointing to the center, requiring a net inward force $F_c=\dfrac{mv^2}{r}$ supplied by a real force (tension, gravity, friction, normal). There is no outward force. For vertical circles and banked curves, decompose the real forces to find which provides the centripetal requirement.

    Worked example. A $0.50\ \text{kg}$ ball is whirled on a $1.0\ \text{m}$ string in a horizontal circle at $3.0\ \text{m/s}$. The string tension supplies the whole centripetal force: $T=\dfrac{mv^2}{r}=\dfrac{0.50(3.0)^2}{1.0}=4.5\ \text{N}$.

    Worked example (vertical circle). At the top of a vertical loop of radius $r$, gravity and the normal force both point toward the center: $N+mg=\dfrac{mv^2}{r}$. The slowest possible speed at the top is where the track pushes with nothing at all ($N=0$): $v_{\min}=\sqrt{gr}$. For $r=2.5\ \text{m}$: $v_{\min}=\sqrt{9.8(2.5)}=4.9\ \text{m/s}$. Any slower and the cart leaves the track before the top.

    The velocity points along the tangent; the centripetal force points to the centre
    The velocity points along the tangent; the centripetal force points to the centre
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ gia tốc hướng tâm
    2.10

    Exam tips

    • Locate the center of mass with $x_{cm}=\tfrac{1}{M}\int x\,dm$ (or $\tfrac{\sum m_i x_i}{\sum m_i}$ for point masses) and use $\lambda,\sigma,\rho$ for the mass element.
    • The net external force moves the center of mass as if all mass sat there: $\vec F_{net}=M\vec a_{cm}$.
    • Define your system clearly — internal forces cancel, so only external forces change its momentum.
    • Exploit symmetry to shortcut a center-of-mass integral.
    • Distinguish center of mass from center of gravity (identical in a uniform field).
  • 3

    Work, Energy, and Power · ⁨Công, năng lượng và công suất⁩

    Watch lesson · ⁨Xem bài học⁩
    3.1

    Translational Kinetic Energy

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 3.1.A: Describe the translational kinetic energy of an object in terms of the object's mass and velocity.

    • 3.1.A.1 An object's translational kinetic energy is given by the equation
      • Equation: $K = \dfrac{1}{2}mv^2$
    • 3.1.A.2 Translational kinetic energy is a scalar quantity.
    • 3.1.A.3 Different observers may measure different values of the translational kinetic energy of an object, depending on the observer's frame of reference.
    Tiếng Việt

    Mục tiêu học tập 3.1.A: Mô tả động năng tịnh tiến của một vật dựa trên khối lượng và vận tốc của vật đó.

    • 3.1.A.1 Động năng tịnh tiến của một vật được cho bởi phương trình
      • Phương trình: $K = \dfrac{1}{2}mv^2$
    • 3.1.A.2 Động năng tịnh tiến là đại lượng vô hướng.
    • 3.1.A.3 Các quan sát viên khác nhau có thể đo được các giá trị khác nhau của động năng tịnh tiến của một vật, tùy thuộc vào hệ quy chiếu của họ.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Kinetic energy 动能 is the energy of motion, a scalar 标量 measured in joules 焦耳 (J):

    $$K=\tfrac{1}{2}mv^2.$$

    It grows with the square of speed – doubling the speed quadruples $K$. One subtlety worth knowing: kinetic energy depends on the observer's reference frame 参考系. A passenger walking down a train has a small $K$ measured inside the train and a huge one measured from the ground – both observers are right, each in their own frame.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Kinetic energy/kɪˈnetɪk ˈenədʒi/ Động năng
    scalar/ˈskeɪlə/ vô hướng
    joules/dʒuːlz/ joules
    reference frame/ˈrefrəns freɪm/ hệ quy chiếu
    3.2

    Work

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 3.2.A: Describe the work done on an object or system by a given force or collection of forces.

    • 3.2.A.1 Work is the amount of energy transferred into or out of a system by a force exerted on that system over a distance.
      • 3.2.A.1.i The work done by a conservative force exerted on a system is path-independent and only depends on the initial and final configurations of that system.
      • 3.2.A.1.ii The work done by a conservative force on a system—or the change in the potential energy of the system—will be zero if the system returns to its initial configuration.
      • 3.2.A.1.iii Potential energies are associated only with conservative forces.
      • 3.2.A.1.iv The work done by a nonconservative force is path-dependent.
      • 3.2.A.1.v The most common nonconservative forces are friction and air resistance.
    • 3.2.A.2 Work is a scalar quantity that may be positive, negative, or zero.
    • 3.2.A.3 The work done on an object by a variable force is calculated using
      • Equation: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$, where the integral is taken over the path from point $a$ to point $b$.
      • 3.2.A.3.i The dot product between two vectors, $\vec{A}$ and $\vec{B}$, results in a scalar quantity of magnitude $\vec{A} \cdot \vec{B} = AB\cos\theta$.
      • 3.2.A.3.ii Only the component of the force exerted on a system that is parallel to the displacement of the point of application of the force will change the system's total energy.
      • 3.2.A.3.iii If the component of the force exerted on a system that is parallel to the displacement is constant, the work done on the system by the force is given by the derived equation $W = F_{\parallel}d = Fd\cos\theta$.
      • 3.2.A.3.iv The component of the force exerted on a system perpendicular to the direction of the displacement of the system's center of mass can change the direction of the system's motion without changing the system's kinetic energy.
    • 3.2.A.4 The work–energy theorem states that the change in an object's kinetic energy is equal to the sum of the work (net work) being done by all forces exerted on the object.
      • Equation: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
      • 3.2.A.4.i An external force may change the configuration of a system. The component of the external force parallel to the displacement times the displacement of the point of application of the force gives the change in kinetic energy of the system.
      • 3.2.A.4.ii If the system's center of mass and the point of application of the force move the same distance when a force is exerted on a system, then the system may be modeled as an object, and only the system's kinetic energy can change.
      • 3.2.A.4.iii The energy dissipated by friction is typically equated to the force of friction times the length of the path over which the force is exerted.
        • Equation: $\Delta E_{\text{mech}} = F_f d\cos\theta$
      • 3.2.A.5 Work is equal to the area under the curve of a graph of $F_{\parallel}$ as a function of displacement.

    Boundary statement: AP Physics C: Mechanics only expects students to analyze the transfer of mechanical energy, although students should be aware that mechanical energy may be dissipated in the form of thermal energy or sound.

    Tiếng Việt

    Mục tiêu học tập 3.2.A: Mô tả công thực hiện lên một vật hoặc hệ thống bởi một lực đã cho hoặc một tập hợp các lực.

    • 3.2.A.1 Công là lượng năng lượng được truyền vào hoặc ra khỏi một hệ thống bởi một lực tác dụng lên hệ thống đó trong một khoảng cách.
      • 3.2.A.1.i Công do một lực bảo toàn tác dụng lên một hệ thống không phụ thuộc vào đường đi và chỉ phụ thuộc vào trạng thái ban đầu và cuối cùng của hệ thống đó.
      • 3.2.A.1.ii Công do một lực bảo toàn tác dụng lên một hệ thống—hoặc sự thay đổi thế năng của hệ thống—sẽ bằng không nếu hệ thống trở lại trạng thái ban đầu của nó.
      • 3.2.A.1.iii Thế năng chỉ liên quan đến các lực bảo toàn.
      • 3.2.A.1.iv Công do một lực phi bảo toàn phụ thuộc vào đường đi.
      • 3.2.A.1.v Các lực phi bảo toàn phổ biến nhất là ma sát và lực cản không khí.
    • 3.2.A.2 Công là đại lượng vô hướng có thể mang giá trị dương, âm hoặc bằng không.
    • 3.2.A.3 Công thực hiện lên một vật bởi một lực biến thiên được tính bằng
      • Phương trình: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$, trong đó tích phân lấy trên đường đi từ điểm $a$ đến điểm $b$.
      • 3.2.A.3.i Tích vô hướng giữa hai vector, $\vec{A}$ và $\vec{B}$, kết quả là một đại lượng vô hướng có độ lớn là $\vec{A} \cdot \vec{B} = AB\cos\theta$.
      • 3.2.A.3.ii Chỉ thành phần của lực tác dụng lên hệ song song với độ dịch chuyển của điểm đặt lực mới làm thay đổi tổng năng lượng của hệ.
      • 3.2.A.3.iii Nếu thành phần của lực tác dụng lên hệ song song với độ dịch chuyển là hằng số, công thực hiện lên hệ bởi lực này được cho bởi phương trình suy ra $W = F_{\parallel}d = Fd\cos\theta$.
      • 3.2.A.3.iv Thành phần của lực tác dụng lên hệ vuông góc với phương độ dịch chuyển của trọng tâm hệ có thể làm thay đổi hướng chuyển động của hệ mà không làm thay đổi động năng của hệ.
    • 3.2.A.4 Định lý động năng phát biểu rằng độ biến thiên động năng của một vật bằng tổng công (công ròng) do tất cả các lực tác dụng lên vật thực hiện.
      • Phương trình: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
      • 3.2.A.4.i Một lực bên ngoài có thể làm thay đổi cấu hình của một hệ thống. Thành phần của lực bên ngoài song song với độ dịch chuyển nhân với độ dịch chuyển của điểm đặt lực sẽ cho sự thay đổi động năng của hệ thống.
      • 3.2.A.4.ii Nếu trọng tâm của hệ thống và điểm đặt lực di chuyển cùng một khoảng cách khi một lực tác dụng lên hệ thống, thì hệ thống có thể được mô hình hóa như một vật, và chỉ có động năng của hệ thống mới có thể thay đổi.
      • 3.2.A.4.iii Năng lượng tiêu tán do ma sát thường được quy về tích của lực ma sát và chiều dài quỹ đạo mà lực đó tác dụng.
        • Phương trình: $\Delta E_{\text{mech}} = F_f d\cos\theta$
      • 3.2.A.5 Công bằng diện tích nằm dưới đường cong của đồ thị $F_{\parallel}$ theo độ dịch chuyển.

    Phát biểu biên: AP Physics C: Cơ học chỉ yêu cầu học sinh phân tích sự truyền tải cơ năng, mặc dù học sinh nên biết rằng cơ năng có thể bị tiêu tán dưới dạng nhiệt năng hoặc âm thanh.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Work 功 is energy transferred into or out of a system by a force acting over a distance. For a variable force it is an integral 积分 along the path:

    $$W=\int_a^b \vec{F}\cdot d\vec{r}=\int F\cos\theta\,dr.$$

    For a constant force this reduces to $W=Fd\cos\theta$; on a force–position graph, work is the area under the curve. Work is a scalar with a sign, and the sign is physics, not bookkeeping:

    • Positive – force has a component along the motion (it speeds the object up).
    • Negative – force opposes the motion (friction 摩擦力 and air drag do negative work).
    • Zero – force perpendicular to the motion (the normal force 法向力 on a sliding block, gravity on a horizontal move, tension in a circular swing).
    Only the force component along the displacement does work
    Only the force component along the displacement does work

    The work–energy theorem 动能定理 collects every force's contribution: the net work equals the change in kinetic energy,

    $$W_{\text{net}}=\sum W_i=\Delta K.$$

    Worked example. A variable force $F(x)=3x^2\ \text{N}$ (along the motion) acts from $x=0$ to $x=2\ \text{m}$: $W=\displaystyle\int_0^2 3x^2\,dx=\big[x^3\big]_0^2=8\ \text{J}$. Acting alone on a body starting from rest, it would raise the kinetic energy to exactly $8\ \text{J}$.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Work/wɜːk/ Công
    integral/ˈɪntɪɡrəl/ tích phân
    friction/ˈfrɪkʃn/ lực ma sát
    normal force/ˈnɔːml fɔːs/ lực pháp tuyến
    work–energy theorem/wɜːk ˈenədʒi ˈθɪərəm/ Định lý công – năng lượng
    3.3

    Potential Energy

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 3.3.A: Describe the potential energy of a system.

    • 3.3.A.1 A system composed of two or more objects has potential energy if the objects within that system only interact with each other through conservative forces.
    • 3.3.A.2 Potential energy is a scalar quantity associated with the position of objects within a system.
    • 3.3.A.3 The definition of zero potential energy for a given system is a decision made by the observer considering the situation to simplify or otherwise assist in analysis.
    • 3.3.A.4 The relationship between conservative forces exerted on a system and the system's potential energy is
      • Equation: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
    • 3.3.A.5 The conservative forces exerted on a system in a single dimension can be determined using the slope of the system's potential energy with respect to position in that dimension; these forces point in the direction of decreasing potential energy.
      • Equation: $F_x = -\dfrac{dU(x)}{dx}$
    • 3.3.A.6 Graphs of a system's potential energy as a function of its position can be useful in determining physical properties of that system.
      • 3.3.A.6.i Stable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object opposite to the direction of the small displacement, accelerating the object back toward the equilibrium position.
      • 3.3.A.6.ii Unstable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object in the same direction as the small displacement, accelerating the object away from the equilibrium position.
      • 3.3.A.6.iii In a given dimension, stable equilibrium positions exist at locations where the potential energy as a function of position in that dimension has a local minimum.
      • 3.3.A.6.iv In a given dimension, unstable equilibrium positions occur at locations where the potential energy as a function of position in that dimension has a local maximum.
    • 3.3.A.7 The potential energy of common physical systems can be described using the physical properties of that system.
      • 3.3.A.7.i The elastic potential energy of an ideal spring is given by the following equation, where $\Delta x$ is the distance the spring has been stretched or compressed from its equilibrium length.
        • Equation: $U_s = \dfrac{1}{2}k(\Delta x)^2$
      • 3.3.A.7.ii The general form for the gravitational potential energy of a system consisting of two approximately spherical distributions of mass (e.g., moons, planets, or stars) is given by the equation
        • Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
      • 3.3.A.7.iii Because the gravitational field near the surface of a planet is nearly constant, the change in gravitational potential energy in a system consisting of an object with mass $m$ and a planet with gravitational field of magnitude $g$ when the object is near the surface of the planet may be approximated by the equation
        • Equation: $\Delta U_g = mg\Delta y$
    • 3.3.A.8 The total potential energy of a system containing more than two objects is the sum of the potential energy of each pair of objects within the system.
    Tiếng Việt

    Mục tiêu học tập 3.3.A: Mô tả thế năng của một hệ thống.

    • 3.3.A.1 Một hệ thống gồm hai hoặc nhiều vật có thế năng nếu các vật trong hệ thống đó chỉ tương tác với nhau thông qua các lực bảo toàn.
    • 3.3.A.2 Thế năng là đại lượng vô hướng liên quan đến vị trí của các vật trong một hệ thống.
    • 3.3.A.3 Việc xác định mức thế năng bằng không cho một hệ thống nhất định là quyết định của người quan sát xem xét tình huống để đơn giản hóa hoặc hỗ trợ việc phân tích.
    • 3.3.A.4 Mối quan hệ giữa các lực bảo toàn tác dụng lên hệ và thế năng của hệ là
      • Phương trình: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
    • 3.3.A.5 Các lực bảo toàn tác dụng lên hệ trong một chiều có thể được xác định bằng độ dốc của thế năng hệ theo vị trí trong chiều đó; các lực này hướng về phía giảm thế năng.
      • Phương trình: $F_x = -\dfrac{dU(x)}{dx}$
    • 3.3.A.6 Đồ thị thế năng của hệ theo vị trí có thể hữu ích trong việc xác định các đặc tính vật lý của hệ.
      • 3.3.A.6.i Cân bằng bền là vị trí mà tại đó một độ dịch chuyển nhỏ của vật sẽ tạo ra lực tác dụng lên vật ngược với hướng của độ dịch chuyển nhỏ, đẩy vật trở lại vị trí cân bằng.
      • 3.3.A.6.ii Cân bằng không bền là vị trí mà tại đó một độ dịch chuyển nhỏ của vật sẽ tạo ra lực tác dụng lên vật cùng hướng với độ dịch chuyển nhỏ, đẩy vật rời khỏi vị trí cân bằng.
      • 3.3.A.6.iii Trong một chiều nhất định, các vị trí cân bằng bền tồn tại tại những nơi mà thế năng theo vị trí trong chiều đó có cực tiểu địa phương.
      • 3.3.A.6.iv Trong một chiều nhất định, các vị trí cân bằng không bền xảy ra tại những nơi mà thế năng theo vị trí trong chiều đó có cực đại địa phương.
    • 3.3.A.7 Thế năng của các hệ vật lý thông thường có thể được mô tả bằng các đặc tính vật lý của hệ đó.
      • 3.3.A.7.i Thế năng đàn hồi của lò xo lý tưởng được cho bởi phương trình sau, trong đó $\Delta x$ là khoảng cách lò xo bị kéo dãn hoặc nén so với chiều dài cân bằng.
        • Phương trình: $U_s = \dfrac{1}{2}k(\Delta x)^2$
      • 3.3.A.7.ii Dạng tổng quát của thế năng hấp dẫn cho một hệ gồm hai phân bố khối lượng xấp xỉ hình cầu (ví dụ: vệ tinh, hành tinh hoặc sao) được cho bởi phương trình
        • Phương trình: $U_g = -G\dfrac{m_1 m_2}{r}$
      • 3.3.A.7.iii Vì trường hấp dẫn gần bề mặt hành tinh gần như không đổi, độ biến thiên thế năng hấp dẫn trong hệ gồm một vật có khối lượng $m$ và một hành tinh có cường độ trường hấp dẫn $g$ khi vật ở gần bề mặt hành tinh có thể xấp xỉ bằng phương trình
        • Phương trình: $\Delta U_g = mg\Delta y$
    • 3.3.A.8 Thế năng tổng cộng của một hệ chứa hơn hai vật là tổng thế năng của mỗi cặp vật trong hệ.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Potential energy 势能 is energy a system stores by the positions of its parts – it exists only for conservative forces 保守力, whose work is path independent. It is defined through work:

    $$\Delta U=-\int_a^b\vec{F}\cdot d\vec{r},$$

    and you are free to choose where $U=0$ – only changes in $U$ matter, so pick the zero that makes the problem simplest. The standard results:

    • Gravity near a surface: $\Delta U_g=mg\,\Delta y$.
    • Gravity in general: $U_g=-\dfrac{Gm_1m_2}{r}$ (zero at infinite separation).
    • Spring: $U_s=\tfrac12k(\Delta x)^2$, with $\Delta x$ measured from natural length.

    For systems of several objects, add the potential energy of each pair. Turning the definition around, a conservative force is minus the derivative 导数 of its potential energy:

    $$F_x=-\frac{dU}{dx}.$$

    The force points "downhill" on the $U(x)$ curve. Equilibrium sits where the slope is zero: a minimum is a stable equilibrium 稳定平衡 (displaced, the force pushes back), a maximum is an unstable equilibrium 不稳定平衡 (displaced, the force pushes away).

    On a potential-energy curve the force points downhill and E = U marks the turning points
    On a potential-energy curve the force points downhill and E = U marks the turning points

    Worked example. Given $U(x)=2x^3-6x$ (joules), the force is $F=-\dfrac{dU}{dx}=6-6x^2$. Equilibria sit at $F=0$: $x=\pm1$. Since $\dfrac{d^2U}{dx^2}=12x$ is positive at $x=+1$ (a minimum – stable) and negative at $x=-1$ (a maximum – unstable), the two points behave oppositely.

    Explore · ⁨Khám phá⁩

    Store elastic potential energy in a spring

    Stretching a spring stores elastic potential energy $\tfrac12 kx^2$ — the area under the force-extension line. Release it and that energy becomes kinetic. · ⁨Kéo dài lò xo sẽ tích trữ thế năng đàn hồi $\tfrac12 kx^2$ — diện tích dưới đường cong lực - độ dãn. Thả ra thì năng lượng đó chuyển thành động năng.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Potential energy/pəˈtenʃl ˈenədʒi/ Thế năng
    conservative forces/kənˈsɜːvətɪv ˈfɔːsɪz/ Lực bảo toàn
    derivative/dɪˈrɪvətɪv/ đạo hàm
    stable equilibrium/ˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ cân bằng ổn định
    unstable equilibrium/ʌnˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ cân bằng không ổn định
    3.4

    Conservation of Energy

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 3.4.A: Describe the energies present in a system.

    • 3.4.A.1 A system composed of only a single object can only have kinetic energy.
    • 3.4.A.2 A system that contains objects that interact via conservative forces or that can change its shape reversibly may have both kinetic and potential energies.

    Learning Objective 3.4.B: Describe the behavior of a system using conservation of mechanical energy principles.

    • 3.4.B.1 Mechanical energy is the sum of a system's kinetic and potential energies.
    • 3.4.B.2 Any change to a type of energy within a system must be balanced by an equivalent change of other types of energies within the system or by a transfer of energy between the system and its surroundings.
    • 3.4.B.3 A system may be selected so that the total energy of that system is constant.
    • 3.4.B.4 If the total energy of a system changes, that change will be equivalent to the energy transferred into or out of the system.

    Learning Objective 3.4.C: Describe how the selection of a system determines whether the energy of that system changes.

    • 3.4.C.1 Energy is conserved in all interactions.
    • 3.4.C.2 If the work done on a selected system is zero and there are no nonconservative interactions within the system, the total mechanical energy of the system is constant.
    • 3.4.C.3 If the work done on a selected system is nonzero, energy is transferred between the system and the environment.

    Boundary statement: AP Physics C: Mechanics expects students to know that mechanical energy can be dissipated as thermal energy or sound by nonconservative forces.

    Tiếng Việt

    Mục tiêu học tập 3.4.A: Mô tả các dạng năng lượng tồn tại trong một hệ thống.

    • 3.4.A.1 Một hệ thống chỉ bao gồm một vật duy nhất chỉ có thể có động năng.
    • 3.4.A.2 Một hệ thống chứa các vật tương tác thông qua lực bảo toàn hoặc có thể thay đổi hình dạng thuận nghịch có thể có cả động năng và thế năng.

    Mục tiêu học tập 3.4.B: Mô tả hành vi của một hệ thống sử dụng các nguyên tắc bảo toàn cơ năng.

    • 3.4.B.1 Cơ năng là tổng của động năng và thế năng của một hệ.
    • 3.4.B.2 Mọi sự thay đổi của một dạng năng lượng trong hệ phải được cân bằng bởi một sự thay đổi tương đương của các dạng năng lượng khác trong hệ hoặc do sự truyền năng lượng giữa hệ và môi trường xung quanh.
    • 3.4.B.3 Một hệ có thể được chọn sao cho tổng năng lượng của hệ đó không đổi.
    • 3.4.B.4 Nếu tổng năng lượng của một hệ thay đổi, thì sự thay đổi đó sẽ tương đương với năng lượng được truyền vào hoặc ra khỏi hệ.

    Mục tiêu học tập 3.4.C: Mô tả cách việc lựa chọn hệ xác định liệu năng lượng của hệ có thay đổi hay không.

    • 3.4.C.1 Năng lượng được bảo toàn trong mọi tương tác.
    • 3.4.C.2 Nếu công thực hiện lên một hệ đã chọn bằng 0 và không có các tương tác phi bảo toàn nào bên trong hệ, thì tổng cơ năng của hệ là không đổi.
    • 3.4.C.3 Nếu công thực hiện lên một hệ thống được chọn khác không, năng lượng được truyền tải giữa hệ thống và môi trường.

    Phát biểu biên: AP Physics C: Cơ học yêu cầu học sinh biết rằng cơ năng có thể bị tiêu tán thành nhiệt năng hoặc âm thanh do các lực phi bảo toàn.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Energy conservation: KE ⇄ PE

    Energy is conserved in all interactions – the question is only where it goes. Mechanical energy 机械能 is the sum $E=K+U$. If the external work on a system is zero and nothing inside it acts through nonconservative forces 非保守力, then

    $$K_1+U_1=K_2+U_2.$$

    When friction or drag act, they convert mechanical energy into thermal energy 热能 ($\Delta E_{\text{mech}}=-F_fd$), and the balance must include that term. If external work is done, the system's total energy changes by exactly the energy transferred: $W_{\text{ext}}=\Delta E_{\text{sys}}$. Choosing the system is choosing the bookkeeping – a single object can only have kinetic energy; include the Earth or the spring and the system can store potential energy too.

    A pendulum trades gravitational potential energy for kinetic energy and back
    A pendulum trades gravitational potential energy for kinetic energy and back

    A potential-energy graph is a complete motion map: the horizontal line at height $E$ is the total energy, the gap $E-U(x)$ is the kinetic energy at each $x$, and the crossings $E=U$ are the turning points 转折点 where the object momentarily stops and reverses.

    Worked example. A $2.0\ \text{kg}$ block slides down a ramp from rest at height $1.5\ \text{m}$, arriving at the bottom at $4.0\ \text{m/s}$. Energy accounting: $mgh=29.4\ \text{J}$ available; $\tfrac12mv^2=16\ \text{J}$ arrives as kinetic energy; so friction converted $29.4-16=13\ \text{J}$ into thermal energy along the way.

    A roller coaster trades energy back and forth: highest (most PE) at the top, fastest (most KE) at the bottom
    A roller coaster trades energy back and forth: highest (most PE) at the top, fastest (most KE) at the bottom
    Explore · ⁨Khám phá⁩

    Watch energy convert as an object falls

    With no friction, mechanical energy is conserved: as an object falls, gravitational potential energy turns into kinetic energy while the total stays fixed. · ⁨Không có ma sát, cơ năng được bảo toàn: khi vật rơi, năng lượng thế trọng lực chuyển hóa thành năng lượng động trong khi tổng năng lượng không đổi.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Mechanical energy/mɪˈkænɪkl ˈenədʒi/ Năng lượng cơ học
    nonconservative forces/ˌnɒŋkənˈsɜːvətɪv ˈfɔːsɪz/ lực không bảo toàn
    thermal energy/ˈθɜːml ˈenədʒi/ năng lượng nhiệt
    turning points/ˈtɜːnɪŋ pɔɪnts/ các điểm dừng
    Watch lesson · ⁨Xem bài học⁩
    3.5

    Power

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 3.5.A: Describe the transfer of energy into, out of, or within a system in terms of power.

    • 3.5.A.1 Power is the rate at which energy changes with respect to time, either by transfer into or out of a system or by conversion from one type to another within a system.
    • 3.5.A.2 Average power is the amount of energy being transferred or converted, divided by the time it took for that transfer or conversion to occur.
      • Equation: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
    • 3.5.A.3 Because work is the change in energy of an object or system due to a force, average power is the total work done, divided by the time during which that work was done.
      • Equation: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
    • 3.5.A.4 The instantaneous power delivered to an object by a force is given by the equation
      • Equation: $P_{\text{inst}} = \dfrac{dW}{dt}$
    • 3.5.A.5 The instantaneous power delivered to an object by the component of a constant force parallel to the object's velocity can be described with the derived equation
      • Equation: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$
    Tiếng Việt

    Mục tiêu học tập 3.5.A: Mô tả sự truyền năng lượng vào, ra khỏi hoặc bên trong một hệ dưới góc độ công suất.

    • 3.5.A.1 Công suất là tốc độ mà năng lượng thay đổi theo thời gian, thông qua sự truyền vào hoặc ra khỏi hệ, hoặc thông qua sự chuyển đổi từ dạng này sang dạng khác bên trong hệ.
    • 3.5.A.2 Công suất trung bình là lượng năng lượng được truyền hoặc chuyển đổi, chia cho thời gian cần thiết để quá trình truyền hoặc chuyển đổi đó xảy ra.
      • Phương trình: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
    • 3.5.A.3 Vì công là sự thay đổi năng lượng của một vật hoặc hệ do một lực gây ra, nên công suất trung bình là tổng công thực hiện, chia cho thời gian diễn ra công đó.
      • Phương trình: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
    • 3.5.A.4 Công suất tức thời cung cấp cho một vật bởi một lực được cho bởi phương trình
      • Phương trình: $P_{\text{inst}} = \dfrac{dW}{dt}$
    • 3.5.A.5 Công suất tức thời cung cấp cho một vật bởi thành phần của lực không đổi song song với vận tốc của vật có thể được mô tả bằng phương trình suy ra
      • Phương trình: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Power 功率 is the rate of energy transfer, in watts 瓦特 (W):

    $$P_{\text{avg}}=\frac{\Delta E}{\Delta t}=\frac{W}{\Delta t},\qquad P_{\text{inst}}=\frac{dW}{dt}=\vec{F}\cdot\vec{v}.$$

    It measures how fast work is done, not how much. The dot product matters: only the force component along the velocity delivers power.

    Power is the slope of the work-time graph: the same work in less time means more power
    Power is the slope of the work-time graph: the same work in less time means more power

    Worked example. A block released from rest at the top of a frictionless $3.0\ \text{m}$-high ramp reaches the bottom at $v=\sqrt{2gh}=7.7\ \text{m/s}$ (from $mgh=\tfrac12mv^2$). A motor that then drives it at a steady $7.7\ \text{m/s}$ against a $20\ \text{N}$ resistance delivers $P=Fv=20(7.7)\approx150\ \text{W}$.

    Worked example. A $1200\ \text{kg}$ car climbs a hill that rises $1.0\ \text{m}$ for every $20\ \text{m}$ of road, at a steady $15\ \text{m/s}$. The engine must supply gravity's power drain: $P=mg\,v\sin\theta=1200(9.8)(15)\big(\tfrac{1}{20}\big)\approx8.8\ \text{kW}$ – before adding air resistance.

    Exam skill. Energy FRQs reward the accounting sentence: name your system, state which forces do work on it, and write the balance ($W_{\text{ext}}=\Delta K+\Delta U+\Delta E_{\text{thermal}}$) before plugging in numbers. "Friction is present, so mechanical energy is not conserved" is a scored statement.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Power/ˈpaʊə/ Công suất
    watts/wɒts/ watt
    3.5

    Exam tips

    • Use the work–energy theorem $W_{net}=\Delta KE$ and compute work as $W=\int \vec F\cdot d\vec r$ for a variable force.
    • Read work off a force–position graph as the area under the curve.
    • Power is $P=\tfrac{dW}{dt}=\vec F\cdot\vec v$; watch instantaneous vs average.
    • Split forces into conservative (define a potential energy) and non-conservative (dissipate energy).
    • Choose energy methods over kinematics when the force varies or the path is complex.
  • 4

    Linear Momentum · ⁨Động lượng tuyến tính⁩

    Watch lesson · ⁨Xem bài học⁩
    4.1

    Linear Momentum · ⁨Động lượng tuyến tính⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 4.1.A: Describe the linear momentum of an object or system.

    • 4.1.A.1 Linear momentum is defined by the equation $\vec{p} = m\vec{v}$.
    • 4.1.A.2 Momentum is a vector quantity and has the same direction as the velocity.
    • 4.1.A.3 Momentum can be used to analyze collisions and explosions.
      • 4.1.A.3.i A collision is a model for an interaction where the forces exerted between the involved objects in the system are much larger than the net external force exerted on those objects during the interaction.
      • 4.1.A.3.ii As only the initial and final states of a collision are analyzed, the object model may be used to analyze collisions.
      • 4.1.A.3.iii An explosion is a model for an interaction in which forces internal to the system move objects within that system apart.
    Tiếng Việt

    Mục tiêu học tập 4.1.A: Mô tả động lượng tuyến tính của một vật hoặc hệ.

    • 4.1.A.1 Động lượng tuyến tính được định nghĩa bởi phương trình $\vec{p} = m\vec{v}$.
    • 4.1.A.2 Động lượng là đại lượng vector và có cùng hướng với vận tốc.
    • 4.1.A.3 Động lượng có thể được sử dụng để phân tích va chạm và vụ nổ.
      • 4.1.A.3.i Va chạm là mô hình cho một tương tác trong đó các lực tác dụng giữa các vật tham gia trong hệ lớn hơn rất nhiều so với ngoại lực ròng tác dụng lên các vật đó trong suốt quá trình tương tác.
      • 4.1.A.3.ii Vì chỉ trạng thái đầu và cuối của va chạm được phân tích, mô hình vật chất điểm có thể được dùng để phân tích va chạm.
      • 4.1.A.3.iii Vụ nổ là mô hình cho một tương tác trong đó các lực nội bộ của hệ đẩy các vật nằm trong hệ ra xa nhau.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English

    Linear momentum 动量 is mass times velocity:

    $$\vec{p}=m\vec{v}.$$

    It is a vector 矢量 pointing along the velocity, and it is the quantity for analysing collisions 碰撞 and explosions 爆炸. A collection of objects can be treated as one system moving with the velocity of its center of mass 质心:

    $$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$

    so the system's total momentum is its total mass times $\vec{v}_{\text{cm}}$ – one object's worth of bookkeeping for any number of parts.

    Tiếng Việt

    Động lượng tuyến tính là tích của khối lượng và vận tốc:

    $$\vec{p}=m\vec{v}.$$

    Nó là một véc-tơ chỉ theo phương vận tốc, và là thông số chính để phân tích va chạm và phá vỡ. Một tập hợp vật thể có thể được xem xét như một hệ duy nhất di chuyển với vận tốc trọng tâm của nó:

    $$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$

    nên tổng động lượng của hệ bằng tổng khối lượng nhân với $\vec{v}_{\text{cm}}$ – một cách tính toán đơn giản hóa bất kể số lượng bộ phận tham gia.

    4.2

    Change in Momentum and Impulse · ⁨Sự biến thiên động lượng và Xung lực⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 4.2.A: Describe the impulse delivered to an object or system.

    • 4.2.A.1 The rate of change of a system's momentum is equal to the net external force exerted on that system.
      • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
    • 4.2.A.2 Impulse is defined as the integral of a force exerted on an object or system over a time interval.
      • Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
    • 4.2.A.3 Impulse is a vector quantity and has the same direction as the net force exerted on the system.
    • 4.2.A.4 The impulse delivered to a system by a net external force is equal to the area under the curve of a graph of the net external force exerted on the system as a function of time.
    • 4.2.A.5 The net external force exerted on a system is equal to the slope of a graph of the momentum of the system as a function of time.

    Learning Objective 4.2.B: Describe the relationship between the impulse exerted on an object or system and the change in momentum of the object or system.

    • 4.2.B.1 Change in momentum is the difference between a system's final momentum and its initial momentum.
      • Equation: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
    • 4.2.B.2 The impulse–momentum theorem relates the impulse delivered to an object and the object's change in momentum.
      • 4.2.B.2.i The impulse exerted on an object is equal to the object's change in momentum.
        • Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
      • 4.2.B.2.ii Newton's second law of motion is a direct result of the impulse–momentum theorem applied to systems with constant mass.
        • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
      • 4.2.B.2.iii The impulse–momentum theorem also describes the behavior of a system in which the velocity is constant but the mass changes with respect to time.
        • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$
    Tiếng Việt

    Mục tiêu học tập 4.2.A: Mô tả xung lượng tác dụng lên một vật hoặc hệ.

    • 4.2.A.1 Tốc độ thay đổi động lượng của một hệ bằng lực ngoài tổng hợp tác dụng lên hệ đó.
      • Phương trình: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
    • 4.2.A.2 Xung lực được định nghĩa là tích phân của lực tác dụng lên một vật hoặc hệ trong một khoảng thời gian.
      • Phương trình: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
    • 4.2.A.3 Xung lượng là đại lượng vector và có cùng hướng với ngoại lực ròng tác dụng lên hệ.
    • 4.2.A.4 Xung lượng tác dụng lên một hệ bởi ngoại lực ròng bằng diện tích phía dưới đường cong của đồ thị biểu diễn ngoại lực ròng tác dụng lên hệ theo hàm số thời gian.
    • 4.2.A.5 Ngoại lực ròng tác dụng lên một hệ bằng hệ số góc của đồ thị biểu diễn động lượng của hệ theo hàm số thời gian.

    Mục tiêu học tập 4.2.B: Mô tả mối quan hệ giữa xung lực tác dụng lên một vật hoặc hệ và sự thay đổi động lượng của vật hoặc hệ đó.

    • 4.2.B.1 Sự biến thiên động lượng là hiệu giữa động lượng cuối và động lượng ban đầu của hệ.
      • Phương trình: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
    • 4.2.B.2 Định lý xung-động lượng liên hệ giữa xung lực truyền cho một vật và sự thay đổi động lượng của vật đó.
      • 4.2.B.2.i Xung lực tác dụng lên một vật bằng với sự thay đổi động lượng của vật đó.
        • Phương trình: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
      • 4.2.B.2.ii Định luật II Newton về chuyển động là kết quả trực tiếp của định lý xung-động lượng áp dụng cho các hệ có khối lượng không đổi.
        • Phương trình: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
      • 4.2.B.2.iii Định lý xung-động lượng cũng mô tả hành vi của một hệ mà trong đó vận tốc không đổi nhưng khối lượng thay đổi theo thời gian.
        • Phương trình: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English

    Newton's second law is really a statement about momentum:

    $$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$

    which reduces to $m\vec{a}$ when the mass is constant – and handles a changing mass when it is not (the special case $\vec{F}=\dfrac{dm}{dt}\vec{v}$ holds only when the velocity is constant, e.g. a chain piling onto a scale or sand landing on a belt moving at fixed speed; a rocket does not fit, since it accelerates). The impulse 冲量 delivered by a force is its time integral, and the impulse–momentum theorem 冲量-动量定理 says it equals the change in momentum:

    $$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$

    Impulse is a vector along the net force. Read it off graphs both ways:

    • On a force–time graph, impulse is the area under the curve.
    • On a momentum–time graph, the net force is the slope 斜率 at each instant.

    Spreading the same $\Delta p$ over a longer time lowers the force – that is why airbags, crumple zones, and soft landings work, and why you bend your knees when you land.

    Worked example. A time-varying force $F(t)=10t\ \text{N}$ acts on a $2.0\ \text{kg}$ object for $2.0\ \text{s}$. The impulse is $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$, so the speed changes by $\Delta v=J/m=10\ \text{m/s}$.

    Tiếng Việt

    Định luật thứ hai của Newton thực chất là phát biểu về động lượng:

    $$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$

    giản hóa thành $m\vec{a}$ khi khối lượng không đổi – và xử lý khối lượng thay đổi khi nó không phải hằng số (trường hợp đặc biệt $\vec{F}=\dfrac{dm}{dt}\vec{v}$ chỉ đúng khi vận tốc không đổi, ví dụ như chuỗi rơi vào cân hoặc cát rơi lên băng tải chạy đều; tên lửa không thuộc trường hợp này vì nó gia tốc). Xung lượng mà lực tác dụng là tích phân theo thời gian của lực, và định lý xung lượng - động lượng nói rằng nó bằng độ biến thiên động lượng:

    $$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$

    Xung lượng là một véc-tơ theo phương của lực hợp. Đọc nó trên đồ thị theo cả hai cách:

    • Trên đồ thị lực - thời gian, xung lượng là diện tích dưới đường cong.
    • Trên đồ thị động lượng - thời gian, lực hợp là độ dốc tại mỗi thời điểm.
    Xung lực là diện tích dưới đường cong lực - thời gian, bằng lực trung bình nhân với thời gian tiếp xúc
    Xung lực là diện tích dưới đường cong lực - thời gian, bằng lực trung bình nhân với thời gian tiếp xúc

    Phân tán cùng một $\Delta p$ trong khoảng thời gian dài hơn sẽ làm giảm lực – đó là lý do túi khí, vùng hấp thụ va đập và việc hạ cánh mềm hoạt động hiệu quả, cũng như lý do chúng ta gập gối khi hạ cánh.

    Ví dụ minh họa. Một lực biến đổi theo thời gian $F(t)=10t\ \text{N}$ tác dụng lên vật $2.0\ \text{kg}$ trong khoảng thời gian $2.0\ \text{s}$. Xung lượng là $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$, nên vận tốc thay đổi một lượng $\Delta v=J/m=10\ \text{m/s}$.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Linear momentum/ˈlɪnɪə məʊˈmentəm/ Động lượng tuyến tính
    vector/ˈvektə/ vector
    collisions/kəˈlɪʒnz/ Va chạm
    explosions/ekˈspləʊʒnz/ Phá nổ
    center of mass/ˈsentə ɒv mæs/ trọng tâm
    impulse/ˈɪmpʌls/ xung điện
    impulse–momentum theorem/ˈɪmpʌls məʊˈmentəm ˈθɪərəm/ Định lý xung – động lượng
    slope/sləʊp/ hệ số góc
    conserved/kənˈsɜːvd/ bảo toàn
    kinetic energy/kɪˈnetɪk ˈenədʒi/ động năng
    elastic collision/ɪˈlæstɪk kəˈlɪʒn/ va chạm đàn hồi
    inelastic collision/ɪnɪˈlæstɪk kəˈlɪʒn/ va chạm không đàn hồi
    deformation/ˌdiːfɔːˈmeɪʃn/ biến dạng
    perfectly inelastic collision/ˈpɜːfektlɪ ɪnɪˈlæstɪk kəˈlɪʒn/ va chạm không đàn hồi hoàn toàn
    4.3

    Conservation of Linear Momentum · ⁨Bảo toàn động lượng tuyến tính⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 4.3.A: Describe the behavior of a system using conservation of linear momentum.

    • 4.3.A.1 A collection of objects with individual momenta can be described as one system with one center-of-mass velocity.
      • 4.3.A.1.i For a collection of objects, the velocity of a system's center of mass can be calculated using the equation
        • Equation: $\vec{v}_{\text{cm}} = \dfrac{\sum \vec{p}_i}{\sum m_i} = \dfrac{\sum (m_i \vec{v}_i)}{\sum m_i}$
      • 4.3.A.1.ii The velocity of a system's center of mass is constant in the absence of a net external force.
    • 4.3.A.2 The total momentum of a system is the sum of the momenta of the system's constituent parts.
    • 4.3.A.3 In the absence of net external forces, any change to the momentum of an object within a system must be balanced by an equivalent and opposite change of momentum elsewhere within the system. Any change to the momentum of a system is due to a transfer of momentum between the system and its surroundings.
      • 4.3.A.3.i The impulse exerted by one object on a second object is equal and opposite to the impulse exerted by the second object on the first. This is a direct result of Newton's third law.
      • 4.3.A.3.ii A system may be selected so that the total momentum of that system is constant.
      • 4.3.A.3.iii If the total momentum of a system changes, that change will be equivalent to the impulse exerted on the system.
        • Equation: $\vec{J} = \Delta\vec{p}$
    • 4.3.A.4 Correct application of conservation of momentum can be used to determine the velocity of a system immediately before and immediately after collisions or explosions.

    Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze collisions and interactions in one or two dimensions. Three-dimensional collisions may be analyzed qualitatively.

    Learning Objective 4.3.B: Describe how the selection of a system determines whether the momentum of that system changes.

    • 4.3.B.1 Momentum is conserved in all interactions.
    • 4.3.B.2 If the net external force on the selected system is zero, the total momentum of the system is constant.
    • 4.3.B.3 If the net external force on the selected system is nonzero, momentum is transferred between the system and the environment.
    Tiếng Việt

    Mục tiêu học tập 4.3.A: Mô tả hành vi của một hệ dựa trên nguyên lý bảo toàn động lượng tuyến tính.

    • 4.3.A.1 Một tập hợp các vật có động lượng riêng lẻ có thể được mô tả như một hệ duy nhất với một vận tốc tâm khối.
      • 4.3.A.1.i Đối với một tập hợp các vật, vận tốc của tâm khối lượng hệ có thể được tính toán bằng phương trình
        • Phương trình: $\vec{v}_{\text{cm}} = \dfrac{\sum \vec{p}_i}{\sum m_i} = \dfrac{\sum (m_i \vec{v}_i)}{\sum m_i}$
      • 4.3.A.1.ii Vận tốc tâm khối của hệ không đổi khi không có ngoại lực ròng tác dụng.
    • 4.3.A.2 Tổng động lượng của một hệ bằng tổng các động lượng của các thành phần cấu tạo nên hệ.
    • 4.3.A.3 Trong điều kiện không có ngoại lực ròng, mọi sự thay đổi động lượng của một vật bên trong hệ phải được cân bằng bởi một sự thay đổi động lượng tương đương và ngược chiều ở nơi khác bên trong hệ. Mọi sự thay đổi động lượng của hệ là do sự truyền động lượng giữa hệ và môi trường xung quanh.
      • 4.3.A.3.i Xung lượng mà một vật tác dụng lên vật thứ hai bằng và ngược hướng với xung lượng mà vật thứ hai tác dụng lên vật đầu tiên. Đây là kết quả trực tiếp của Định luật III Newton.
      • 4.3.A.3.ii Một hệ thống có thể được chọn sao cho tổng động lượng của hệ thống đó không đổi.
      • 4.3.A.3.iii Nếu tổng động lượng của một hệ thống thay đổi, sự thay đổi đó sẽ tương đương với xung lực tác dụng lên hệ thống đó.
        • Phương trình: $\vec{J} = \Delta\vec{p}$
    • 4.3.A.4 Áp dụng đúng định luật bảo toàn động lượng có thể được sử dụng để xác định vận tốc của hệ ngay trước và ngay sau va chạm hoặc nổ.

    Tuyên bố giới hạn: AP Physics C: Cơ học chỉ yêu cầu học sinh phân tích định lượng va chạm và tương tác trong một hoặc hai chiều. Va chạm ba chiều có thể được phân tích định tính.

    Mục tiêu học tập 4.3.B: Mô tả cách lựa chọn hệ quyết định liệu động lượng của hệ đó có thay đổi hay không.

    • 4.3.B.1 Động lượng được bảo toàn trong mọi tương tác.
    • 4.3.B.2 Nếu hợp lực bên ngoài tác dụng lên hệ đã chọn bằng không, tổng động lượng của hệ là không đổi.
    • 4.3.B.3 Nếu hợp lực bên ngoài tác dụng lên hệ đã chọn khác không, động lượng được truyền giữa hệ và môi trường xung quanh.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English

    Internal forces come in Newton's-third-law pairs, so they cancel inside any system: they can shuffle momentum between parts but never change the total. Momentum only enters or leaves a system through a net external force ($\vec{J}=\Delta\vec{p}$). So, with zero net external force, total momentum is conserved 守恒:

    $$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$

    Momentum is conserved in every collision, however violent – choose the system large enough that the collision forces are internal. Apply conservation separately along each axis; AP asks for quantitative work in one or two dimensions.

    Worked example (explosion). A $6.0\ \text{kg}$ shell at rest splits into a $2.0\ \text{kg}$ piece moving at $9.0\ \text{m/s}$ east and a $4.0\ \text{kg}$ piece. Total momentum stays zero, so the heavy piece moves west at $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. The kinetic energy came from stored (chemical or spring) energy – momentum conservation does not require kinetic-energy conservation.

    Tiếng Việt

    Lực nội sinh xuất hiện theo cặp theo định luật thứ ba của Newton, nên chúng triệt tiêu lẫn nhau bên trong bất kỳ hệ thống nào: chúng có thể chuyển động lượng giữa các bộ phận nhưng không bao giờ thay đổi tổng động lượng. Động lượng chỉ đi vào hoặc rời khỏi hệ thống thông qua lực ngoại hợp ($\vec{J}=\Delta\vec{p}$). Do đó, với lực ngoại hợp bằng không, tổng động lượng được bảo toàn:

    $$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$

    Động lượng được bảo toàn trong mọi va chạm, dù mạnh hay yếu – hãy chọn hệ thống đủ lớn để lực va chạm trở thành lực nội sinh. Áp dụng sự bảo toàn riêng biệt theo từng trục; đề thi AP yêu cầu tính toán định lượng trong một hoặc hai chiều.

    Va chạm trực diện: tổng động lượng trước bằng tổng động lượng sau
    Va chạm trực diện: tổng động lượng trước bằng tổng động lượng sau

    Ví dụ minh họa (phá vỡ). Một viên đạn $6.0\ \text{kg}$ đang đứng yên tách thành một mảnh $2.0\ \text{kg}$ bay với vận tốc $9.0\ \text{m/s}$ về phía đông và một mảnh $4.0\ \text{kg}$. Tổng động lượng vẫn bằng không, nên mảnh nặng di chuyển về phía tây với vận tốc $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. Động năng đến từ năng lượng dự trữ (hóa học hoặc lò xo) – sự bảo toàn động lượng không đòi hỏi sự bảo toàn động năng.

    Explore · ⁨Khám phá⁩

    Collide two carts and conserve momentum · ⁨ va chạm hai xe và bảo toàn động lượng⁩

    In any collision the total momentum $\sum mv$ before equals the total after. Set the masses and speeds and check the momentum bookkeeping. · ⁨Trong mọi va chạm, tổng động lượng $\sum mv$ trước bằng tổng sau. Thiết lập khối lượng và vận tốc rồi kiểm tra việc tính toán động lượng.⁩

    4.4

    Elastic and Inelastic Collisions · ⁨Va chạm đàn hồi và không đàn hồi⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 4.4.A: Describe whether an interaction between objects is elastic or inelastic.

    • 4.4.A.1 An elastic collision between objects is one in which the initial kinetic energy of the system is equal to the final kinetic energy of the system.
    • 4.4.A.2 In an elastic collision, the final kinetic energies of each of the objects within the system may be different from their initial kinetic energies.
    • 4.4.A.3 An inelastic collision between objects is one in which the total kinetic energy of the system decreases.
    • 4.4.A.4 In an inelastic collision, some of the initial kinetic energy is not restored to kinetic energy but is transformed by nonconservative forces into other forms of energy.
    • 4.4.A.5 In a perfectly inelastic collision, the objects stick together and move with the same velocity after the collision.
    Tiếng Việt

    Mục tiêu học tập 4.4.A: Mô tả liệu tương tác giữa các vật có phải là đàn hồi hay không đàn hồi.

    • 4.4.A.1 Va chạm đàn hồi giữa các vật là va chạm mà tại đó động năng ban đầu của hệ bằng động năng cuối cùng của hệ.
    • 4.4.A.2 Trong va chạm đàn hồi, động năng cuối cùng của mỗi vật trong hệ có thể khác với động năng ban đầu của chúng.
    • 4.4.A.3 Va chạm không đàn hồi giữa các vật là va chạm mà tại đó tổng động năng của hệ giảm đi.
    • 4.4.A.4 Trong va chạm không đàn hồi, một phần động năng ban đầu không được phục hồi thành động năng mà bị các lực không bảo toàn biến đổi thành các dạng năng lượng khác.
    • 4.4.A.5 Trong va chạm hoàn toàn không đàn hồi, các vật dính vào nhau và chuyển động với cùng một vận tốc sau va chạm.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English
    Conservation of momentum in a collision

    All collisions conserve momentum; they differ in what happens to the kinetic energy 动能:

    type momentum kinetic energy
    elastic collision 弹性碰撞 conserved total conserved (individual shares may change)
    inelastic collision 非弹性碰撞 conserved decreases – some becomes heat, sound, deformation 形变
    perfectly inelastic collision 完全非弹性碰撞 conserved largest possible loss – the objects stick and share one velocity

    Strategy: always write momentum conservation first; add the kinetic-energy equation only when the problem says "elastic". Two useful elastic facts: equal masses in a 1D elastic collision simply exchange velocities, and in the center-of-mass frame each object just reverses its velocity.

    Worked example. A $1000\ \text{kg}$ car at $20\ \text{m/s}$ strikes a stationary $1500\ \text{kg}$ car and they lock together – perfectly inelastic. Momentum: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. Kinetic energy falls from $2.0\times10^5\ \text{J}$ to $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: about $60\%$ is lost, even though momentum is exactly conserved.

    Worked example (2D). A puck moving east at $4.0\ \text{m/s}$ strikes an identical puck at rest; after the glancing hit, one moves at $2.0\ \text{m/s}$ at $60^\circ$ north of east. Conserve each axis: east–west, $m(4.0)=m(2.0)\cos60^\circ+mv_x$, so $v_x=3.0\ \text{m/s}$; north–south, $0=m(2.0)\sin60^\circ-mv_y$, so $v_y=1.7\ \text{m/s}$. The second puck moves at $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$, about $30^\circ$ south of east.

    Exam skill. On FRQs, justify with the condition, not the slogan: "the net external force on the two-puck system is zero during the collision, so its total momentum is constant." If asked whether the collision is elastic, compute the kinetic energy before and after and compare – never assume.

    Tiếng Việt
    Bảo toàn động lượng trong va chạm

    Tất cả các va chạm đều bảo toàn động lượng; chúng khác nhau ở những gì xảy ra với động năng:

    loại động lượng động năng
    va chạm đàn hồi bảo toàn tổng bảo toàn (phần riêng lẻ có thể thay đổi)
    va chạm không đàn hồi bảo toàn giảm – một phần trở thành nhiệt, âm thanh, biến dạng
    va chạm không đàn hồi hoàn toàn bảo toàn mất mát lớn nhất có thể – các vật dính vào nhau và chia sẻ chung một vận tốc

    Chiến lược: luôn luôn viết phương trình bảo toàn động lượng trước; chỉ thêm phương trình động năng khi đề bài nói "đàn hồi". Hai quy tắc hữu ích về va chạm đàn hồi: nếu hai vật có khối lượng bằng nhau trong va chạm đàn hồi 1D, chúng chỉ đơn giản đổi chỗ vận tốc, và trong khung tham chiếu trọng tâm, mỗi vật chỉ đảo ngược vận tốc của mình.

    Ví dụ minh họa. Một ô tô $1000\ \text{kg}$ đang di chuyển ở vận tốc $20\ \text{m/s}$ va chạm với ô tô $1500\ \text{kg}$ đang đứng yên và chúng khóa chặt vào nhau – va chạm không đàn hồi hoàn toàn. Động lượng: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. Động năng giảm từ $2.0\times10^5\ \text{J}$ xuống $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: khoảng $60\%$ bị mất, mặc dù động lượng được bảo toàn hoàn toàn.

    Ví dụ minh họa (2D). Một puck di chuyển về phía đông với vận tốc $4.0\ \text{m/s}$ va chạm nhẹ vào một puck giống hệt đang đứng yên; sau cú va chạm, một cái di chuyển với vận tốc $2.0\ \text{m/s}$ ở góc $60^\circ$ so với phương đông. Bảo toàn từng trục: đông - tây, $m(4.0)=m(2.0)\cos60^\circ+mv_x$, suy ra $v_x=3.0\ \text{m/s}$; bắc - nam, $0=m(2.0)\sin60^\circ-mv_y$, suy ra $v_y=1.7\ \text{m/s}$. Puck thứ hai di chuyển với vận tốc $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$, khoảng $30^\circ$ về phía nam so với phương đông.

    Va chạm xiên, phân tích dọc theo hai trục vuông góc
    Va chạm xiên, phân tích dọc theo hai trục vuông góc

    Kỹ năng làm bài thi. Trong các câu hỏi tự luận (FRQ), hãy giải thích dựa trên điều kiện, không phải khẩu hiệu: "lực ngoài tổng hợp tác dụng lên hệ hai vật là bằng không trong quá trình va chạm, do đó động lượng toàn phần của nó được bảo toàn." Nếu được hỏi liệu va chạm có đàn hồi hay không, hãy tính toán động năng trước và sau va chạm rồi so sánh – tuyệt đối không được giả định.

    A Newton's cradle: five steel balls hanging in a row
    Một chiếc búa Newton minh họa sự truyền tải động lượng và động năng qua một va chạm gần như đàn hồi
    Explore · ⁨Khám phá⁩

    Compare elastic and inelastic collisions · ⁨So sánh va chạm đàn hồi và không đàn hồi⁩

    Momentum is always conserved, but kinetic energy is only conserved in an elastic collision. In an inelastic one the carts stick and some energy becomes heat. · ⁨Động lượng luôn được bảo toàn, nhưng động năng chỉ được bảo toàn trong va chạm đàn hồi. Trong va chạm không đàn hồi, các xe dính vào nhau và một phần năng lượng chuyển thành nhiệt.⁩

    4.4

    Exam tips · ⁨Mẹo làm bài thi⁩

    English
    • Impulse equals the momentum change: $\vec J=\int \vec F\,dt=\Delta\vec p$, and it is the area under a force–time graph.
    • Momentum is conserved whenever the net external force is zero — always the go-to for collisions.
    • Distinguish elastic (kinetic energy conserved) from inelastic (kinetic energy decreases) collisions; in a perfectly inelastic collision the objects stick and move with one velocity.
    • Apply conservation to each component (x and y) separately in 2-D.
    • Connect to center of mass: total momentum $=M\vec v_{cm}$.
    Tiếng Việt
    • Xung lực bằng với độ biến thiên động lượng: $\vec J=\int \vec F\,dt=\Delta\vec p$, và nó chính là diện tích dưới đồ thị lực–thời gian.
    • Động lượng được bảo toàn bất cứ khi nào lực ngoài tổng hợp bằng không – luôn là phương án ưu tiên cho các vấn đề va chạm.
    • Phân biệt va chạm đàn hồi (động năng được bảo toàn) và va chạm không đàn hồi (động năng giảm đi); trong một va chạm hoàn toàn không đàn hồi, các vật dính vào nhau và di chuyển cùng một vận tốc.
    • Áp dụng định luật bảo toàn cho từng thành phần (x và y) riêng biệt trong chuyển động 2 chiều.
    • Liên kết với tâm khối lượng: động lượng toàn phần $=M\vec v_{cm}$.
  • 5

    Torque and Rotational Dynamics · ⁨Mô-men lực và động học quay⁩

    Watch lesson · ⁨Xem bài học⁩
    5.1

    Rotational Kinematics

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 5.1.A: Describe the rotation of a system with respect to time using angular displacement, angular velocity, and angular acceleration.

    • 5.1.A.1 Angular displacement is the measurement of the angle, in radians, through which a point on a rigid system rotates about a specified axis.
      • Equation: $\Delta\theta = \theta - \theta_0$
      • 5.1.A.1.i A rigid system is one that holds its shape but in which different points on the system move in different directions during rotation. A rigid system cannot be modeled as an object.
      • 5.1.A.1.ii One direction of angular displacement about an axis of rotation—clockwise or counterclockwise—is typically indicated as mathematically positive, with the other direction becoming mathematically negative.
      • 5.1.A.1.iii If the rotation of a system about an axis may be well described using the motion of the system's center of mass, the system may be treated as a single object. For example, the rotation of Earth about its axis may be considered negligible when considering the revolution of Earth about the center of mass of the Earth–Sun system.
    • 5.1.A.2 Angular velocity is the rate at which angular position changes with respect to time.
      • Equation: $\omega = \dfrac{d\theta}{dt}$
    • 5.1.A.3 Angular acceleration is the rate at which angular velocity changes with respect to time.
      • Equation: $\alpha = \dfrac{d\omega}{dt}$
    • 5.1.A.4 Angular displacement, angular velocity, and angular acceleration around one axis are analogous to linear displacement, velocity, and acceleration in one dimension and demonstrate the same mathematical relationships.
      • 5.1.A.4.i For constant angular acceleration, the mathematical relationships between angular displacement, angular velocity, and angular acceleration can be described with the following equations:
        • $\omega = \omega_0 + \alpha t$
        • $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
        • $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
      • 5.1.A.4.ii Graphs of angular displacement, angular velocity, and angular acceleration as functions of time can be used to find the relationships between those quantities.

    Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of said vectors will not be assessed on the exam.

    Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.

    Tiếng Việt

    Mục tiêu học tập 5.1.A: Mô tả chuyển động quay của hệ theo thời gian bằng cách sử dụng độ dịch chuyển góc, vận tốc góc và gia tốc góc.

    • 5.1.A.1 Độ dịch chuyển góc là phép đo góc (tính bằng radian) mà một điểm trên hệ cứng quay quanh một trục xác định.
      • Phương trình: $\Delta\theta = \theta - \theta_0$
      • 5.1.A.1.i Hệ cứng là hệ giữ nguyên hình dạng nhưng các điểm khác nhau trên hệ chuyển động theo các hướng khác nhau trong quá trình quay. Một hệ cứng không thể được mô hình hóa như một vật thể.
      • 5.1.A.1.ii Một chiều của độ dịch chuyển góc quanh trục quay—theo chiều kim đồng hồ hoặc ngược chiều kim đồng hồ—thường được quy ước là dương trong toán học, còn chiều kia trở thành âm.
      • 5.1.A.1.iii Nếu chuyển động quay của hệ quanh một trục có thể được mô tả tốt bằng chuyển động của tâm khối lượng của hệ, thì hệ có thể được xem xét như một vật thể duy nhất. Ví dụ, khi xét chuyển động quỹ đạo của Trái Đất quanh tâm khối lượng của hệ Trái Đất - Mặt Trời, sự quay của Trái Đất quanh trục của chính nó có thể coi là không đáng kể.
    • 5.1.A.2 Vận tốc góc là tốc độ thay đổi vị trí góc theo thời gian.
      • Phương trình: $\omega = \dfrac{d\theta}{dt}$
    • 5.1.A.3 Gia tốc góc là tốc độ thay đổi vận tốc góc theo thời gian.
      • Phương trình: $\alpha = \dfrac{d\omega}{dt}$
    • 5.1.A.4 Độ dịch chuyển góc, vận tốc góc và gia tốc góc quanh một trục tương tự như độ dịch chuyển, vận tốc và gia tốc tuyến tính theo một chiều và thể hiện các mối quan hệ toán học giống nhau.
      • 5.1.A.4.i Đối với gia tốc góc không đổi, các mối quan hệ toán học giữa độ dịch chuyển góc, vận tốc góc và gia tốc góc có thể được mô tả bằng các phương trình sau:
        • $\omega = \omega_0 + \alpha t$
        • $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
        • $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
      • 5.1.A.4.ii Đồ thị biểu diễn độ dịch chuyển góc, vận tốc góc và gia tốc góc theo thời gian có thể được sử dụng để tìm các mối quan hệ giữa các đại lượng đó.

    Tuyên bố giới hạn: AP Physics C: Cơ học yêu cầu học sinh có khả năng thao tác toán học các độ lớn của độ lệch góc, vận tốc góc và gia tốc góc sử dụng quy ước vector. Tuy nhiên, hướng của các vector này sẽ không được đánh giá trong kỳ thi.

    Mô tả về hướng của các đại lượng động học quay cho một điểm hoặc vật rắn chỉ giới hạn ở chiều kim đồng hồ và ngược chiều kim đồng hồ so với một trục quay xác định.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Rotation mirrors linear motion with angular quantities, defined as derivatives:

    $$\omega=\frac{d\theta}{dt},\qquad \alpha=\frac{d\omega}{dt}=\frac{d^2\theta}{dt^2}.$$

    Here $\theta$ is angular displacement 角位移 in radians 弧度, $\omega$ the angular velocity 角速度, and $\alpha$ the angular acceleration 角加速度. (AP works with their magnitudes and signs; the 3D vector directions are not assessed.) For constant $\alpha$, the kinematic equations are the linear ones re-lettered:

    $$\omega=\omega_0+\alpha t,\qquad \Delta\theta=\omega_0t+\tfrac12\alpha t^2,\qquad \omega^2=\omega_0^2+2\alpha\,\Delta\theta.$$
    One radian is the angle whose arc length equals the radius
    One radian is the angle whose arc length equals the radius

    Worked example. A fan blade slows from $30\ \text{rad/s}$ to rest with $\alpha=-6.0\ \text{rad/s}^2$: it takes $t=5.0\ \text{s}$ and turns through $\Delta\theta=\dfrac{0-30^2}{2(-6.0)}=75\ \text{rad}$ – about $12$ revolutions.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ góc quay
    radians/ˈreɪdɪənz/ radian
    angular velocity/ˈæŋɡjʊlə vəˈlɒsɪti/ vận tốc góc
    angular acceleration/ˈæŋɡjʊlə əkˌseləˈreɪʃn/ gia tốc góc
    5.2

    Connecting Linear and Rotational Motion

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 5.2.A: Describe the linear motion of a point on a rotating rigid system that corresponds to the rotational motion of that point, and vice versa.

    • 5.2.A.1 For a point at a distance $r$ from a fixed axis of rotation, the linear distance $s$ traveled by the point as the system rotates through an angle $\Delta\theta$ is given by the equation $\Delta s = r\Delta\theta$.
    • 5.2.A.2 Derived relationships of linear velocity and of the tangential component of acceleration to their respective angular quantities are given by the following equations:
      • $s = r\theta$
      • $v = r\omega$
      • $a_T = r\alpha$
    • 5.2.A.3 For a rigid system, all points within that system have the same angular velocity and angular acceleration.

    Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of the vectors will not be assessed on the exam.

    Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.

    Tiếng Việt

    Mục tiêu học tập 5.2.A: Mô tả chuyển động tuyến tính của một điểm trên hệ cứng đang quay tương ứng với chuyển động quay của điểm đó, và ngược lại.

    • 5.2.A.1 Đối với một điểm ở khoảng cách $r$ từ trục quay cố định, quãng đường tuyến tính $s$ mà điểm đó di chuyển khi hệ quay qua một góc $\Delta\theta$ được cho bởi phương trình $\Delta s = r\Delta\theta$.
    • 5.2.A.2 Các mối quan hệ suy ra từ vận tốc tuyến tính và thành phần tiếp tuyến của gia tốc so với các đại lượng góc tương ứng của chúng được cho bởi các phương trình sau:
      • $s = r\theta$
      • $v = r\omega$
      • $a_T = r\alpha$
    • 5.2.A.3 Đối với hệ cứng, tất cả các điểm bên trong hệ đó đều có cùng vận tốc góc và gia tốc góc.

    Tuyên bố giới hạn: AP Physics C: Cơ học yêu cầu học sinh có khả năng thao tác toán học các độ lớn của độ lệch góc, vận tốc góc và gia tốc góc sử dụng quy ước vector. Tuy nhiên, hướng của các vector sẽ không được đánh giá trong kỳ thi.

    Mô tả về hướng của các đại lượng động học quay cho một điểm hoặc vật rắn chỉ giới hạn ở chiều kim đồng hồ và ngược chiều kim đồng hồ so với một trục quay xác định.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    A point at radius $r$ from the axis moves along its arc with

    $$s=r\theta,\qquad v=r\omega,\qquad a_t=r\alpha,$$

    so points farther out move faster. A rotating point generally has two acceleration components at once: the tangential acceleration 切向加速度 $a_t=r\alpha$ (speeding up along the arc) and the centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}=r\omega^2$ (turning, towards the axis). They are perpendicular, so $a=\sqrt{a_t^2+a_c^2}$.

    As the radius turns through an angle, a point moves along an arc at speed v
    As the radius turns through an angle, a point moves along an arc at speed v
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    tangential acceleration/tænˈdʒenʃl əkˌseləˈreɪʃn/ gia tốc tiếp tuyến
    centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ gia tốc hướng tâm
    5.3

    Torque

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 5.3.A: Identify the torques exerted on a rigid system.

    • 5.3.A.1 Torque results only from the force component perpendicular to the position vector from the axis of rotation to the point of application of the force.
    • 5.3.A.2 The lever arm is the perpendicular distance from the axis of rotation to the line of action of the exerted force.

    Learning Objective 5.3.B: Describe the torques exerted on a rigid system.

    • 5.3.B.1 Torques can be described using force diagrams.
      • 5.3.B.1.i Force diagrams are similar to free-body diagrams and are used to analyze the torques exerted on a rigid system.
      • 5.3.B.1.ii Similar to free-body diagrams, force diagrams represent the relative magnitude and direction of the forces exerted on a rigid system. Force diagrams also depict the location at which those forces are exerted relative to the axis of rotation.
    • 5.3.B.2 The torque exerted on a rigid system about a chosen pivot point by a given force is described by $\vec{\tau} = \vec{r} \times \vec{F}$.
      • 5.3.B.2.i The cross-product between two vectors, $\vec{A}$ and $\vec{B}$, results in a vector quantity of magnitude $\vec{A} \times \vec{B} = AB\sin\theta$.
      • 5.3.B.2.ii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ is perpendicular to both vectors $\vec{A}$ and $\vec{B}$ and therefore is normal to the plane defined by vectors $\vec{A}$ and $\vec{B}$.
      • 5.3.B.2.iii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ can be qualitatively determined by applying the appropriate right-hand rule.
    Tiếng Việt

    Mục tiêu học tập 5.3.A: Xác định các momen lực tác dụng lên hệ cứng.

    • 5.3.A.1 Momen lực chỉ phát sinh từ thành phần lực vuông góc với vectơ vị trí từ trục quay đến điểm đặt lực.
    • 5.3.A.2 Cánh tay đòn là khoảng cách vuông góc từ trục quay đến đường tác dụng của lực.

    Mục tiêu học tập 5.3.B: Mô tả các mô-men tác dụng lên một hệ vật cứng.

    • 5.3.B.1 Mô-men có thể được mô tả bằng sơ đồ lực.
      • 5.3.B.1.i Sơ đồ lực tương tự như sơ đồ vật tự do và được sử dụng để phân tích các mô-men tác dụng lên một hệ vật cứng.
      • 5.3.B.1.ii Tương tự như sơ đồ vật tự do, sơ đồ lực biểu diễn độ lớn tương đối và hướng của các lực tác dụng lên một hệ vật cứng. Sơ đồ lực cũng chỉ ra vị trí mà các lực đó tác dụng so với trục quay.
    • 5.3.B.2 Momen lực tác dụng lên một hệ vật rắn đối với một điểm tựa đã chọn bởi một lực cho trước được mô tả bởi $\vec{\tau} = \vec{r} \times \vec{F}$.
      • 5.3.B.2.i Tích có hướng giữa hai vector, $\vec{A}$ và $\vec{B}$, tạo ra một đại lượng vector có độ lớn là $\vec{A} \times \vec{B} = AB\sin\theta$.
      • 5.3.B.2.ii Hướng của vector thu được từ tích có hướng của hai vector $\vec{A}$ và $\vec{B}$ vuông góc với cả hai vector $\vec{A}$ và $\vec{B}$, do đó nó pháp tuyến với mặt phẳng xác định bởi hai vector $\vec{A}$ và $\vec{B}$.
      • 5.3.B.2.iii Hướng của vector thu được từ tích có hướng của hai vector $\vec{A}$ và $\vec{B}$ có thể được xác định định tính bằng cách áp dụng quy tắc bàn tay phải phù hợp.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    The principle of moments (torque)

    Torque 力矩 is the turning effect of a force – the rotational cause, as force is the translational cause. It is a vector product 矢量积:

    $$\vec{\tau}=\vec{r}\times\vec{F},\qquad \tau=rF\sin\theta=F\,r_\perp,$$

    where $r_\perp$, the moment arm 力臂, is the perpendicular distance from the axis to the force's line of action. More force, applied farther from the axis, more perpendicular: more torque. A force pointing straight at (or away from) the axis has zero torque. In a plane, give counterclockwise and clockwise torques opposite signs and add.

    As a vector product, $\vec\tau=\vec r\times\vec F$ points perpendicular to the plane of $\vec r$ and $\vec F$, with its direction fixed by the right-hand rule 右手定则: curl your right fingers from $\vec r$ toward $\vec F$ and your thumb points along $\vec\tau$ – out of the page for a counterclockwise turn, into it for a clockwise one. The same rule gives the direction of angular momentum $\vec L=\vec r\times\vec p$.

    The torque of a force depends on the perpendicular distance from the axis
    The torque of a force depends on the perpendicular distance from the axis
    A gear train: torques and rotational inertia couple through the gear ratio
    A gear train: torques and rotational inertia couple through the gear ratio
    Explore · ⁨Khám phá⁩

    Balance torques on a beam · ⁨Cân bằng mô-men trên thanh dầm⁩

    Torque is force times perpendicular distance, $\tau=Fd$. The beam is in rotational equilibrium when the torques on each side are equal. · ⁨Mô-men là lực nhân với khoảng cách vuông góc, $\tau=Fd$. Thanh dầm ở trạng thái cân bằng quay khi mô-men ở mỗi bên bằng nhau.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Torque/tɔːk/ Mô-men lực
    vector product/ˈvektə ˈprɒdʌkt/ tích có hướng (vector product)
    moment arm/ˈməʊmənt ɑːm/ Cánh tay lực
    right-hand rule/raɪt hænd ruːl/ qui tắc bàn tay phải
    Watch lesson · ⁨Xem bài học⁩
    5.4

    Rotational Inertia

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 5.4.A: Describe the rotational inertia of a rigid system relative to a given axis of rotation.

    • 5.4.A.1 Rotational inertia measures a rigid system's resistance to changes in rotation and is related to the mass of the system and the distribution of that mass relative to the axis of rotation.
    • 5.4.A.2 The rotational inertia of an object rotating a perpendicular distance $r$ from an axis is described by the equation $I = mr^2$.
    • 5.4.A.3 The total rotational inertia of a collection of objects about an axis is the sum of the rotational inertias of each object about that axis.
      • Equation: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
    • 5.4.A.4 For a solid that can be considered as a collection of differential masses, $dm$, the solid's rotational inertia can be calculated using the equation $I = \int r^2\, dm$, where $r$ is the perpendicular distance from $dm$ to the axis of rotation.

    Learning Objective 5.4.B: Describe the rotational inertia of a rigid system rotating about an axis that does not pass through the system's center of mass.

    • 5.4.B.1 A rigid system's rotational inertia in a given plane is at a minimum when the rotational axis passes through the system's center of mass.
    • 5.4.B.2 The parallel axis theorem uses the following equation to relate the rotational inertia of a rigid system about any axis that is parallel to an axis through its center of mass:
      • Equation: $I' = I_{\text{cm}} + Md^2$

    Boundary statement: AP Physics C: Mechanics only expects students to use calculus in the derivations of the rotational inertia of thin rods of uniform or nonuniform density about an arbitrary axis perpendicular to the rod, as well as derivations of the rotational inertia of a thin cylindrical shell, disk, or rigid bodies that can be considered to be made up of coaxial rings or shells about an axis that passes through their centers (e.g., annular rings).

    Students should have a qualitative understanding of the factors that affect rotational inertia; for example, how rotational inertia is greater when mass is farther from the axis of rotation, which is why a hoop has more rotational inertia than a solid puck of the same mass and radius.

    Tiếng Việt

    Mục tiêu học tập 5.4.A: Mô tả quán tính quay của một hệ vật cứng so với một trục quay cho trước.

    • 5.4.A.1 Quán tính quay đo lường sự kháng cự của một hệ vật cứng đối với sự thay đổi chuyển động quay và liên quan đến khối lượng của hệ thống và sự phân bố khối lượng đó so với trục quay.
    • 5.4.A.2 Momen quán tính của một vật quay tại khoảng cách vuông góc $r$ từ một trục được mô tả bởi phương trình $I = mr^2$.
    • 5.4.A.3 Momen quán tính tổng hợp của một tập hợp các vật đối với một trục là tổng các momen quán tính của từng vật đối với trục đó.
      • Phương trình: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
    • 5.4.A.4 Đối với một vật rắn có thể xem như một tập hợp các phần tử khối lượng vi phân, $dm$, momen quán tính của vật rắn có thể được tính toán bằng phương trình $I = \int r^2\, dm$, trong đó $r$ là khoảng cách vuông góc từ $dm$ đến trục quay.

    Mục tiêu học tập 5.4.B: Mô tả quán tính quay của một hệ vật cứng quay quanh một trục không đi qua trọng tâm của hệ.

    • 5.4.B.1 Quán tính quay của một hệ vật cứng trong một mặt phẳng cho trước đạt giá trị nhỏ nhất khi trục quay đi qua trọng tâm của hệ.
    • 5.4.B.2 Định lý trục song song sử dụng phương trình sau để liên hệ quán tính quay của một hệ vật cứng quanh bất kỳ trục nào song song với trục đi qua trọng tâm của nó:
      • Phương trình: $I' = I_{\text{cm}} + Md^2$

    Tuyên bố giới hạn: AP Physics C: Cơ học chỉ yêu cầu học sinh sử dụng giải tích trong các chứng minh momen quán tính của thanh mảnh có mật độ đều hoặc không đều đối với một trục tùy ý vuông góc với thanh, cũng như các chứng minh momen quán tính của vỏ trụ mỏng, đĩa, hoặc các vật rắn có thể xem như được cấu thành từ các vòng tròn hoặc vỏ đồng trục đối với một trục đi qua tâm của chúng (ví dụ: vòng tròn rỗng).

    Học sinh cần có hiểu biết định tính về các yếu tố ảnh hưởng đến momen quán tính; ví dụ, momen quán tính lớn hơn khi khối lượng nằm xa trục quay hơn, đây là lý do tại sao một vòng tròn có momen quán tính lớn hơn một đĩa đặc có cùng khối lượng và bán kính.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Rotational inertia 转动惯量 $I$ measures resistance to angular acceleration – the rotational analog of mass, but it depends on where the mass sits. For point masses, $I=\sum m_ir_i^2$; for a continuous body,

    $$I=\int r^2\,dm.$$

    Mass far from the axis dominates, because of the $r^2$.

    Worked example (rod). A uniform rod (mass $M$, length $L$) about its centre: with linear density 线密度 $\lambda=M/L$, $dm=\lambda\,dx$, so $I=\displaystyle\int_{-L/2}^{L/2}x^2\,\frac{M}{L}\,dx=\frac{1}{12}ML^2$. AP also expects nonuniform rods: if $\lambda(x)=cx$ on $[0,L]$, first find $M=\int_0^L cx\,dx=\tfrac12cL^2$, then $I=\int_0^L x^2(cx)\,dx=\tfrac14cL^4=\tfrac12ML^2$ about the light end.

    Worked example (disk from rings). A solid disk is a nest of rings: a ring at radius $r$ of width $dr$ has $dm=\dfrac{M}{\pi R^2}\,2\pi r\,dr$, so

    $$I=\int_0^R r^2\,dm=\frac{2M}{R^2}\int_0^R r^3\,dr=\tfrac12MR^2.$$

    The same coaxial-shell method handles cylindrical shells and annular rings.

    The parallel-axis theorem 平行轴定理 shifts any known $I$ to a parallel axis a distance $d$ away:

    $$I'=I_{\text{cm}}+Md^2.$$

    For the rod about one end: $I=\tfrac1{12}ML^2+M\big(\tfrac{L}{2}\big)^2=\tfrac13ML^2$.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ Momen quán tính quay
    linear density/ˈlɪnɪə ˈdensɪti/ Mật độ tuyến tính
    parallel-axis theorem/ˈpærəlel ˈæksɪs ˈθɪərəm/ định lý trục song song
    5.5

    Rotational Equilibrium

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 5.5.A: Describe the conditions under which a system's angular velocity remains constant.

    • 5.5.A.1 A system may exhibit rotational equilibrium (constant angular velocity) without being in translational equilibrium, and vice versa.
      • 5.5.A.1.i Free-body and force diagrams describe the nature of the forces and torques exerted on an object or rigid system.
      • 5.5.A.1.ii Rotational equilibrium is a configuration of torques such that the net torque exerted on the system is zero.
        • Equation: $\sum \tau_i = 0$
      • 5.5.A.1.iii The rotational analog of Newton's first law is that a system will have a constant angular velocity only if the net torque exerted on the system is zero.
    • 5.5.A.2 A rotational corollary to Newton's second law states that if the torques exerted on a rigid system are not balanced, the system's angular velocity must be changing.

    Boundary statement: AP Physics C: Mechanics does not expect students to simultaneously analyze rotation in multiple planes.

    Tiếng Việt

    Mục tiêu học tập 5.5.A: Mô tả các điều kiện để vận tốc góc của một hệ duy trì không đổi.

    • 5.5.A.1 Một hệ có thể thể hiện trạng thái cân bằng quay (vận tốc góc không đổi) mà không cần ở trạng thái cân bằng tịnh tiến, và ngược lại.
      • 5.5.A.1.i Sơ đồ vật tự do và sơ đồ lực mô tả bản chất của các lực và mô-men tác dụng lên một vật hay hệ vật cứng.
      • 5.5.A.1.ii Cân bằng quay là trạng thái của các mô-men sao cho tổng mô-men tác dụng lên hệ bằng không.
        • Phương trình: $\sum \tau_i = 0$
      • 5.5.A.1.iii Phiên bản quay của định luật Newton thứ nhất là: một hệ sẽ có vận tốc góc không đổi chỉ khi tổng mô-men tác dụng lên hệ bằng không.
    • 5.5.A.2 Hệ quả quay của định luật Newton thứ hai phát biểu rằng nếu các mô-men tác dụng lên một hệ vật cứng không cân bằng, thì vận tốc góc của hệ phải đang thay đổi.

    Tuyên bố giới hạn: AP Physics C: Cơ học không yêu cầu học sinh đồng thời phân tích chuyển động quay trong nhiều mặt phẳng.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Newton's first law has a rotational form: with zero net torque, angular velocity is constant – an object in rotational equilibrium 转动平衡 either does not rotate or rotates steadily. Full static equilibrium 静平衡 needs both $\sum F=0$ and $\sum\tau=0$ (about any axis). The standard move for beams and ladders: put the axis at the point where an unknown force acts, so that force drops out of the torque equation.

    At balance the clockwise and anticlockwise torques about the axis are equal
    At balance the clockwise and anticlockwise torques about the axis are equal

    Worked example. A uniform $20\ \text{kg}$ beam, $4.0\ \text{m}$ long, is pivoted at its left end and held horizontal by a vertical rope at its right end. A $40\ \text{kg}$ child sits $1.0\ \text{m}$ from the pivot. Torques about the pivot: $T(4.0)=20g(2.0)+40g(1.0)$, so $T=\dfrac{392+392}{4.0}=196\ \text{N}$. Then vertical force balance gives the pivot's upward push: $F_p=(60)(9.8)-196=392\ \text{N}$. Choosing the pivot as the axis removed $F_p$ from the torque equation entirely.

    A beam balance: rotational equilibrium when clockwise and anticlockwise torques match
    A beam balance: rotational equilibrium when clockwise and anticlockwise torques match
    Explore · ⁨Khám phá⁩

    Find the balance point · ⁨Tìm điểm cân bằng⁩

    For rotational equilibrium the total clockwise torque equals the total anticlockwise torque. Move the forces and distances until the beam balances. · ⁨Để đạt cân bằng quay, tổng mô-men chiều kim đồng hồ phải bằng tổng mô-men ngược chiều kim đồng hồ. Di chuyển lực và khoảng cách cho đến khi thanh cân bằng.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    rotational equilibrium/rəʊˈteɪʃənl ˌiːkwɪˈlɪbrɪəm/ cân bằng quay
    static equilibrium/ˈstætɪk ˌiːkwɪˈlɪbrɪəm/ cân bằng tĩnh
    Watch lesson · ⁨Xem bài học⁩
    5.6

    Newton's Second Law in Rotational Form

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 5.6.A: Describe the conditions under which a system's angular velocity changes.

    • 5.6.A.1 Angular velocity changes when the net torque exerted on the object or system is not equal to zero.
    • 5.6.A.2 The rate at which the angular velocity of a rigid system changes is directly proportional to the net torque exerted on the rigid system and is in the same direction. The angular acceleration of the rigid system is inversely proportional to the rotational inertia of the rigid system.
      • Equation: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
    • 5.6.A.3 To fully describe a rotating rigid system, linear and rotational analyses may need to be performed independently.
    Tiếng Việt

    Mục tiêu học tập 5.6.A: Mô tả các điều kiện để vận tốc góc của một hệ thay đổi.

    • 5.6.A.1 Vận tốc góc thay đổi khi tổng mô-men tác dụng lên vật hay hệ không bằng không.
    • 5.6.A.2 Tốc độ thay đổi vận tốc góc của một hệ vật cứng tỷ lệ thuận với tổng mô-men tác dụng lên hệ vật cứng và cùng hướng. Gia tốc góc của hệ vật cứng tỷ lệ nghịch với quán tính quay của hệ vật cứng.
      • Phương trình: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
    • 5.6.A.3 Để mô tả đầy đủ một hệ vật cứng đang quay, có thể cần phải thực hiện các phân tích tịnh tiến và quay độc lập.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    A net torque produces angular acceleration in proportion to the rotational inertia:

    $$\alpha=\frac{\sum\tau}{I}\qquad\Big(\text{more generally }\sum\vec{\tau}=\frac{d\vec{L}}{dt}\Big).$$

    Solve rotational dynamics exactly like translational dynamics, with $\tau\leftrightarrow F$, $I\leftrightarrow m$, $\alpha\leftrightarrow a$ – free-body diagram, equations, solve.

    A massive pulley: the two tensions differ because the pulley needs net torque
    A massive pulley: the two tensions differ because the pulley needs net torque

    Worked example (massive pulley). Masses $m_1=4.0\ \text{kg}$ and $m_2=2.0\ \text{kg}$ hang from a rope over a pulley 滑轮 of rotational inertia $I=0.50\ \text{kg}\cdot\text{m}^2$ and radius $R=0.20\ \text{m}$. Three Newton's-law equations, one per body:

    $$m_1g-T_1=m_1a,\qquad T_2-m_2g=m_2a,\qquad (T_1-T_2)R=I\alpha=\frac{Ia}{R}.$$

    Adding them (with $I/R^2=12.5\ \text{kg}$): $a=\dfrac{(m_1-m_2)g}{m_1+m_2+I/R^2}=\dfrac{19.6}{18.5}=1.1\ \text{m/s}^2$. Then $T_1=m_1(g-a)=35\ \text{N}$ and $T_2=m_2(g+a)=22\ \text{N}$. The tensions must differ – otherwise nothing would spin the pulley. (If a problem says the pulley is light, then $I\approx0$ and the tensions become equal again.)

    Exam skill. Rotational FRQs score the setup: separate free-body diagrams for each mass and the pulley, the string constraint $a=R\alpha$ stated, and the sign convention consistent. The single most common error is assuming one tension throughout a rope that passes over a massive pulley.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    pulley/ˈpʊli/ con pulley
    5.6

    Exam tips

    • Use the rotational analogues: $\theta,\omega=\tfrac{d\theta}{dt},\alpha=\tfrac{d\omega}{dt}$, with the constant-$\alpha$ equations mirroring linear kinematics.
    • Convert between linear and angular with $v=r\omega$ and $a_t=r\alpha$ (plus centripetal $a_c=\tfrac{v^2}{r}=\omega^2 r$).
    • Keep radians throughout and fix a positive sense of rotation.
    • Relate torque to angular acceleration through $\tau=I\alpha$.
    • Draw the rotation axis — the moment arm is the perpendicular distance to it.
  • 6

    Energy and Momentum of Rotating Systems · ⁨Năng lượng và động lượng của hệ quay⁩

    Watch lesson · ⁨Xem bài học⁩
    6.1

    Rotational Kinetic Energy · ⁨Động năng Quay⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 6.1.A: Describe the rotational kinetic energy of a rigid system in terms of the rotational inertia and angular velocity of that rigid system.

    • 6.1.A.1 The rotational kinetic energy of an object or rigid system is related to the rotational inertia and angular velocity of the rigid system and is given by the equation $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
      • Equation: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
      • 6.1.A.1.i The rotational inertia of an object about a fixed axis can be used to show that the rotational kinetic energy of that object is equivalent to its translational kinetic energy, which is its total kinetic energy.
      • 6.1.A.1.ii The total kinetic energy of a rigid system is the sum of its rotational kinetic energy due to its rotation about its center of mass and the translational kinetic energy due to the linear motion of its center of mass.
    • 6.1.A.2 A rigid system can have rotational kinetic energy while its center of mass is at rest due to the individual points within the rigid system having linear speed and, therefore, kinetic energy.
    • 6.1.A.3 Rotational kinetic energy is a scalar quantity.
    Tiếng Việt

    Mục tiêu học tập 6.1.A: Mô tả động năng quay của một hệ vật cứng theo quán tính quay và vận tốc góc của hệ vật cứng đó.

    • 6.1.A.1 Động năng quay của một vật hay hệ vật cứng liên quan đến quán tính quay và vận tốc góc của hệ vật cứng và được cho bởi phương trình $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
      • Phương trình: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
      • 6.1.A.1.i Quán tính quay của một vật quanh một trục cố định có thể được sử dụng để chứng minh rằng động năng quay của vật đó tương đương với động năng tịnh tiến của nó, tức là tổng động năng của nó.
      • 6.1.A.1.ii Tổng động năng của một hệ vật cứng là tổng động năng quay do sự quay quanh trọng tâm của nó và động năng tịnh tiến do chuyển động tuyến tính của trọng tâm.
    • 6.1.A.2 Một hệ vật cứng có thể có động năng quay trong khi trọng tâm của nó đứng yên do các điểm riêng lẻ bên trong hệ vật cứng có vận tốc tuyến tính và, do đó, có động năng.
    • 6.1.A.3 Động năng quay là đại lượng vô hướng.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English

    A spinning body has rotational kinetic energy 转动动能

    $$K_{\text{rot}}=\tfrac12 I\omega^2,$$

    the rotational twin of $\tfrac12mv^2$, with the rotational inertia 转动惯量 $I$ playing the role of mass. A body that both moves and spins carries both terms:

    $$K=\tfrac12 mv_{\text{cm}}^2+\tfrac12 I\omega^2.$$

    Worked example. A uniform cylinder ($I=\tfrac12mr^2$) rolls at speed $v$. Its kinetic energy is $K=\tfrac12mv^2+\tfrac12\big(\tfrac12mr^2\big)\big(\tfrac{v}{r}\big)^2=\tfrac34mv^2$ – one third of it is rotational. The same ball of energy bookkeeping decides every rolling problem.

    Tiếng Việt

    Một vật đang quay có động năng quay

    $$K_{\text{rot}}=\tfrac12 I\omega^2,$$

    bản sao quay của $\tfrac12mv^2$, trong đó momen quán tính $I$ đóng vai trò như khối lượng. Một vật vừa di chuyển vừa quay mang cả hai thành phần:

    $$K=\tfrac12 mv_{\text{cm}}^2+\tfrac12 I\omega^2.$$

    Ví dụ minh họa. Một trụ đều ($I=\tfrac12mr^2$) lăn với vận tốc $v$. Động năng của nó là $K=\tfrac12mv^2+\tfrac12\big(\tfrac12mr^2\big)\big(\tfrac{v}{r}\big)^2=\tfrac34mv^2$ – một phần ba thuộc về động năng quay. Nguyên tắc kế toán năng lượng này áp dụng cho mọi bài toán lăn.

    6.2

    Torque and Work · ⁨Mô-men Lực và Công⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 6.2.A: Describe the work done on a rigid system by a given torque or collection of torques.

    • 6.2.A.1 A torque can transfer energy into or out of an object or rigid system if the torque is exerted over an angular displacement.
    • 6.2.A.2 The amount of work done on a rigid system by a torque is related to the magnitude of that torque and the angular displacement through which the rigid system rotates during the interval in which that torque is exerted.
      • Equation: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
    • 6.2.A.3 Work done on a rigid system by a given torque can be found from the area under the curve of a graph of the torque as a function of angular position.
    Tiếng Việt

    Mục tiêu học tập 6.2.A: Mô tả công thực hiện lên một hệ cứng bởi một mô-men lực cho trước hoặc một tập hợp các mô-men lực.

    • 6.2.A.1 Một mô-men lực có thể truyền năng lượng vào hoặc ra khỏi một vật thể hoặc hệ cứng nếu mô-men lực đó tác dụng trong một góc quay (độ dịch chuyển góc).
    • 6.2.A.2 Độ lớn của công thực hiện lên một hệ cứng bởi một mô-men lực liên quan đến độ lớn của mô-men lực đó và độ dịch chuyển góc mà hệ cứng quay trong khoảng thời gian mô-men lực đó tác dụng.
      • Phương trình: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
    • 6.2.A.3 Công thực hiện lên một hệ vật rắn bởi một momen lực cho trước có thể tìm thấy từ diện tích dưới đường cong của biểu đồ momen lực theo vị trí góc.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English

    A torque 力矩 acting through an angular displacement 角位移 does work, and power is torque times angular velocity:

    $$W=\int_{\theta_1}^{\theta_2}\tau\,d\theta,\qquad P=\tau\omega.$$

    These are the rotational forms of $W=\int F\,dx$ and $P=Fv$ – the whole translational energy toolkit carries over with $F\to\tau$, $x\to\theta$, $v\to\omega$.

    Worked example. A motor applies a constant $8.0\ \text{N}\cdot\text{m}$ torque to a flywheel for $5.0$ full turns: $W=\tau\,\Delta\theta=8.0(5.0)(2\pi)=250\ \text{J}$, which appears as rotational kinetic energy if friction is negligible.

    Tiếng Việt

    Một mô-men lực tác dụng qua một góc lệch quay thực hiện công, và công suất bằng mô-men lực nhân với vận tốc góc:

    $$W=\int_{\theta_1}^{\theta_2}\tau\,d\theta,\qquad P=\tau\omega.$$

    Đây là dạng quay của $W=\int F\,dx$ và $P=Fv$ – toàn bộ bộ công cụ năng lượng tịnh tiến được chuyển giao hoàn toàn với $F\to\tau$, $x\to\theta$, $v\to\omega$.

    Ví dụ minh họa. Một động cơ tác dụng một mô-men lực không đổi $8.0\ \text{N}\cdot\text{m}$ lên bánh đà trong $5.0$ vòng quay đầy đủ: $W=\tau\,\Delta\theta=8.0(5.0)(2\pi)=250\ \text{J}$, xuất hiện dưới dạng động năng quay nếu ma sát không đáng kể.

    Explore · ⁨Khám phá⁩

    Balance torques on a beam · ⁨Cân bằng mô-men trên thanh dầm⁩

    Torque is force times perpendicular distance, $\tau=Fd$. Equal torques on each side keep the beam in rotational equilibrium. · ⁨Mô-men lực là lực nhân với khoảng cách vuông góc, $\tau=Fd$. Hai mô-men lực bằng nhau ở hai bên giữ cho dầm cân bằng quay.⁩

    6.3

    Angular Momentum and Angular Impulse · ⁨Động lượng Góc và Xung lượng Góc⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 6.3.A: Describe the angular momentum of an object or rigid system.

    • 6.3.A.1 The magnitude of the angular momentum of a rigid system about a specific axis can be described with the equation $L = I\omega$.
      • Equation: $L = I\omega$
    • 6.3.A.2 The angular momentum of an object about a given point is $\vec{L} = \vec{r} \times \vec{p}$.
      • Equation: $\vec{L} = \vec{r} \times \vec{p}$
      • 6.3.A.2.i The selection of the axis about which an object is considered to rotate influences the determination of the angular momentum of that object.
      • 6.3.A.2.ii The measured angular momentum of an object traveling in a straight line depends on the distance between the reference point and the object, the mass of the object, the speed of the object, and the angle between the radial distance and the velocity of the object.

    Learning Objective 6.3.B: Describe the angular impulse delivered to an object or rigid system by a torque.

    • 6.3.B.1 Angular impulse is defined as the product of the torque exerted on an object or rigid system and the time interval during which the torque is exerted.
      • Equation: $\text{angular impulse} = \displaystyle\int \tau \, dt$
    • 6.3.B.2 Angular impulse has the same direction as the torque imparting it.
    • 6.3.B.3 The angular impulse delivered to an object or rigid system by a torque can be found from the area under the curve of a graph of the torque as a function of time.

    Learning Objective 6.3.C: Relate the change in angular momentum of an object or rigid system to the angular impulse given to that object or rigid system.

    • 6.3.C.1 The magnitude of the change in angular momentum can be described by comparing the magnitudes of the final and initial momenta of the object or rigid system.
      • Equation: $\Delta L = L - L_0$
    • 6.3.C.2 A rotational form of the impulse–momentum theorem relates the angular impulse delivered to an object or rigid system and the change in angular momentum of that object or rigid system.
      • 6.3.C.2.i The angular impulse exerted on an object or rigid system is equal to the change in angular momentum of that object or rigid system.
        • Equation: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
      • 6.3.C.2.ii The rotational form of the impulse–momentum theorem is a direct result of Newton's second law of motion for cases in which rotational inertia is constant.
        • Equation: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
    • 6.3.C.3 The net torque exerted on an object or rigid system is equal to the slope of the graph of the angular momentum of an object as a function of time.
    • 6.3.C.4 The angular impulse delivered to an object or rigid system is equal to the area under the curve of a graph of the net external torque exerted on an object as a function of time.
    Tiếng Việt

    Mục tiêu học tập 6.3.A: Mô tả động lượng góc của một vật thể hoặc hệ cứng.

    • 6.3.A.1 Độ lớn của động lượng góc của một hệ cứng quanh một trục xác định có thể được mô tả bằng phương trình $L = I\omega$.
      • Phương trình: $L = I\omega$
    • 6.3.A.2 Động lượng góc của một vật đối với một điểm cho trước là $\vec{L} = \vec{r} \times \vec{p}$.
      • Phương trình: $\vec{L} = \vec{r} \times \vec{p}$
      • 6.3.A.2.i Việc lựa chọn trục mà vật thể được xem xét quay sẽ ảnh hưởng đến việc xác định động lượng góc của vật thể đó.
      • 6.3.A.2.ii Động lượng góc đo được của một vật thể di chuyển theo đường thẳng phụ thuộc vào khoảng cách giữa điểm tham chiếu và vật thể, khối lượng của vật thể, tốc độ của vật thể, và góc giữa bán kính (khoảng cách radial) và vận tốc của vật thể.

    Mục tiêu học tập 6.3.B: Mô tả xung động lượng góc được cung cấp cho một vật thể hoặc hệ cứng bởi một mô-men lực.

    • 6.3.B.1 Xung động lượng góc được định nghĩa là tích của mô-men lực tác dụng lên một vật thể hoặc hệ cứng và khoảng thời gian mà mô-men lực đó tác dụng.
      • Phương trình: $\text{angular impulse} = \displaystyle\int \tau \, dt$
    • 6.3.B.2 Xung động lượng góc có cùng hướng với momen lực tạo ra nó.
    • 6.3.B.3 Xung động lượng góc được cung cấp cho một vật thể hoặc hệ cứng bởi một mô-men lực có thể tìm được từ diện tích dưới đường cong của đồ thị mô-men lực theo thời gian.

    Mục tiêu học tập 6.3.C: Liên hệ sự thay đổi động lượng góc của một vật thể hoặc hệ cứng với xung động lượng góc được cung cấp cho vật thể hoặc hệ đó.

    • 6.3.C.1 Độ lớn của sự thay đổi động lượng góc có thể được mô tả bằng cách so sánh độ lớn của động lượng cuối cùng và đầu tiên của vật hoặc hệ vật rắn.
      • Phương trình: $\Delta L = L - L_0$
    • 6.3.C.2 Dạng quay của định lý xung – động lượng liên hệ giữa xung động lượng góc được cung cấp cho một vật thể hoặc hệ cứng và sự thay đổi động lượng góc của vật thể hoặc hệ đó.
      • 6.3.C.2.i Xung động lượng góc tác dụng lên một vật thể hoặc hệ cứng bằng sự thay đổi động lượng góc của vật thể hoặc hệ đó.
        • Phương trình: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
      • 6.3.C.2.ii Dạng quay của định lý xung-động lượng là kết quả trực tiếp của định luật II Newton về chuyển động trong các trường hợp momen quán tính không đổi.
        • Phương trình: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
    • 6.3.C.3 Momen lực tổng hợp tác dụng lên một vật hoặc hệ vật rắn bằng với hệ số góc của biểu đồ động lượng góc của vật theo thời gian.
    • 6.3.C.4 Xung động lượng góc truyền cho một vật hoặc hệ vật rắn bằng với diện tích dưới đường cong của biểu đồ momen lực ngoài tổng hợp tác dụng lên vật theo thời gian.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English

    Angular momentum 角动量 for a particle is

    $$\vec{L}=\vec{r}\times\vec{p},\qquad |L|=mvr\sin\theta,$$

    so even a particle moving in a straight line has angular momentum about any point not on that line ($L=mv\,d$, with $d$ the perpendicular distance). For a rigid body spinning about a fixed axis, $L=I\omega$. Newton's second law in rotational form is

    $$\vec{\tau}_{\text{net}}=\frac{d\vec{L}}{dt}\quad(=I\alpha\ \text{when }I\text{ is constant}),$$

    and a net torque acting over time delivers an angular impulse 角冲量 $\int\tau\,dt=\Delta L$ – the rotational impulse–momentum theorem.

    Tiếng Việt

    Động lượng góc của một hạt là

    $$\vec{L}=\vec{r}\times\vec{p},\qquad |L|=mvr\sin\theta,$$

    nên ngay cả một hạt chuyển động theo đường thẳng cũng có động lượng góc đối với bất kỳ điểm nào không nằm trên đường thẳng đó ($L=mv\,d$, với $d$ là khoảng cách vuông góc). Đối với vật rắn quay quanh trục cố định, $L=I\omega$. Định luật Newton thứ hai dưới dạng quay là

    $$\vec{\tau}_{\text{net}}=\frac{d\vec{L}}{dt}\quad(=I\alpha\ \text{when }I\text{ is constant}),$$

    và một mô-men lực tổng hợp tác dụng trong thời gian tạo ra xung lượng góc $\int\tau\,dt=\Delta L$ – định lý xung lượng - động lượng góc.

    6.4

    Conservation of Angular Momentum · ⁨Bảo toàn Động lượng Góc⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 6.4.A: Describe the behavior of a system using conservation of angular momentum.

    • 6.4.A.1 The total angular momentum of a system about a rotational axis is the sum of the angular momenta of the system's constituent parts about that rotational axis.
    • 6.4.A.2 Any change to a system's angular momentum must be due to an interaction between the system and its surroundings.
      • 6.4.A.2.i The angular impulse exerted by one object or system on a second object or system is equal and opposite to the angular impulse exerted by the second object or system on the first. This is a direct result of Newton's third law.
      • 6.4.A.2.ii A system may be selected so that the total angular momentum of that system is constant.
      • 6.4.A.2.iii The angular speed of a nonrigid system may change without the angular momentum of the system changing if the system changes shape by moving mass closer to or farther from the rotational axis.
      • 6.4.A.2.iv If the total angular momentum of a system changes, that change will be equivalent to the angular impulse exerted on the system.

    Learning Objective 6.4.B: Describe how the selection of a system determines whether the angular momentum of that system changes.

    • 6.4.B.1 Angular momentum is conserved in all interactions.
    • 6.4.B.2 If the net external torque exerted on a selected object or rigid system is zero, the total angular momentum of that system is constant.
    • 6.4.B.3 If the net external torque exerted on a selected object or rigid system is nonzero, angular momentum is transferred between the system and the environment.
    Tiếng Việt

    Mục tiêu học tập 6.4.A: Mô tả hành vi của một hệ sử dụng bảo toàn động lượng góc.

    • 6.4.A.1 Động lượng góc tổng hợp của một hệ đối với một trục quay là tổng các động lượng góc của các bộ phận cấu thành hệ đối với trục quay đó.
    • 6.4.A.2 Bất kỳ sự thay đổi nào đối với động lượng góc của một hệ đều phải do tương tác giữa hệ và môi trường xung quanh.
      • 6.4.A.2.i Xung động lượng góc mà một vật thể hoặc hệ tác dụng lên vật thể hoặc hệ thứ hai bằng nhau và ngược chiều với xung động lượng góc mà vật thể hoặc hệ thứ hai tác dụng lên vật thể hoặc hệ đầu tiên. Đây là kết quả trực tiếp của định luật III Newton.
      • 6.4.A.2.ii Có thể chọn một hệ sao cho tổng động lượng góc của hệ đó không đổi.
      • 6.4.A.2.iii Tốc độ góc của một hệ không cứng có thể thay đổi mà không làm thay đổi động lượng góc của hệ nếu hệ thay đổi hình dạng bằng cách di chuyển khối lượng lại gần hoặc xa trục quay hơn.
      • 6.4.A.2.iv Nếu tổng động lượng góc của một hệ thay đổi, thì sự thay đổi đó sẽ tương đương với xung động lượng góc tác dụng lên hệ.

    Mục tiêu học tập 6.4.B: Mô tả cách việc lựa chọn hệ xác định liệu động lượng góc của hệ đó có thay đổi hay không.

    • 6.4.B.1 Động lượng góc được bảo toàn trong mọi tương tác.
    • 6.4.B.2 Nếu mô-men lực ngoại tổng hợp tác dụng lên một vật thể hoặc hệ cứng đã chọn bằng không, thì tổng động lượng góc của hệ đó không đổi.
    • 6.4.B.3 Nếu mô-men lực ngoại tổng hợp tác dụng lên một vật thể hoặc hệ cứng đã chọn khác không, động lượng góc sẽ được truyền giữa hệ và môi trường.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English
    Angular momentum: pull in, spin faster

    With zero net external torque, total angular momentum is conserved 守恒:

    $$L_{\text{before}}=L_{\text{after}},\qquad I_1\omega_1=I_2\omega_2\ \text{(one rigid body reshaping)}.$$

    If $I$ shrinks, $\omega$ grows – a spinning skater speeds up pulling her arms in. The rule survives collisions and shape changes, which is what makes it so useful: pick the axis so that every external force (gravity, the pivot force) exerts no torque about it.

    Worked example. A skater spins at $2.0\ \text{rev/s}$ with $I_1=4.0\ \text{kg}\cdot\text{m}^2$. Pulling in her arms drops it to $I_2=1.6\ \text{kg}\cdot\text{m}^2$: $\omega_2=\dfrac{4.0}{1.6}(2.0)=5.0\ \text{rev/s}$. Her kinetic energy rises – the extra energy is the work her muscles do pulling her arms inward.

    Worked example (rotational collision). A $0.020\ \text{kg}$ bullet at $300\ \text{m/s}$ strikes the tip of a uniform rod ($M=1.5\ \text{kg}$, length $l=0.60\ \text{m}$) hanging from a pivot, and embeds. About the pivot, gravity and the pivot force exert no torque during the strike, so $L$ is conserved: $L=mvl=0.020(300)(0.60)=3.6\ \text{kg}\cdot\text{m}^2/\text{s}$. Afterwards $I=\tfrac13Ml^2+ml^2=0.18+0.0072=0.187\ \text{kg}\cdot\text{m}^2$, so $\omega=\dfrac{3.6}{0.187}\approx19\ \text{rad/s}$. (Linear momentum is not conserved here – the pivot pushes on the rod – and kinetic energy certainly is not: check both before claiming them.)

    Tiếng Việt
    Angular momentum: pull in, spin faster

    Với tổng mô-men lực ngoài bằng không, động lượng góc tổng cộng được bảo toàn:

    $$L_{\text{before}}=L_{\text{after}},\qquad I_1\omega_1=I_2\omega_2\ \text{(one rigid body reshaping)}.$$

    Nếu $I$ giảm, $\omega$ tăng – một vận động viên trượt băng quay nhanh hơn khi thu tay vào. Quy tắc này vẫn đúng trong va chạm và thay đổi hình dạng, điều đó khiến nó hữu ích: hãy chọn trục sao cho mọi lực ngoài (trọng lực, lực tại bản lề) không tạo mô-men lực đối với nó.

    Ví dụ minh họa. Một vận động viên trượt băng quay với $2.0\ \text{rev/s}$ và $I_1=4.0\ \text{kg}\cdot\text{m}^2$. Việc thu tay vào làm giảm nó xuống còn $I_2=1.6\ \text{kg}\cdot\text{m}^2$: $\omega_2=\dfrac{4.0}{1.6}(2.0)=5.0\ \text{rev/s}$. Động năng của cô ấy tăng – phần năng lượng dư thừa chính là công mà cơ bắp cô ấy thực hiện để kéo tay vào trong.

    Kéo khối lượng vào trong làm giảm I, nên ω tăng để bảo toàn L = Iω
    Kéo khối lượng vào trong làm giảm I, nên ω tăng để bảo toàn L = Iω
    Angular momentum about the pivot is conserved as the bullet embeds in the rod
    Angular momentum about the pivot is conserved as the bullet embeds in the rod

    Ví dụ minh họa (va chạm quay). Một viên đạn $0.020\ \text{kg}$ với $300\ \text{m/s}$ va chạm vào đầu một thanh đều ($M=1.5\ \text{kg}$, dài $l=0.60\ \text{m}$) treo từ bản lề, và chui vào. Đối với bản lề, trọng lực và lực tại bản hinge không tạo mô-men lực trong lúc va chạm, nên $L$ được bảo toàn: $L=mvl=0.020(300)(0.60)=3.6\ \text{kg}\cdot\text{m}^2/\text{s}$. Sau đó $I=\tfrac13Ml^2+ml^2=0.18+0.0072=0.187\ \text{kg}\cdot\text{m}^2$, vì vậy $\omega=\dfrac{3.6}{0.187}\approx19\ \text{rad/s}$. (Động lượng tuyến tính không được bảo toàn ở đây – bản hinge đẩy lên thanh – và động năng chắc chắn không được bảo toàn: hãy kiểm tra cả hai trước khi khẳng định chúng.)

    Figure skaters performing on the ice
    Figure skating and angular momentum: a skater who pulls their arms in during a spin lowers their rotational inertia, so they spin faster
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    rotational kinetic energy/rəʊˈteɪʃənl kɪˈnetɪk ˈenədʒi/ động năng quay
    rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ mô men quán tính
    torque/tɔːk/ mô-men lực
    angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ góc quay
    Angular momentum/ˈæŋɡjʊlə məʊˈmentəm/ Động lượng góc
    angular impulse/ˈæŋɡjʊlə ˈɪmpʌls/ xung lượng góc
    conserved/kənˈsɜːvd/ bảo toàn
    6.5

    Rolling · ⁨Chuyển động Lăn⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 6.5.A: Describe the kinetic energy of a system that has translational and rotational motion.

    • 6.5.A.1 The total kinetic energy of a system is the sum of the system's translational and rotational kinetic energies.
      • Equation: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$

    Learning Objective 6.5.B: Describe the motion of a system that is rolling without slipping.

    • 6.5.B.1 While rolling without slipping, the translational motion of a system's center of mass is related to the rotational motion of the system itself with the following equations:
      • Equation: $\Delta x_{\text{cm}} = r\Delta\theta$
      • Equation: $v_{\text{cm}} = r\omega$
      • Equation: $a_{\text{cm}} = r\alpha$
    • 6.5.B.2 For ideal cases, rolling without slipping implies that the frictional force does not dissipate any energy from the rolling system.

    Learning Objective 6.5.C: Describe the motion of a system that is rolling while slipping.

    • 6.5.C.1 When slipping, the motion of a system's center of mass and the system's rotational motion cannot be directly related.
    • 6.5.C.2 When a rotating system is slipping relative to another surface, the point of application of the force of kinetic friction exerted on the system moves with respect to the surface, so the force of kinetic friction will dissipate energy from the system.

    Boundary statement: Rolling friction is beyond the scope of AP Physics C: Mechanics.

    Tiếng Việt

    Mục tiêu học tập 6.5.A: Mô tả động năng của một hệ có cả chuyển động tịnh tiến và chuyển động quay.

    • 6.5.A.1 Tổng động năng của một hệ là tổng các động năng tịnh tiến và động năng quay của hệ.
      • Phương trình: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$

    Mục tiêu học tập 6.5.B: Mô tả chuyển động của một hệ đang lăn không trượt.

    • 6.5.B.1 Khi lăn không trượt, chuyển động tịnh tiến của tâm khối lượng của hệ liên quan đến chuyển động quay của chính hệ theo các phương trình sau:
      • Phương trình: $\Delta x_{\text{cm}} = r\Delta\theta$
      • Phương trình: $v_{\text{cm}} = r\omega$
      • Phương trình: $a_{\text{cm}} = r\alpha$
    • 6.5.B.2 Trong trường hợp lý tưởng, lăn không trượt có nghĩa là lực ma sát không làm tiêu tán bất kỳ năng lượng nào từ hệ thống đang lăn.

    Mục tiêu học tập 6.5.C: Mô tả chuyển động của một hệ thống đang lăn có trượt.

    • 6.5.C.1 Khi có trượt, chuyển động của trọng tâm hệ thống và chuyển động quay của hệ thống không thể liên kết trực tiếp với nhau.
    • 6.5.C.2 Khi một hệ thống đang quay trượt so với bề mặt khác, điểm đặt của lực ma sát động tác dụng lên hệ thống di chuyển tương đối với bề mặt, do đó lực ma sát động sẽ làm tiêu tán năng lượng từ hệ thống.

    Khẳng định biên: Ma sát lăn nằm ngoài phạm vi nội dung của AP Physics C: Cơ học.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English
    Rolling without slipping

    Rolling without slipping 无滑滚动 ties translation to rotation: the contact point is momentarily at rest, so

    $$\Delta x_{\text{cm}}=r\,\Delta\theta,\qquad v_{\text{cm}}=r\omega,\qquad a_{\text{cm}}=r\alpha.$$

    Static friction supplies the torque that keeps the spin matched to the motion, but at a point that is not sliding – so for pure rolling, friction does no work, and energy conservation is safe to use. (Rolling friction is beyond the AP course.)

    Racing shapes down an incline shows the energy split. With $I=\beta mr^2$, energy conservation gives

    $$a_{\text{cm}}=\frac{g\sin\theta}{1+\beta}:$$

    a sphere ($\beta=\tfrac25$) beats a disk 圆盘 ($\beta=\tfrac12$), which beats a hoop 圆环 ($\beta=1$) – mass and radius cancel completely. More of the hoop's energy is locked in rotation, so its center moves slower.

    Worked example. A solid sphere rolls from rest down a $30^\circ$ incline: $a=\dfrac{g\sin30^\circ}{1+\tfrac25}=\dfrac{9.8(0.50)}{1.4}=3.5\ \text{m/s}^2$, versus $4.9\ \text{m/s}^2$ for a frictionless slider – rolling objects always lose the race against sliding ones.

    Tiếng Việt
    Rolling without slipping

    Lăn không trượt liên kết chuyển động tịnh tiến với quay: điểm tiếp xúc tạm thời đứng yên, vì vậy

    $$\Delta x_{\text{cm}}=r\,\Delta\theta,\qquad v_{\text{cm}}=r\omega,\qquad a_{\text{cm}}=r\alpha.$$
    Trong lăn không trượt, điểm tiếp xúc đứng yên, nên v = rω
    Trong lăn không trượt, điểm tiếp xúc đứng yên, nên v = rω

    Ma sát tĩnh cung cấp mô-men lực giữ cho sự quay khớp với chuyển động, nhưng tại một điểm không bị trượt – nên đối với lăn thuần túy, ma sát không thực hiện công, và việc sử dụng định luật bảo toàn năng lượng là an toàn. (Ma sát lăn nằm ngoài chương trình AP.)

    Cuộc đua xuống dốc cho thấy sự phân chia năng lượng. Với $I=\beta mr^2$, định luật bảo toàn năng lượng cho

    $$a_{\text{cm}}=\frac{g\sin\theta}{1+\beta}:$$

    một hình cầu ($\beta=\tfrac25$) vượt mặt một hình đĩa ($\beta=\tfrac12$), người chiến thắng trước một vòng tròn ($\beta=1$) – khối lượng và bán kính triệt tiêu hoàn toàn. Nhiều năng lượng hơn của vòng tròn bị khóa trong quay, nên tâm của nó di chuyển chậm hơn.

    Rolling race: the shape with the smallest I/mr² reaches the bottom first
    Rolling race: the shape with the smallest I/mr² reaches the bottom first

    Ví dụ minh họa. Một hình cầu đặc lăn từ trạng thái nghỉ xuống một mặt dốc $30^\circ$: $a=\dfrac{g\sin30^\circ}{1+\tfrac25}=\dfrac{9.8(0.50)}{1.4}=3.5\ \text{m/s}^2$, so với $4.9\ \text{m/s}^2$ cho một vật trượt không ma sát – vật lăn luôn thua cuộc so với vật trượt.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Rolling without slipping/ˈrəʊlɪŋ wɪˈðaʊt ˈslɪpɪŋ/ Lăn không trượt
    disk/dɪsk/ đĩa
    hoop/huːp/ vòng tròn
    centripetal force/senˈtrɪpɪtl fɔːs/ lực lượng hướng tâm
    satellite/ˈsætəlaɪt/ tinh vân
    gravitational potential energy/ˌɡrævɪˈteɪʃənl pəˈtenʃl ˈenədʒi/ khối lượng, g và độ cao thẳng đứng tăng lên
    total mechanical energy/ˈtəʊtl mɪˈkænɪkl ˈenədʒi/ Tổng năng lượng cơ học
    escape velocity/eˈskeɪp vəˈlɒsɪti/ vận tốc thoát ly
    elliptical orbit/ɪˈlɪptɪkl ˈɔːbɪt/ Quỹ đạo elip
    Kepler's second law/ˈkepləz ˈsekənd lɔː/ Định luật Kepler thứ hai
    6.6

    Motion of Orbiting Satellites · ⁨Chuyển động của Vệ tinh Quanh quỹ đạo⁩

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 6.6.A: Describe the motions of a system consisting of two objects or systems interacting only via gravitational forces.

    • 6.6.A.1 In a system consisting only of a massive central object and an orbiting satellite with mass that is negligible in comparison to the central object's mass, the motion of the central object itself is negligible.
    • 6.6.A.2 The motion of satellites in orbits is constrained by conservation laws.
      • 6.6.A.2.i In circular orbits, the system's total mechanical energy, the system's gravitational potential energy, and the satellite's angular momentum and kinetic energy are constant.
      • 6.6.A.2.ii In elliptical orbits, the system's total mechanical energy and the satellite's angular momentum are constant, but the system's gravitational potential energy and the satellite's kinetic energy can each change.
      • 6.6.A.2.iii The gravitational potential energy of a system consisting of a satellite and a massive central object is defined to be zero when the satellite is an infinite distance from the central object.
        • Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
    • 6.6.A.3 The total energy of a system consisting of a satellite orbiting a central object in a circular path can be written in terms of the gravitational potential energy of that system or the kinetic energy of the satellite.
      • Equation: $K = -\dfrac{1}{2}U$
      • Equation: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
    • 6.6.A.4 The escape velocity of a satellite is the satellite's velocity such that the mechanical energy of the satellite–central-object system is equal to zero.
      • 6.6.A.4.i When the only force exerted on a satellite is gravity from a central object, a satellite that reaches escape velocity will move away from the central body until its speed reaches zero at an infinite distance from the central body.
      • 6.6.A.4.ii The escape velocity of a satellite from a central body of mass $M$ can be derived using conservation of energy laws.
        • Equation: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$
    Tiếng Việt

    Mục tiêu học tập 6.6.A: Mô tả chuyển động của một hệ gồm hai vật thể hoặc hệ tương tác chỉ thông qua lực hấp dẫn.

    • 6.6.A.1 Trong hệ thống chỉ bao gồm một vật trung tâm mass lớn và một vệ tinh có khối lượng bỏ so với khối lượng của vật trung tâm, bản thân chuyển động của vật trung tâm là không đáng kể.
    • 6.6.A.2 Chuyển động của các vệ tinh trong quỹ đạo bị ràng buộc bởi các định luật bảo toàn.
      • 6.6.A.2.i Trong các quỹ đạo tròn, tổng năng lượng cơ học của hệ thống, thế năng hấp dẫn của hệ thống, động lượng góc và động năng của vệ tinh đều không đổi.
      • 6.6.A.2.ii Trong các quỹ đạo elip, tổng năng lượng cơ học của hệ thống và động lượng góc của vệ tinh không đổi, nhưng thế năng hấp dẫn của hệ thống và động năng của vệ tinh có thể thay đổi.
      • 6.6.A.2.iii Thế năng hấp dẫn của hệ thống gồm một vệ tinh và một vật trung tâm mass lớn được quy ước bằng 0 khi vệ tinh ở vô cùng xa vật trung tâm.
        • Phương trình: $U_g = -G\dfrac{m_1 m_2}{r}$
    • 6.6.A.3 Năng lượng toàn phần của một hệ gồm vệ tinh đang quay quanh một vật trung tâm theo quỹ đạo tròn có thể được viết dưới dạng thế năng hấp dẫn của hệ đó hoặc động năng của vệ tinh.
      • Phương trình: $K = -\dfrac{1}{2}U$
      • Phương trình: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
    • 6.6.A.4 Vận tốc thoát ly của vệ tinh là vận tốc sao cho cơ năng của hệ vệ tinh–vật trung tâm bằng không.
      • 6.6.A.4.i Khi lực duy nhất tác dụng lên vệ tinh là lực hấp dẫn từ một vật trung tâm, một vệ tinh đạt vận tốc thoát ly sẽ di chuyển ra xa vật trung tâm cho đến khi tốc độ của nó đạt zero ở khoảng vô cùng từ vật trung tâm.
      • 6.6.A.4.ii Vận tốc thoát ly của một vệ tinh khỏi một vật trung tâm có khối lượng $M$ có thể được suy ra bằng các định luật bảo toàn năng lượng.
        • Phương trình: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    English
    Orbital motion (Kepler's 2nd law)

    Gravity supplies the centripetal force 向心力 for a satellite 卫星 in a circular orbit:

    $$\frac{GMm}{r^2}=\frac{mv^2}{r}\quad\Rightarrow\quad v=\sqrt{\frac{GM}{r}}$$

    – larger orbits are slower. With gravitational potential energy 引力势能 $U_g=-\dfrac{GMm}{r}$, a circular orbit obeys $K=-\tfrac12U$, so the total mechanical energy 总机械能 is

    $$E=K+U=\frac{U}{2}=-\frac{GMm}{2r},$$

    negative because the satellite is bound. To escape from radius $r$, total energy must reach zero, giving the escape velocity 逃逸速度

    $$v_{\text{esc}}=\sqrt{\frac{2GM}{r}}.$$

    In an elliptical orbit 椭圆轨道, $E$ and $L$ are fixed: gravity points at the focus, so it exerts no torque about it. Conserved $L$ means the satellite sweeps equal areas in equal times – Kepler's second law 开普勒第二定律 – and therefore moves fastest at closest approach, slowest at the far point. Energy conservation connects speeds at the two ends.

    Worked example. For a satellite at $r=7.0\times10^{6}\ \text{m}$ around Earth ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$): orbital speed $v=\sqrt{GM/r}=7.6\times10^{3}\ \text{m/s}$, while escaping from that radius needs $v_{\text{esc}}=\sqrt{2GM/r}=1.1\times10^{4}\ \text{m/s}$ – exactly $\sqrt2$ times the circular speed.

    Exam skill. Orbit FRQs are energy-and-angular-momentum problems in disguise: write $E=\tfrac12mv^2-\dfrac{GMm}{r}$ and $L=mvr\sin\theta$ at the two points of interest and solve the pair – never assume the orbit formulae for circles apply to an ellipse.

    Tiếng Việt
    Chuyển động quỹ đạo (Định luật 2 Kepler)

    Trọng lực cung cấp lực hướng tâm cho một tinh vân trong quỹ đạo tròn:

    $$\frac{GMm}{r^2}=\frac{mv^2}{r}\quad\Rightarrow\quad v=\sqrt{\frac{GM}{r}}$$

    – quỹ đạo lớn hơn thì chậm hơn. Với thế năng hấp dẫn $U_g=-\dfrac{GMm}{r}$, một quỹ đạo tròn tuân theo $K=-\tfrac12U$, vì vậy tổng năng lượng cơ học là

    $$E=K+U=\frac{U}{2}=-\frac{GMm}{2r},$$

    âm vì tinh vân bị ràng buộc. Để thoát khỏi bán kính $r$, tổng năng lượng phải đạt đến không, dẫn đến vận tốc thoát ly

    $$v_{\text{esc}}=\sqrt{\frac{2GM}{r}}.$$
    Trọng lực tạo ra lực hướng tâm giữ vệ tinh trên quỹ đạo
    Trọng lực cung cấp lực hướng tâm giữ vệ tinh trong quỹ đạo

    Trong quỹ đạo elip, $E$ và $L$ là cố định: trọng lực chỉ vào tiêu điểm, nên nó không tạo mô-men lực đối với tiêu điểm đó. Động lượng góc được bảo toàn $L$ có nghĩa là tinh vân quét diện tích bằng nhau trong khoảng thời gian bằng nhau – Định luật thứ hai của Kepler – và do đó di chuyển nhanh nhất ở điểm gần nhất, chậm nhất ở điểm xa nhất. Định luật bảo toàn năng lượng liên kết vận tốc ở hai đầu.

    Ví dụ minh họa. Đối với một tinh vân ở $r=7.0\times10^{6}\ \text{m}$ quanh Trái Đất ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$): vận tốc quỹ đạo $v=\sqrt{GM/r}=7.6\times10^{3}\ \text{m/s}$, trong khi thoát ra khỏi bán kính đó cần $v_{\text{esc}}=\sqrt{2GM/r}=1.1\times10^{4}\ \text{m/s}$ – đúng bằng $\sqrt2$ lần vận tốc tròn.

    Kỹ năng làm bài thi. Các câu hỏi FRQ về quỹ đạo thực chất là bài toán năng lượng và động lượng góc: hãy viết $E=\tfrac12mv^2-\dfrac{GMm}{r}$ và $L=mvr\sin\theta$ tại hai điểm cần xét rồi giải hệ phương trình – tuyệt đối không được giả sử các công thức quỹ đạo tròn áp dụng cho hình elip.

    Explore · ⁨Khám phá⁩

    Compare orbits at different radii · ⁨So sánh quỹ đạo ở bán kính khác nhau⁩

    An orbiting satellite is in free fall, gravity supplying the centripetal force. A larger orbit means a slower speed and longer period (Kepler's third law). · ⁨Vệ tinh đang quay là đang rơi tự do, trọng lực cung cấp lực hướng tâm. Quỹ đạo lớn hơn nghĩa là tốc độ chậm hơn và chu kỳ dài hơn (định luật Kepler thứ ba).⁩

    6.6

    Exam tips · ⁨Mẹo làm bài thi⁩

    English
    • Compute the moment of inertia $I=\int r^2\,dm$ and shift axes with the parallel-axis theorem $I=I_{cm}+Md^2$.
    • Rotational kinetic energy is $\tfrac12 I\omega^2$; a rolling body has both translational and rotational KE.
    • Conserve angular momentum $L=I\omega$ when net external torque is zero (a spinning skater pulling in).
    • Use energy conservation for rolling-without-slipping problems ($v=r\omega$ ties the two motions).
    • Know standard $I$ values (hoop, disk, rod, sphere) and where the axis is.
    Tiếng Việt
    • Tính mô men quán tính $I=\int r^2\,dm$ và dịch trục tọa độ bằng định lý trục song song $I=I_{cm}+Md^2$.
    • Động năng quay là $\tfrac12 I\omega^2$; một vật lăn vừa có động năng chuyển động tịnh tiến vừa có động năng quay.
    • Bảo toàn động lượng góc $L=I\omega$ khi mô-men lực ngoài tổng hợp bằng không (ví dụ: vận động viên trượt băng kéo tay vào thân).
    • Sử dụng định luật bảo toàn năng lượng cho bài toán lăn không trượt ($v=r\omega$ liên kết hai chuyển động này).
    • Nhớ các giá trị chuẩn $I$ của các vật thể (vòng tròn, đĩa, thanh, quả cầu) và vị trí trục quay tương ứng.
  • 7

    Oscillations · ⁨Dao động⁩

    Watch lesson · ⁨Xem bài học⁩
    7.1

    Defining Simple Harmonic Motion

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 7.1.A: Describe simple harmonic motion.

    • 7.1.A.1 Simple harmonic motion is a special case of periodic motion.
    • 7.1.A.2 SHM results when the magnitude of the restoring force exerted on an object is proportional to that object's displacement from its equilibrium position.
      • Derived equation: $ma_x = -k\Delta x$
      • 7.1.A.2.i A restoring force is a force that is exerted in a direction opposite to the object's displacement from an equilibrium position.
      • 7.1.A.2.ii An equilibrium position is a location at which the net force exerted on an object or system is zero.
    Tiếng Việt

    Mục tiêu học tập 7.1.A: Mô tả chuyển động điều hòa đơn.

    • 7.1.A.1 Chuyển động điều hòa đơn là một trường hợp đặc biệt của chuyển động chu kỳ.
    • 7.1.A.2 SHM xảy ra khi độ lớn của lực hồi phục tác dụng lên vật tỷ lệ thuận với độ dịch chuyển của vật đó khỏi vị trí cân bằng.
      • Phương trình suy ra: $ma_x = -k\Delta x$
      • 7.1.A.2.i Lực hồi phục là lực tác dụng theo hướng ngược lại với độ dịch chuyển của vật khỏi vị trí cân bằng.
      • 7.1.A.2.ii Vị trí cân bằng là vị trí mà tổng lực tác dụng lên vật hoặc hệ thống bằng 0.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Simple harmonic motion

    Simple harmonic motion 简谐运动 (SHM) is a special case of periodic motion 周期运动. It appears whenever two things are true: there is an equilibrium 平衡位置 position where the net force is zero, and displacing the object produces a restoring force 回复力 – a force pointing back toward equilibrium – whose magnitude is proportional to the displacement:

    $$F=-k\,\Delta x.$$

    Newton's second law then gives the defining differential equation 微分方程:

    $$\frac{d^2x}{dt^2}=-\frac{k}{m}\,x=-\omega^2 x,\qquad \omega=\sqrt{\frac{k}{m}}.$$

    Its solution is sinusoidal, $x(t)=A\cos(\omega t+\phi)$. You do not need to prove this solution – you need to recognise the equation: any system whose motion obeys "$\ddot{x}=-\omega^2x$" is a simple harmonic oscillator, whatever it is made of. (A mass hanging on a vertical spring works the same way: gravity only shifts the equilibrium point; the oscillation about it is unchanged.)

    In SHM the acceleration always points back towards equilibrium, opposite the displacement
    In SHM the acceleration always points back towards equilibrium, opposite the displacement
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    Simple harmonic motion/ˈsɪmpl hɑːˈmɒnɪk ˈməʊʃn/ Chuyển động điều hòa
    periodic motion/ˌpɪərɪˈɒdɪk ˈməʊʃn/ Chuyển động chu kỳ
    equilibrium/ˌiːkwɪˈlɪbrɪəm/ cân bằng
    restoring force/rɪˈstɔːrɪŋ fɔːs/ lực phục hồi
    differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ phương trình vi phân
    7.2

    Frequency and Period of SHM

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 7.2.A: Describe the frequency and period of an object exhibiting SHM.

    • 7.2.A.1 The period of SHM is related to the angular frequency, $\omega$, of the object's motion by the following equation:
      • Equation: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
      • 7.2.A.1.i The period of an object–ideal-spring oscillator is given by the equation
        • Equation: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
      • 7.2.A.1.ii The period of a simple pendulum displaced by a small angle is given by the equation
        • Equation: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$
    Tiếng Việt

    Mục tiêu học tập 7.2.A: Mô tả tần số và chu kỳ của vật thực hiện SHM.

    • 7.2.A.1 Chu kỳ của dao động điều hòa (SHM) liên quan đến tần số góc, $\omega$, của chuyển động vật thể qua phương trình sau:
      • Phương trình: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
      • 7.2.A.1.i Chu kỳ của bộ dao động vật–lò xo lý tưởng được cho bởi phương trình
        • Phương trình: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
      • 7.2.A.1.ii Chu kỳ của con lắc đơn bị lệch một góc nhỏ được cho bởi phương trình
        • Phương trình: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    The angular frequency 角频率 $\omega$ sets the period 周期 and frequency 频率:

    $$T=\frac{2\pi}{\omega}=\frac{1}{f}.$$

    For the two standard systems:

    $$T_{\text{spring}}=2\pi\sqrt{\frac{m}{k}},\qquad T_{\text{pendulum}}=2\pi\sqrt{\frac{\ell}{g}}.$$

    Two classic conceptual traps: the period of SHM never depends on the amplitude 振幅, and each system ignores one obvious variable – the pendulum's period does not involve its mass, and the spring's period does not involve $g$ (a spring–block oscillator keeps perfect time in orbit; a pendulum clock does not).

    Explore · ⁨Khám phá⁩

    Time a pendulum's swing · ⁨Đo thời gian dao động của con lắc⁩

    A pendulum's period depends on its length and gravity, not its mass or (small) amplitude: $T=2\pi\sqrt{L/g}$. Lengthen it and each swing takes longer. · ⁨Chu kỳ của con lắc phụ thuộc vào chiều dài và gia tốc trọng trường, không phụ thuộc vào khối lượng hay (biên nhỏ): $T=2\pi\sqrt{L/g}$. Kéo dài chiều dài thì mỗi lần dao động mất nhiều thời gian hơn.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    angular frequency/ˈæŋɡjʊlə ˈfriːkwənsi/ tần số góc
    period/ˈpɪərɪəd/ chu kỳ
    frequency/ˈfriːkwənsi/ tần số
    amplitude/ˈæmplɪtjuːd/ biên
    7.3

    Representing and Analyzing SHM

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 7.3.A: Describe the displacement, velocity, and acceleration of an object exhibiting SHM.

    • 7.3.A.1 For an object exhibiting SHM, the displacement of that object measured from its equilibrium position can be represented by the equations $x = A\cos(2\pi ft)$ or $x = A\sin(2\pi ft)$.
      • 7.3.A.1.i Minima, maxima, and zeros of displacement, velocity, and acceleration are features of harmonic motion.
      • 7.3.A.1.ii Recognizing the positions or times at which the displacement, velocity, and acceleration for SHM have extrema or zeros can help in qualitatively describing the behavior of the motion.
    • 7.3.A.2 The position as a function of time for an object exhibiting SHM is a solution of the second-order differential equation derived from the application of Newton's second law.
      • Derived equation: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
    • 7.3.A.3 Characteristics of SHM, such as velocity and acceleration, can be determined by or derived from the equation $x = A\cos(\omega t + \phi).$
      • 7.3.A.3.i The acceleration of an object exhibiting SHM is related to the object's angular frequency and position.
        • Derived equation: $a = -\omega^2 x$
      • 7.3.A.3.ii It can be shown that the maximum velocity and acceleration of an object exhibiting SHM are related to the angular frequency of the object's motion.
        • Derived equations: $v_{\max} = A\omega$
        • $a_{\max} = A\omega^2$
    • 7.3.A.4 In the presence of a sinusoidal external force, a system may exhibit resonance.
      • 7.3.A.4.i Resonance occurs when an external force is exerted at the natural frequency of an oscillating system.
      • 7.3.A.4.ii Resonance increases the amplitude of oscillating motion.
      • 7.3.A.4.iii The natural frequency of a system is the frequency at which the system will oscillate when it is displaced from its equilibrium position.
    • 7.3.A.5 Changing the amplitude of a system exhibiting SHM will not change its period.
    • 7.3.A.6 Properties of SHM can be determined and analyzed using graphical representations.

    Boundary statement: AP Physics C: Mechanics only expects students to know the solution to the second-order differential equation that describes SHM, as well as be able to identify SHM. AP Physics C: Mechanics does not expect students to mathematically prove that the solution is correct.

    Tiếng Việt

    Mục tiêu học tập 7.3.A: Mô tả độ dịch chuyển, vận tốc và gia tốc của vật thực hiện SHM.

    • 7.3.A.1 Đối với vật thực hiện SHM, độ dịch chuyển của vật đo từ vị trí cân bằng có thể được biểu diễn bằng các phương trình $x = A\cos(2\pi ft)$ hoặc $x = A\sin(2\pi ft)$.
      • 7.3.A.1.i Các điểm cực tiểu, cực đại và bằng không của độ dịch chuyển, vận tốc và gia tốc là những đặc trưng của dao động điều hòa.
      • 7.3.A.1.ii Việc xác định các vị trí hoặc thời điểm mà độ dịch chuyển, vận tốc và gia tốc trong dao động điều hòa đạt giá trị cực đại hoặc bằng không có thể giúp mô tả định tính hành vi của chuyển động.
    • 7.3.A.2 Vị trí theo thời gian của một vật thể thực hiện SHM là nghiệm của phương trình vi phân bậc hai được suy ra từ việc áp dụng định luật thứ hai của Newton.
      • Phương trình suy ra: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
    • 7.3.A.3 Các đặc tính của SHM, như vận tốc và gia tốc, có thể được xác định hoặc suy ra từ phương trình $x = A\cos(\omega t + \phi).$
      • 7.3.A.3.i Gia tốc của một vật thể thực hiện SHM liên quan đến tần số góc và vị trí của vật.
        • Phương trình suy ra: $a = -\omega^2 x$
      • 7.3.A.3.ii Có thể chứng minh rằng vận tốc cực đại và gia tốc cực đại của một vật thể thực hiện SHM liên quan đến tần số góc của chuyển động vật.
        • Phương trình suy ra: $v_{\max} = A\omega$
        • $a_{\max} = A\omega^2$
    • 7.3.A.4 Trong sự tồn tại của ngoại lực điều hòa, một hệ có thể biểu hiện cộng hưởng.
      • 7.3.A.4.i Cộng hưởng xảy ra khi ngoại lực được tác dụng ở tần số tự nhiên của một hệ dao động.
      • 7.3.A.4.ii Cộng hưởng làm tăng biên độ của chuyển động dao động.
      • 7.3.A.4.iii Tần số tự nhiên của một hệ là tần số mà hệ sẽ dao động khi bị dịch chuyển khỏi vị trí cân bằng.
    • 7.3.A.5 Thay đổi biên độ của một hệ thực hiện SHM sẽ không làm thay đổi chu kỳ của nó.
    • 7.3.A.6 Các tính chất của SHM có thể được xác định và phân tích sử dụng các biểu diễn đồ thị.

    Khẳng định biên: AP Physics C: Cơ học chỉ yêu cầu học sinh biết nghiệm của phương trình vi phân bậc hai mô tả SHM, cũng như có khả năng nhận diện SHM. AP Physics C: Cơ học không yêu cầu học sinh chứng minh bằng toán học rằng nghiệm đó là đúng.

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Differentiate $x(t)=A\cos(\omega t+\phi)$ twice:

    $$v=-A\omega\sin(\omega t+\phi),\qquad a=-A\omega^2\cos(\omega t+\phi)=-\omega^2x.$$

    So at the ends of the swing ($x=\pm A$) the speed is zero and the acceleration is largest; passing through equilibrium ($x=0$) the acceleration is zero and the speed is largest, $v_{\max}=A\omega$. The amplitude $A$ and the phase constant 相位常数 $\phi$ come from the initial conditions: where the object starts and how fast it is moving. Eliminating $t$ (or using energy, below) gives speed as a function of position:

    $$v=\pm\,\omega\sqrt{A^2-x^2}.$$
    Displacement varies sinusoidally with time in simple harmonic motion
    Displacement varies sinusoidally with time in simple harmonic motion

    Worked example. A $0.50\ \text{kg}$ mass on a $k=200\ \text{N/m}$ spring: $\omega=\sqrt{k/m}=20\ \text{rad/s}$, $T=2\pi/\omega=0.31\ \text{s}$. With $A=0.10\ \text{m}$: $v_{\max}=A\omega=2.0\ \text{m/s}$ at equilibrium, and at $x=0.050\ \text{m}$ the speed is $v=\omega\sqrt{A^2-x^2}=20\sqrt{0.10^2-0.050^2}=1.7\ \text{m/s}$.

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    phase constant/feɪz ˈkɒnstənt/ Hằng số pha
    7.4

    Energy of Simple Harmonic Oscillators

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 7.4.A: Describe the mechanical energy of a system exhibiting SHM.

    • 7.4.A.1 The total energy of a system exhibiting SHM is the sum of the system's kinetic and potential energies.
      • Relevant equation: $E_{\text{total}} = U + K$
    • 7.4.A.2 Conservation of energy indicates that the total energy of a system exhibiting SHM is constant.
    • 7.4.A.3 The kinetic energy of a system exhibiting SHM is at a maximum when the system's potential energy is at a minimum.
    • 7.4.A.4 The potential energy of a system exhibiting SHM is at a maximum when the system's kinetic energy is at a minimum.
      • 7.4.A.4.i The minimum kinetic energy of a system exhibiting SHM is zero.
      • 7.4.A.4.ii Changing the amplitude of a system exhibiting SHM will change the maximum potential energy of the system and, therefore, the total energy of the system.
        • Relevant equation for a spring–object system: $E_{\text{total}} = \dfrac{1}{2}kA^2$
    Tiếng Việt

    Mục tiêu học tập 7.4.A: Mô tả năng lượng cơ học của hệ thống thực hiện SHM.

    • 7.4.A.1 Tổng năng lượng của hệ thống thực hiện SHM là tổng của động năng và thế năng của hệ thống.
      • Phương trình liên quan: $E_{\text{total}} = U + K$
    • 7.4.A.2 Định luật bảo toàn năng lượng chỉ ra rằng tổng năng lượng của hệ thống thực hiện SHM là không đổi.
    • 7.4.A.3 Động năng của hệ thống thực hiện SHM đạt cực đại khi thế năng của hệ thống đạt cực tiểu.
    • 7.4.A.4 Thế năng của một hệ thực hiện dao động điều hòa đạt cực đại khi động năng của hệ đạt cực tiểu.
      • 7.4.A.4.i Động năng cực tiểu của một hệ thực hiện dao động điều hòa bằng không.
      • 7.4.A.4.ii Thay đổi biên độ của một hệ thực hiện dao động điều hòa sẽ làm thay đổi thế năng cực đại của hệ, và do đó làm thay đổi tổng năng lượng của hệ.
        • Phương trình liên quan cho hệ lò xo–vật: $E_{\text{total}} = \dfrac{1}{2}kA^2$

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    The total energy of the oscillator is the sum $E=U+K$, and with no friction it is constant – energy just trades back and forth between the spring's potential energy and the mass's kinetic energy:

    $$E=\tfrac12kA^2=\tfrac12kx^2+\tfrac12mv^2.$$

    All potential at the ends (where $K=0$), all kinetic at equilibrium (where $U$ is minimum). Because $E\propto A^2$, doubling the amplitude quadruples the energy.

    Kinetic and potential energy swap over a cycle while the total energy stays constant
    Kinetic and potential energy swap over a cycle while the total energy stays constant

    Worked example. Where is the energy split evenly? Set $\tfrac12kx^2=\tfrac12E=\tfrac14kA^2$, so $x=A/\sqrt2\approx0.71A$ – much closer to the end than to the middle. For the system above ($A=0.10\ \text{m}$): $x=0.071\ \text{m}$.

    Left alone, a system oscillates at its own natural frequency 固有频率 (set by $k$ and $m$: $f_0=\frac{1}{2\pi}\sqrt{k/m}$). Drive it with a periodic force at that same frequency and the amplitude grows dramatically – resonance 共振. Each well-timed push adds energy faster than damping removes it, so the driven amplitude peaks sharply when the driving frequency matches $f_0$ (a swing pumped in time, a bridge shaken by wind).

    Explore · ⁨Khám phá⁩

    Trade kinetic and potential energy in SHM · ⁨Trao đổi động năng và thế năng trong dao động điều hòa⁩

    In simple harmonic motion, energy sloshes between kinetic (fastest at the centre) and potential (greatest at the extremes) while the total stays constant. · ⁨Trong dao động điều hòa, năng lượng dao động qua lại giữa động năng (nhanh nhất tại tâm) và thế năng (lớn nhất tại biên) trong khi tổng năng lượng không đổi.⁩

    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    natural frequency/ˈnætʃərəl ˈfriːkwənsi/ tần số tự nhiên
    resonance/ˈrezənəns/ cộng hưởng
    7.5

    Simple and Physical Pendulums

    Syllabus · ⁨Chương trình⁩
    English

    Learning Objective 7.5.A: Describe the properties of a physical pendulum.

    • 7.5.A.1 A physical pendulum is a rigid body that undergoes oscillation about a fixed axis.
    • 7.5.A.2 For small amplitudes of motion, the period of a physical pendulum is derived from the application of Newton's second law in rotational form.
      • Relevant equation: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
      • 7.5.A.2.i When displaced from equilibrium, the gravitational force exerted on a physical pendulum's center of mass provides a restoring torque.
        • Derived equation: $\tau = -mgd\sin\theta$
      • 7.5.A.2.ii For small amplitudes of motion, the small-angle approximation can be applied to the restoring torque.
        • Derived equation: $\sin\theta \approx \theta$
        • $\tau = -mgd\theta = I\alpha$
      • 7.5.A.2.iii The small-angle approximation and Newton's second law in rotational form yield a second-order differential equation that describes SHM:
        • Equation: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
    • 7.5.A.3 A simple pendulum is a special case of physical pendulums in which the hanging object can be modeled as a point mass at a distance, $l$, from the pivot point.
      • Relevant equation: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
    • 7.5.A.4 A torsion pendulum is a case of SHM where the restoring torque is proportional to the angular displacement of a rotating system. For example, a horizontal disk that is suspended from a wire attached to its center of mass may undergo rotational oscillations about the wire in the horizontal plane.
      • Derived equation: $I\alpha = -k\Delta\theta$
    Tiếng Việt

    Mục tiêu học tập 7.5.A: Mô tả các tính chất của con lắc vật lý.

    • 7.5.A.1 Con lắc vật lý là một vật cứng thực hiện dao động quanh một trục cố định.
    • 7.5.A.2 Đối với biên độ chuyển động nhỏ, chu kỳ của con lắc vật lý được suy ra từ việc áp dụng định luật thứ hai của Newton dưới dạng quay.
      • Phương trình liên quan: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
      • 7.5.A.2.i Khi bị lệch khỏi vị trí cân bằng, lực hấp dẫn tác dụng lên tâm khối lượng của con lắc vật lý tạo ra một mô-men hồi phục.
        • Phương trình suy ra: $\tau = -mgd\sin\theta$
      • 7.5.A.2.ii Đối với biên độ chuyển động nhỏ, xấp xỉ góc nhỏ có thể được áp dụng cho mô-men hồi phục.
        • Phương trình suy ra: $\sin\theta \approx \theta$
        • $\tau = -mgd\theta = I\alpha$
      • 7.5.A.2.iii Xấp xỉ góc nhỏ và định luật thứ hai của Newton dưới dạng quay tạo ra một phương trình vi phân bậc hai mô tả SHM:
        • Phương trình: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
    • 7.5.A.3 Con lắc đơn là trường hợp đặc biệt của các con lắc vật lý trong đó vật treo có thể được mô hình hóa như một điểm mass ở khoảng cách, $l$, từ điểm treo.
      • Phương trình liên quan: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
    • 7.5.A.4 Con lắc xoắn là một trường hợp SHM trong đó mô-men hồi phục tỷ lệ với độ lệch góc của một hệ quay. Ví dụ, một đĩa nằm ngang được treo từ một sợi dây gắn vào tâm khối lượng của nó có thể thực hiện dao động quay quanh sợi dây trong mặt phẳng nằm ngang.
      • Phương trình suy ra: $I\alpha = -k\Delta\theta$

    Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

    Energy conservation: KE ⇄ PE

    A physical pendulum 物理摆 is any rigid body swinging about a fixed pivot. Displace it by an angle $\theta$ and gravity, acting at the center of mass a distance $d$ from the pivot, supplies a restoring torque

    $$\tau=-mgd\sin\theta.$$

    For small angles, apply the small-angle approximation 小角度近似 $\sin\theta\approx\theta$ and Newton's second law in rotational form ($\tau=I\alpha$):

    $$\frac{d^2\theta}{dt^2}=-\frac{mgd}{I}\,\theta=-\omega^2\theta\quad\Rightarrow\quad T_{\text{phys}}=2\pi\sqrt{\frac{I}{mgd}}.$$

    This is the same "$\ddot\theta=-\omega^2\theta$" pattern as before – recognising it is the derivation. A simple pendulum 单摆 is the special case of a point mass on a light string: $I=m\ell^2$ and $d=\ell$ give $T=2\pi\sqrt{\ell/g}$.

    Gravity acting at the center of mass provides a physical pendulum's restoring torque
    Gravity acting at the center of mass provides a physical pendulum's restoring torque

    Worked example. A uniform rod (mass $M$, length $L$) swings from one end: $I=\tfrac13ML^2$, $d=\tfrac{L}{2}$, so

    $$T=2\pi\sqrt{\frac{\tfrac13ML^2}{Mg\,\tfrac{L}{2}}}=2\pi\sqrt{\frac{2L}{3g}}$$

    – shorter than a simple pendulum of length $L$, because the rod's mass sits nearer the pivot.

    A torsion pendulum 扭摆 – a disk hanging from a wire that twists – is SHM one more time: the wire's restoring torque is proportional to the twist angle, $I\alpha=-\kappa\,\Delta\theta$, giving $T=2\pi\sqrt{I/\kappa}$.

    Exam skill. Every pendulum FRQ wants the same three steps: write the restoring torque about the pivot, apply the small-angle approximation, and match the result to $\ddot\theta=-\omega^2\theta$ to read off $\omega$. State the small-angle step explicitly – it is a scored point, and it is why large-amplitude swings are not simple harmonic.

    A large Foucault pendulum swinging over a marked floor
    A Foucault pendulum: a long, heavy pendulum whose slow swing reveals the Earth turning beneath it
    Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
    English Tiếng Việt
    physical pendulum/ˈfɪzɪkl ˈpendjʊləm/ con lắc vật lý
    small-angle approximation/smɔːl ˈæŋɡl əˌprɒksɪˈmeɪʃn/ xấp xỉ góc nhỏ
    simple pendulum/ˈsɪmpl ˈpendjʊləm/ con lắc đơn
    torsion pendulum/ˈtɔːʃn ˈpendjʊləm/ Con lắc xoắn
    7.5

    Exam tips

    • Identify SHM from a linear restoring force $F=-kx$, which gives $\tfrac{d^2x}{dt^2}=-\omega^2 x$ with $\omega=\sqrt{k/m}$.
    • Write the solution $x=A\cos(\omega t+\phi)$ and get $v,a$ by differentiating; period $T=\tfrac{2\pi}{\omega}$ is amplitude-independent.
    • Energy trades between $\tfrac12 kx^2$ and $\tfrac12 mv^2$, with total $\tfrac12 kA^2$.
    • For a pendulum, use the small-angle approximation $\sin\theta\approx\theta$ to reach SHM.
    • Match phase to the start: released from rest at maximum displacement uses cosine.

Log in or create account · ⁨Đăng nhập hoặc tạo tài khoản⁩

IGCSE, A-Level & AP