| Learning Objective | Essential Knowledge |
|---|---|
6.1.A |
|
Energy and Momentum of Rotating Systems
AP Physics C: Mechanics · Topic 6
 8:12
Energy and Momentum of Rotating Systems
Watch a figure skater spin. Arms stretched out, she turns slowly. She pulls her arms in — and without pushing off anything, she spins much faster. Nobody…
English narration · English + 中文 subtitles burned in
6.1
Rotational Kinetic Energy
Syllabus
Source: College Board AP Course and Exam Description
In 1967 the astronomer Jocelyn Bell noticed radio pulses arriving every 1.34 seconds, as regular as a clock. They came from a pulsar – a neutron star only about 20 km across, left behind when a massive star collapsed. A star that turned once every few weeks shrank to a ten-thousandth of its radius, and because its angular momentum stayed the same, it now spins about once a second; some pulsars spin more than 700 times a second. This unit extends energy and momentum – the two great conservation laws – to things that rotate.
A spinning body has rotational kinetic energy 转动动能
$$K_{\text{rot}}=\tfrac12 I\omega^2,$$
the rotational twin of $\tfrac12mv^2$, with the rotational inertia 转动惯量 $I$ playing the role of mass. A body that both moves and spins carries both terms:
$$K=\tfrac12 mv_{\text{cm}}^2+\tfrac12 I\omega^2.$$
Worked example. A uniform cylinder ($I=\tfrac12mr^2$) rolls at speed $v$. Its kinetic energy is $K=\tfrac12mv^2+\tfrac12\big(\tfrac12mr^2\big)\big(\tfrac{v}{r}\big)^2=\tfrac34mv^2$ – one third of it is rotational. The same energy bookkeeping decides every rolling problem.
A rigid body can have rotational kinetic energy even when its center of mass is at rest – a spinning flywheel stays in one place, yet every point on it moves and carries kinetic energy. Like all energy, $K_{\text{rot}}$ is a scalar: it has no direction, even though $\omega$ does.
Explore
Rotational kinetic energy
A spinning body's kinetic energy grows with the square of its angular speed.
Vocabulary
Train
| English |
|---|
| rotational kinetic energy/rəʊˈteɪʃənl kɪˈnetɪk ˈenədʒi/ |
| rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ |
6.2
Torque and Work
Syllabus
| Learning Objective | Essential Knowledge |
|---|---|
6.2.A |
|
Source: College Board AP Course and Exam Description
A torque 力矩 acting through an angular displacement 角位移 does work, and power is torque times angular velocity:
$$W=\int_{\theta_1}^{\theta_2}\tau\,d\theta,\qquad P=\tau\omega.$$
These are the rotational forms of $W=\int F\,dx$ and $P=Fv$ – the whole translational energy toolkit carries over with $F\to\tau$, $x\to\theta$, $v\to\omega$.
Work done by a torque is the area under a torque–angle graph, just as work done by a force is the area under a force–position graph.
Worked example (variable torque). A wind-up spring motor exerts a torque that falls steadily from $10\ \text{N·m}$ to zero as it unwinds through one full turn ($2\pi$ rad). The graph is a triangle, so $W=\tfrac12(2\pi)(10)=31$ J.
Worked example. A motor applies a constant $8.0\ \text{N}\cdot\text{m}$ torque to a flywheel for $5.0$ full turns: $W=\tau\,\Delta\theta=8.0(5.0)(2\pi)=250\ \text{J}$, which appears as rotational kinetic energy if friction is negligible.
Explore
Balance torques on a beam
Torque is force times perpendicular distance, $\tau=Fd$. Equal torques on each side keep the beam in rotational equilibrium.
Vocabulary
Train
| English |
|---|
| torque/tɔːk/ |
| angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ |
6.3
Angular Momentum and Angular Impulse
Syllabus
| Learning Objective | Essential Knowledge |
|---|---|
6.3.A |
|
6.3.B |
|
6.3.C |
|
Source: College Board AP Course and Exam Description
Angular momentum 角动量 for a particle is
$$\vec{L}=\vec{r}\times\vec{p},\qquad |L|=mvr\sin\theta,$$
so even a particle moving in a straight line has angular momentum about any point not on that line ($L=mv\,d$, with $d$ the perpendicular distance). For a rigid body spinning about a fixed axis, $L=I\omega$. Newton's second law in rotational form is
$$\vec{\tau}_{\text{net}}=\frac{d\vec{L}}{dt}\quad(=I\alpha\ \text{when }I\text{ is constant}),$$
and a net torque acting over time delivers an angular impulse 角冲量 $\int\tau\,dt=\Delta L$ – the rotational impulse–momentum theorem. Angular impulse points the same way as the torque that delivers it.
The graphs work exactly like their linear versions:
- the area under a torque–time graph is the angular impulse, and so the change in $L$;
- the slope of an angular momentum–time graph is the net torque.
Worked example (angular impulse). A $0.50\ \text{kg·m}^2$ wheel spinning at 12 rad/s is braked by a constant friction torque of $1.5\ \text{N·m}$. The angular impulse needed to stop it is $\Delta L=0-0.50(12)=-6.0$ kg·m²/s, so the time is $\dfrac{6.0}{1.5}=4.0$ s. During this time it turns through $\tfrac12(12)(4.0)=24$ rad, and the brake does $W=-1.5(24)=-36$ J of work – exactly the wheel's starting kinetic energy, $\tfrac12(0.50)(12)^2=36$ J.
Explore
Angular momentum
Angular momentum is rotational inertia times angular speed.
Vocabulary
Train
| English |
|---|
| Angular momentum/ˈæŋɡjʊlə məʊˈmentəm/ |
| angular impulse/ˈæŋɡjʊlə ˈɪmpʌls/ |
6.4
Conservation of Angular Momentum
Syllabus
| Learning Objective | Essential Knowledge |
|---|---|
6.4.A |
|
6.4.B |
|
Source: College Board AP Course and Exam Description
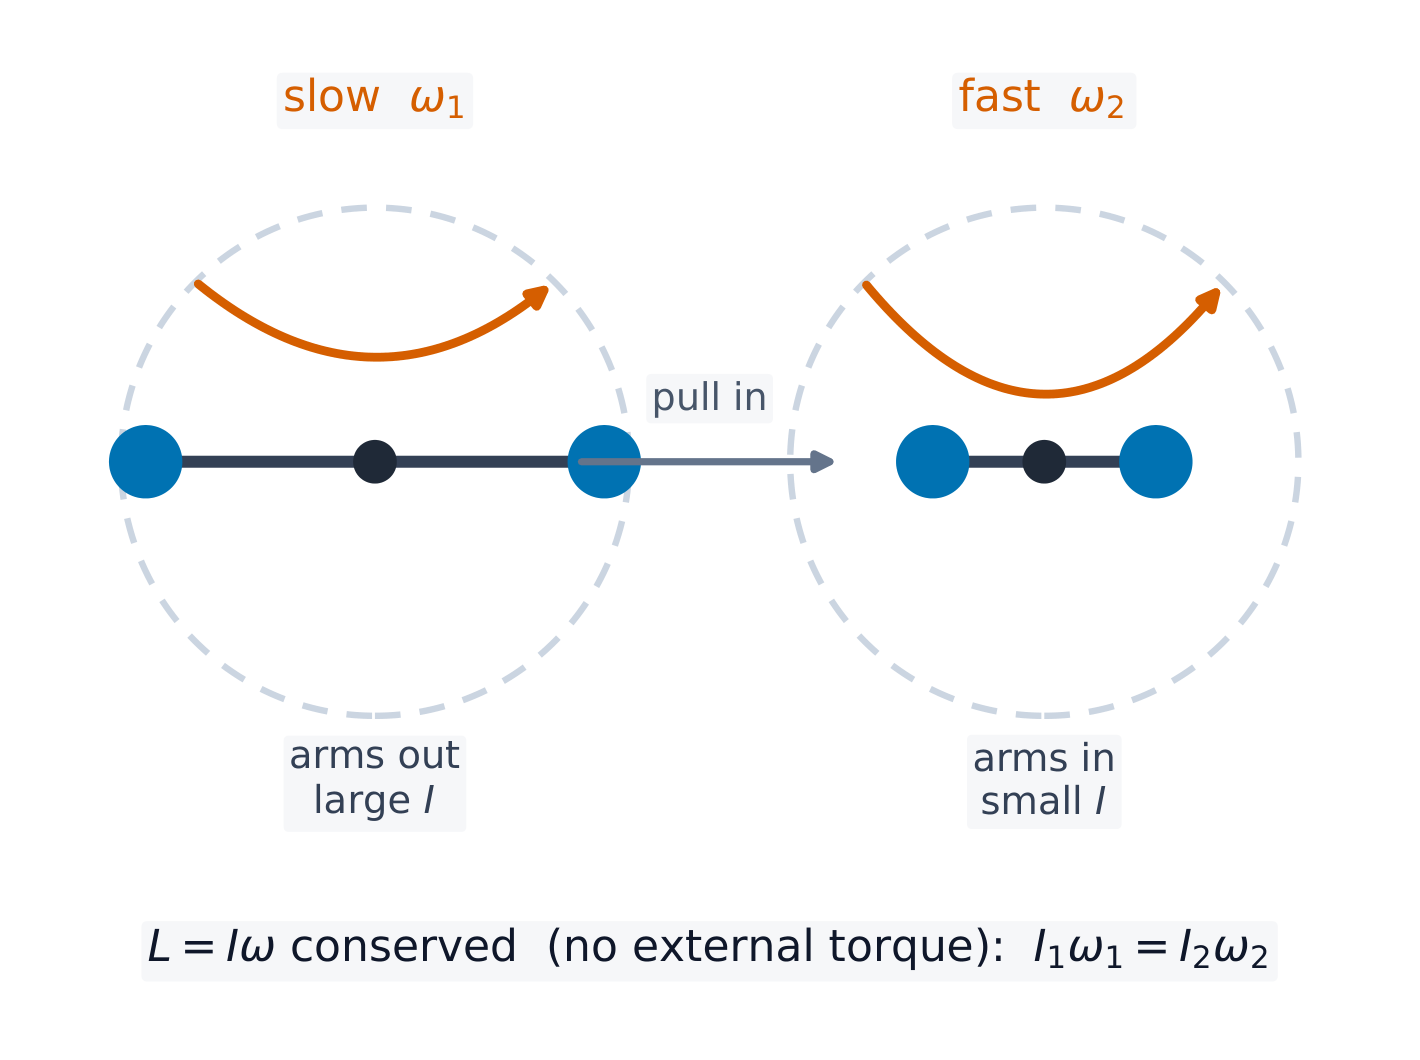
The angular momentum of a system about an axis is the sum of the angular momenta of its parts about that axis. As with linear momentum, angular momentum is conserved in all interactions: any change in a system's $L$ must come from an interaction with its surroundings, through an external torque. With zero net external torque, total angular momentum is conserved 守恒:
$$L_{\text{before}}=L_{\text{after}},\qquad I_1\omega_1=I_2\omega_2\ \text{(one rigid body reshaping)}.$$
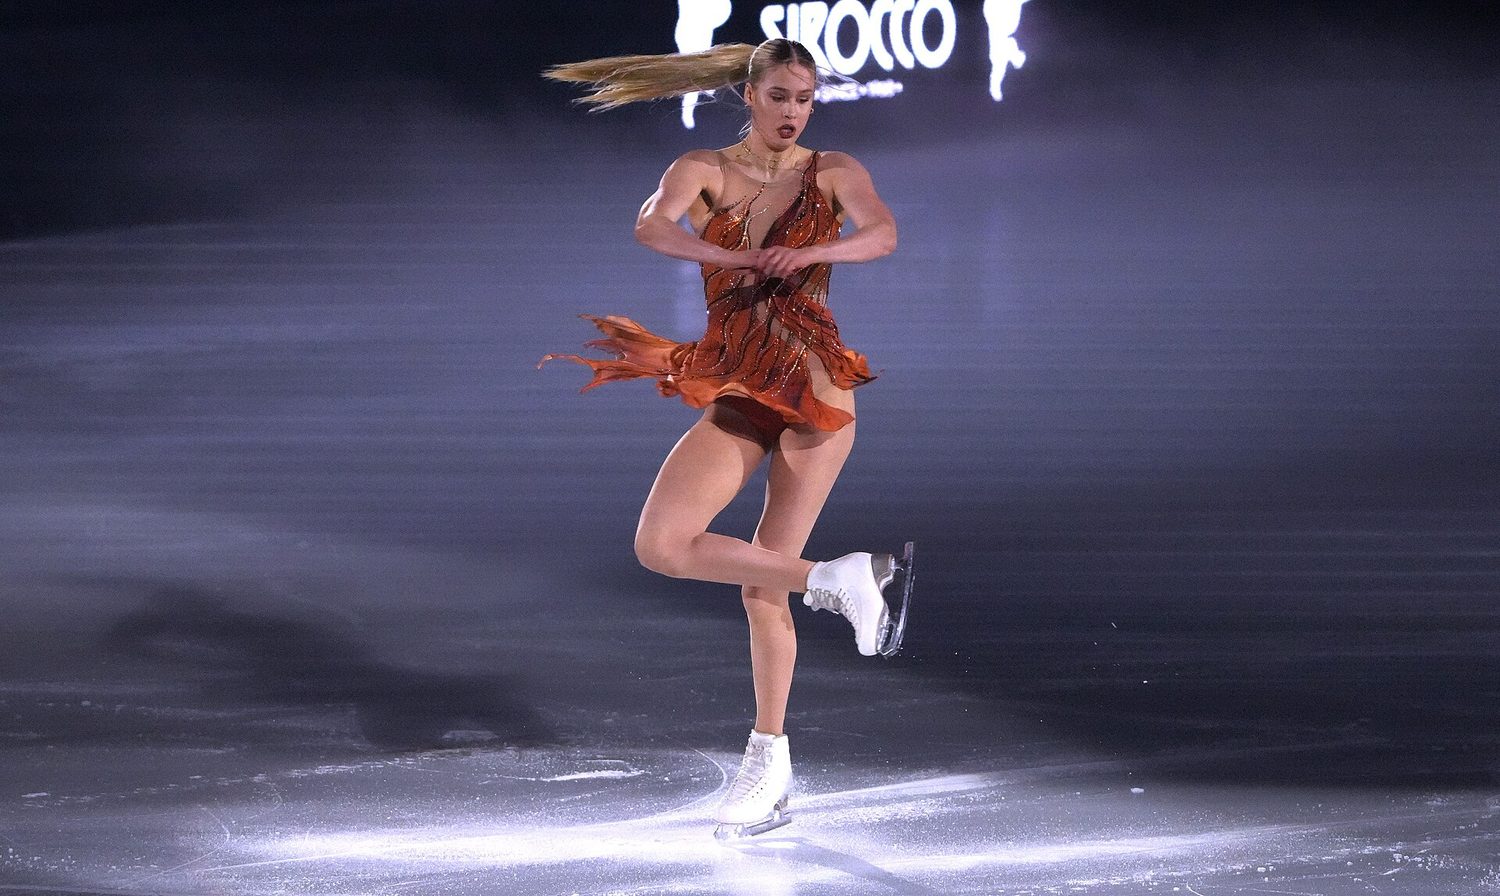
If $I$ shrinks, $\omega$ grows – a spinning skater speeds up pulling her arms in. The rule survives collisions and shape changes, which is what makes it so useful: pick the axis so that every external force (gravity, the pivot force) exerts no torque about it.
Worked example. A skater spins at $2.0\ \text{rev/s}$ with $I_1=4.0\ \text{kg}\cdot\text{m}^2$. Pulling in her arms drops it to $I_2=1.6\ \text{kg}\cdot\text{m}^2$: $\omega_2=\dfrac{4.0}{1.6}(2.0)=5.0\ \text{rev/s}$. Her kinetic energy rises – the extra energy is the work her muscles do pulling her arms inward.
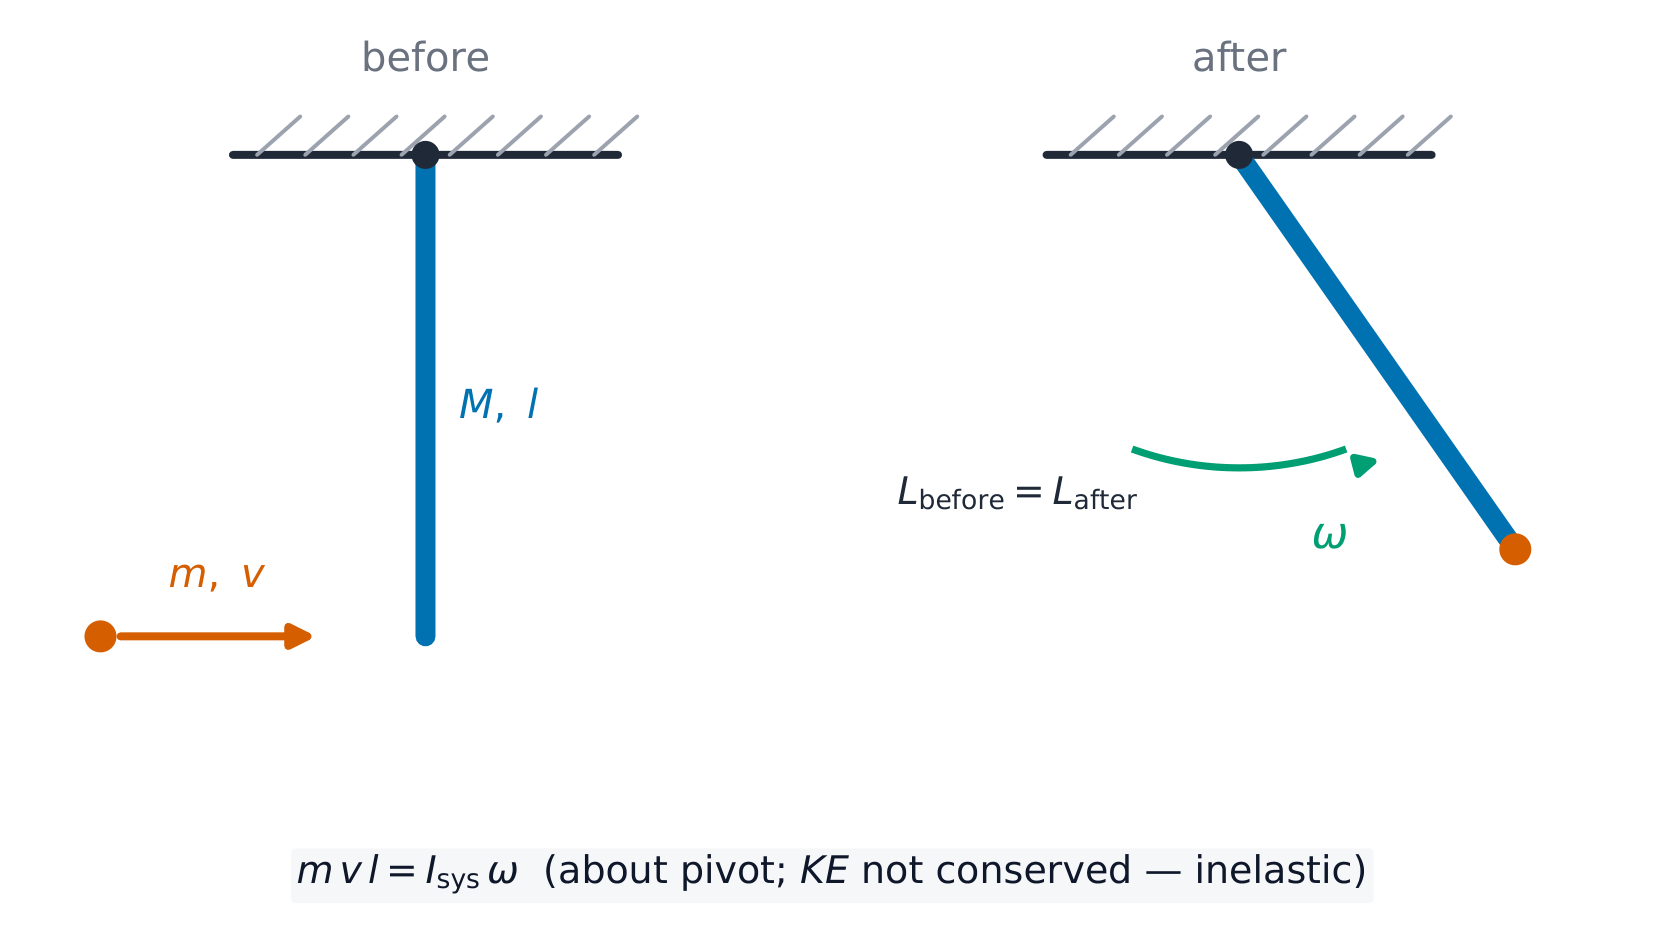
Worked example (rotational collision). A $0.020\ \text{kg}$ bullet at $300\ \text{m/s}$ strikes the tip of a uniform rod ($M=1.5\ \text{kg}$, length $l=0.60\ \text{m}$) hanging from a pivot, and embeds. About the pivot, gravity and the pivot force exert no torque during the strike, so $L$ is conserved: $L=mvl=0.020(300)(0.60)=3.6\ \text{kg}\cdot\text{m}^2/\text{s}$. Afterwards $I=\tfrac13Ml^2+ml^2=0.18+0.0072=0.187\ \text{kg}\cdot\text{m}^2$, so $\omega=\dfrac{3.6}{0.187}\approx19\ \text{rad/s}$. (Linear momentum is not conserved here – the pivot pushes on the rod – and kinetic energy certainly is not: check both before claiming them.)
Vocabulary
Train
| English |
|---|
| conserved/kənˈsɜːvd/ |
6.5
Rolling
Syllabus
| Learning Objective | Essential Knowledge |
|---|---|
6.5.A |
|
6.5.B |
|
6.5.C |
Boundary statement: Rolling friction is beyond the scope of AP Physics C: Mechanics. |
Source: College Board AP Course and Exam Description
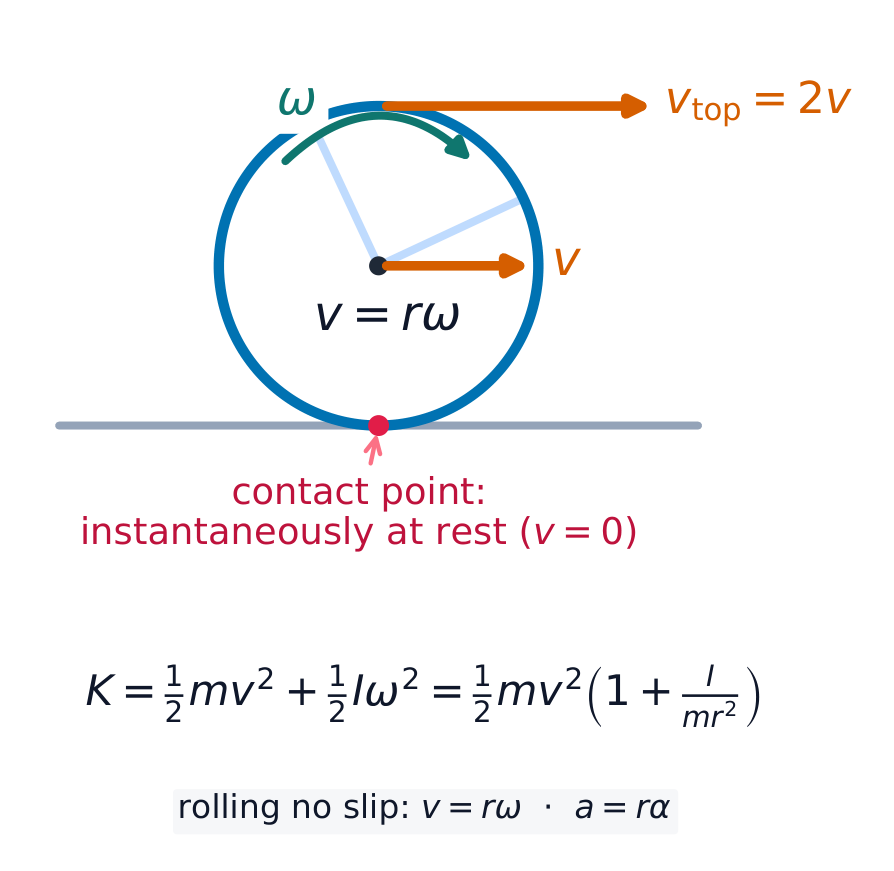
Rolling without slipping 无滑滚动 ties translation to rotation: the contact point is momentarily at rest, so
$$\Delta x_{\text{cm}}=r\,\Delta\theta,\qquad v_{\text{cm}}=r\omega,\qquad a_{\text{cm}}=r\alpha.$$
Static friction supplies the torque that keeps the spin matched to the motion, but at a point that is not sliding – so for pure rolling, friction does no work, and energy conservation is safe to use. (Rolling friction is beyond the AP course.)
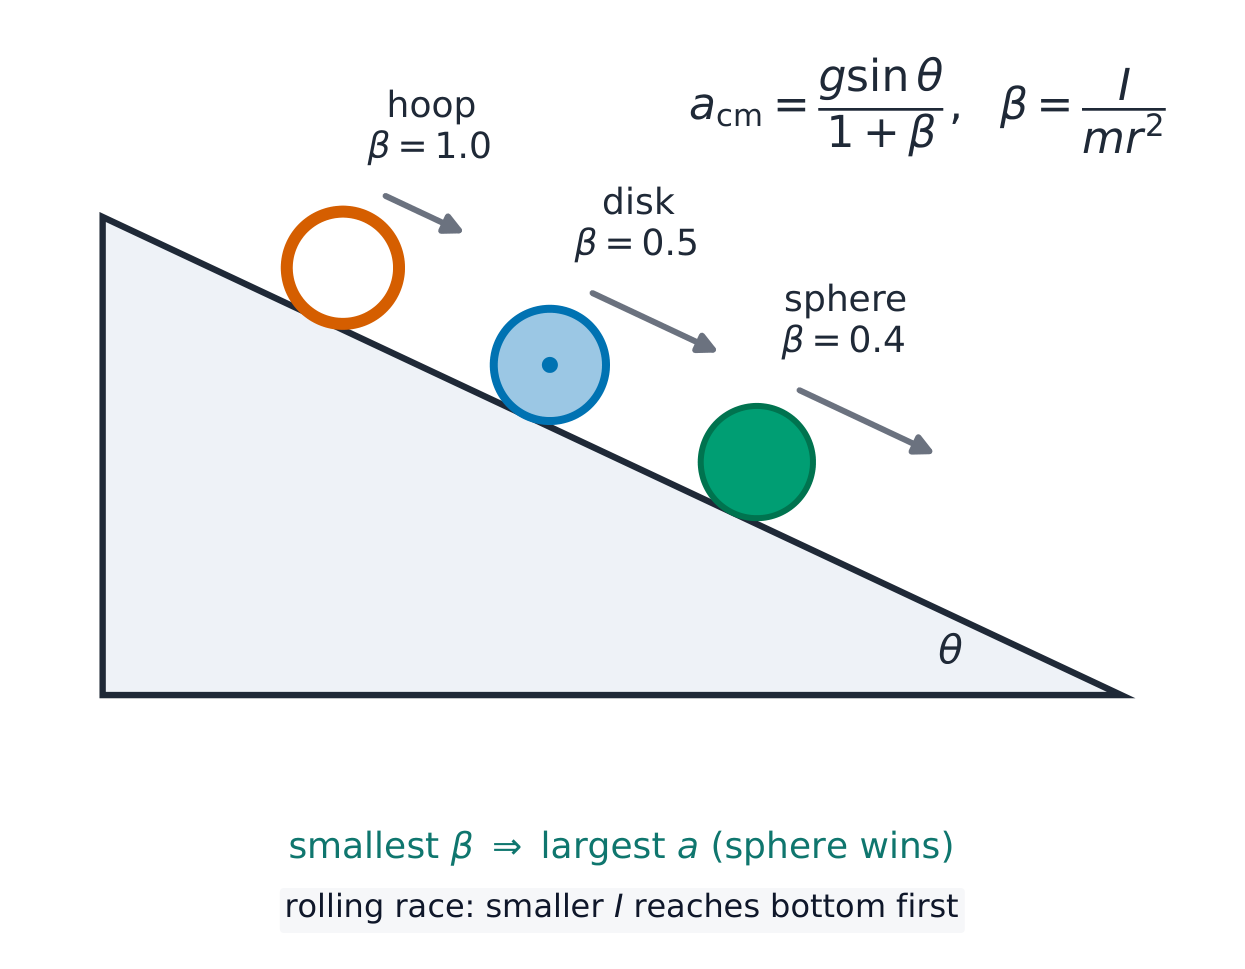
Racing shapes down an incline shows the energy split. With $I=\beta mr^2$, energy conservation gives
$$a_{\text{cm}}=\frac{g\sin\theta}{1+\beta}:$$
a sphere ($\beta=\tfrac25$) beats a disk 圆盘 ($\beta=\tfrac12$), which beats a hoop 圆环 ($\beta=1$) – mass and radius cancel completely. More of the hoop's energy is locked in rotation, so its center moves slower.
Slipping. When an object slides as well as spins, $v_{\text{cm}}\neq r\omega$ and the two motions cannot be linked directly. The contact point moves over the surface, so kinetic friction does dissipate energy – it turns kinetic energy into heat. Kinetic friction then works on both motions at once: it slows the center of mass and its torque changes the spin, until $v=r\omega$ and pure rolling begins.
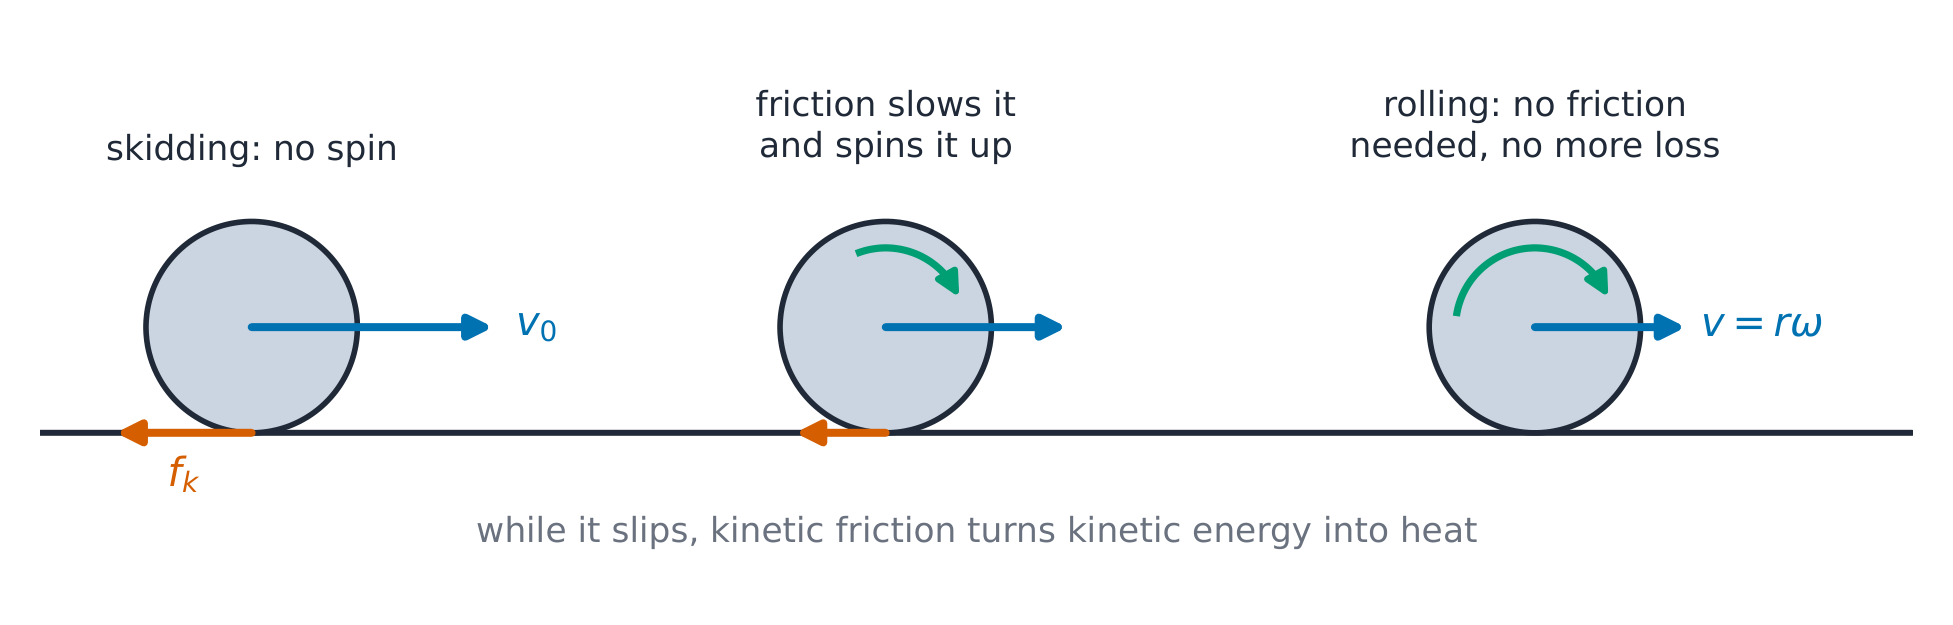
Worked example (skid to roll). A bowling ball (solid sphere, $I=\tfrac25mr^2$) is released at $v_0=7.0$ m/s with no spin. The coefficient of kinetic friction is 0.20. Linear: $a=-\mu g=-2.0\ \text{m/s}^2$, so $v=7.0-2.0t$. Rotational: $\alpha=\dfrac{\mu mgr}{\tfrac25mr^2}=\dfrac{5\mu g}{2r}$, so $r\omega=\tfrac52\mu g\,t=5.0t$. Rolling starts when $v=r\omega$: $7.0-2.0t=5.0t$, so $t=1.0$ s and $v=5.0$ m/s ($=\tfrac57v_0$). Kinetic energy falls from $\tfrac12m(7.0)^2=24.5m$ to $\tfrac12m(5.0)^2\big(1+\tfrac25\big)=17.5m$: about 29% was dissipated by friction while slipping.
Worked example. A solid sphere rolls from rest down a $30^\circ$ incline: $a=\dfrac{g\sin30^\circ}{1+\tfrac25}=\dfrac{9.8(0.50)}{1.4}=3.5\ \text{m/s}^2$, versus $4.9\ \text{m/s}^2$ for a frictionless slider – rolling objects always lose the race against sliding ones.
How the energy is shared. For an object rolling without slipping, $v=\omega R$ and $I=\beta MR^2$, so
$$\frac{K_{\text{rot}}}{K_{\text{total}}}=\frac{\tfrac12I\omega^2}{\tfrac12Mv^2+\tfrac12I\omega^2}=\frac{\beta}{1+\beta}.$$
For a solid cylinder ($\beta=\tfrac12$) the ratio is $\tfrac13$; for a solid sphere ($\beta=\tfrac25$) it is $\tfrac27$; for a hoop ($\beta=1$) it is $\tfrac12$. The larger the share that goes into rotation, the slower the object moves down a ramp, so a sphere beats a cylinder, which beats a hoop.
Worked example (rolling round a loop). A small solid sphere rolls without slipping down a track and round a vertical loop of radius $R$ (sphere radius much smaller than $R$). From what height $h$ must it start to just stay on the track at the top?
- At the top, gravity alone gives the centripetal force: $mg=\dfrac{mv^2}{R}$, so $v^2=gR$.
- Energy: $mgh=mg(2R)+\tfrac12mv^2+\tfrac12\left(\tfrac25mr^2\right)\left(\dfrac{v}{r}\right)^2=2mgR+\tfrac{7}{10}mgR$.
- So $h=2.7R$, higher than the $2.5R$ needed by a block that slides without friction, because some energy goes into spinning.
Worked example (sliding, then rolling). A bowling ball (solid sphere) is thrown along a lane with speed $v_0$ and no spin. Kinetic friction ($\mu$) slows its centre and makes it spin, until $v=\omega R$ and it rolls.
- Linear: $v=v_0-\mu gt$.
- Rotation: friction's torque $\mu MgR=\tfrac25MR^2\alpha$, so $\alpha=\dfrac{5\mu g}{2R}$ and $\omega R=\tfrac52\mu gt$.
- Rolling starts when $v_0-\mu gt=\tfrac52\mu gt$: $t=\dfrac{2v_0}{7\mu g}$, and then $v=\tfrac57v_0$.
Angular momentum about the contact line with the lane is conserved too (friction acts through that line), which gives the same $\tfrac57v_0$ more quickly. Kinetic energy is lost while it slides.
Explore
Rolling without slipping
For a wheel that rolls without slipping, v = r omega. Sort each case.
Vocabulary
Train
| English |
|---|
| rolling without slipping/ˈrəʊlɪŋ wɪˈðaʊt ˈslɪpɪŋ/ |
| disk/dɪsk/ |
| hoop/huːp/ |
6.6
Motion of Orbiting Satellites
Syllabus
| Learning Objective | Essential Knowledge |
|---|---|
6.6.A |
|
Source: College Board AP Course and Exam Description
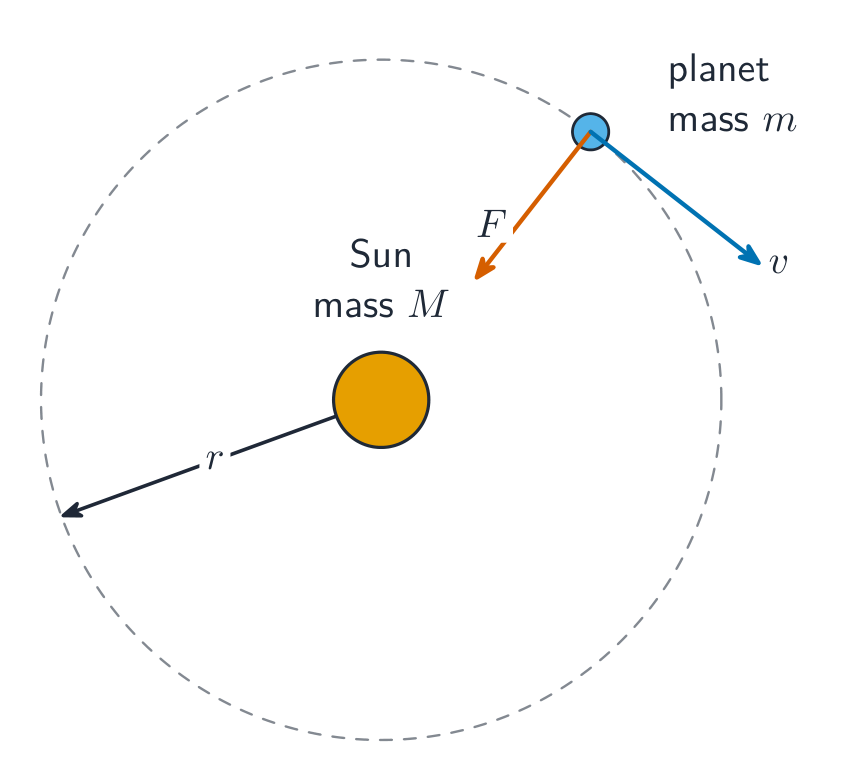
When a satellite orbits a much more massive central object (a planet around the Sun, a spacecraft around Earth), the central object's own motion is negligible, so we treat it as fixed. The satellite's motion is then fixed by the conservation laws.
Gravity supplies the centripetal force 向心力 for a satellite 卫星 in a circular orbit:
$$\frac{GMm}{r^2}=\frac{mv^2}{r}\quad\Rightarrow\quad v=\sqrt{\frac{GM}{r}}$$
– larger orbits are slower. With gravitational potential energy 引力势能 $U_g=-\dfrac{GMm}{r}$, a circular orbit obeys $K=-\tfrac12U$, so the total mechanical energy 总机械能 is
$$E=K+U=\frac{U}{2}=-\frac{GMm}{2r},$$
negative because the satellite is bound. To escape from radius $r$, total energy must reach zero, giving the escape velocity 逃逸速度
$$v_{\text{esc}}=\sqrt{\frac{2GM}{r}}.$$
In an elliptical orbit 椭圆轨道, $E$ and $L$ are fixed: gravity points at the focus, so it exerts no torque about it. Conserved $L$ means the satellite sweeps equal areas in equal times – Kepler's second law 开普勒第二定律 – and therefore moves fastest at closest approach, slowest at the far point. Energy conservation connects speeds at the two ends.
Worked example. For a satellite at $r=7.0\times10^{6}\ \text{m}$ around Earth ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$): orbital speed $v=\sqrt{GM/r}=7.6\times10^{3}\ \text{m/s}$, while escaping from that radius needs $v_{\text{esc}}=\sqrt{2GM/r}=1.1\times10^{4}\ \text{m/s}$ – exactly $\sqrt2$ times the circular speed.
Worked example (elliptical orbit). A satellite moves on an ellipse around Earth ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$). At closest approach it is $7.0\times10^6$ m from Earth's centre, moving at $8.7\times10^3$ m/s; at its farthest it is $1.4\times10^7$ m away. Find its speed there. At both ends the velocity is perpendicular to the radius, so $L=mvr$ and $v_2=\dfrac{v_1r_1}{r_2}=\dfrac{8.7\times10^3(7.0\times10^6)}{1.4\times10^7}=4.4\times10^3$ m/s. Check with energy per kilogram: $\tfrac12(8.7\times10^3)^2-\dfrac{4.0\times10^{14}}{7.0\times10^6}=-1.9\times10^7$ J/kg, and $\tfrac12(4.4\times10^3)^2-\dfrac{4.0\times10^{14}}{1.4\times10^7}=-1.9\times10^7$ J/kg. The two agree.
Exam skill. Orbit FRQs are energy-and-angular-momentum problems in disguise: write $E=\tfrac12mv^2-\dfrac{GMm}{r}$ and $L=mvr\sin\theta$ at the two points of interest and solve the pair – never assume the orbit formulae for circles apply to an ellipse.
Explore
Compare orbits at different radii
An orbiting satellite is in free fall, gravity supplying the centripetal force. A larger orbit means a slower speed and longer period (Kepler's third law).
Vocabulary
Train
| English |
|---|
| centripetal force/senˈtrɪpɪtl fɔːs/ |
| satellite/ˈsætəlaɪt/ |
| gravitational potential energy/ˌɡrævɪˈteɪʃənl pəˈtenʃl ˈenədʒi/ |
| total mechanical energy/ˈtəʊtl mɪˈkænɪkl ˈenədʒi/ |
| escape velocity/eˈskeɪp vəˈlɒsɪti/ |
| elliptical orbit/ɪˈlɪptɪkl ˈɔːbɪt/ |
| Kepler's second law/ˈkepləz ˈsekənd lɔː/ |
6.6
Exam tips
- Compute the moment of inertia $I=\int r^2\,dm$ and shift axes with the parallel-axis theorem $I=I_{cm}+Md^2$.
- Rotational kinetic energy is $\tfrac12 I\omega^2$; a rolling body has both translational and rotational KE.
- Conserve angular momentum $L=I\omega$ when net external torque is zero (a spinning skater pulling in).
- Use energy conservation for rolling-without-slipping problems ($v=r\omega$ ties the two motions).
- Know standard $I$ values (hoop, disk, rod, sphere) and where the axis is.
Common mistakes
- Conserving linear momentum when a rod is hit while hanging from a pivot. The pivot pushes during the collision; conserve angular momentum about the pivot instead.
- Leaving out rotational kinetic energy for a rolling object. $K = \tfrac12 Mv^2 + \tfrac12 I\omega^2$ with $\omega = v/R$.
- Saying static friction on a rolling wheel wastes energy. With no slipping, the contact point is at rest, so static friction does no work.
- Using circular-orbit formulas for an ellipse. Use conservation of energy and of angular momentum between the two points.
- Forgetting that a skater who pulls in her arms gains kinetic energy: $L$ is conserved, not $K$.
- Using $v=r\omega$ while an object is still skidding. It holds only once rolling without slipping has begun.
Interactive lessons on this topic
Work through it step by step, with instant-check exercises.