| Learning Objective | Essential Knowledge |
|---|---|
1.1.A |
|
Tips
فيزياء AP C: الميكانيكا هي النسخة المبنية على التفاضل والتكامل: الحركيات، القوى، الشغل والطاقة والقدرة، الزخم، العزم والدوران، والتذبذبات. تغطي مساحة أقل من الفيزياء 1 لكنها أعمق بكثير، والتفاضل والتكامل ليس مجرد زينة — بل هو الطريقة التي تُستنتج بها النتائج وكيف يتوقع الامتحان استخدامها.
على أرض الواقع: أعد التكامل للحصول على قيمة كلية من كمية متغيرة، وأعد التفاضل من الموقع إلى السرعة إلى التسارع، براحة وبدون أن يُطلب منك ذلك.
الديناميكا الدوارة هي المكان الذي يُهدر فيه الوقت، لأن عزوم القصور الذاتي يجب إعدادها كتكاملات بدلاً من حفظها.
تأخذ الملاحظات كل وحدة بترتيب CED مع عرض التفاضل والتكامل بشكل كامل. يتم حفظ الورقات السابقة والمعايير المعتمدة في المكتبة. ونظراً لأن الكثير من الدرجات تعتمد على الإعداد وليس الحساب، فإن الأمثلة المحلولة تُظهر بوضوح بناء التكامل قبل إكماله.
-
1
Kinematics · الحركية
Watch lesson · شاهد الدرس1.1
Scalars and Vectors · الكميات القياسية والمتجهات
Syllabus · المنهج
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishKinematics 运动学 describes motion. Two kinds of quantity:
- A scalar 标量 has only size (magnitude 大小): distance, speed, mass, time.
- A vector 矢量 has magnitude and direction: displacement, velocity, acceleration, force.
In this calculus-based course you resolve vectors into components 分量 and add them component by component; a vector's magnitude is $\sqrt{v_x^2+v_y^2+\cdots}$. Physics C also writes vectors with unit vectors 单位矢量: $\vec{v}=v_x\hat{i}+v_y\hat{j}$, where $\hat{i}$ and $\hat{j}$ are directions of length one along $x$ and $y$ – handy because calculus can then act on each component separately.
العربيةالحركة تصف الحركة. نوعان من الكميات:
- الكمية القياسية لها حجم فقط (مقدار): المسافة، السرعة، الكتلة، الزمن.
- المتجه له مقدار و اتجاه: الإزاحة، السرعة المتجهة، التسارع، القوة.
في هذا المقرر القائم على التفاضل والتكامل تقوم بتفكيك المتجهات إلى مكونات وتجمعها مركبة بمركبة؛ مقدار المتجه هو $\sqrt{v_x^2+v_y^2+\cdots}$. كتب الفيزياء C أيضًا المتجهات باستخدام متجهات الوحدة: $\vec{v}=v_x\hat{i}+v_y\hat{j}$، حيث $\hat{i}$ و$\hat{j}$ هما اتجاهات وحدة الطول على طول $x$ و$y$ – مفيد لأن التفاضل والتكامل يمكن أن يؤثر على كل مركبة على حدة.
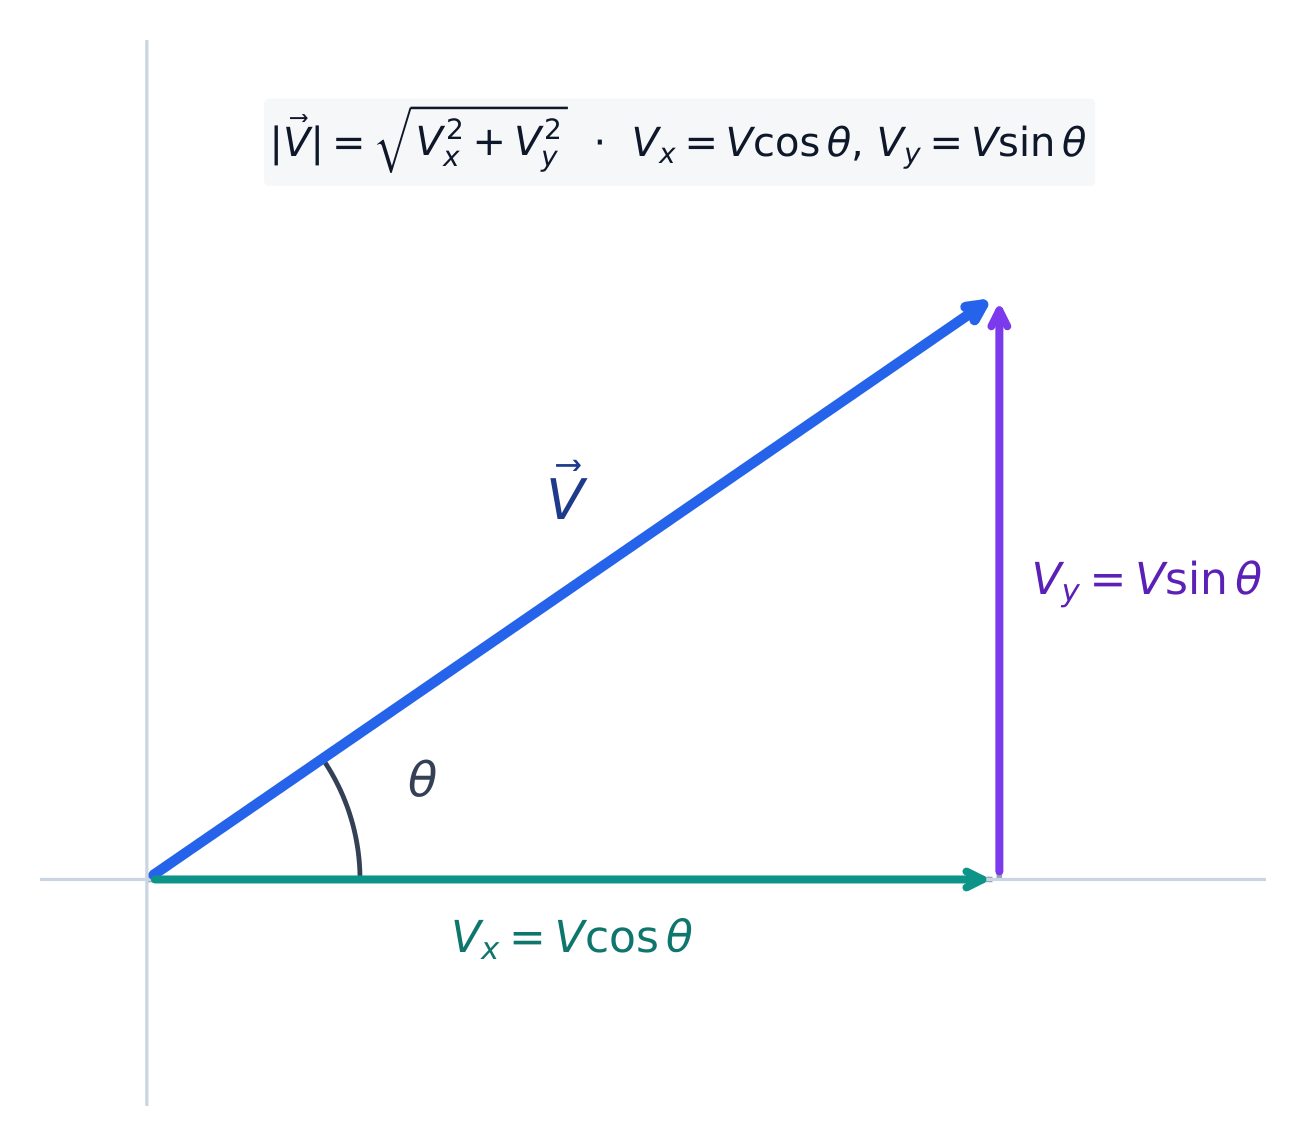
تفكيك متجه إلى مركبات x و y الخاصة به 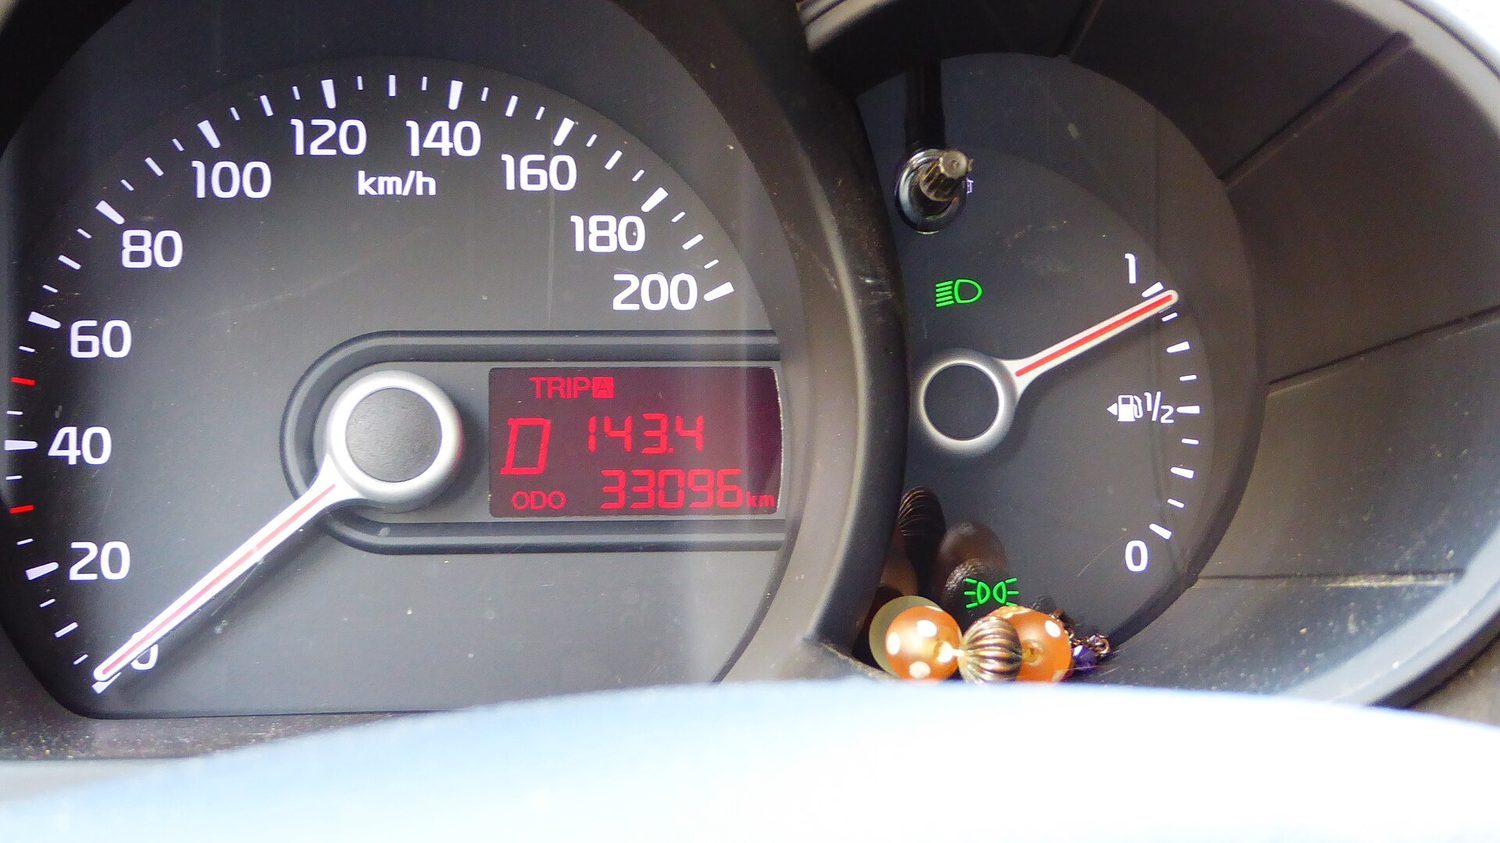
عداد سرعة السيارة: السرعة هي مقدار السرعة المتجهة — معدل حركة قياسي Explore · استكشفExplore the dot product · استكشف الضرب القياسي
Drag the components of $\vec{A}$ and $\vec{B}$. The dot product $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ reaches zero exactly when the two vectors are perpendicular — the geometry behind $\cos\theta$. · اسحب مكونات $\vec{A}$ و$\vec{B}$. تصل الضرب القياسي $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ إلى الصفر بالضبط عندما يكون المتجهان متعامدين — وهذا هو الأساس الهندسي لـ $\cos\theta$.
Vocabulary · مفردات Train · تدريبEnglish العربية vector/ˈvektə/ شعاعية components/kəmˈpəʊnənts/ مكونات unit vectors/ˈjuːnɪt ˈvektəz/ متجهات الوحدة derivatives/dɪˈrɪvətɪvz/ مشتقاتها average velocity/ˈævrɪdʒ vəˈlɒsɪti/ السرعة المتوسطة instantaneous velocity/ˌɪnstənˈteɪnɪəs vəˈlɒsɪti/ السرعة اللحظية free fall/friː fɔːl/ السقوط الحر reference frame/ˈrefrəns freɪm/ إطار مرجعي relative motion/ˈrelətɪv ˈməʊʃn/ الحركة النسبية projectile motion/prəˈdʒektaɪl ˈməʊʃn/ حركة المقذوفات 1.2
Displacement, Velocity, and Acceleration · الإزاحة، والسرعة المتجهة، والتسارع
Syllabus · المنهج
EnglishLearning Objective 1.2.A: Describe a change in an object's position.
- 1.2.A.1 When using the object model, the size, shape, and internal configuration are ignored. The object may be treated as a single point with extensive properties such as mass and charge.
- 1.2.A.2 Displacement is the change in an object's position.
- Equation: $\Delta x = x - x_0$
Learning Objective 1.2.B: Describe the average velocity and acceleration of an object.
- 1.2.B.1 Averages of velocity and acceleration are calculated considering the initial and final states of an object over an interval of time.
- 1.2.B.2 Average velocity is the displacement of an object divided by the interval of time in which that displacement occurs.
- Equation: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
- 1.2.B.3 Average acceleration is the change in velocity divided by the interval of time in which that change in velocity occurs.
- Equation: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
- 1.2.B.4 An object is accelerating if either the magnitude and/or direction of the object's velocity are changing.
- 1.2.B.5 Calculating average velocity or average acceleration over a very small time interval yields a value that is very close to the instantaneous velocity or instantaneous acceleration.
Learning Objective 1.2.C: Describe the instantaneous position, velocity, and acceleration of an object as a function of time.
- 1.2.C.1 As the time interval used to calculate the average value of a quantity approaches zero, the average value of that quantity approaches the value of the quantity at that instant, called the instantaneous value.
- 1.2.C.1.i Instantaneous velocity is the rate of change of the object's position, which is equal to the derivative of position with respect to time.
- Equation: $\vec{v} = \dfrac{d\vec{r}}{dt}$
- Equation: $v_x = \dfrac{dx}{dt}$
- 1.2.C.1.ii Instantaneous acceleration is the rate of change of the object's velocity, which is equal to the derivative of velocity with respect to time.
- Equation: $\vec{a} = \dfrac{d\vec{v}}{dt}$
- Equation: $a_x = \dfrac{dv_x}{dt}$
- 1.2.C.1.i Instantaneous velocity is the rate of change of the object's position, which is equal to the derivative of position with respect to time.
- 1.2.C.2 Time-dependent functions and instantaneous values of position, velocity, and acceleration can be determined using differentiation and integration.
العربيةهدف التعلم 1.2.A: وصف تغير موقع جسم ما.
- 1.2.A.1 عند استخدام نموذج الجسم، يتم إهمال الحجم والشكل والتكوين الداخلي. يمكن التعامل مع الجسم كنقطة واحدة بخصائص واسعة مثل الكتلة والشحنة.
- 1.2.A.2 الإزاحة هي التغير في موقع جسم ما.
- المعادلة: $\Delta x = x - x_0$
هدف التعلم 1.2.B: وصف السرعة المتوسطة والتسارع المتوسط لجسم ما.
- 1.2.B.1 تُحسب متوسطات السرعة والتسارع مع مراعاة الحالات الأولية والنهائية للجسم خلال فترة زمنية.
- 1.2.B.2 السرعة المتوسطة هي إزاحة جسم مقسومة على الفترة الزمنية التي حدثت فيها تلك الإزاحة.
- المعادلة: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
- 1.2.B.3 التسارع المتوسط هو التغير في السرعة مقسوماً على الفترة الزمنية الذي حدث فيها ذلك التغير في السرعة.
- المعادلة: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
- 1.2.B.4 يكون الجسم متسارعًا إذا كان مقدار السرعة و/أو اتجاه سرعة الجسم يتغيران.
- 1.2.B.5 حساب السرعة المتوسطة أو التسارع المتوسط خلال فترة زمنية صغيرة جداً يعطي قيمة قريبة جداً من السرعة اللحظية أو التسارع اللحظي.
الهدف التعليمي 1.2.C: وصف الموضع اللحظي والسرعة والتسارع لجسم ما بدلالة الزمن.
- 1.2.C.1 مع اقتراب فترة الزمن المستخدمة لحساب القيمة المتوسطة لكمية ما من الصفر، تقترب القيمة المتوسطة لتلك الكمية من قيمتها عند تلك اللحظة، والتي تسمى القيمة اللحظية.
- 1.2.C.1.i السرعة اللحظية هي معدل تغير موضع الجسم، وهي تساوي المشتقة الزمنية للموضع.
- معادلة: $\vec{v} = \dfrac{d\vec{r}}{dt}$
- معادلة: $v_x = \dfrac{dx}{dt}$
- 1.2.C.1.ii التسارع اللحظي هو معدل تغير سرعة الجسم، وهو يساوي المشتقة الزمنية للسرعة.
- معادلة: $\vec{a} = \dfrac{d\vec{v}}{dt}$
- معادلة: $a_x = \dfrac{dv_x}{dt}$
- 1.2.C.1.i السرعة اللحظية هي معدل تغير موضع الجسم، وهي تساوي المشتقة الزمنية للموضع.
- 1.2.C.2 يمكن تحديد الدوال المعتمدة على الزمن والقيم اللحظية للموضع والسرعة والتسارع باستخدام التفاضل والتكامل.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishProjectile motion is two independent motions Because motion can change continuously, define the rates as derivatives 导数:
$$v=\frac{dx}{dt},\qquad a=\frac{dv}{dt}=\frac{d^2x}{dt^2}.$$Reversing this, integrate to recover velocity and position:$$v(t)=v_0+\int_0^t a\,dt,\qquad x(t)=x_0+\int_0^t v\,dt.$$Distinguish the average from the instantaneous: average velocity 平均速度 is $\Delta x/\Delta t$ over an interval, while instantaneous velocity 瞬时速度 is the derivative at one moment – the slope of the tangent line, and what a speedometer shows.For constant acceleration these give the familiar kinematic equations ($v=v_0+at$, $x=x_0+v_0t+\tfrac12at^2$, $v^2=v_0^2+2a\,\Delta x$). The most important constant-$a$ case is free fall 自由落体: near Earth's surface every object, heavy or light, accelerates downward at $g=9.8\ \text{m/s}^2$ once air resistance is negligible. When $a$ or $v$ varies with time, use the integrals directly.
Worked example. A particle moves with $x(t)=2t^3-3t^2$ (metres). Differentiate for velocity and acceleration:
$$v=\frac{dx}{dt}=6t^2-6t,\qquad a=\frac{dv}{dt}=12t-6.$$At $t=2\ \text{s}$, $v=24-12=12\ \text{m/s}$ and $a=24-6=18\ \text{m/s}^2$. This calculus link – not just the constant-$a$ formulas – is what distinguishes Physics C.Worked example. A particle starts from rest at the origin with $a(t)=6t$. Integrate: $v=\int 6t\,dt=3t^2$ and $x=\int 3t^2\,dt=t^3$. At $t=2\ \text{s}$, $v=12\ \text{m/s}$ and $x=8\ \text{m}$.
العربيةحركة المقذوفات هي حركتان مستقلتان لأن الحركة يمكن أن تتغير باستمرار، عرّف المعدلات sebagai مشتقات:
$$v=\frac{dx}{dt},\qquad a=\frac{dv}{dt}=\frac{d^2x}{dt^2}.$$عكس هذه العملية، قم بالتكامل لاستعادة السرعة والموقع:$$v(t)=v_0+\int_0^t a\,dt,\qquad x(t)=x_0+\int_0^t v\,dt.$$فرق بين المتوسط واللحظي: السرعة المتوسطة هي $\Delta x/\Delta t$ خلال فترة زمنية، بينما السرعة اللحظية هي المشتقة عند لحظة واحدة – ميل الخط المماس، وما يظهره عداد السرعة.بالنسبة لتسارع ثابت، تعطي هذه المعادلات الحركية المألوفة ($v=v_0+at$، $x=x_0+v_0t+\tfrac12at^2$، $v^2=v_0^2+2a\,\Delta x$). الحالة الأهم لتسارع-$a$ ثابت هي السقوط الحر: بالقرب من سطح الأرض يتسارع كل جسم، ثقيلًا كان أو خفيفًا، لأسفل بمقدار $g=9.8\ \text{m/s}^2$ بمجرد إهمال مقاومة الهواء. عندما تتغير $a$ أو $v$ مع الزمن، استخدم التكاملات مباشرة.
مثال محلول. جسيم يتحرك بمقدار $x(t)=2t^3-3t^2$ (أمتار). اشتق للحصول على السرعة والتسارع:
$$v=\frac{dx}{dt}=6t^2-6t,\qquad a=\frac{dv}{dt}=12t-6.$$عند $t=2\ \text{s}$، $v=24-12=12\ \text{m/s}$ و$a=24-6=18\ \text{m/s}^2$. هذا الرابط بالتفاضل والتكامل – ليس فقط معادلات تسارع-$a$ الثابت – هو ما يميز الفيزياء C.مثال محلول. جسيم يبدأ من السكون عند نقطة الأصل بـ $a(t)=6t$. تكامل: $v=\int 6t\,dt=3t^2$ و$x=\int 3t^2\,dt=t^3$. عند $t=2\ \text{s}$، $v=12\ \text{m/s}$ و$x=8\ \text{m}$.
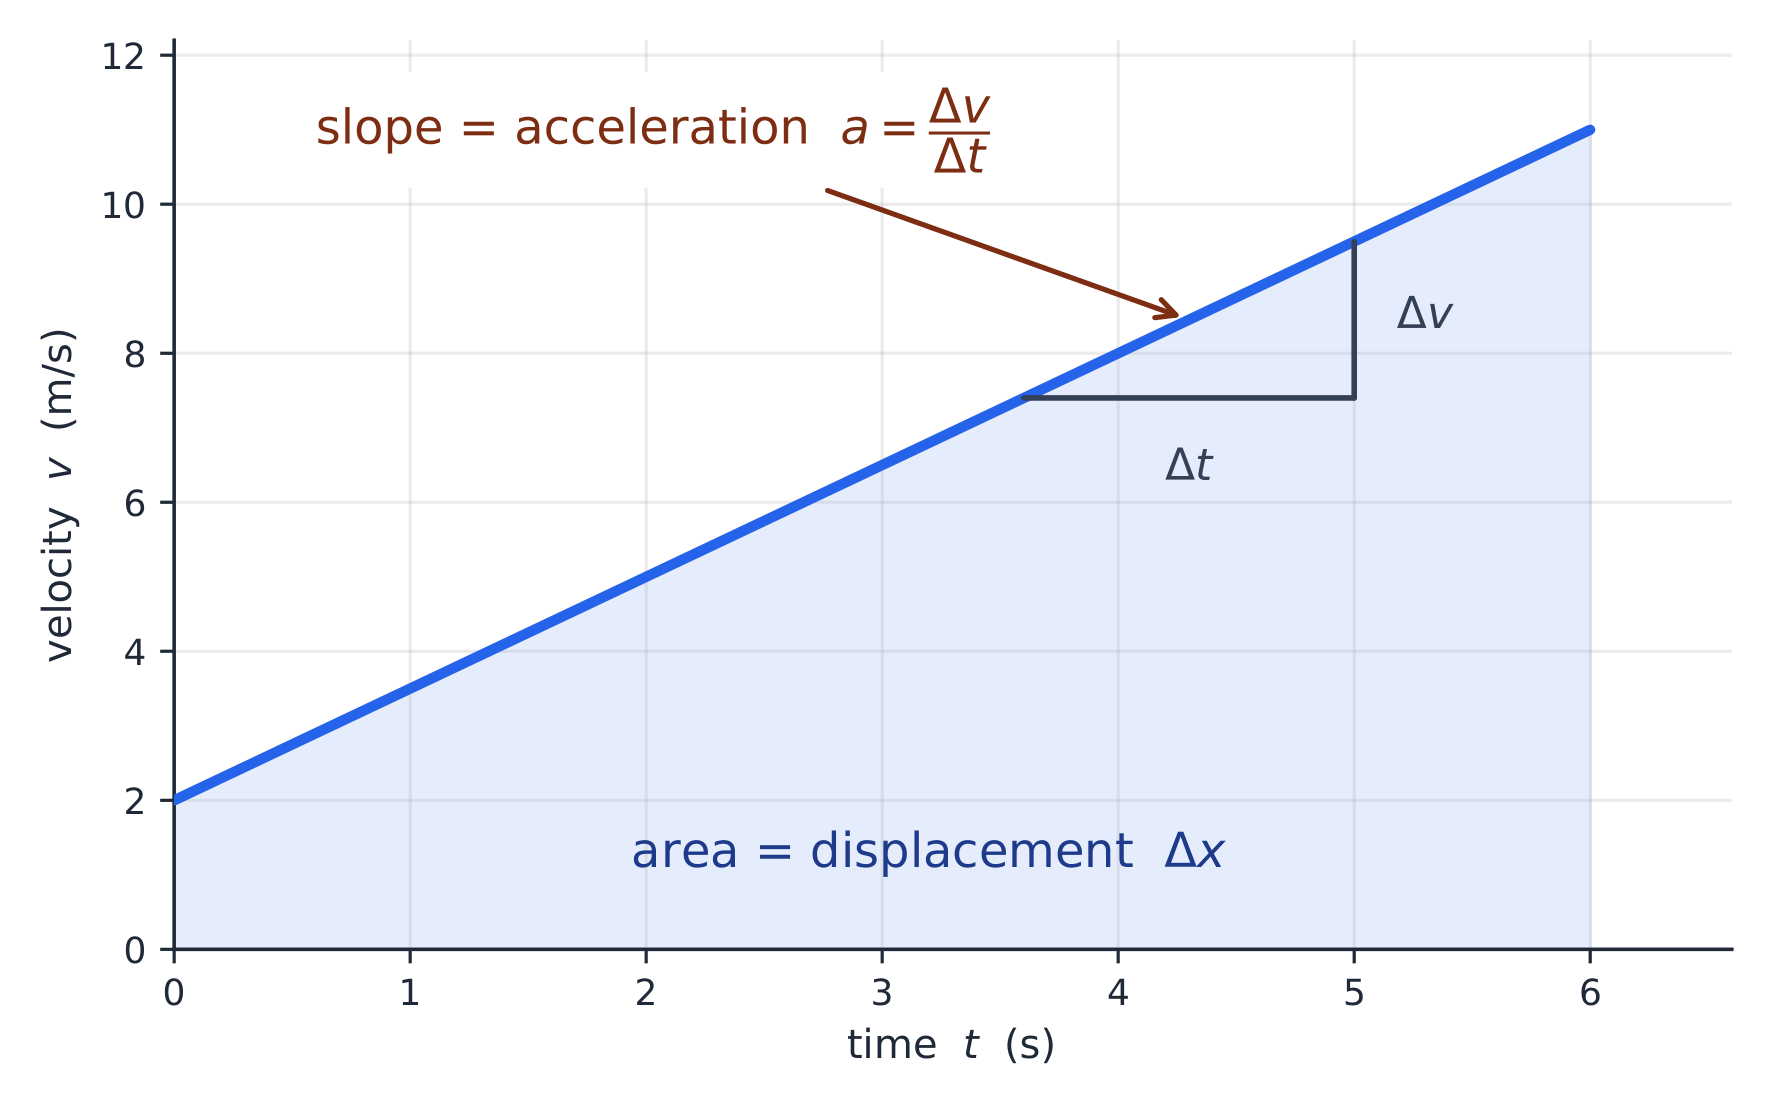
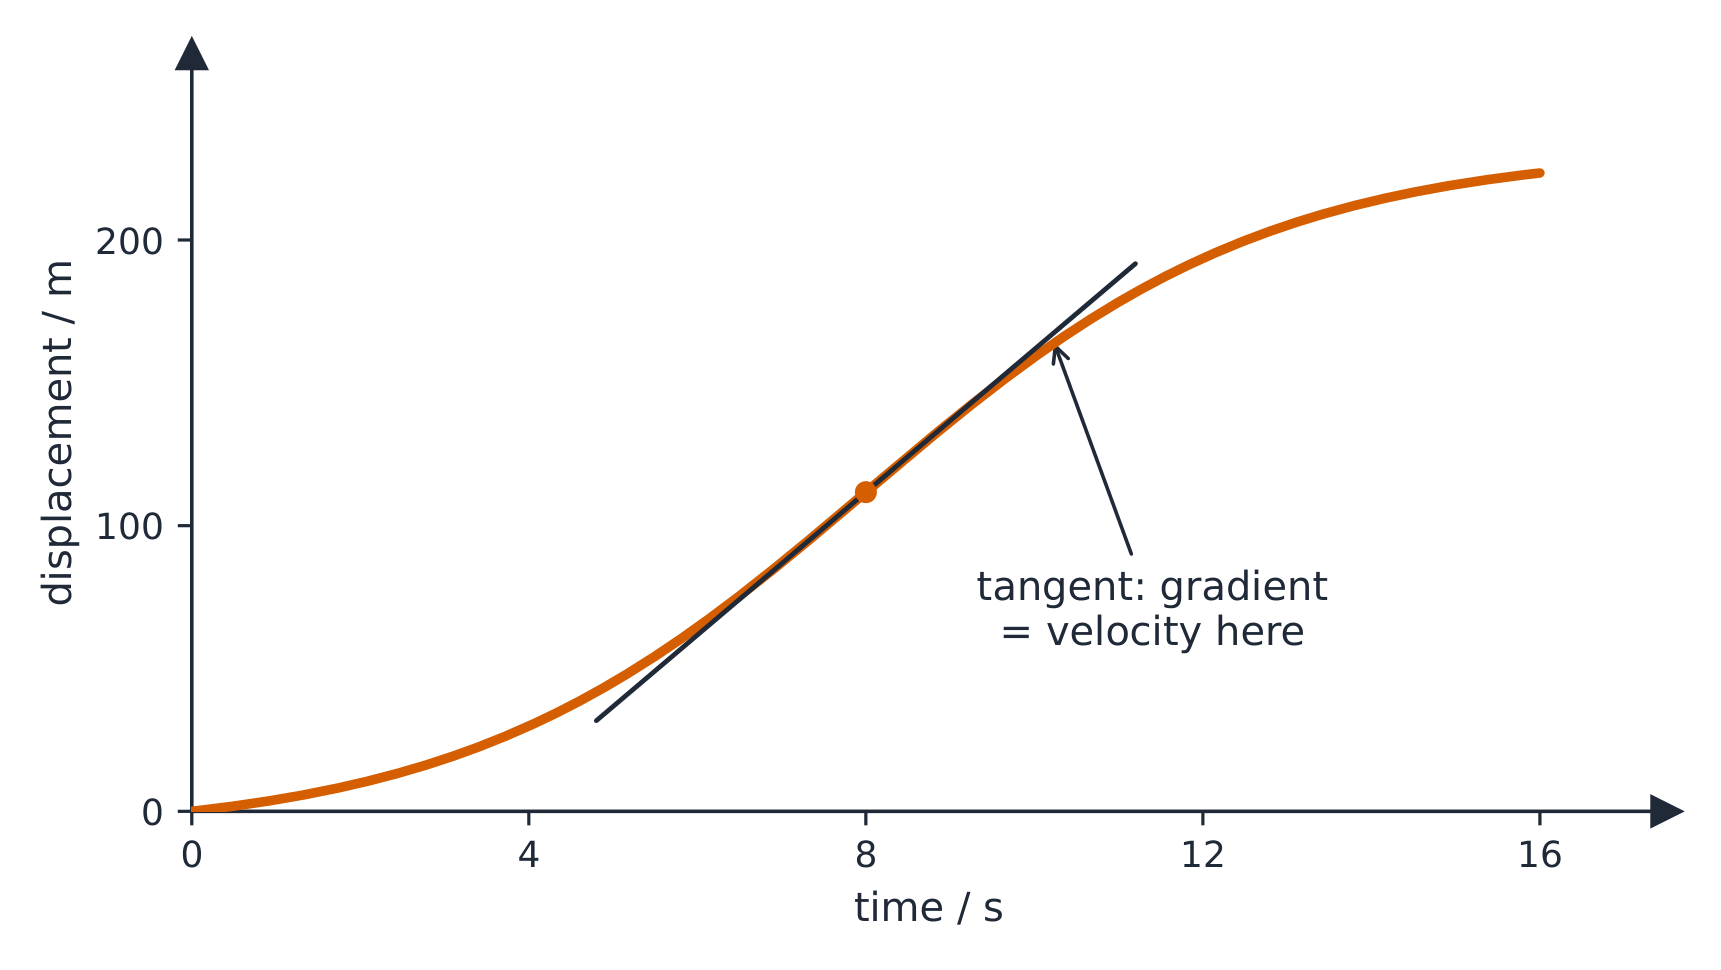
على رسم بياني للسرعة والزمن، الميل هو التسارع والمساحة هو الإزاحة 
قطار عالي السرعة: الحركية تصف الإزاحة، والسرعة المتجهة، والتسارع عبر الزمن Vocabulary · مفردات Train · تدريبEnglish العربية Kinematics/ˌkɪnɪˈmætɪks/ الحركية scalar/ˈskeɪlə/ كمية قياسية magnitude/ˈmæɡnɪtjuːd/ المقدار 1.3
Representing Motion · تمثيل الحركة
Syllabus · المنهج
EnglishLearning Objective 1.3.A: Describe the position, velocity, and acceleration of an object using representations of that object's motion.
- 1.3.A.1 Motion can be represented by motion diagrams, figures, graphs, equations, and narrative descriptions.
- 1.3.A.2 For constant acceleration, three kinematic equations can be used to describe instantaneous linear motion in one dimension:
- Equation: $v_x = v_{x0} + a_x t$
- Equation: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
- Equation: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
- Note: The equations above are written to indicate motion in the $x$-direction, but these equations can be used in any single dimension as appropriate.
- 1.3.A.3 Near the surface of Earth, the vertical acceleration caused by the force of gravity is downward, constant, and has a measured value approximately equal to
- Equation: $a_g = g \approx 10 \ \text{m/s}^2$.
- 1.3.A.4 Graphs of position, velocity, and acceleration as functions of time can be used to find the relationships between those quantities.
- 1.3.A.4.i An object's instantaneous velocity is the rate of change of the object's position, which is equal to the slope of a line tangent to a point on a graph of the object's position as a function of time.
- Equation: $v_x = \dfrac{dx}{dt}$
- 1.3.A.4.ii An object's instantaneous acceleration is the rate of change of the object's velocity, which is equal to the slope of a line tangent to a point on a graph of the object's velocity as a function of time.
- Equation: $a_x = \dfrac{dv_x}{dt}$
- 1.3.A.4.iii The displacement of an object during a time interval is equal to the area under the curve of a graph of the object's velocity as a function of time (i.e., the area bounded by the function and the horizontal axis for the appropriate interval).
- Equation: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
- 1.3.A.4.iv The change in velocity of an object during a time interval is equal to the area under the curve of a graph of the acceleration of the object as a function of time.
- Equation: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$
- 1.3.A.4.i An object's instantaneous velocity is the rate of change of the object's position, which is equal to the slope of a line tangent to a point on a graph of the object's position as a function of time.
Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism expects that for all situations in which a numerical quantity is required for g, the value $g \approx 10 \ \text{m/s}^2$ will be used. However, students will not be penalized for correctly using the more precise commonly accepted values of $g = 9.81 \ \text{m/s}^2$ or $g = 9.8 \ \text{m/s}^2$.
العربيةهدف التعلم 1.3.A: وصف موقع وسرعة وتسارع جسم ما باستخدام تمثيلات لحركته.
- 1.3.A.1 يمكن تمثيل الحركة بمخططات الحركة، الأشكال، الرسوم البيانية، المعادلات، والأوصاف السردية.
- 1.3.A.2 بالنسبة للتسارع الثابت، يمكن استخدام ثلاث معادلات حركية لوصف الحركة الخطية اللحظية في بُعد واحد:
- المعادلة: $v_x = v_{x0} + a_x t$
- المعادلة: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
- المعادلة: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
- ملاحظة: المعادلات أعلاه مكتوبة للإشارة إلى الحركة في اتجاه $x$، ولكن يمكن استخدام هذه المعادلات في أي بُعد واحد حسب الحاجة.
- 1.3.A.3 بالقرب من سطح الأرض، يكون التسارع الرأسي الناتج عن قوة الجاذبية نحو الأسفل، ثابتاً، وقيمته المقاسة تقارب
- المعادلة: $a_g = g \approx 10 \ \text{m/s}^2$.
- 1.3.A.4 يمكن استخدام رسوم بيانية للموقع والسرعة والتسارع كدوال للزمن لإيجاد العلاقات بين تلك الكميات.
- 1.3.A.4.i السرعة اللحظية لجسم ما هي معدل تغير موقعه، وتساوي ميل خط مماس لنقطة على رسم بياني لموقع الجسم كدالة للزمن.
- معادلة: $v_x = \dfrac{dx}{dt}$
- 1.3.A.4.ii التسارع اللحظي لجسم ما هو معدل تغير سرعته، ويساوي ميل خط مماس لنقطة على رسم بياني لسرعته كدالة للزمن.
- معادلة: $a_x = \dfrac{dv_x}{dt}$
- 1.3.A.4.iii إزاحة جسم ما خلال فترة زمنية تساوي المساحة تحت منحنى رسم بياني لسرعته كدالة للزمن (أي المساحة المحصورة بين الدالة والمحور الأفقي للفترة المناسبة).
- معادلة: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
- 1.3.A.4.iv التغير في سرعة جسم ما خلال فترة زمنية يساوي المساحة تحت منحنى رسم بياني لتسارعه كدالة للزمن.
- معادلة: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$
- 1.3.A.4.i السرعة اللحظية لجسم ما هي معدل تغير موقعه، وتساوي ميل خط مماس لنقطة على رسم بياني لموقع الجسم كدالة للزمن.
عبارة حدودية: يتوقع امتحان AP Physics C: الميكانيكا وAP Physics C: الكهرباء والمغناطيس أن يُستخدم القيمة $g \approx 10 \ \text{m/s}^2$ لجميع الحالات التي يتطلب فيها حساب كمية عددية لـ g. ومع ذلك، لن يتم معاقبة الطلاب الذين يستخدمون بشكل صحيح القيم المقبولة عموماً والأكثر دقة لـ $g = 9.81 \ \text{m/s}^2$ أو $g = 9.8 \ \text{m/s}^2$.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishMove fluently between description, graph, table, and equation:
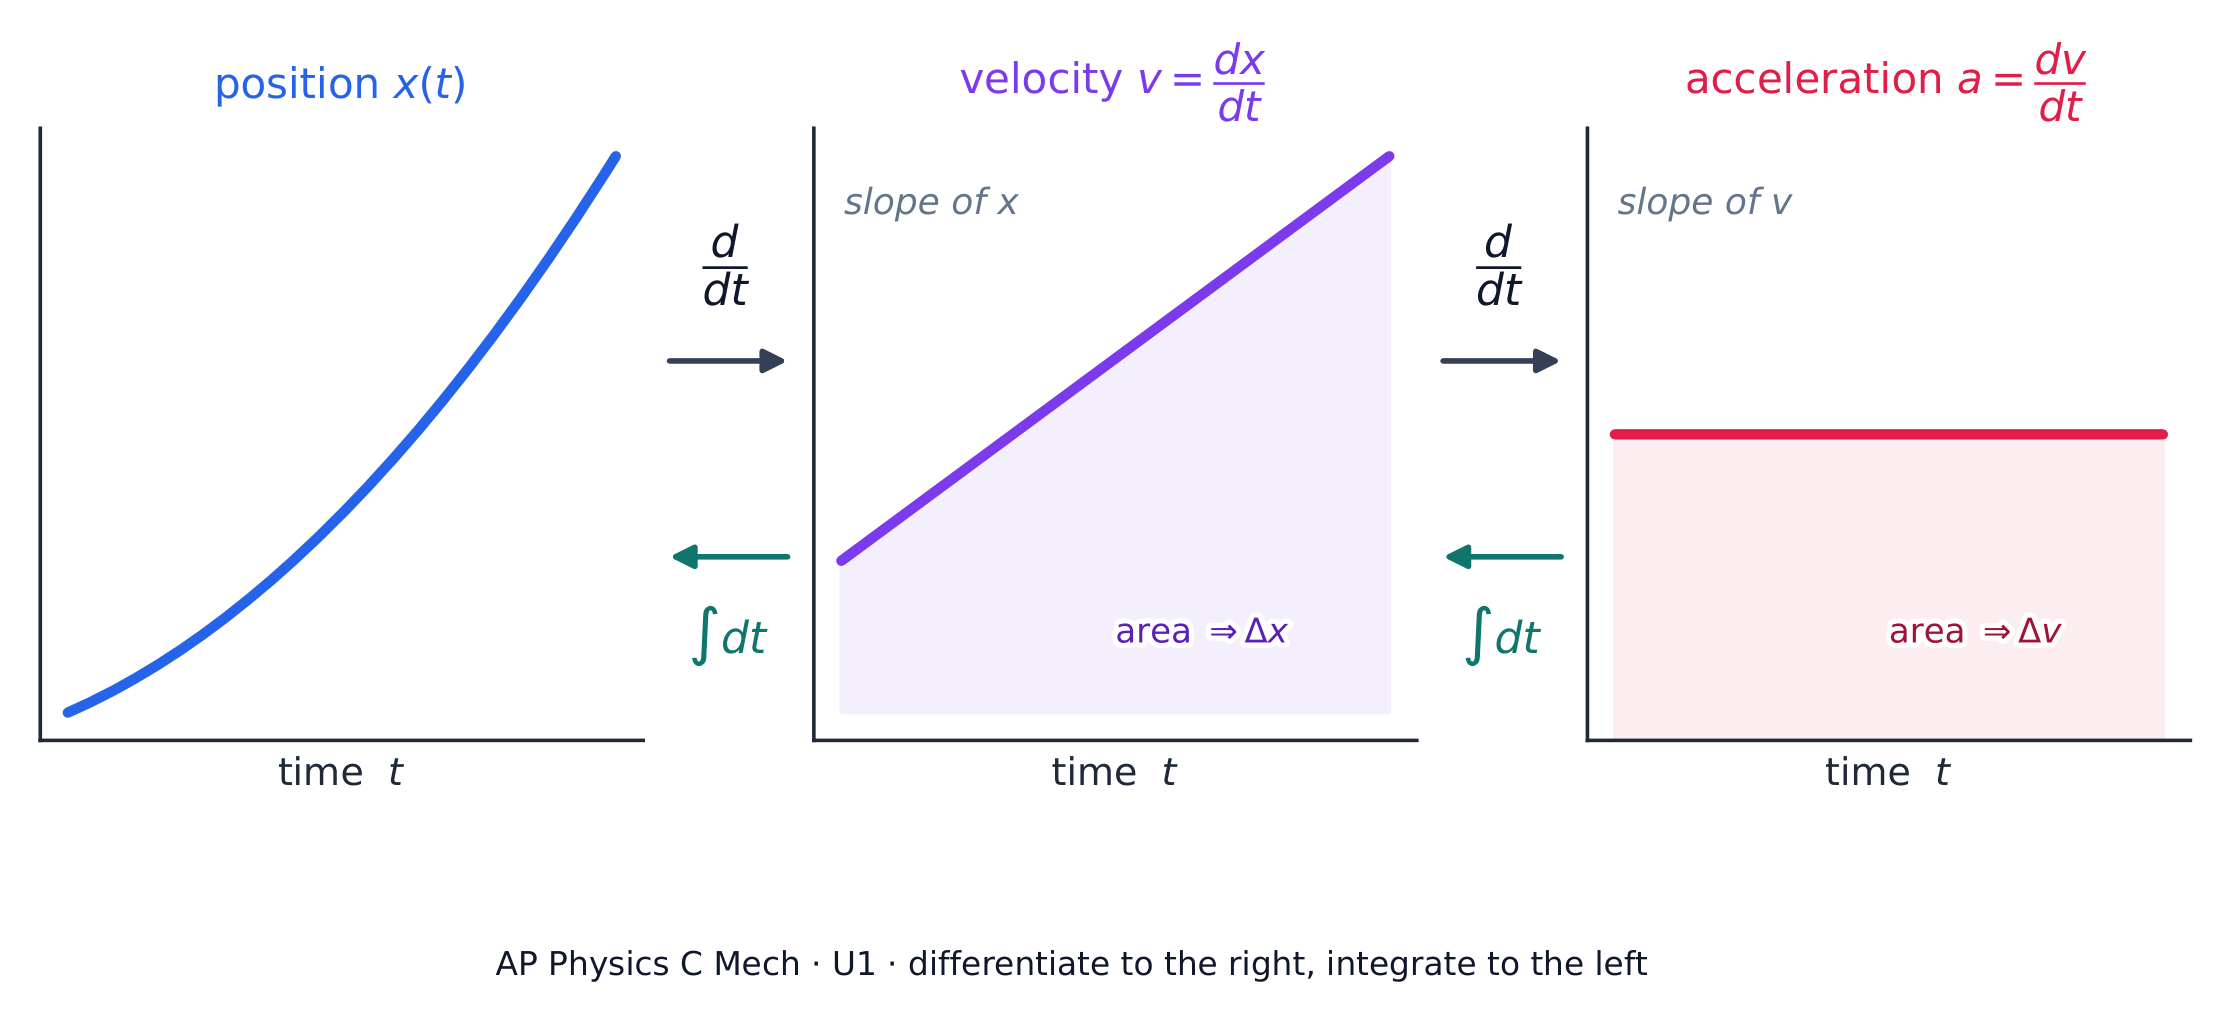
- On a position–time graph, the slope ($dx/dt$) is velocity.
- On a velocity–time graph, the slope is acceleration and the area ($\int v\,dt$) is displacement.
- On an acceleration–time graph, the area ($\int a\,dt$) is the change in velocity.
Slopes are derivatives; areas are integrals – the two are inverse operations here.
العربيةانتقل بسلاسة بين الوصف، الرسم البياني، الجدول، والمعادلة:
رسم بياني للإزاحة والزمن: الميل عند أي لحظة هو السرعة - على رسم بياني الموقع–الزمن، الميل ($dx/dt$) هو السرعة.
- على رسم بياني السرعة–الزمن، الميل هو التسارع والمساحة ($\int v\,dt$) هي الإزاحة.
- على رسم بياني التسارع–الزمن، المساحة ($\int a\,dt$) هي التغير في السرعة.
الميل هو مشتق؛ المساحة هي تكامل – العمليتان هما معكوسان هنا.
الموضع والسرعة والتسارع مرتبطة بالاشتقاق Explore · استكشفExplore the velocity–time graph · استكشف رسم السرعة-الزمن
Change the start velocity and acceleration. The slope of a $v$–$t$ line is the acceleration $a=\tfrac{dv}{dt}$, and the area underneath is the displacement $\Delta x=\int v\,dt$ — slope and area are the graphical faces of the derivative and the integral. · غيّر السرعة الابتدائية والتسارع. الميل لخط $v$–$t$ هو التسارع $a=\tfrac{dv}{dt}$، والمساحة تحته هي الإزاحة $\Delta x=\int v\,dt$ — فالميل والمساحة هما الوجه البياني للمشتقة والتكامل.
1.4
Reference Frames and Relative Motion · إطارات المرجع والحركة النسبية
Syllabus · المنهج
EnglishLearning Objective 1.4.A: Describe the reference frame of a given observer.
- 1.4.A.1 The choice of reference frame will determine the direction and magnitude of quantities measured by an observer in that reference frame.
Learning Objective 1.4.B: Describe the motion of objects as measured by observers in different inertial reference frames.
- 1.4.B.1 Measurements from a given reference frame may be converted to measurements from another reference frame.
- 1.4.B.2 The observed velocity of an object results from the combination of the object's velocity and the velocity of the observer's reference frame.
- 1.4.B.2.i Combining the motion of an object and the motion of an observer in a given reference frame involves the addition or subtraction of vectors.
- 1.4.B.2.ii The acceleration of any object is the same as measured from all inertial reference frames.
Boundary statement: Unless otherwise stated, the frame of reference of any problem may be assumed to be inertial.
العربيةهدف التعلم 1.4.A: وصف إطار المرجع لمراقب معين.
- 1.4.A.1 يحدد اختيار إطار مرجعي اتجاه وكميات الكمية المقاسة من قبل مراقب في ذلك الإطار المرجعي.
الهدف التعليمي 1.4.B: وصف حركة الأجسام كما تقيسها مراقب في إطارات مرجعية قصورية مختلفة.
- 1.4.B.1 يمكن تحويل القياسات من إطار مرجعي محدد إلى قياسات من إطار مرجعي آخر.
- 1.4.B.2 ناتج السرعة الظاهرية لجسم ما هو نتاج دمج سرعة الجسم مع سرعة الإطار المرجعي للمراقب.
- 1.4.B.2.i يتضمن دمج حركة جسم وحركة مراقب في إطار مرجعي معين عملية جمع أو طرح المتجهات.
- 1.4.B.2.ii تسارع أي جسم يكون نفسه عند قياسه من جميع الإطارات المرجعية القصورية.
عبارة الحدود: ما لم يُذكر خلاف ذلك، يمكن افتراض أن الإطار المرجعي لأي مسألة هو إطار قصوري.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishAll motion is relative to a reference frame 参考系. Combine velocities by vector addition: $\vec{v}_{A/C}=\vec{v}_{A/B}+\vec{v}_{B/C}$. This handles boats crossing rivers and passengers on moving vehicles – relative motion 相对运动 problems. Read the subscripts as a chain: "A relative to B" plus "B relative to C" gives "A relative to C".
Worked example. A boat that moves at $4.0\ \text{m/s}$ in still water heads straight across a river flowing at $3.0\ \text{m/s}$. Relative to the ground the boat moves at $\sqrt{4.0^2+3.0^2}=5.0\ \text{m/s}$, angled downstream. If the river is $80\ \text{m}$ wide, the crossing still takes $t=\dfrac{80}{4.0}=20\ \text{s}$ – only the across-stream component crosses the river; the current just carries the boat $60\ \text{m}$ downstream.
العربيةجميع الحركات نسبية بالنسبة لإطار مرجعي مُعرّف. اجمع السرعات بجمع المتجهات: $\vec{v}_{A/C}=\vec{v}_{A/B}+\vec{v}_{B/C}$. هذا يُعالج عبور القوارب للأنهار والمسافرين في المركبات المتحركة – مسائل الحركة النسبية. اقرأ الفهارس كسلسلة: "A بالنسبة إلى B" زائد "B بالنسبة إلى C" يعطي "A بالنسبة إلى C".
مثال محلول. قارب يتحرك بسرعة $4.0\ \text{m/s}$ في ماء ساكن ويتجه مباشرة عبر نهر جريانه $3.0\ \text{m/s}$. بالنسبة للأرض، يتحرك القارب بسرعة $\sqrt{4.0^2+3.0^2}=5.0\ \text{m/s}$، مائلاً نحو مجرى النهر. إذا كان عرض النهر $80\ \text{m}$، فإن العبور يستغرق لا يزال $t=\dfrac{80}{4.0}=20\ \text{s}$ – فقط المكون المتقاطع مع تيار النهر يعبر النهر؛ بينما يجرّ التيار القارب مسافة $60\ \text{m}$ نحو الأسفل.
1.5
Motion in Two or Three Dimensions · الحركة في بعدين أو ثلاثة أبعاد
Syllabus · المنهج
EnglishLearning Objective 1.5.A: Describe the motion of an object moving in two or three dimensions.
- 1.5.A.1 Motion in two or three dimensions can be analyzed using one-dimensional kinematic relationships if the motion is separated into components.
- 1.5.A.2 Velocity and acceleration may be different in each dimension and may be nonuniform.
- 1.5.A.3 Motion in one dimension may be changed without causing a change in a perpendicular dimension.
- 1.5.A.4 Projectile motion is a special case of two-dimensional motion that has zero acceleration in one dimension and constant, nonzero acceleration in the second dimension.
Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze the motion of an object in two dimensions. AP Physics C: Electricity and Magnetism expects students to also qualitatively describe the motion of a particle in three dimensions.
العربيةهدف التعلم 1.5.A: وصف حركة جسم يتحرك في بعدين أو ثلاثة أبعاد.
- 1.5.A.1 يمكن تحليل الحركة في بعدين أو ثلاثة أبعاد باستخدام العلاقات الحركية أحادية البعد إذا تم فصل الحركة إلى مركبات.
- 1.5.A.2 قد تختلف السرعة والتسارع في كل بُعد وقد تكون غير منتظمة.
- 1.5.A.3 يمكن تغيير الحركة في بُعد واحد دون إحداث تغيير في بُعد عمودي عليه.
- 1.5.A.4 حركة المقذوفات حالة خاصة من الحركة ثنائية الأبعاد تتميز بصفر تسارع في أحد البعدين وتسارع ثابت وغير صفري في البعد الثاني.
عبارة حدودية: يتوقع امتحان AP Physics C: الميكانيكا فقط من الطلاب التحليل الكمي لحركة جسم في بعدين. بينما يتوقع امتحان AP Physics C: الكهرباء والمغناطيس من الطلاب أيضاً الوصف النوعي لحركة جسيم في ثلاثة أبعاد.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishIn two or three dimensions, position is a vector $\vec{r}(t)=\langle x(t),y(t),z(t)\rangle$, and velocity and acceleration are its successive derivatives – each component handled independently.
Worked example. $\vec{r}(t)=\big(2t^2\big)\hat{i}+\big(4t-t^3\big)\hat{j}$ (metres). Differentiating each component: $\vec{v}=4t\,\hat{i}+(4-3t^2)\,\hat{j}$ and $\vec{a}=4\,\hat{i}-6t\,\hat{j}$. At $t=1\ \text{s}$: $\vec{v}=4\hat{i}+1\hat{j}$, so the speed is $\sqrt{17}\approx4.1\ \text{m/s}$ – no new physics, just one derivative per component.
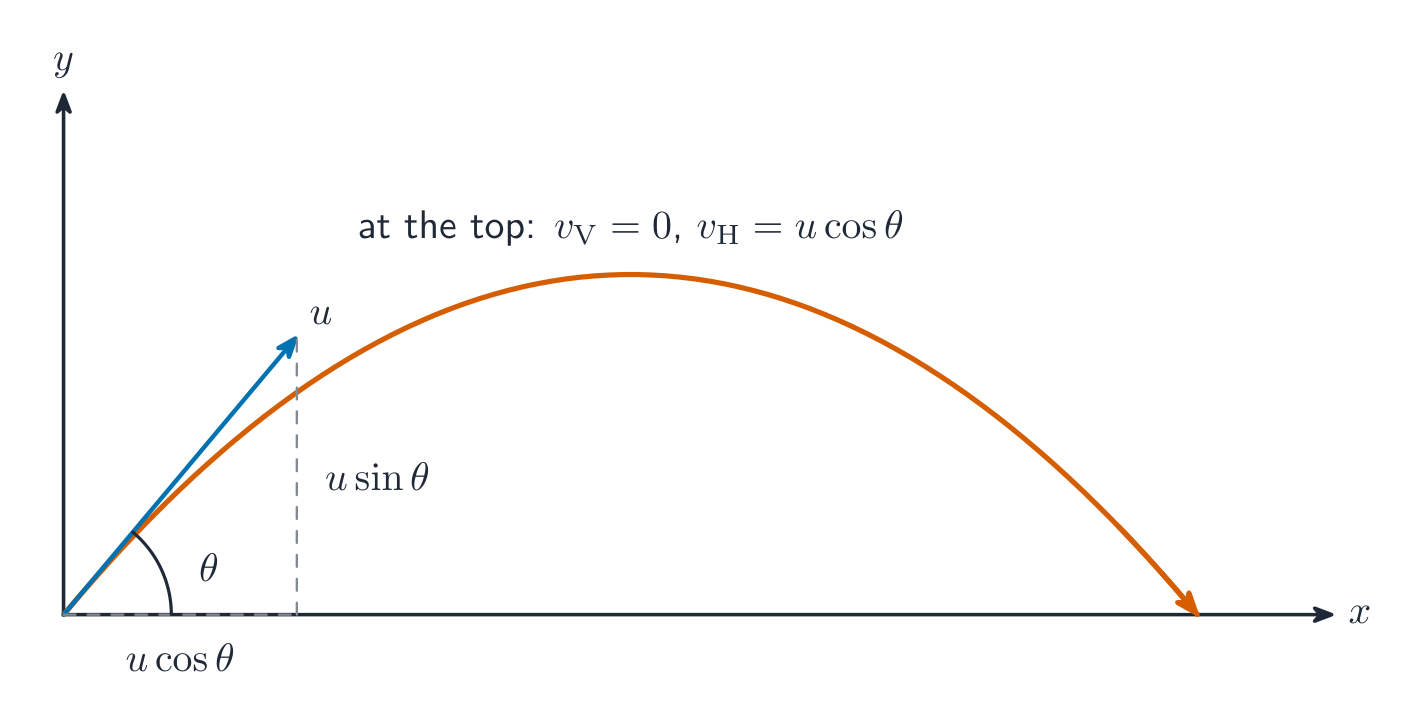
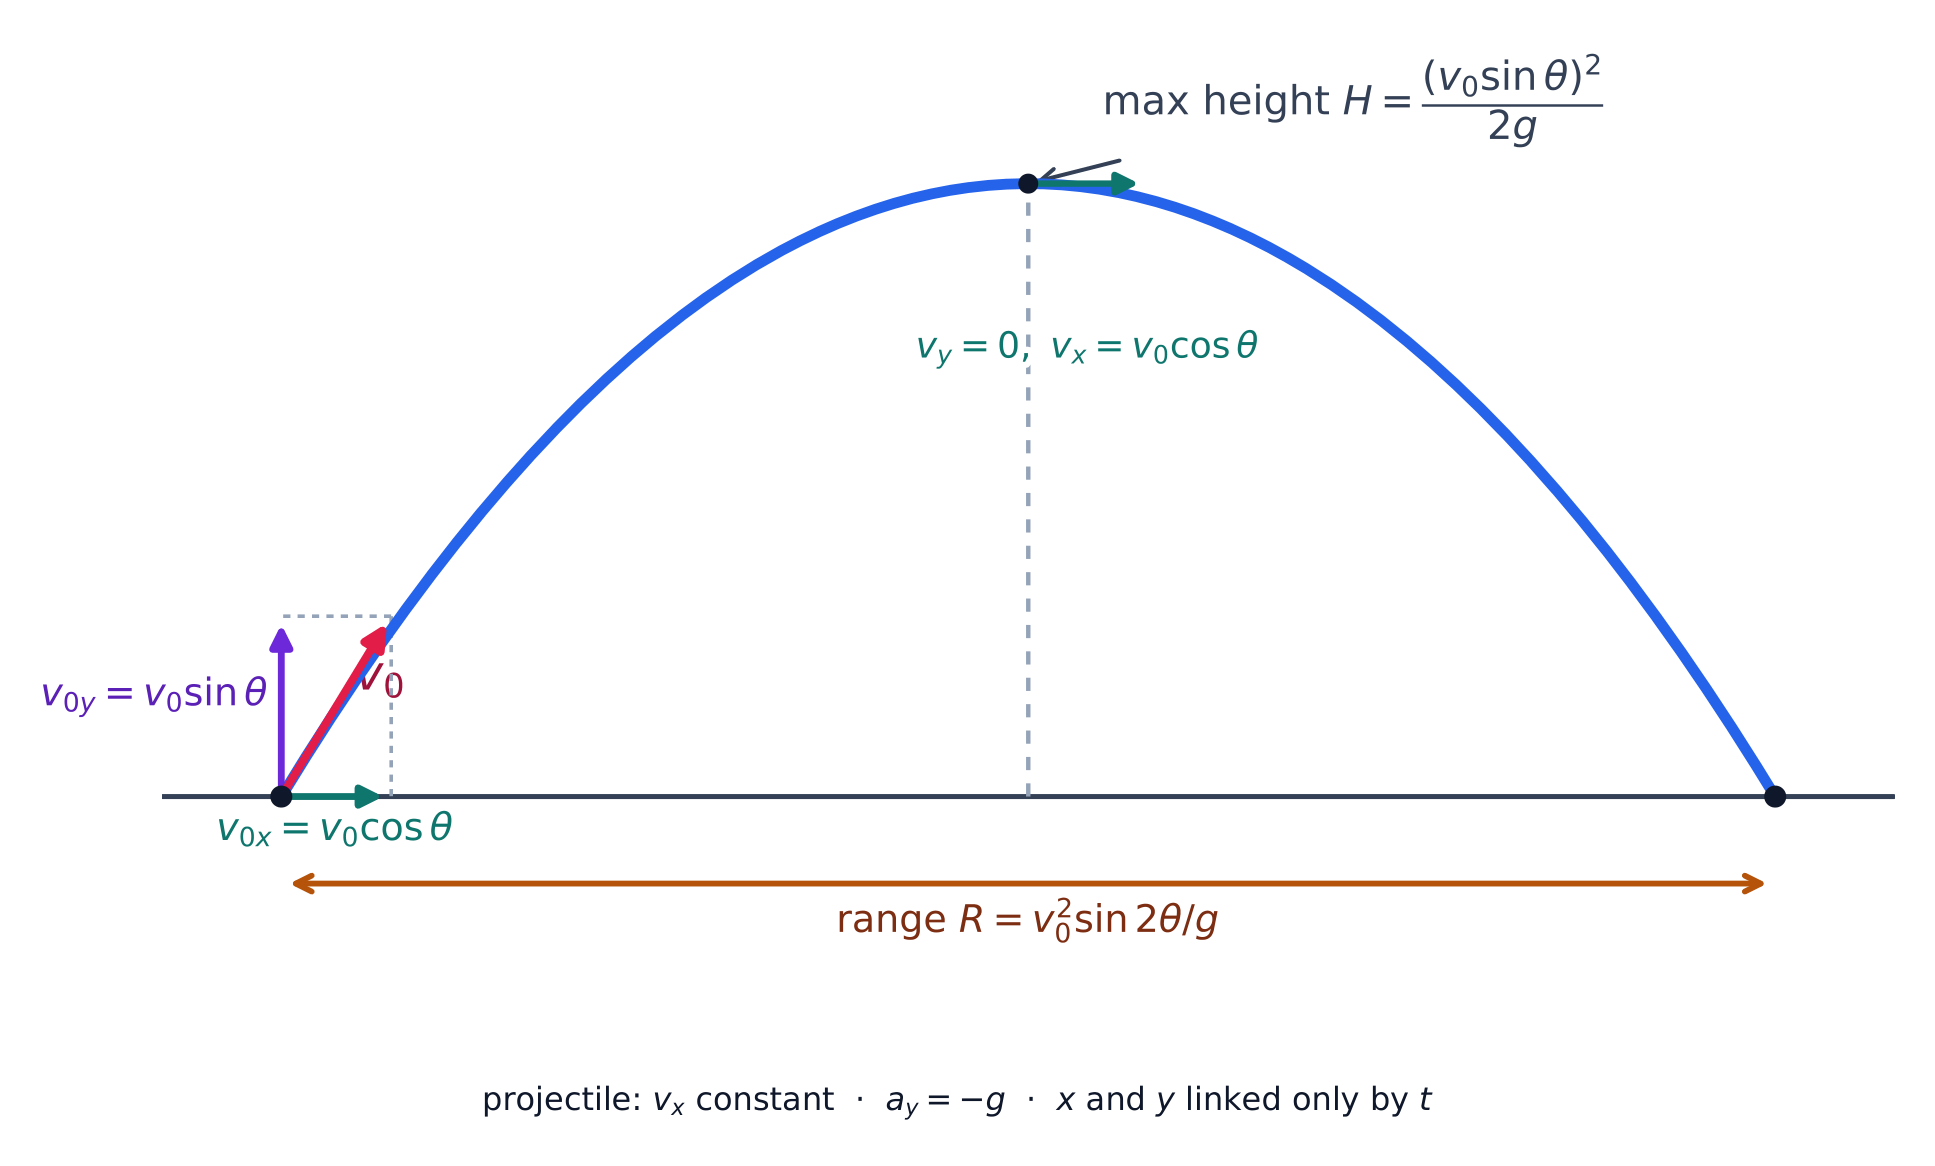
For projectile motion 抛体运动, horizontal and vertical motions are independent, linked only by time $t$: horizontally $a_x=0$ (constant velocity), vertically $a_y=-g$. The path is a parabola. This component method extends to any two-dimensional motion where the accelerations along each axis are known.
Worked example. A ball is launched at $20\ \text{m/s}$, $30^{\circ}$ above the horizontal ($g=9.8\ \text{m/s}^2$). The components are $v_{0x}=20\cos30^{\circ}=17.3\ \text{m/s}$ and $v_{0y}=20\sin30^{\circ}=10\ \text{m/s}$. The vertical motion sets the time: total flight $=\dfrac{2v_{0y}}{g}=\dfrac{20}{9.8}=2.0\ \text{s}$, maximum height $=\dfrac{v_{0y}^2}{2g}=5.1\ \text{m}$, and range $=v_{0x}\times2.0=35\ \text{m}$.
العربيةفي بعدين أو ثلاثة أبعاد، الموضع هو متجه $\vec{r}(t)=\langle x(t),y(t),z(t)\rangle$، والسرعة والتسارع هما مشتقاته المتتالية – كل مكون يتم التعامل معه بشكل مستقل.
مثال محلول. $\vec{r}(t)=\big(2t^2\big)\hat{i}+\big(4t-t^3\big)\hat{j}$ (أمتار). باشتقاق كل مكون: $\vec{v}=4t\,\hat{i}+(4-3t^2)\,\hat{j}$ و $\vec{a}=4\,\hat{i}-6t\,\hat{j}$. عند $t=1\ \text{s}$: $\vec{v}=4\hat{i}+1\hat{j}$، لذا السرعة هي $\sqrt{17}\approx4.1\ \text{m/s}$ – لا فيزياء جديدة، مجرد مشتق واحد لكل مكون.
مقذوف يُطلق بزاوية: الحركات الأفقية والعمودية مستقلة بالنسبة للحركة المقذوفة، الحركات الأفقية والرأسية مستقلة، ترتبطان فقط بالزمن $t$: أفقيًا $a_x=0$ (سرعة ثابتة)، رأسيًا $a_y=-g$. المسار هو قطع مكافئ. يمتد هذه الطريقة المكوّناتية إلى أي حركة ثنائية الأبعاد حيث تسارعات المحاور المعروفة.
مثال محلول. رمية تُطلق بسرعة $20\ \text{m/s}$، بزاوية $30^{\circ}$ فوق الأفقي ($g=9.8\ \text{m/s}^2$). المركبات هي $v_{0x}=20\cos30^{\circ}=17.3\ \text{m/s}$ و$v_{0y}=20\sin30^{\circ}=10\ \text{m/s}$. يحدد الحركة الرأسية الوقت: إجمالي زمن الطيران $=\dfrac{2v_{0y}}{g}=\dfrac{20}{9.8}=2.0\ \text{s}$، أقصى ارتفاع $=\dfrac{v_{0y}^2}{2g}=5.1\ \text{m}$، والمدى $=v_{0x}\times2.0=35\ \text{m}$.
قذيفة تُطلق بزاوية: مكونات السرعة، أقصى ارتفاع، ومدى Explore · استكشفExplore projectile motion · استكشف حركة المقذوفات
Fire the projectile, then vary the angle and speed. The horizontal motion is steady while gravity acts only downward — together they trace a parabola. Find the angle that gives the greatest range (it peaks near $45^\circ$), and try the Moon. · أطلق المقذوف، ثم غيّر الزاوية والسرعة. الحركة الأفقية منتظمة بينما تعمل الجاذبية فقط لأسفل — معًا يرسمان قطعًا مكافئًا. جد الزاوية التي تعطي أقصى مدى (تصل للذروة بالقرب من $45^\circ$)، وحاول القمر الصناعي.
1.5
Exam tips · نصائح للامتحان
English- Resolve every vector into components before adding — never add magnitudes at an angle directly.
- On Physics C you are expected to use calculus: velocity is $\vec v=\tfrac{d\vec r}{dt}$ and acceleration $\vec a=\tfrac{d\vec v}{dt}$; reverse with integration.
- Carry and check units and treat direction with signs (choose a positive axis and stick to it).
- Use the dot product for work-type quantities and the cross product for torque and angular momentum.
- Sketch the vectors — a diagram catches sign and direction errors the algebra hides.
العربية- حلل كل متجه إلى مكونات قبل جمعه – لا تجمع المقدارات الزاوية مباشرة.
- في فيزياء C يُتوقع منك استخدام التفاضل والتكامل: السرعة هي $\vec v=\tfrac{d\vec r}{dt}$ والتسارع $\vec a=\tfrac{d\vec v}{dt}$؛ عوّض بالتكامل.
- احتفظ بـوحدات القياس وتحقق منها وعامِل الاتجاه بإشارات (اختر محورًا موجبًا التزم به).
- استخدم الضرب النقطي لكميات الشغل والضرب الاتجاهي للعزم وزخم الزاوية.
- ارسم المتجهات – الرسم البياني يكشف أخطاء الإشارات والاتجاه التي تخفيها الجبر.
-
2
Force and Translational Dynamics · القوة والديناميكا الانتقالية
Watch lesson · شاهد الدرس2.1
Systems and Center of Mass
Syllabus · المنهج
EnglishLearning Objective 2.1.A: Describe the properties and interactions of a system.
- 2.1.A.1 System properties are determined by the interactions between objects within the system.
- 2.1.A.2 If the properties or interactions of the constituent objects within a system are not important in modeling the behavior of the macroscopic system, the system can itself be treated as a single object.
- 2.1.A.3 Systems may allow interactions between constituent parts of the system and the environment, which may result in the transfer of energy or mass.
- 2.1.A.4 Individual objects within a chosen system may behave differently from each other as well as from the system as a whole.
- 2.1.A.5 The internal structure of a system affects the analysis of that system.
- 2.1.A.6 As variables external to a system are changed, the system's substructure may change.
Learning Objective 2.1.B: Describe the location of a system's center of mass with respect to the system's constituent parts.
- 2.1.B.1 For objects or systems with symmetrical mass distributions, the center of mass is located on lines of symmetry.
- 2.1.B.2 The location of a system's center of mass along a given axis can be calculated using the equation
- Equation: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
- 2.1.B.3 For a nonuniform solid that can be considered as a collection of differential masses, $dm$, the solid's center of mass can be calculated using the equation
- Equation: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
- 2.1.B.3.i The linear mass density of a rod or other linear rigid body is the derivative of the rod's mass with respect to the position of the differential mass element on the rigid body.
- Equation: $\lambda = \dfrac{d}{d\ell} m(\ell)$
- 2.1.B.3.ii If a function of mass density is given for a solid, the total mass can be determined by integrating the mass density over the length (one dimension), area (two dimensions), or volume (three dimensions) of the solid. For example:
- Equation: $M_{\text{total}} = \int \rho(r)\, dV$
- 2.1.B.4 A system can be modeled as a singular object that is located at the system's center of mass.
العربيةالهدف التعليمي 2.1.A: وصف خصائص وتفاعلات النظام.
- 2.1.A.1 تُحدد خصائص النظام من خلال التفاعلات بين الأجسام داخل النظام.
- 2.1.A.2 إذا لم تكن خصائص أو تفاعلات الأجسام المكونة للنظام مهمة في نمذجة سلوك النظام العياني، يمكن اعتبار النظام ككائن واحد.
- 2.1.A.3 قد تسمح الأنظمة بالتفاعلات بين أجزاء النظام المكونة والبيئة، مما قد يؤدي إلى انتقال الطاقة أو الكتلة.
- 2.1.A.4 قد تتصرف الأجسام الفردية داخل نظام مختار بشكل مختلف عن بعضها البعض وكذلك عن النظام بأكمله.
- 2.1.A.5 يؤثر البنية الداخلية للنظام على تحليل هذا النظام.
- 2.1.A.6 عندما تتغير المتغيرات الخارجية للنظام، قد تتغير البنية الفرعية للنظام.
الهدف التعليمي 2.1.B: وصف موقع مركز كتلة النظام بالنسبة لأجزائه المكونة.
- 2.1.B.1 بالنسبة للأجسام أو الأنظمة ذات التوزيع الكتلي المتماثل، يقع مركز الكتلة على خطوط التماثل.
- 2.1.B.2 يمكن حساب موقع مركز كتلة النظام على طول محور معين باستخدام المعادلة ⟦number⟧
- المعادلة: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
- 2.1.B.3 بالنسبة لجسم صلب غير منتظم يمكن اعتباره مجموعة من الكتل التفاضلية، $dm$، يمكن حساب مركز كتلة الجسم الصلب باستخدام المعادلة
- المعادلة: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
- 2.1.B.3.i الكثافة الخطية للكتلة لعصا أو جسم صلب خطي آخر هي مشتقة كتلة العصا بالنسبة لموضع عنصر الكتلة التفاضلي على الجسم الصلب.
- معادلة: $\lambda = \dfrac{d}{d\ell} m(\ell)$
- 2.1.B.3.ii إذا كانت دالة لكثافة الكتلة معطاة لجسم صلب، يمكن تحديد الكتلة الكلية عن طريق تكامل كثافة الكتلة على طول (بُعد واحد)، مساحة (بعدين)، أو حجم (ثلاثة أبعاد) الجسم الصلب. على سبيل المثال:
- معادلة: $M_{\text{total}} = \int \rho(r)\, dV$
- 2.1.B.4 يمكن نمذجة النظام كجسم مفرد يقع في مركز كتلة النظام.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
A system 系统 is the object or objects you analyze, treated as a point at its center of mass 质心. For a set of masses, $x_{\text{cm}}=\dfrac{\sum m_i x_i}{\sum m_i}$; for a continuous body, $x_{\text{cm}}=\dfrac{1}{M}\int x\,dm$. Only external forces move the center of mass.
Vocabulary · مفردات Train · تدريبEnglish العربية system/ˈsɪstəm/ نظام center of mass/ˈsentə ɒv mæs/ مركز الكتلة 2.2
Forces and Free-Body Diagrams
Syllabus · المنهج
EnglishLearning Objective 2.2.A: Describe a force as an interaction between two objects or systems
- 2.2.A.1 Forces are vector quantities that describe the interactions between objects or systems.
- 2.2.A.1.i A force exerted on an object or system is always due to the interaction of that object or system with another object or system.
- 2.2.A.1.ii An object or system cannot exert a net force on itself.
- 2.2.A.2 Contact forces describe the interaction of an object or system touching another object or system and are macroscopic effects of interatomic electric forces.
Learning Objective 2.2.B: Describe the forces exerted on an object or system using a free-body diagram.
- 2.2.B.1 Free-body diagrams are useful tools for visualizing forces being exerted on a single object or system and for determining the equations that represent a physical situation.
- 2.2.B.2 The free-body diagram of an object or system shows each of the forces exerted on the object or system by the environment.
- 2.2.B.3 Forces exerted on an object or system are represented as vectors originating from the representation of the center of mass, such as a dot. A system is treated as though all of its mass is located at the center of mass.
- 2.2.B.4 A coordinate system with one axis parallel to the direction of acceleration of the object or system simplifies the translation from free-body diagram to algebraic representation. For example, in a free-body diagram of an object on an inclined plane, it is useful to set one axis parallel to the surface of the incline.
Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism only expect students to depict the forces exerted on objects, not the force components on free-body diagrams. On the AP Physics exams, individual forces represented on a free-body diagram must be drawn as individual straight arrows, originating on the dot and pointing in the direction of the force. Individual forces that are in the same direction must be drawn side by side, not overlapping.
العربيةهدف التعلم 2.2.A: وصف القوة كتفاعل بين جسمين أو نظامين.
- 2.2.A.1 القوى كميات متجهة تصف التفاعلات بين الأجسام أو النظم.
- 2.2.A.1.i تكون القوة المؤثرة على جسم أو نظام دائماً نتيجة تفاعل ذلك الجسم أو النظام مع جسم أو نظام آخر.
- 2.2.A.1.ii لا يمكن لجسم أو نظام أن يمارس قوة صافية على نفسه.
- 2.2.A.2 تصف قوى التلامس تفاعل جسم أو نظام يلمس جسمًا أو نظامًا آخر، وهي تأثيرات عيانية لقوى كهربائية بين الذرات.
الهدف التعليمي 2.2.B: وصف القوى المؤثرة على جسم أو نظام باستخدام مخطط الجسم الحر.
- 2.2.B.1 تُعد مخططات الجسم الحر أدوات مفيدة لتصوير القوى المؤثرة على جسم أو نظام واحد ولتحديد المعادلات التي تمثل الحالة الفيزيائية.
- 2.2.B.2 يوضح مخطط الجسم الحر كل القوى المؤثرة على الجسم أو النظام بواسطة البيئة المحيطة به.
- 2.2.B.3 يتم تمثيل القوى المؤثرة على جسم أو نظام كمتجهات تنطلق من تمثيل مركز الكتلة، مثل نقطة. يُعامل النظام وكأن كتلته كلها تقع في مركز الكتلة.
- 2.2.B.4 تبسيط نظام إحداثي يحتوي على محور موازٍ لاتجاه تسارع الجسم أو النظام يسهّل التحويل من مخطط الجسم الحر إلى التمثيل الجبري. على سبيل المثال، في مخطط جسم حر لجسم على سطح مائل، يكون من المفيد جعل أحد المحاور موازيًا لسطح الانحدار.
عبارة الحدود: يقتصر امتحان AP Physics C: الميكانيكا وAP Physics C: الكهرباء والمغناطيسية على تمثيل القوى المؤثرة على الأجسام، ولا يتطلب رسم مركبات القوى في مخططات الجسم الحر. في امتحانات AP، يجب رسم القوى الفردية الممثلة في مخطط الجسم الحر作为 أسهم مستقيمة فردية تنطلق من النقطة وتشير في اتجاه القوة. يجب رسم القوى الفردية التي تتجه في نفس الاتجاه بجانب بعضها البعض، وليس فوق بعضها البعض.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
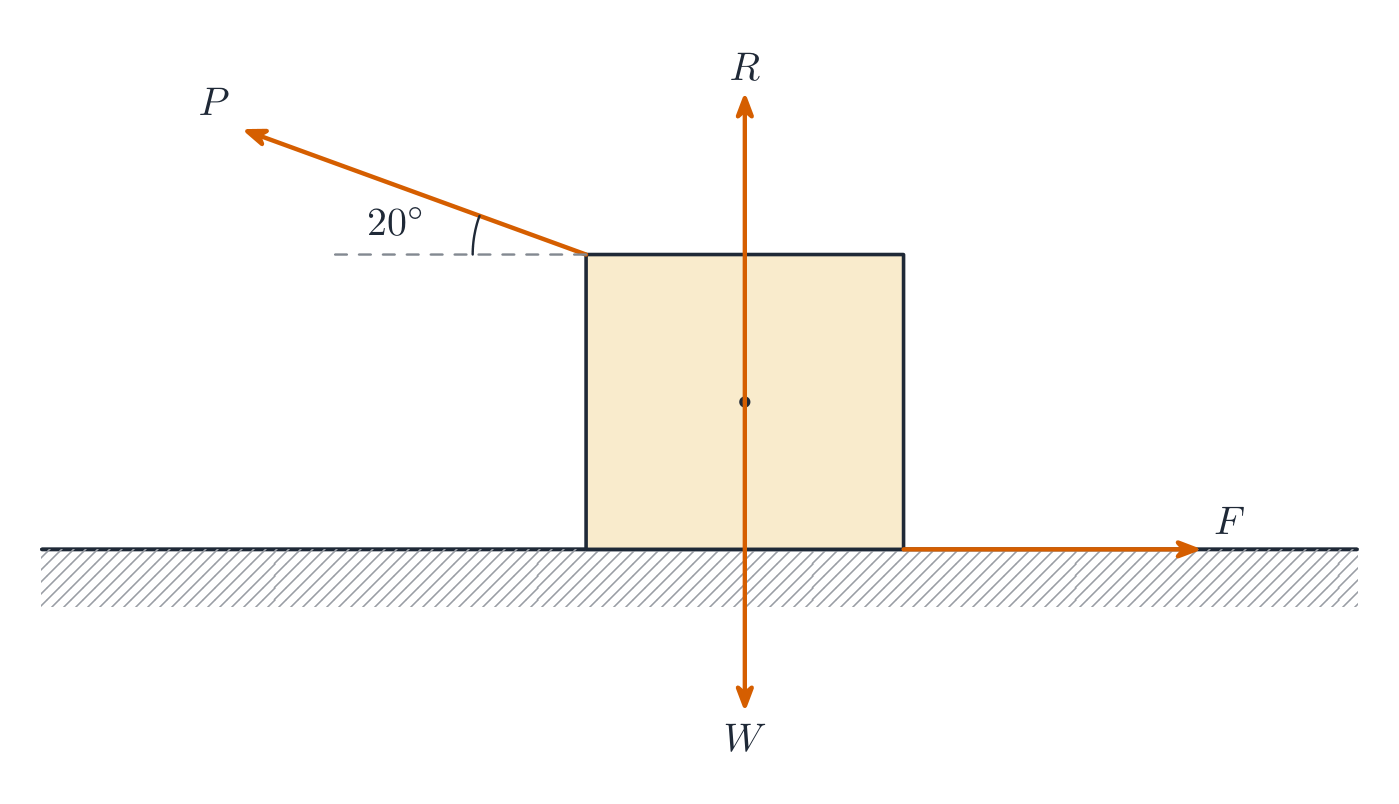
A force 力 is a push or pull (a vector, in newtons). A free-body diagram 受力图 draws one object with an arrow for every force on it – weight, normal, tension, friction, applied, drag. Draw it first; it sets up every dynamics equation.
A free-body diagram shows every force acting on one object Explore · استكشفBalance the forces on a free-body diagram · وزّن القوى في مخطط الجسم الحر
A free-body diagram shows every force on one object as an arrow. The object accelerates only if the forces don't cancel — the net force sets $a=F/m$. · المخطط الحر للجسم يُظهر كل قوة تؤثر على جسم واحد كسهم. يتسارع الجسم فقط إذا لم تلغِ القوى بعضها البعض — حيث يحدد القوة المحصلة $a=F/m$.
Vocabulary · مفردات Train · تدريبEnglish العربية force/fɔːs/ القوة free-body diagram/friː ˈbɒdi ˈdaɪəɡræm/ مخطط الجسم الحر 2.3
Newton's Third Law
Syllabus · المنهج
EnglishLearning Objective 2.3.A: Describe the interaction of two objects or systems using Newton's third law and a representation of paired forces exerted on each object or system.
- 2.3.A.1 Newton's third law describes the interaction of two objects or systems in terms of the paired forces that each exerts on the other.
- Equation: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
- 2.3.A.2 Interactions between objects within a system (internal forces) do not influence the motion of a system's center of mass.
- 2.3.A.3 Tension is the macroscopic net result of forces that infinitesimal segments of a string, cable, chain, or similar system exert on each other in response to an external force.
- 2.3.A.3.i An ideal string has negligible mass and does not stretch when under tension.
- 2.3.A.3.ii The tension in an ideal string is the same at all points within the string.
- 2.3.A.3.iii In a string with nonnegligible mass, tension may not be the same at all points within the string.
- 2.3.A.3.iv An ideal pulley is a pulley that has negligible mass and rotates about an axle through its center of mass with negligible friction.
العربيةهدف التعلم 2.3.A: وصف تفاعل جسمين أو نظامين باستخدام قانون نيوتن الثالث وتمثيل قوى متقابلة مؤثرة على كل جسم أو نظام.
- 2.3.A.1 يصف قانون نيوتن الثالث تفاعل جسمين أو نظامين بدلالة القوى المتقابلة التي يؤثر بها كل منهما على الآخر.
- المعادلة: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
- 2.3.A.2 لا تؤثر التفاعلات بين الأجسام داخل نظام ما (القوى الداخلية) في حركة مركز كتلة ذلك النظام.
- 2.3.A.3 الشد هو النتيجة الكلية المجهرية للقوى التي تؤثر بها مقاطع غير محدودة الصغر من الحبل أو الكابل أو السلسلة أو نظام مماثل على بعضها البعض استجابة لقوة خارجية.
- 2.3.A.3.i الحبل المثالي له كتلة مهملة ولا يتمدد عند تعرضه للشد.
- 2.3.A.3.ii يكون الشد في الحبل المثالي متساوياً عند جميع نقاطه داخل الحبل.
- 2.3.A.3.iii في الحبل ذي الكتلة غير المهملة، قد لا يكون الشد متساوياً عند جميع نقاطه داخل الحبل.
- 2.3.A.3.iv البكرة المثالية هي بكرة ذات كتلة مهملة تدور حول محور يمر بمركز كتلتها مع احتكاك مهمل.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
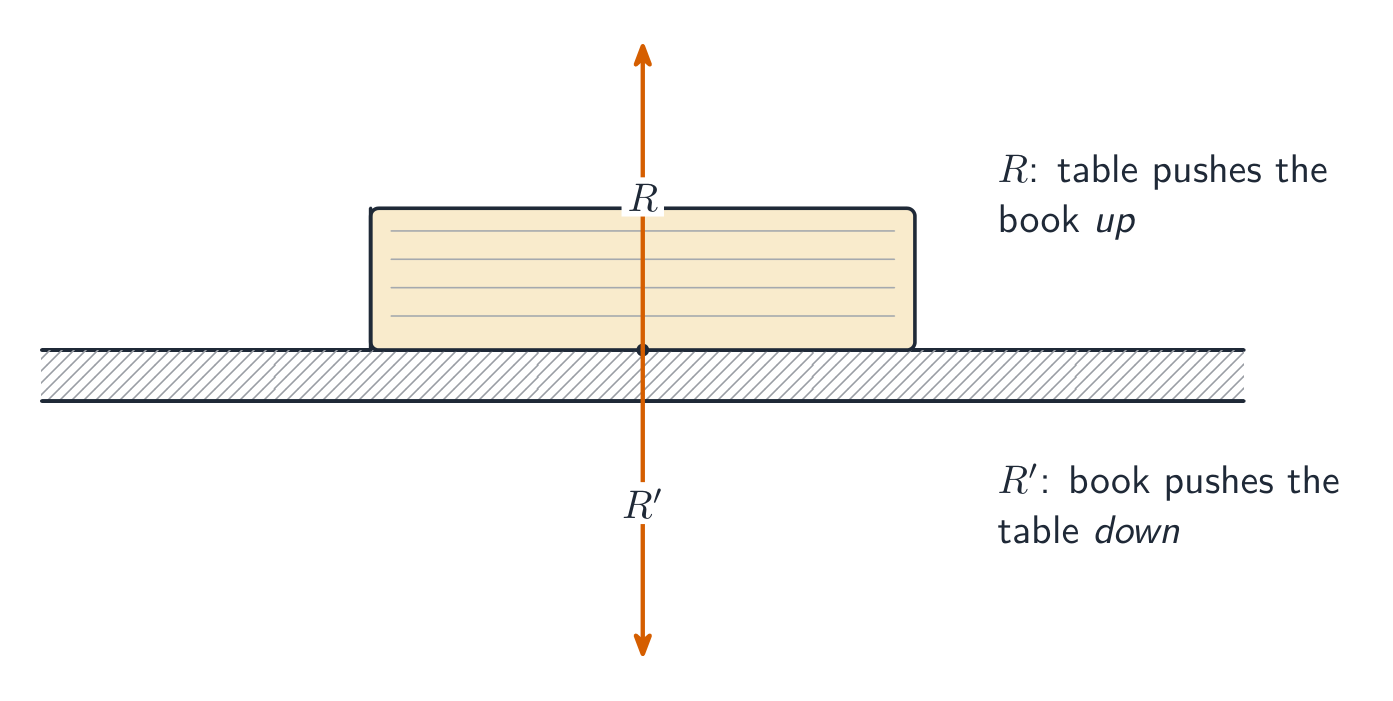
Newton's third law 牛顿第三定律: A pushes B, B pushes back equally and oppositely. The pair acts on different objects, so it never cancels within one free-body diagram.
A Newton's third-law pair: equal and opposite forces on two different objects Vocabulary · مفردات Train · تدريبEnglish العربية Newton's third law/ˈnjuːtnz θɜːd lɔː/ القانون الثالث لنيوTON 2.4
Newton's First Law
Syllabus · المنهج
EnglishLearning Objective 2.4.A: Describe the conditions under which a system's velocity remains constant.
- 2.4.A.1 The net force on a system is the vector sum of all forces exerted on the system.
- 2.4.A.2 Translational equilibrium is the configuration of forces such that the net force exerted on a system is zero.
- Derived equation: $\sum \vec{F}_i = 0$
- 2.4.A.3 Newton's first law states that if the net force exerted on a system is zero, the velocity of that system will remain constant.
- 2.4.A.4 Forces may be balanced in one dimension but unbalanced in another. The system's velocity will change only in the direction of the unbalanced force.
- 2.4.A.5 An inertial reference frame is one from which an observer would verify Newton's first law of motion.
العربيةهدف التعلم 2.4.A: وصف الظروف التي تظل فيها سرعة النظام ثابتة.
- 2.4.A.1 محصلة القوى المؤثرة على النظام هي المجموع الاتجاهي لكل القوى المؤثرة عليه.
- 2.4.A.2 الاتزان الانتقالي هو حالة القوى بحيث تكون محصلة القوى المؤثرة على النظام مساوية للصفر.
- معادلة مستنتجة: $\sum \vec{F}_i = 0$
- 2.4.A.3 ينص قانون نيوتن الأول على أنه إذا كانت محصلة القوى المؤثرة على نظام ما تساوي الصفر، فإن سرعة ذلك النظام ستبقى ثابتة.
- 2.4.A.4 يمكن أن تكون القوى متوازنة في بُعد واحد وغير متوازنة في بُعد آخر. ستتغير سرعة النظام فقط في اتجاه القوة غير المتوازنة.
- 2.4.A.5 الإطار المرجعي القصوري هو إطار يتحقق منه المراقب قانون نيوتن الأول للحركة.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Newton's first law (inertia 惯性): with zero net force 合力, velocity stays constant – the object is in translational equilibrium 平动平衡.
Vocabulary · مفردات Train · تدريبEnglish العربية inertia/ɪˈnɜːʃə/ القصور الذاتي net force/net fɔːs/ القوة المحصلة translational equilibrium/trænˈsleɪʃənl ˌiːkwɪˈlɪbrɪəm/ التوازن الانتقالي 2.5
Newton's Second Law
Syllabus · المنهج
EnglishLearning Objective 2.5.A: Describe the conditions under which a system's velocity changes.
- 2.5.A.1 Unbalanced forces are a configuration of forces such that the net force exerted on a system is not equal to zero.
- 2.5.A.2 Newton's second law of motion states that the acceleration of a system's center of mass has a magnitude proportional to the magnitude of the net force exerted on the system and is in the same direction as that net force.
- Equation: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
- 2.5.A.3 The velocity of a system's center of mass will only change if a nonzero net external force is exerted on that system.
العربيةهدف التعلم 2.5.A: وصف الظروف التي تتغير فيها سرعة النظام.
- 2.5.A.1 القوى غير المتوازنة هي حالة من القوى تكون فيها محصلة القوى المؤثرة على النظام لا تساوي الصفر.
- 2.5.A.2 ينص قانون نيوتن الثاني للحركة على أن تسارع مركز كتلة النظام له مقدار متناسب طردياً مع مقدار محصلة القوى المؤثرة على النظام ويكون في نفس اتجاه تلك المحصلة.
- المعادلة: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
- 2.5.A.3 لن تتغير سرعة مركز كتلة نظام ما إلا إذا أثرت عليه محصلة قوى خارجية غير صفرية.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
The general form uses momentum:
$$\sum\vec{F}=\frac{d\vec{p}}{dt}=m\vec{a}\ \ (\text{for constant mass}).$$Apply it one axis at a time. When forces depend on velocity or position, this becomes a differential equation 微分方程 to solve.Worked example. A $2.0\ \text{kg}$ block slides down a frictionless incline 斜面 at $30^{\circ}$. Only the along-ramp component of gravity drives it, so $a=g\sin30^{\circ}=9.8(0.5)=4.9\ \text{m/s}^2$, independent of the mass.
Worked example (two bodies). A $6.0\ \text{kg}$ cart on a frictionless table is pulled by a string over a light pulley to a hanging $2.0\ \text{kg}$ mass. Treat the pair as one system: only the hanging weight drives it, so $a=\dfrac{2.0(9.8)}{8.0}=2.45\ \text{m/s}^2$. Then isolate the cart alone to find the string tension 张力: $T=6.0(2.45)\approx15\ \text{N}$. System first for $a$, single body for internal forces – that two-step is the standard pattern.
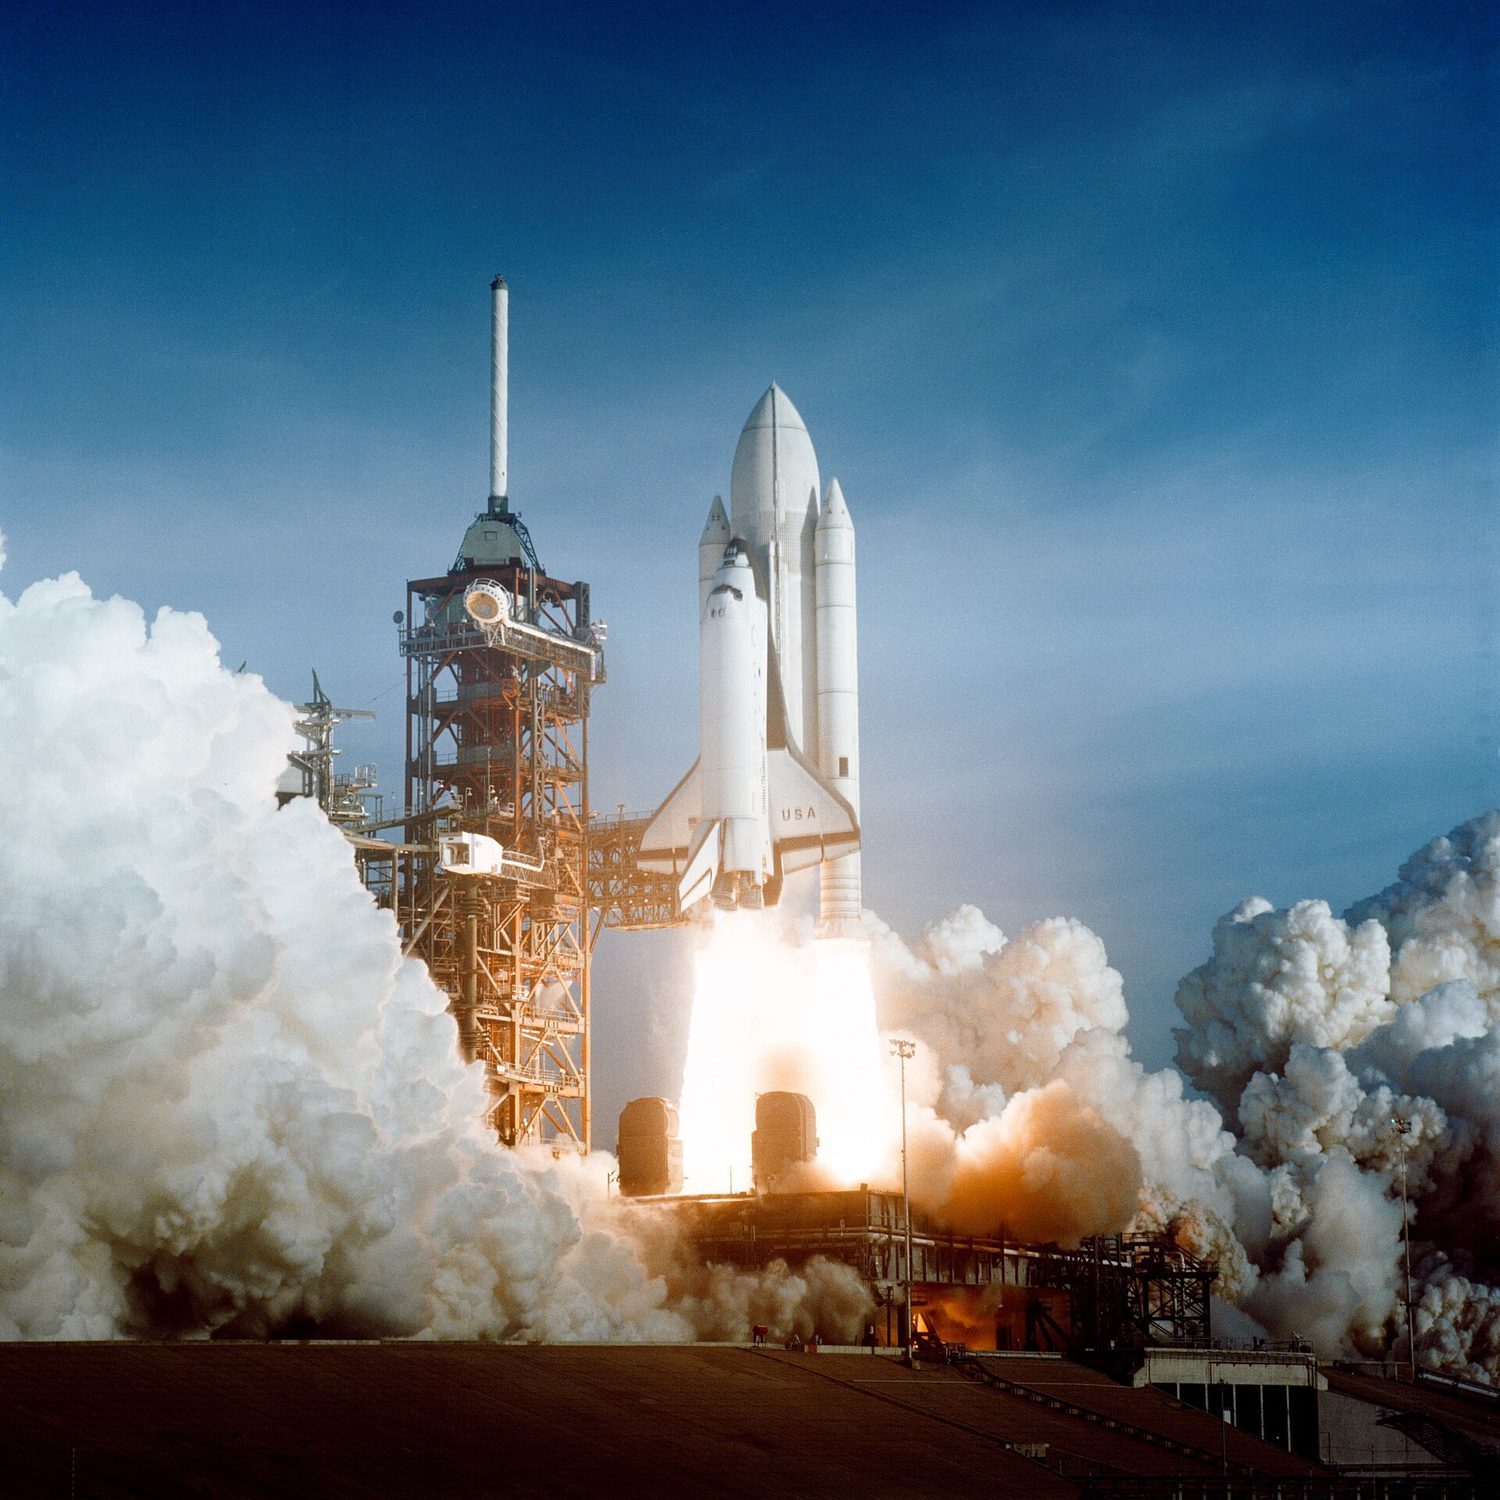
A rocket launch: net force changes momentum — F_net = ma for translational dynamics Vocabulary · مفردات Train · تدريبEnglish العربية differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ معادلة تفاضلية incline/ɪnˈklaɪn/ الميلان tension/ˈtenʃn/ قوة الشد 2.6
Gravitational Force
Syllabus · المنهج
EnglishLearning Objective 2.6.A: Describe the gravitational interaction between two objects or systems with mass.
- 2.6.A.1 Newton's law of universal gravitation describes the gravitational force between two objects or systems as directly proportional to each of their masses and inversely proportional to the square of the distance between the systems' centers of mass.
- Equation: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
- 2.6.A.1.i The gravitational force is attractive.
- 2.6.A.1.ii The gravitational force is always exerted along the line connecting the center of mass of the two interacting systems.
- 2.6.A.1.iii The gravitational force on a system can be considered to be exerted on the system's center of mass.
- 2.6.A.2 A field models the effects of a noncontact force exerted on an object at various positions in space.
- 2.6.A.2.i The magnitude of the gravitational field created by a system of mass $M$ at a point in space is equal to the ratio of the gravitational force exerted by the system on a test object of mass $m$ to the mass of the test object.
- Derived equation: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
- 2.6.A.2.ii If the gravitational force is the only force exerted on an object, the observed acceleration of the object (in $\text{m/s}^2$) is numerically equal to the magnitude of the gravitational field strength (in $\text{N/kg}$) at that location.
- 2.6.A.2.i The magnitude of the gravitational field created by a system of mass $M$ at a point in space is equal to the ratio of the gravitational force exerted by the system on a test object of mass $m$ to the mass of the test object.
- 2.6.A.3 The gravitational force exerted by an astronomical body on a relatively small nearby object is called weight.
- Derived equation: $\text{Weight} = F_g = mg$
Learning Objective 2.6.B: Describe situations in which the gravitational force can be considered constant.
- 2.6.B.1 If the gravitational force between two systems' centers of mass has a negligible change as the relative position of the two systems changes, the gravitational force can be considered constant at all points between the initial and final positions of the systems.
- 2.6.B.2 Near the surface of Earth, the strength of the gravitational field is
- Equation: $g \approx 10\ \text{N/kg}$
Learning Objective 2.6.C: Describe the conditions under which the magnitude of a system's apparent weight is different from the magnitude of the gravitational force exerted on that system.
- 2.6.C.1 The magnitude of the apparent weight of a system is the magnitude of the normal force exerted on the system.
- 2.6.C.2 If the system is accelerating, the apparent weight of the system is not equal to the magnitude of the gravitational force exerted on the system.
- 2.6.C.3 A system appears weightless when there are no forces exerted on the system or when the force of gravity is the only force exerted on the system.
- 2.6.C.4 The equivalence principle states that an observer in a noninertial reference frame is unable to distinguish between an object's apparent weight and the gravitational force exerted on the object by a gravitational field.
Learning Objective 2.6.D: Describe inertial and gravitational mass.
- 2.6.D.1 Objects have inertial mass, or inertia, a property that determines how much an object's motion resists changes when interacting with another object.
- 2.6.D.2 Gravitational mass is related to the force of attraction between two systems with mass.
- 2.6.D.3 Inertial mass and gravitational mass have been experimentally verified to be equivalent.
Learning Objective 2.6.E: Describe the gravitational force exerted on an object by a uniform spherical distribution of mass.
- 2.6.E.1 The net gravitational force exerted on an object by a uniform spherical distribution of mass is the sum of the individual forces from small differential masses that comprise the distribution.
- 2.6.E.2 Newton's shell theorem describes the net gravitational force exerted on an object by a uniform spherical shell of mass.
- 2.6.E.2.i The net gravitational force exerted on an object inside a thin spherical shell is zero.
- 2.6.E.2.ii The net gravitational force exerted on an object outside a thin spherical shell can be determined by treating the shell as a single massive object located at the center of the shell.
- 2.6.E.2.iii An object inside a sphere of uniform density experiences a net gravitational force from only a partial mass of the sphere.
- 2.6.E.2.iv The partial mass of a sphere that contributes to the net gravitational force exerted on an object within that sphere is the portion of the sphere's mass located a distance less than or equal to the object's distance from the center of the sphere and can be calculated using the density of the sphere.
- Derived equation: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
- 2.6.E.3 The gravitational force exerted on an object within a uniform sphere can be shown to be proportional to the object's distance from the sphere's center.
- Derived equation: $F_{g,\text{partial}} = -k r_{\text{partial}}$
Boundary statement: AP Physics C: Mechanics does not expect students to mathematically prove or derive Newton's shell theorem.
العربيةهدف التعلم 2.6.A: وصف التفاعل الجاذب بين جسمين أو نظامين لهما كتلة.
- 2.6.A.1 ينص قانون نيوتن للجذب العام على أن القوة الجاذبة بين جسمين أو نظامين تتناسب طردياً مع كتلة كل منهما وتتناسب عكسياً مع مربع المسافة بين مركزي كتلتهما.
- المعادلة: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
- 2.6.A.1.i القوة الجاذبة قوة تجاذبية.
- 2.6.A.1.ii تُؤثر قوة الجاذبية دائمًا على طول الخط الواصل بين مركز ثقل النظامين المتفاعلين.
- 2.6.A.1.iii يمكن اعتبار أن القوة الجاذبة المؤثرة على نظام ما تُؤثر على مركز كتلته.
- 2.6.A.2 المجال يمثل تأثير قوة غير تلامسية تُؤثر على جسم في مواقع مختلفة في الفضاء.
- 2.6.A.2.i مقدار المجال الجاذب الذي يولده نظام كتلته $M$ عند نقطة في الفضاء يساوي نسبة القوة الجاذبة التي يبذله该系统 على جسم اختبار كتلته $m$ إلى كتلة الجسم الاختبار.
- معادلة مشتقة: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
- 2.6.A.2.ii إذا كانت قوة الجاذبية هي القوة الوحيدة المؤثرة على جسم، فإن التسارع المرصود للجسم (في $\text{m/s}^2$) يساوي عدديًا مقدار شدة مجال الجاذبية (في $\text{N/kg}$) عند تلك الموقع.
- 2.6.A.2.i مقدار المجال الجاذب الذي يولده نظام كتلته $M$ عند نقطة في الفضاء يساوي نسبة القوة الجاذبة التي يبذله该系统 على جسم اختبار كتلته $m$ إلى كتلة الجسم الاختبار.
- 2.6.A.3 تسمى القوة الجاذبة التي يبذرها جرم فلكي على جسم صغير قريب منه بالوزن.
- معادلة مستنتجة: $\text{Weight} = F_g = mg$
هدف التعلم 2.6.B: وصف الحالات التي يمكن فيها اعتبار القوة الجاذبة ثابتة.
- 2.6.B.1 إذا كان التغير في القوة الجاذبة بين مركزي كتلة نظامين مهملاً مع تغير وضعيهما النسبي، فيمكن اعتبار القوة الجاذبة ثابتة عند جميع النقاط بين الوضعين الابتدائي والنهائي للنظامين.
- 2.6.B.2 بالقرب من سطح الأرض، يكون مقدار شدة مجال الجاذبية:
- المعادلة: $g \approx 10\ \text{N/kg}$
هدف التعلم 2.6.C: وصف الظروف التي يكون فيها مقدار الوزن الظاهري لنظام مختلفاً عن مقدار القوة الجاذبة المؤثرة عليه.
- 2.6.C.1 مقدار الوزن الظاهري لنظام هو مقدار القوة العمودية المؤثرة عليه.
- 2.6.C.2 إذا كان النظام يتسارع، فإن وزنه الظاهري لا يساوي مقدار القوة الجاذبة المؤثرة عليه.
- 2.6.C.3 يبدو النظام خفيف الوزن عندما لا توجد قوى مؤثرة عليه أو عندما تكون الجاذبية هي القوة الوحيدة المؤثرة عليه.
- 2.6.C.4 تنص مبدأ التكافؤ على أن المراقب في إطار مرجعي غير قصوري لا يستطيع التمييز بين الوزن الظاهري لجسم ما والقوة الجاذبة المؤثرة عليه من قبل مجال جاذبية.
الهدف التعليمي 2.6.D: وصف الكتلة القصورية والكتلة الجاذبة.
- 2.6.D.1 تمتلك الأجسام كتلة قصورية، أو قصوراً (إنرفيا)، وهي خاصية تحدد مدى مقاومة حركة الجسم للتغيرات عند تفاعله مع جسم آخر.
- 2.6.D.2 ترتبط الكتلة الجاذبة بقوة التجاذب بين نظامين لهما كتلة.
- 2.6.D.3 تم التحقق تجريبياً من تكافؤ الكتلة القصورية والكتلة الجاذبة.
هدف التعلم 2.6.E: وصف قوة الجاذبية المؤثرة على جسم بسبب توزيع كروي منتظم للكتلة.
- 2.6.E.1 محصلة قوة الجاذبية المؤثرة على جسم بسبب توزيع كروي منتظم للكتلة هي مجموع القوى الفردية من كتل تفاضلية صغيرة تشكل هذا التوزيع.
- 2.6.E.2 تصف نظرية القشرة لنيوتن محصلة قوة الجاذبية المؤثرة على جسم بسبب قشرة كروية منتظمة للكتلة.
- 2.6.E.2.i محصلة قوة الجاذبية المؤثرة على جسم داخل قشرة كروية رقيقة تساوي صفرًا.
- 2.6.E.2.ii يمكن تحديد محصلة قوة الجاذبية المؤثرة على جسم خارج قشرة كروية رقيقة عن طريق اعتبار القشرة كجسم ضخم واحد يقع في مركز القشرة.
- 2.6.E.2.iii يتعرض جسم داخل كرة ذات كثافة منتظمة لمحصلة قوة جاذبية ناتجة عن جزء فقط من كتلة الكرة.
- 2.6.E.2.iv الكتلة الجزئية للكرة التي تساهم في محصلة قوة الجاذبية المؤثرة على جسم داخل تلك الكرة هي الجزء من كتلة الكرة الواقع على مسافة أقل من أو تساوي المسافة التي يبعد عنها الجسم عن مركز الكرة، ويمكن حسابها باستخدام كثافة الكرة.
- معادلة مشتقة: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
- 2.6.E.3 يمكن إثبات أن قوة الجاذبية المؤثرة على جسم داخل كرة منتظمة تتناسب طرديًا مع بُعد الجسم عن مركز الكرة.
- معادلة مستنتجة: $F_{g,\text{partial}} = -k r_{\text{partial}}$
عبارة الحدود: لا يتوقع من امتحان AP Physics C: الميكانيكا أن يقوم الطلاب بإثبات أو اشتقاق نظرية القشرة لنيوتن رياضياً.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
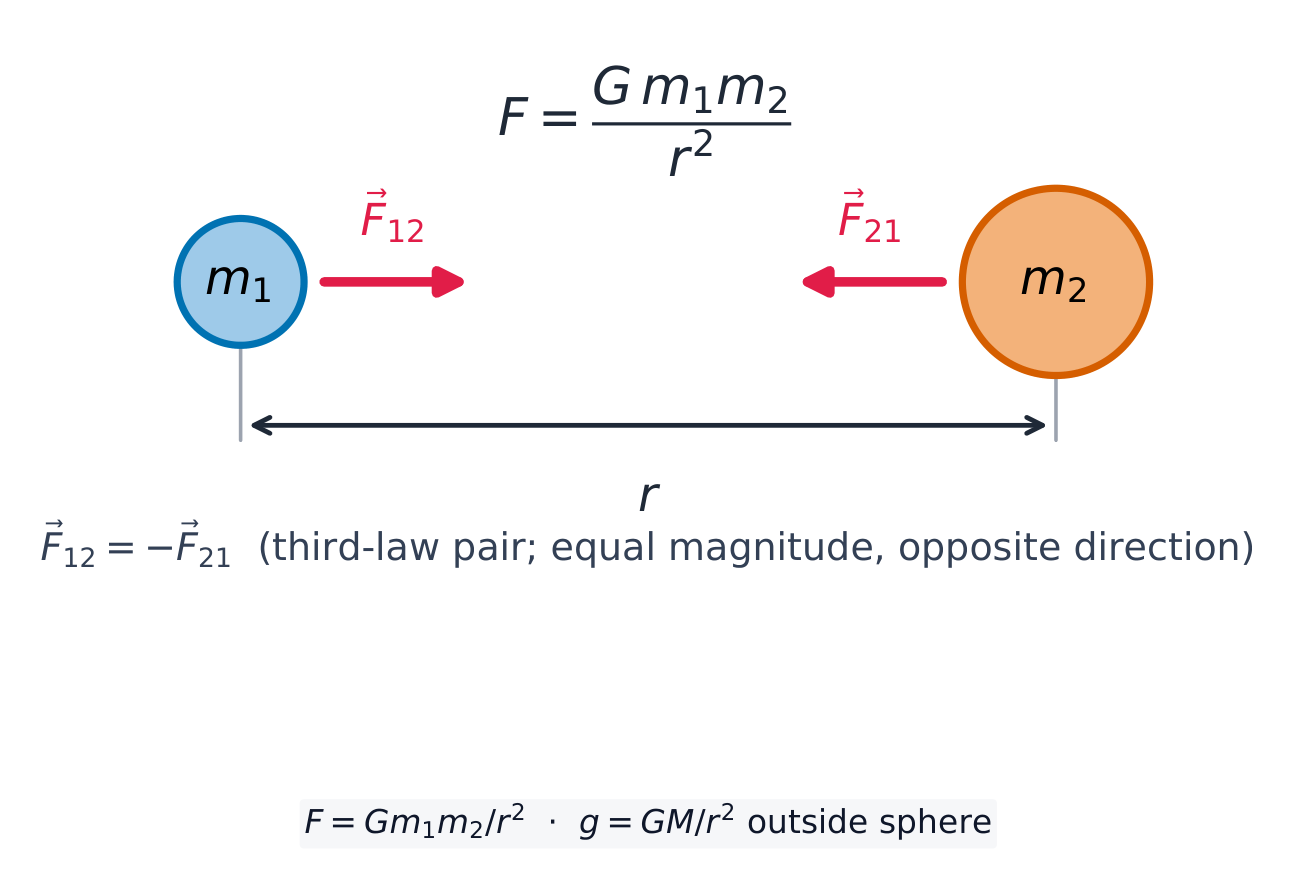
Orbital motion (Kepler's 2nd law) Near a surface, weight is $F_g=mg$. In general, Newton's law of gravitation 万有引力定律:
$$F_g=\frac{Gm_1m_2}{r^2},$$attractive and inverse-square. The gravitational field is $g=\dfrac{GM}{r^2}$.Two masses attract each other with equal, opposite, inverse-square forces along the line joining them Vocabulary · مفردات Train · تدريبEnglish العربية Newton's law of gravitation/ˈnjuːtnz lɔː ɒv ˌɡrævɪˈteɪʃn/ قانون نيوتن للجاذبية 2.7
Kinetic and Static Friction
Syllabus · المنهج
EnglishLearning Objective 2.7.A: Describe kinetic friction between two surfaces.
- 2.7.A.1 Kinetic friction occurs when two surfaces in contact move relative to each other.
- 2.7.A.1.i The kinetic friction force is exerted in a direction opposite the motion of each surface relative to the other surface.
- 2.7.A.1.ii The force of friction between two surfaces does not depend on the size of the surface area of contact.
- 2.7.A.2 The magnitude of the kinetic friction force exerted on an object is the product of the normal force the surface exerts on the object and the coefficient of kinetic friction.
- Equation: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
- 2.7.A.2.i The coefficient of kinetic friction depends on the material properties of the surfaces that are in contact.
- 2.7.A.2.ii Normal force is the perpendicular component of the force exerted on an object by the surface with which it is in contact; it is directed away from the surface.
Learning Objective 2.7.B: Describe static friction between two surfaces.
- 2.7.B.1 Static friction may occur between the contacting surfaces of two objects that are not moving relative to each other.
- 2.7.B.2 Static friction adopts the value and direction required to prevent an object from slipping or sliding on a surface.
- Equation: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
- 2.7.B.2.i Slipping and sliding refer to situations in which two surfaces are moving relative to each other.
- 2.7.B.2.ii There exists a maximum value for which static friction will prevent an object from slipping on a given surface.
- Derived equation: $F_{f,s,\text{max}} = \mu_s F_N$
- 2.7.B.3 The coefficient of static friction is typically greater than the coefficient of kinetic friction for a given pair of surfaces.
العربيةهدف التعلم 2.7.A: وصف الاحتكاك الحركي بين سطحين.
- 2.7.A.1 يحدث الاحتكاك الحركي عندما يتحرك سطحان متلامسان بالنسبة لبعضهما البعض.
- 2.7.A.1.i تُؤثر قوة الاحتكاك الحركي في اتجاه معاكس لحركة كل سطح بالنسبة للسطح الآخر.
- 2.7.A.1.ii لا تعتمد قوة الاحتكاك بين سطحين على مساحة سطح التلامس.
- 2.7.A.2 مقدار قوة الاحتكاك الحركي المؤثرة على جسم هو حاصل ضرب القوة العمودية التي يمارسها السطح على الجسم ومعامل الاحتكاك الحركي.
- المعادلة: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
- 2.7.A.2.i يعتمد معامل الاحتكاك الحركي على الخصائص المادية للأسطح المتلامسة.
- 2.7.A.2.ii القوة العمودية هي المكون العمودي للقوة المؤثرة على جسم بواسطة السطح الذي يتلامس معه؛ وتكون موجهة بعيداً عن السطح.
الهدف التعليمي 2.7.B: وصف الاحتكاك السكوني بين سطحين.
- 2.7.B.1 قد يحدث الاحتكاك السكوني بين أسطح التلامس لجسمين غير متحركين بالنسبة لبعضهما البعض.
- 2.7.B.2 يأخذ الاحتكاك السكوني القيمة والاتجاه اللازمين لمنع انزلاق جسم أو انزلاقه على سطح.
- المعادلة: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
- 2.7.B.2.i يشير الانزلاق والانزلاق إلى مواقف تتحرك فيها سطحان بالنسبة لبعضهما البعض.
- 2.7.B.2.ii يوجد حد أقصى لقيمة الاحتكاك السكوني التي تمنع جسماً من الانزلاق على سطح معين.
- معادلة مشتقة: $F_{f,s,\text{max}} = \mu_s F_N$
- 2.7.B.3 عادة ما يكون معامل الاحتكاك السكوني أكبر من معامل الاحتكاك الحركي لنظام معين من الأسطح.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Friction 摩擦力 opposes sliding along a surface: kinetic 动摩擦 $f_k=\mu_k N$ while sliding, and static 静摩擦 $f_s\le\mu_s N$ up to a maximum before sliding. $N$ is the normal force 法向力. Note the inequality: static friction is only as large as it needs to be, and $\mu_s N$ is its ceiling, not its value.
Worked example. The same block on the same $30^{\circ}$ incline, now with $\mu_k=0.20$. Perpendicular to the ramp: $N=mg\cos30^{\circ}$. Along the ramp: $ma=mg\sin30^{\circ}-\mu_k mg\cos30^{\circ}$, so $a=g(\sin30^{\circ}-0.20\cos30^{\circ})=9.8(0.500-0.173)=3.2\ \text{m/s}^2$ – the mass cancels again.
Explore · استكشفSlide a block down a slope with friction · زُلِّ كتلة على سطح ميل مع احتكاك
Friction opposes motion up to a maximum $\mu N$. Tilt the slope until gravity's pull along it beats static friction and the block starts to slide. · الاحتكاك يعارض الحركة حتى حد أقصى $\mu N$. ميّل السطح حتى يتفوق سحب الجاذبية عليه على الاحتكاك الساكن وتبدأ الكتلة بالزلاق.
Vocabulary · مفردات Train · تدريبEnglish العربية Friction/ˈfrɪkʃn/ الاحتكاك kinetic/kɪˈnetɪk/ حركية static/ˈstætɪk/ ساكنة normal force/ˈnɔːml fɔːs/ القوة العمودية 2.8
Spring Forces
Syllabus · المنهج
EnglishLearning Objective 2.8.A: Describe the force exerted on an object by an ideal spring.
- 2.8.A.1 An ideal spring has negligible mass and exerts a force that is proportional to the change in its length as measured from its relaxed length. A nonideal spring either has nonnegligible mass or exerts a force that is not proportional to the change in its length as measured from its relaxed length.
- 2.8.A.2 The magnitude of the force exerted by an ideal spring on an object is given by Hooke's law:
- Equation: $\vec{F}_s = -k \Delta \vec{x}$
- 2.8.A.3 The force exerted on an object by a spring is always directed toward the equilibrium position of the object–spring system.
Learning Objective 2.8.B: Describe the equivalent spring constant of a combination of springs exerting forces on an object.
- 2.8.B.1 A collection of springs that exert forces on an object may behave as though they were a single spring with an equivalent spring constant $k_{\text{eq}}$.
- 2.8.B.1.i The inverse of the equivalent spring constant of a set of springs in series is equal to the sum of the inverses of the individual spring constants.
- Derived equation: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
- 2.8.B.1.ii The equivalent spring constant of a set of springs arranged in series is smaller than the smallest constituent spring constant.
- 2.8.B.1.iii The equivalent spring constant of a set of springs arranged in parallel is the sum of the individual spring constants.
- Derived equation: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$
- 2.8.B.1.i The inverse of the equivalent spring constant of a set of springs in series is equal to the sum of the inverses of the individual spring constants.
Boundary statement: AP Physics C: Mechanics only expects students to find the effective spring constant of systems of springs that are arranged either in series or in parallel and does not expect students to find the effective spring constant of a system in which springs are arranged in both series and parallel.
العربيةهدف التعلم 2.8.A: وصف القوة المؤثرة على جسم بسبب نابض مثالي.
- 2.8.A.1 النابض المثالي له كتلة مهملة ويؤثر بقوة تتناسب طرديًا مع التغير في طوله كما يُقاس من طوله المريح. أما النابض غير المثالي فهو إما أن يكون له كتلة غير مهملة أو يؤثر بقوة لا تتناسب طرديًا مع التغير في طوله كما يُقاس من طوله المريح.
- 2.8.A.2 يُعطى مقدار القوة المؤثرة من قبل زنبرك مثالي على جسم بواسطة قانون هوك:
- المعادلة: $\vec{F}_s = -k \Delta \vec{x}$
- 2.8.A.3 تكون القوة المؤثرة على جسم بواسطة زنبرك دائماً موجهة نحو وضع التوازن لنظام الجسم-الزنبرك.
هدف التعلم 2.8.B: وصف ثابت النابض المكافئ لمجموعة من النوابض تؤثر بقوات على جسم.
- 2.8.B.1 مجموعة من النوابض التي تؤثر بقوات على جسم قد تتصرف وكأنها نابض واحد بـثابت نابض مكافئ $k_{\text{eq}}$.
- 2.8.B.1.i معكوس ثابت النابض المكافئ لمجموعة من النوابض الموصولة على التوالي يساوي مجموع معكوسات ثوابت النوابض الفردية.
- معادلة مشتقة: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
- 2.8.B.1.ii ثابت النابض المكافئ لمجموعة من النوابض الموصولة على التوالي يكون أصغر من أصغر ثابت نابض مكون لها.
- 2.8.B.1.iii ثابت النابض المكافئ لمجموعة من النوابض الموصولة على التوازي هو مجموع ثوابت النوابض الفردية.
- معادلة مشتقة: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$
- 2.8.B.1.i معكوس ثابت النابض المكافئ لمجموعة من النوابض الموصولة على التوالي يساوي مجموع معكوسات ثوابت النوابض الفردية.
عبارة الحدود: يقتصر امتحان AP Physics C: الميكانيكا على إيجاد ثابت النابض الفعال لأنظمة النوابض الموصولة إما على التوالي أو على التوازي، ولا يتوقع من الطلاب إيجاد ثابت النابض الفعال لأنظمة تكون فيها النوابض موصولة على التوالي وعلى التوازي معًا.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
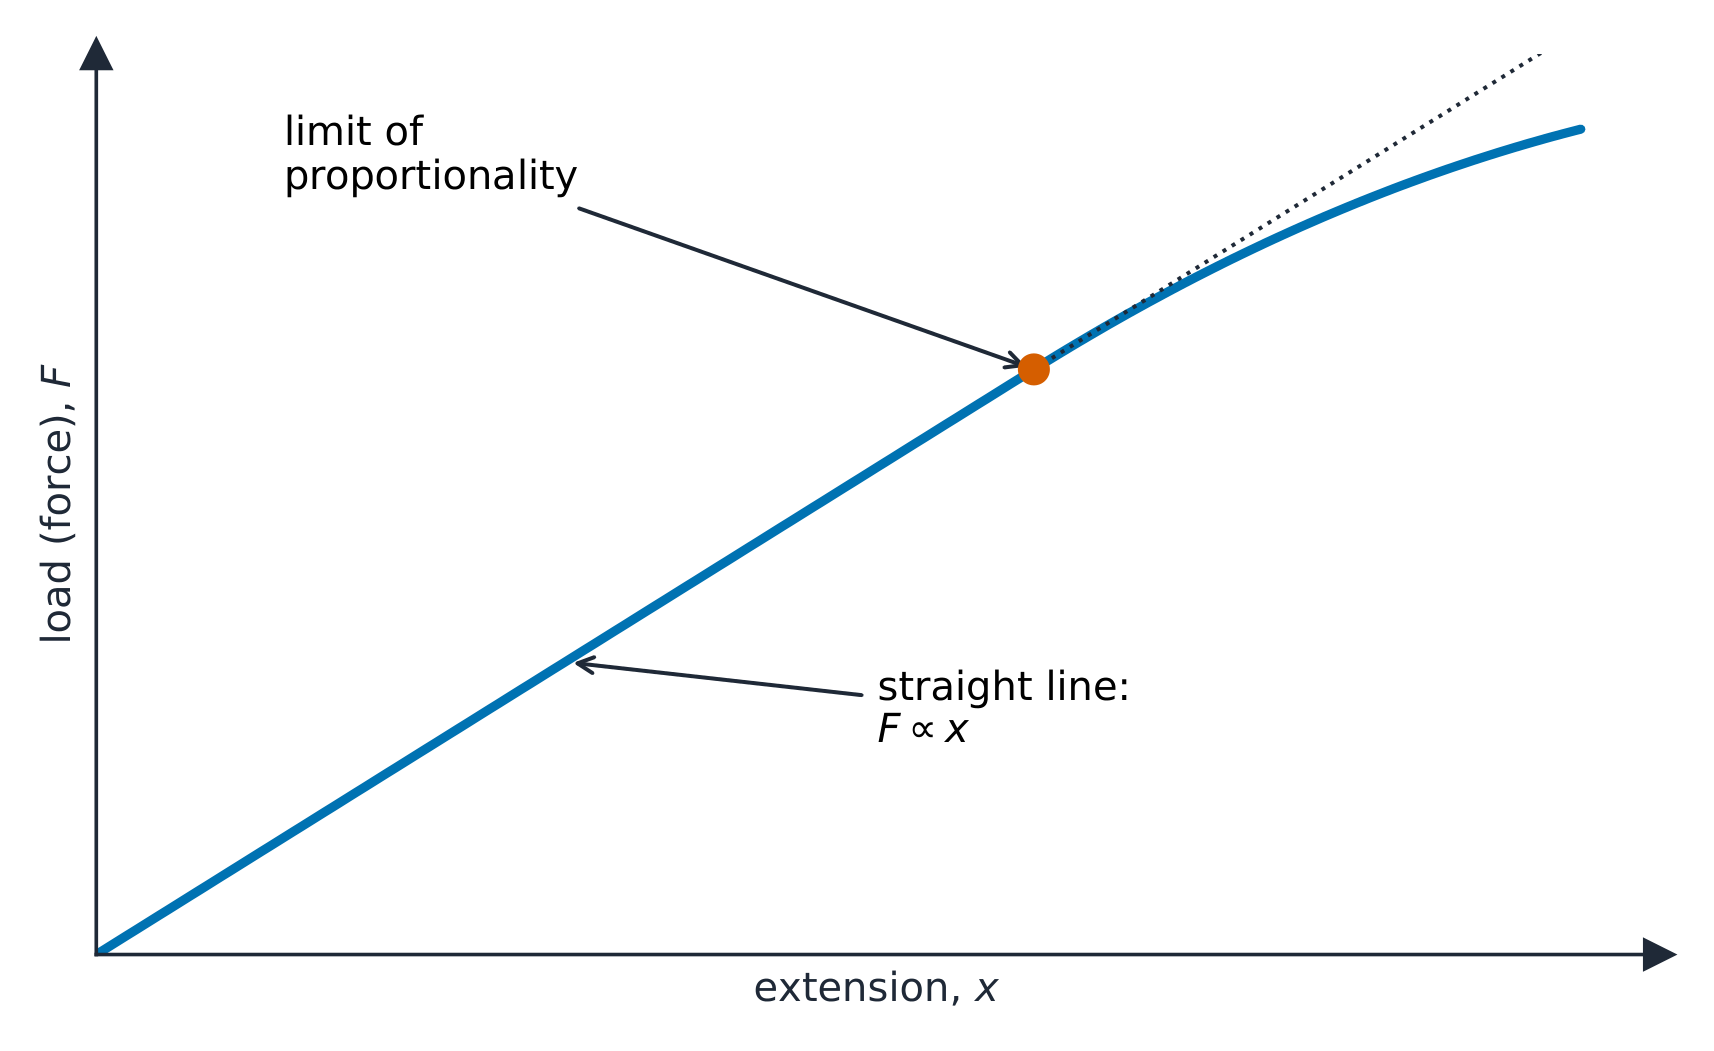
Hooke's law & the elastic limit An ideal spring obeys Hooke's law 胡克定律 $F_s=-kx$, a restoring force set by the spring constant 弹簧劲度系数 $k$. Its stored energy is $U=\tfrac12 kx^2$.
Hooke's law: extension is proportional to load up to the limit of proportionality Combined springs act as one equivalent spring of constant $k_{\text{eq}}$. In parallel (side by side, sharing the load) the constants add, $k_{\text{eq}}=k_1+k_2$ – stiffer than either. In series (end to end) they combine as $\dfrac{1}{k_{\text{eq}}}=\dfrac{1}{k_1}+\dfrac{1}{k_2}$ – softer than the softest one. Two springs pulling a mass from opposite sides also act in parallel, giving a restoring constant $k_1+k_2$. Whichever you have, the SHM period uses $k_{\text{eq}}$: $T=2\pi\sqrt{m/k_{\text{eq}}}$.
Explore · استكشفStretch a spring (Hooke's law) · مدّ نابض (قانون هوك)
A spring's force is proportional to its extension, $F=kx$ (Hooke's law). Pull harder and the extension grows in step — until the spring's limit. · قوة النابض متناسبة مع مدّه، $F=kx$ (قانون هوك). اسحب بقوة أكبر وينتشر المد تدريجياً — حتى reaching limit النابض.
Vocabulary · مفردات Train · تدريبEnglish العربية Hooke's law/hʊks lɔː/ قانون هوك spring constant/sprɪŋ ˈkɒnstənt/ ثابت الزنبرك 2.9
Resistive Forces
Syllabus · المنهج
EnglishLearning Objective 2.9.A: Describe the motion of an object subject to a resistive force.
- 2.9.A.1 A resistive force is defined as a velocity-dependent force in the opposite direction of an object's velocity, for example:
- Equation: $\vec{F}_r = -k\vec{v}$
- 2.9.A.2 Applying Newton's second law to an object upon which a resistive force is exerted results in a differential equation for velocity.
- 2.9.A.2.i Using the method of separation of variables, the velocity can be determined by integrating over the proper limits of integration.
- 2.9.A.2.ii The acceleration or position of a moving object that is subject to a velocity-dependent force may be determined using initial conditions of the object and methods of calculus, once a function for velocity is determined.
- 2.9.A.2.iii The position, velocity, and acceleration as functions of time of an object under the influence of a resistive force of the form $\vec{F}_r = -k\vec{v}$ are exponential and have asymptotes that are determined by the initial conditions of the object and the forces exerted on the object.
- 2.9.A.3 Terminal velocity is defined as the maximum speed achieved by an object moving under the influence of a constant force and a resistive force that are exerted on the object in opposite directions. The terminal condition is reached when the net force exerted on the object is zero.
العربيةهدف التعلم 2.9.A: وصف حركة جسم يخضع لقوة مقاومة.
- 2.9.A.1 تُعرف القوة المقاومة بأنها قوة تعتمد على السرعة وتعمل في عكس اتجاه سرعة الجسم، على سبيل المثال:
- المعادلة: $\vec{F}_r = -k\vec{v}$
- 2.9.A.2 تطبيق قانون نيوتن الثاني على جسم تتعرض له قوة مقاومة يؤدي إلى معادلة تفاضلية للسرعة.
- 2.9.A.2.i باستخدام طريقة فصل المتغيرات، يمكن تحديد السرعة عن طريق التكامل على حدود التكامل المناسبة.
- 2.9.A.2.ii يمكن تحديد تسارع أو موضع جسم متحرك يخضع لقوة تعتمد على السرعة باستخدام الشروط الابتدائية للجسم وطرق التفاضل والتكامل، بمجرد تحديد دالة للسرعة.
- 2.9.A.2.iii الموضع والسرعة والتسارع كدوال للزمن لجسم يتأثر بقوة مقاومة من الشكل $\vec{F}_r = -k\vec{v}$ هي دوال أسية ولها خطوط تقارب تُحدد بالشروط الابتدائية للجسم والقوى المؤثرة عليه.
- 2.9.A.3 تُعرف السرعة النهائية بأنها أقصى سرعة يحققها جسم يتحرك تحت تأثير قوة ثابتة وقوة مقاومة تؤثران على الجسم في اتجاهين متعاكسين. يتم الوصول إلى الحالة النهائية عندما تكون محصلة القوى المؤثرة على الجسم مساوية للصفر.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
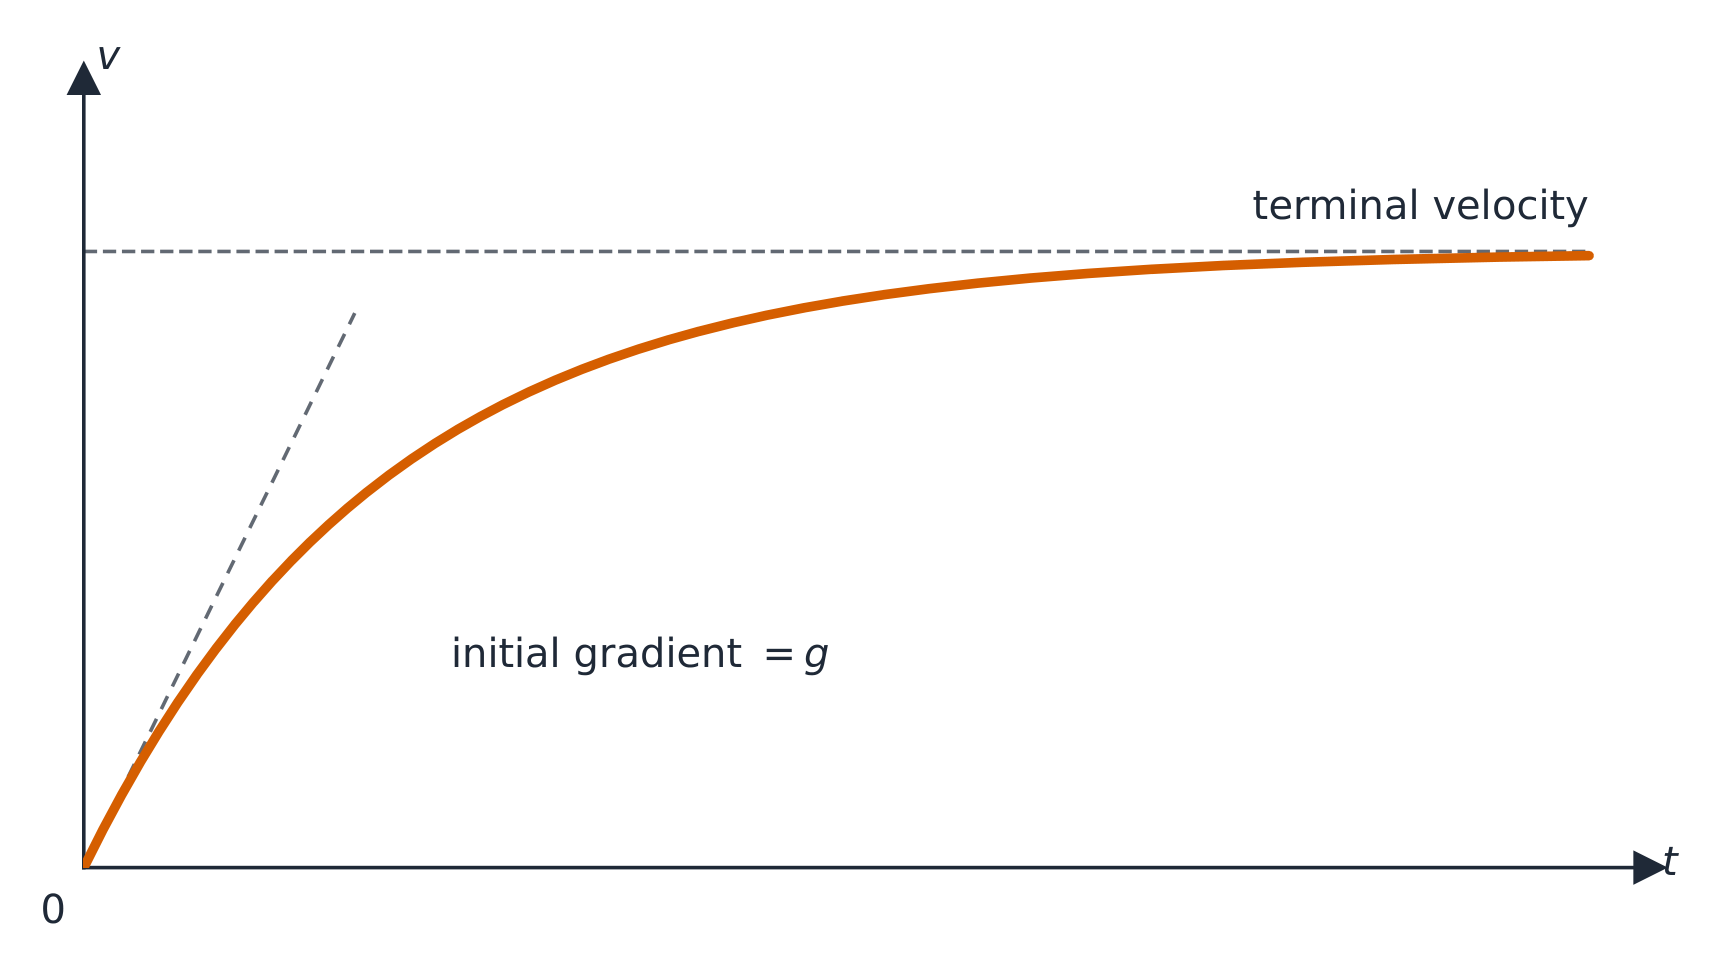
A resistive force 阻力 (drag) opposes motion through a fluid and grows with speed, often modeled as $F=-bv$ or $F=-cv^2$. Newton's second law then gives a differential equation, e.g. $m\dfrac{dv}{dt}=mg-bv$ for a falling object. As speed rises, drag builds until it balances the driving force; the object then stops accelerating and moves at a constant terminal velocity 终极速度, found by setting the net force (and $dv/dt$) to zero.
Worked example. For a falling object with $m\dfrac{dv}{dt}=mg-bv$, the terminal velocity is where $\dfrac{dv}{dt}=0$: $mg=bv_T$, so $v_T=\dfrac{mg}{b}$. With $m=0.10\ \text{kg}$ and $b=0.50\ \text{kg/s}$, $v_T=\dfrac{0.10(9.8)}{0.50}=2.0\ \text{m/s}$.
To get the full motion $v(t)$, separate the variables 分离变量 and integrate from rest:
$$\int_0^{v}\frac{dv'}{mg-bv'}=\int_0^{t}\frac{dt'}{m}\;\Rightarrow\;-\frac{1}{b}\ln\!\frac{mg-bv}{mg}=\frac{t}{m},$$which rearranges to $v(t)=v_T\left(1-e^{-bt/m}\right)$ – the speed rising exponentially toward $v_T$. Showing this integration is the calculus skill a Physics C free-response rewards, not just quoting the final formula.An object falling through a fluid speeds up to a terminal velocity 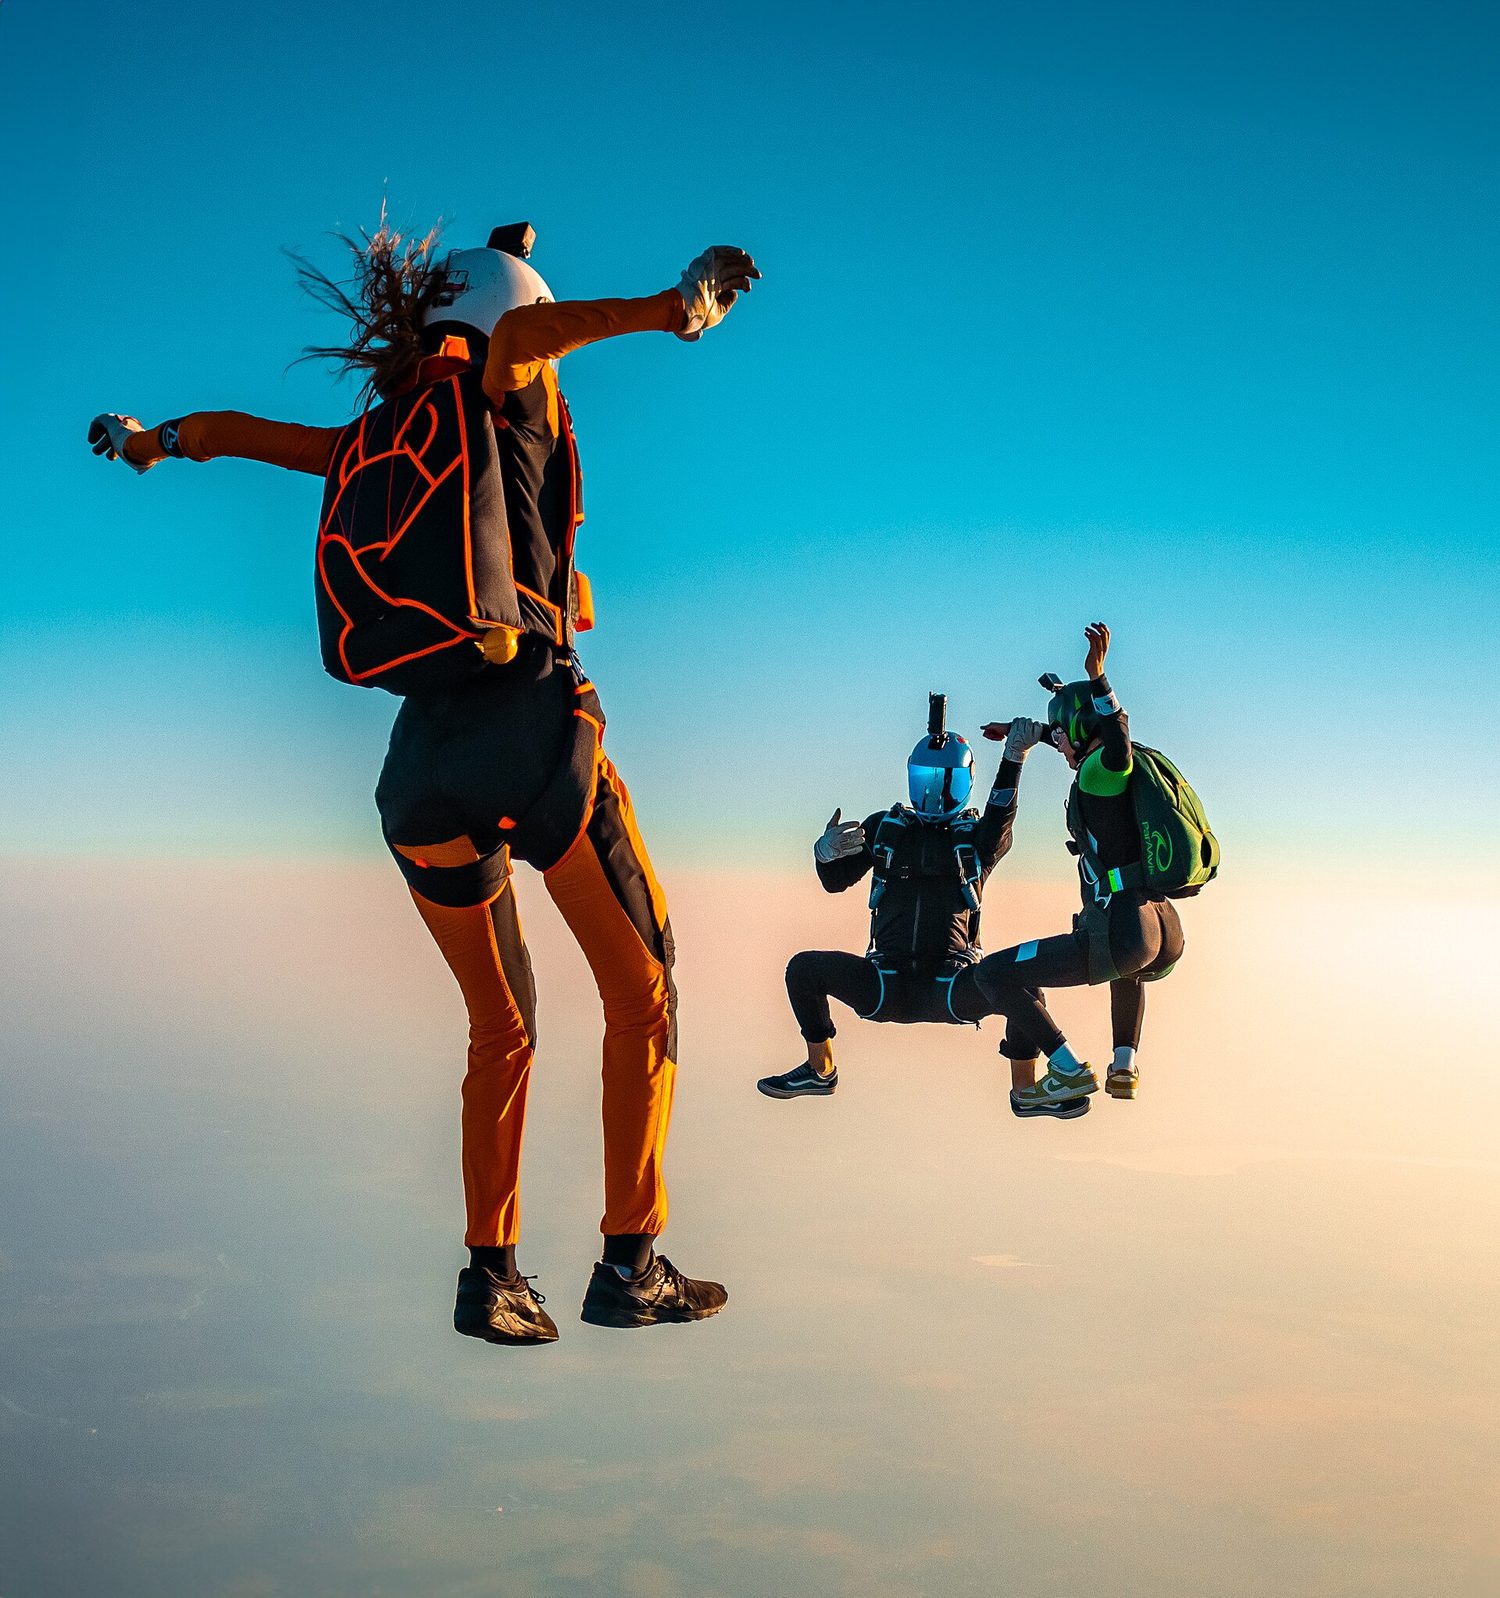
Skydivers in freefall: drag grows with speed until it balances weight at terminal velocity Vocabulary · مفردات Train · تدريبEnglish العربية resistive force/rɪˈzɪstɪv fɔːs/ القوة المقاومة terminal velocity/ˈtɜːmɪnl vəˈlɒsɪti/ السرعة النهائية separate the variables/ˈseprət ðə ˈveərɪəblz/ فصل المتغيرات 2.10
Circular Motion
Syllabus · المنهج
EnglishLearning Objective 2.10.A: Describe the motion of an object traveling in a circular path.
- 2.10.A.1 Centripetal acceleration is the component of an object's acceleration directed toward the center of the object's circular path.
- 2.10.A.1.i The magnitude of centripetal acceleration for an object moving in a circular path is the ratio of the object's tangential speed squared to the radius of the circular path.
- Equation: $a_c = \dfrac{v^2}{r}$
- 2.10.A.1.ii Centripetal acceleration is directed toward the center of an object's circular path.
- 2.10.A.1.i The magnitude of centripetal acceleration for an object moving in a circular path is the ratio of the object's tangential speed squared to the radius of the circular path.
- 2.10.A.2 Centripetal acceleration can result from a single force, more than one force, or components of forces that are exerted on an object in circular motion.
- 2.10.A.2.i At the top of a vertical, circular loop, an object requires a minimum speed to maintain circular motion. At this point, and with this minimum velocity, the gravitational force is the only force that causes the centripetal acceleration.
- Derived equation: $v = \sqrt{gr}$
- 2.10.A.2.ii Components of the static friction force and the normal force can contribute to the net force producing centripetal acceleration of an object traveling in a circle on a banked surface.
- 2.10.A.2.iii A component of tension contributes to the net force producing centripetal acceleration experienced by a conical pendulum.
- 2.10.A.2.i At the top of a vertical, circular loop, an object requires a minimum speed to maintain circular motion. At this point, and with this minimum velocity, the gravitational force is the only force that causes the centripetal acceleration.
- 2.10.A.3 Tangential acceleration is the rate at which an object's speed changes and is directed tangent to the object's circular path.
- 2.10.A.4 The net acceleration of an object moving in a circle is the vector sum of the centripetal acceleration and tangential acceleration.
- 2.10.A.5 The revolution of an object traveling in a circular path at a constant speed (uniform circular motion) can be described using period and frequency.
- 2.10.A.5.i The time to complete one full circular path, one full rotation, or a full cycle of oscillatory motion is defined as period, $T$.
- 2.10.A.5.ii The rate at which an object is completing revolutions is defined as frequency, $f$.
- Equation: $T = \dfrac{1}{f}$
- 2.10.A.5.iii For an object traveling at a constant speed in a circular path, the period is given by the derived equation
- Derived equation: $T = \dfrac{2\pi r}{v}$
Learning Objective 2.10.B: Describe circular orbits using Kepler's third law.
- 2.10.B.1 For a satellite in circular orbit around a central body, the satellite's centripetal acceleration is caused only by gravitational attraction. The period and radius of the circular orbit are related to the mass of the central body.
- Derived equation: $T^2 = \dfrac{4\pi^2}{GM} R^3$
Boundary statement: AP Physics C: Mechanics does not expect students to know Kepler's first or second laws of planetary motion.
العربيةهدف التعلم 2.10.A: وصف حركة جسم يتحرك في مسار دائري.
- 2.10.A.1 التسارع المركزي هو مركب تسارع الجسم الموجه نحو مركز المسار الدائري للجسم.
- 2.10.A.1.i مقدار التسارع المركزي لجسم يتحرك في مسار دائري هو نسبة مربع السرعة المماسية للجسم إلى نصف قطر المسار الدائري.
- معادلة: $a_c = \dfrac{v^2}{r}$
- 2.10.A.1.ii التسارع المركزي موجه نحو مركز المسار الدائري للجسم.
- 2.10.A.1.i مقدار التسارع المركزي لجسم يتحرك في مسار دائري هو نسبة مربع السرعة المماسية للجسم إلى نصف قطر المسار الدائري.
- 2.10.A.2 يمكن أن ينتج التسارع المركزي عن قوة واحدة، أو أكثر من قوة، أو مركبات قوى تُمارس على جسم في حركة دائرية.
- 2.10.A.2.i في أعلى حلقة دائرية رأسية، يحتاج الجسم إلى سرعة دنيا للحفاظ على الحركة الدائرية. عند هذه النقطة، ومع هذه السرعة الدنيا، تكون قوة الجاذبية هي القوة الوحيدة التي تسبب التسارع المركزي.
- معادلة مشتقة: $v = \sqrt{gr}$
- 2.10.A.2.ii يمكن لمركبات قوة الاحتكاك الساكن وقوة رد الفعل أن تساهم في المحصلة المؤثرة التي تنتج التسارع المركزي لجسم يتحرك في دائرة على سطح مائل.
- 2.10.A.2.iii تساهم مركبة الشد في المحصلة المؤثرة التي تنتج التسارع المركزي الذي يتعرض له البندول المخروطي.
- 2.10.A.2.i في أعلى حلقة دائرية رأسية، يحتاج الجسم إلى سرعة دنيا للحفاظ على الحركة الدائرية. عند هذه النقطة، ومع هذه السرعة الدنيا، تكون قوة الجاذبية هي القوة الوحيدة التي تسبب التسارع المركزي.
- 2.10.A.3 التسارع المماسي هو المعدل الذي تتغير به سرعة الجسم وموجه مماسياً للمسار الدائري للجسم.
- 2.10.A.4 المحصلة التسارعية لجسم يتحرك في دائرة هي المجموع الاتجاهي للتسارع المركزي والتسارع المماسي.
- 2.10.A.5 يمكن وصف دوران جسم يتحرك في مسار دائري بسرعة ثابتة (الحركة الدائرية المنتظمة) باستخدام الفترة والتردد.
- 2.10.A.5.i الوقت اللازم لإكمال مسار دائري كامل، دورة كاملة، أو دورة كاملة من الحركة التذبذبية يُعرف بالفترة، $T$.
- 2.10.A.5.ii معدل إتمام الجسم للدورات يُعرف بالتردد، $f$.
- معادلة: $T = \dfrac{1}{f}$
- 2.10.A.5.iii بالنسبة لجسم يتحرك بسرعة ثابتة في مسار دائري، تُعطى الفترة بالمعادلة المستنتجة
- معادلة مشتقة: $T = \dfrac{2\pi r}{v}$
هدف التعلم 2.10.B: وصف المدارات الدائرية باستخدام قانون كبلر الثالث.
- 2.10.B.1 بالنسبة لقمر صناعي في مدار دائري حول جسم مركزي، التسارع المركزي للقمر الصناعي ناتج فقط عن التجاذب الجاذبي. ترتبط الفترة ونصف قطر المدار الدائري بكتلة الجسم المركزي.
- معادلة مستنتجة: $T^2 = \dfrac{4\pi^2}{GM} R^3$
عبارة الحدود: لا يتوقع من امتحان AP Physics C: الميكانيكا أن يعرف الطلاب قانون كبلر الأول أو الثاني لحركة الكواكب.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
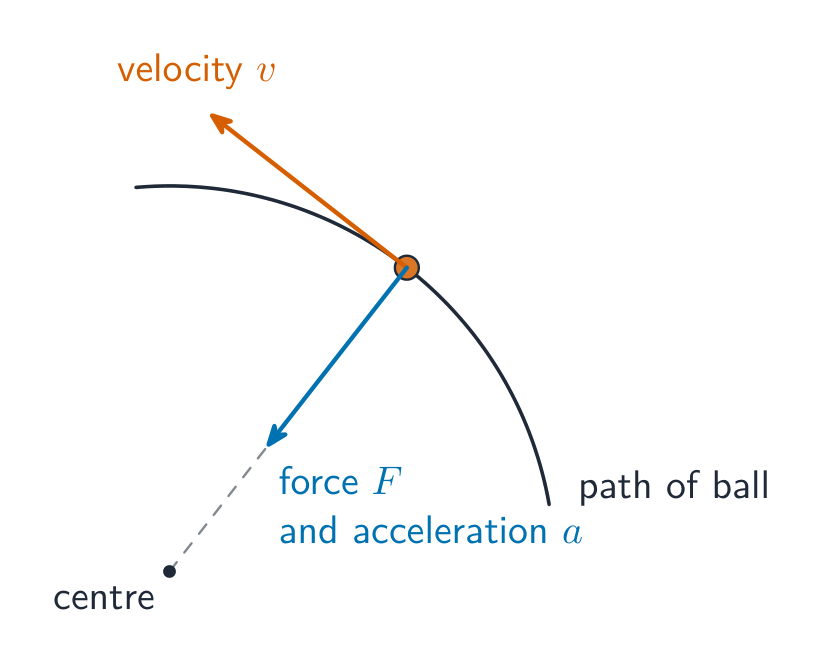
Uniform circular motion Uniform circular motion has a centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}$ pointing to the center, requiring a net inward force $F_c=\dfrac{mv^2}{r}$ supplied by a real force (tension, gravity, friction, normal). There is no outward force. For vertical circles and banked curves, decompose the real forces to find which provides the centripetal requirement.
Worked example. A $0.50\ \text{kg}$ ball is whirled on a $1.0\ \text{m}$ string in a horizontal circle at $3.0\ \text{m/s}$. The string tension supplies the whole centripetal force: $T=\dfrac{mv^2}{r}=\dfrac{0.50(3.0)^2}{1.0}=4.5\ \text{N}$.
Worked example (vertical circle). At the top of a vertical loop of radius $r$, gravity and the normal force both point toward the center: $N+mg=\dfrac{mv^2}{r}$. The slowest possible speed at the top is where the track pushes with nothing at all ($N=0$): $v_{\min}=\sqrt{gr}$. For $r=2.5\ \text{m}$: $v_{\min}=\sqrt{9.8(2.5)}=4.9\ \text{m/s}$. Any slower and the cart leaves the track before the top.
The velocity points along the tangent; the centripetal force points to the centre Vocabulary · مفردات Train · تدريبEnglish العربية centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ التسارع المركزي 2.10
Exam tips
- Locate the center of mass with $x_{cm}=\tfrac{1}{M}\int x\,dm$ (or $\tfrac{\sum m_i x_i}{\sum m_i}$ for point masses) and use $\lambda,\sigma,\rho$ for the mass element.
- The net external force moves the center of mass as if all mass sat there: $\vec F_{net}=M\vec a_{cm}$.
- Define your system clearly — internal forces cancel, so only external forces change its momentum.
- Exploit symmetry to shortcut a center-of-mass integral.
- Distinguish center of mass from center of gravity (identical in a uniform field).
-
3
Work, Energy, and Power · الشغل والطاقة والقوة
Watch lesson · شاهد الدرس3.1
Translational Kinetic Energy · الطاقة الحركية الانتقالية
Syllabus · المنهج
EnglishLearning Objective 3.1.A: Describe the translational kinetic energy of an object in terms of the object's mass and velocity.
- 3.1.A.1 An object's translational kinetic energy is given by the equation
- Equation: $K = \dfrac{1}{2}mv^2$
- 3.1.A.2 Translational kinetic energy is a scalar quantity.
- 3.1.A.3 Different observers may measure different values of the translational kinetic energy of an object, depending on the observer's frame of reference.
العربيةهدف التعلم 3.1.A: وصف الطاقة الحركية الانتقالية لجسم ما بدلالة كتلة الجسم وسرعته.
- 3.1.A.1 تُعطى الطاقة الحركية الانتقالية لجسم ما بالمعادلة
- المعادلة: $K = \dfrac{1}{2}mv^2$
- 3.1.A.2 الطاقة الحركية الانتقالية هي كمية قياسية.
- 3.1.A.3 قد يقيس المراقبون المختلفون قيمًا مختلفة للطاقة الحركية الانتقالية لجسم ما، اعتمادًا على إطار مرجع المراقب.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishKinetic energy 动能 is the energy of motion, a scalar 标量 measured in joules 焦耳 (J):
$$K=\tfrac{1}{2}mv^2.$$It grows with the square of speed – doubling the speed quadruples $K$. One subtlety worth knowing: kinetic energy depends on the observer's reference frame 参考系. A passenger walking down a train has a small $K$ measured inside the train and a huge one measured from the ground – both observers are right, each in their own frame.
العربيةالطاقة الحركية هي طاقة الحركة، وهي كمية قياسية تقاس بـ الجول (J):
$$K=\tfrac{1}{2}mv^2.$$إنها تزداد مع مربع السرعة – مضاعفة السرعة تضاعف $K$ أربع مرات. تفصيل دقيق يستحق المعرفة: الطاقة الحركية تعتمد على الإطار المرجعي للمراقب. راكب يمشي داخل قطار لديه طاقة حركية صغيرة $K$ مقاسة داخل القطار وطاقة هائلة مقاسة من الأرض – كلا المراقبين صحيحان، كل منهما في إطاره الخاص.
3.2
Work · العمل
Syllabus · المنهج
EnglishLearning Objective 3.2.A: Describe the work done on an object or system by a given force or collection of forces.
- 3.2.A.1 Work is the amount of energy transferred into or out of a system by a force exerted on that system over a distance.
- 3.2.A.1.i The work done by a conservative force exerted on a system is path-independent and only depends on the initial and final configurations of that system.
- 3.2.A.1.ii The work done by a conservative force on a system—or the change in the potential energy of the system—will be zero if the system returns to its initial configuration.
- 3.2.A.1.iii Potential energies are associated only with conservative forces.
- 3.2.A.1.iv The work done by a nonconservative force is path-dependent.
- 3.2.A.1.v The most common nonconservative forces are friction and air resistance.
- 3.2.A.2 Work is a scalar quantity that may be positive, negative, or zero.
- 3.2.A.3 The work done on an object by a variable force is calculated using
- Equation: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$, where the integral is taken over the path from point $a$ to point $b$.
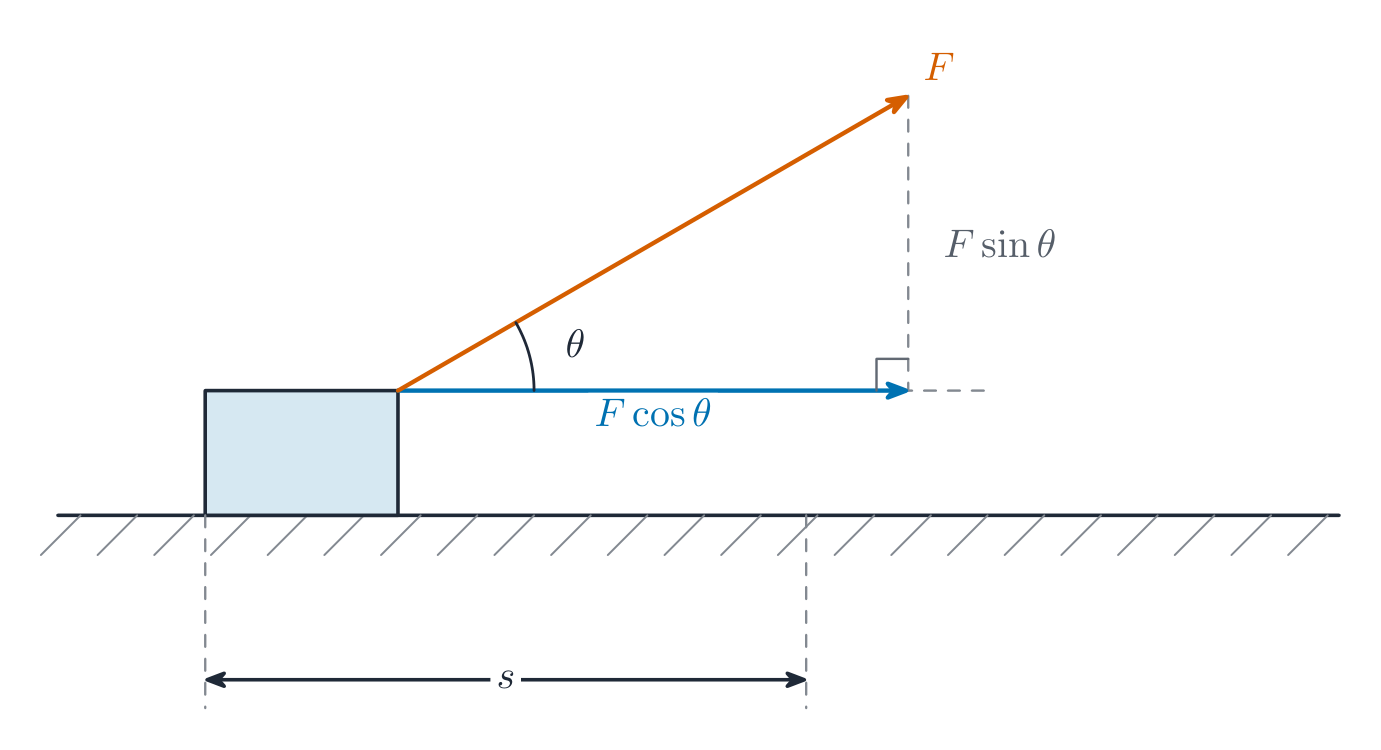
- 3.2.A.3.i The dot product between two vectors, $\vec{A}$ and $\vec{B}$, results in a scalar quantity of magnitude $\vec{A} \cdot \vec{B} = AB\cos\theta$.
- 3.2.A.3.ii Only the component of the force exerted on a system that is parallel to the displacement of the point of application of the force will change the system's total energy.
- 3.2.A.3.iii If the component of the force exerted on a system that is parallel to the displacement is constant, the work done on the system by the force is given by the derived equation $W = F_{\parallel}d = Fd\cos\theta$.
- 3.2.A.3.iv The component of the force exerted on a system perpendicular to the direction of the displacement of the system's center of mass can change the direction of the system's motion without changing the system's kinetic energy.
- 3.2.A.4 The work–energy theorem states that the change in an object's kinetic energy is equal to the sum of the work (net work) being done by all forces exerted on the object.
- Equation: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
- 3.2.A.4.i An external force may change the configuration of a system. The component of the external force parallel to the displacement times the displacement of the point of application of the force gives the change in kinetic energy of the system.
- 3.2.A.4.ii If the system's center of mass and the point of application of the force move the same distance when a force is exerted on a system, then the system may be modeled as an object, and only the system's kinetic energy can change.
- 3.2.A.4.iii The energy dissipated by friction is typically equated to the force of friction times the length of the path over which the force is exerted.
- Equation: $\Delta E_{\text{mech}} = F_f d\cos\theta$
- 3.2.A.5 Work is equal to the area under the curve of a graph of $F_{\parallel}$ as a function of displacement.
Boundary statement: AP Physics C: Mechanics only expects students to analyze the transfer of mechanical energy, although students should be aware that mechanical energy may be dissipated in the form of thermal energy or sound.
العربيةهدف التعلم 3.2.A: وصف الشغل المبذول على جسم أو نظام بواسطة قوة معينة أو مجموعة من القوى.
- 3.2.A.1 الشغل هو مقدار الطاقة المنقولة إلى داخل النظام أو خارجه بواسطة قوة تُمارَس على ذلك النظام عبر مسافة.
- 3.2.A.1.i الشغل المبذول بواسطة قوة محتفظة (conservative) مُمارَس على نظام يكون مستقلاً عن المسار ويعتمد فقط على التكوينات الأولية والنهائية لذلك النظام.
- 3.2.A.1.ii سيكون الشغل المبذول بواسطة قوة محتفظة على نظام—أو التغير في طاقة الوضع للنظام—صفرًا إذا عاد النظام إلى تكوينه الأولي.
- 3.2.A.1.iii ترتبط طاقات الوضع فقط بالقوى المحتفظة.
- 3.2.A.1.iv الشغل المبذول بواسطة قوة غير محتفظة يعتمد على المسار.
- 3.2.A.1.v أكثر القوى غير المحافظة شيوعاً هي الاحتكاك ومقاومة الهواء.
- 3.2.A.2 الشغل هو كمية قياسية قد تكون موجبة أو سالبة أو صفرية.
- 3.2.A.3 يُحسب الشغل المبذول على جسم بواسطة قوة متغيرة باستخدام
- المعادلة: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$، حيث يتم إجراء التكامل على المسار من النقطة $a$ إلى النقطة $b$.
- 3.2.A.3.i ينتج الضرب القياسي بين متجهين، $\vec{A}$ و$\vec{B}$، كمية قياسية مقدارها $\vec{A} \cdot \vec{B} = AB\cos\theta$.
- 3.2.A.3.ii فقط مركبة القوة المؤثرة على نظام موازية لإزاحة نقطة تطبيق القوة هي التي تغير الطاقة الكلية للنظام.
- 3.2.A.3.iii إذا كانت مركبة القوة المؤثرة على نظام موازية للإزاحة ثابتة، فإن الشغل المبذول على النظام بواسطة القوة يُعطى بالمعادلة المستنتجة $W = F_{\parallel}d = Fd\cos\theta$.
- 3.2.A.3.iv يمكن لمركبة القوة المؤثرة على نظام عمودية على اتجاه إزاحة مركز كتلة النظام أن تغير اتجاه حركة النظام دون تغيير طاقته الحركية.
- 3.2.A.4 ينص مبدأ الشغل والطاقة على أن التغير في الطاقة الحركية لجسم يساوي مجموع الشغل (الشغل الصافي) الذي تبذله جميع القوى المؤثرة على الجسم.
- المعادلة: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
- 3.2.A.4.i قد تغير قوة خارجية تكوين النظام. يعطي حاصل ضرب المكون من القوة الخارجية الموازي للإزاحة في إزاحة نقطة تطبيق القوة التغير في الطاقة الحركية للنظام.
- 3.2.A.4.ii إذا تحرك مركز كتلة النظام ونقطة تطبيق القوة نفس المسافة عند ممارسة قوة على نظام، فقد يتم نمذجة النظام كجسم واحد، ويمكن حينها أن يتغير فقط الطاقة الحركية للنظام.
- 3.2.A.4.iii عادةً ما يُساوى الطاقة المبددة بسبب الاحتكاك بقوة الاحتكاك مضروبة في طول المسار الذي تبذلت عليه القوة.
- معادلة: $\Delta E_{\text{mech}} = F_f d\cos\theta$
- 3.2.A.5 الشغل يساوي المساحة تحت منحنى رسم بياني لـ $F_{\parallel}$ بدلالة الإزاحة.
بيان الحدود: يتوقع امتحان AP Physics C: Mechanics من الطلاب فقط تحليل انتقال الطاقة الميكانيكية، على الرغم من أنه يجب على الطلاب معرفة أن الطاقة الميكانيكية قد تُبدد على شكل طاقة حرارية أو صوت.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishWork 功 is energy transferred into or out of a system by a force acting over a distance. For a variable force it is an integral 积分 along the path:
$$W=\int_a^b \vec{F}\cdot d\vec{r}=\int F\cos\theta\,dr.$$For a constant force this reduces to $W=Fd\cos\theta$; on a force–position graph, work is the area under the curve. Work is a scalar with a sign, and the sign is physics, not bookkeeping:
- Positive – force has a component along the motion (it speeds the object up).
- Negative – force opposes the motion (friction 摩擦力 and air drag do negative work).
- Zero – force perpendicular to the motion (the normal force 法向力 on a sliding block, gravity on a horizontal move, tension in a circular swing).
The work–energy theorem 动能定理 collects every force's contribution: the net work equals the change in kinetic energy,
$$W_{\text{net}}=\sum W_i=\Delta K.$$Worked example. A variable force $F(x)=3x^2\ \text{N}$ (along the motion) acts from $x=0$ to $x=2\ \text{m}$: $W=\displaystyle\int_0^2 3x^2\,dx=\big[x^3\big]_0^2=8\ \text{J}$. Acting alone on a body starting from rest, it would raise the kinetic energy to exactly $8\ \text{J}$.
العربيةالشغل هو طاقة تنتقل إلى أو من نظام بواسطة قوة تؤثر عبر مسافة. بالنسبة لقوة متغيرة، يكون تكاملاً على طول المسار:
$$W=\int_a^b \vec{F}\cdot d\vec{r}=\int F\cos\theta\,dr.$$بالنسبة لقوة ثابتة، يتبسط هذا إلى $W=Fd\cos\theta$؛ على الرسم البياني للقوة-الموقع، الشغل هو المساحة تحت المنحنى. الشغل كمية قياسية ذات إشارة، والإشارة هنا فيزياء وليست محاسبة:
- إيجابية – القوة لها مركبة على طول الحركة (تزيد سرعة الجسم).
- سالبة – القوة تعاكس الحركة (الاحتكاك ومقاومة الهواء يقوم بشغل سلبي).
- صفر – القوة عمودية على الحركة (قوة رد الفعل على كتلة تنزلق، الجاذبية على حركة أفقية، الشد في تأرجح دائري).
فقط مركبة القوة على طول الإزاحة تقوم بالعمل ينص نظرية الشغل والطاقة على جمع مساهمات كل قوة: الشغل الصافي يساوي التغير في الطاقة الحركية،
$$W_{\text{net}}=\sum W_i=\Delta K.$$مثال محلول. قوة متغيرة $F(x)=3x^2\ \text{N}$ (على طول الحركة) تعمل من $x=0$ إلى $x=2\ \text{m}$: $W=\displaystyle\int_0^2 3x^2\,dx=\big[x^3\big]_0^2=8\ \text{J}$. إذا عملت وحدها على جسم يبدأ من السكون، فسترفع طاقته الحركية إلى بالضبط $8\ \text{J}$.
Vocabulary · مفردات Train · تدريبEnglish العربية Kinetic energy/kɪˈnetɪk ˈenədʒi/ الطاقة الحركية scalar/ˈskeɪlə/ كمية قياسية joules/dʒuːlz/ جول reference frame/ˈrefrəns freɪm/ إطار مرجعي Work/wɜːk/ الشغل integral/ˈɪntɪɡrəl/ التكامل friction/ˈfrɪkʃn/ الاحتكاك normal force/ˈnɔːml fɔːs/ القوة العمودية work–energy theorem/wɜːk ˈenədʒi ˈθɪərəm/ نظرية الشغل–الطاقة 3.3
Potential Energy · الطاقة الكامنة
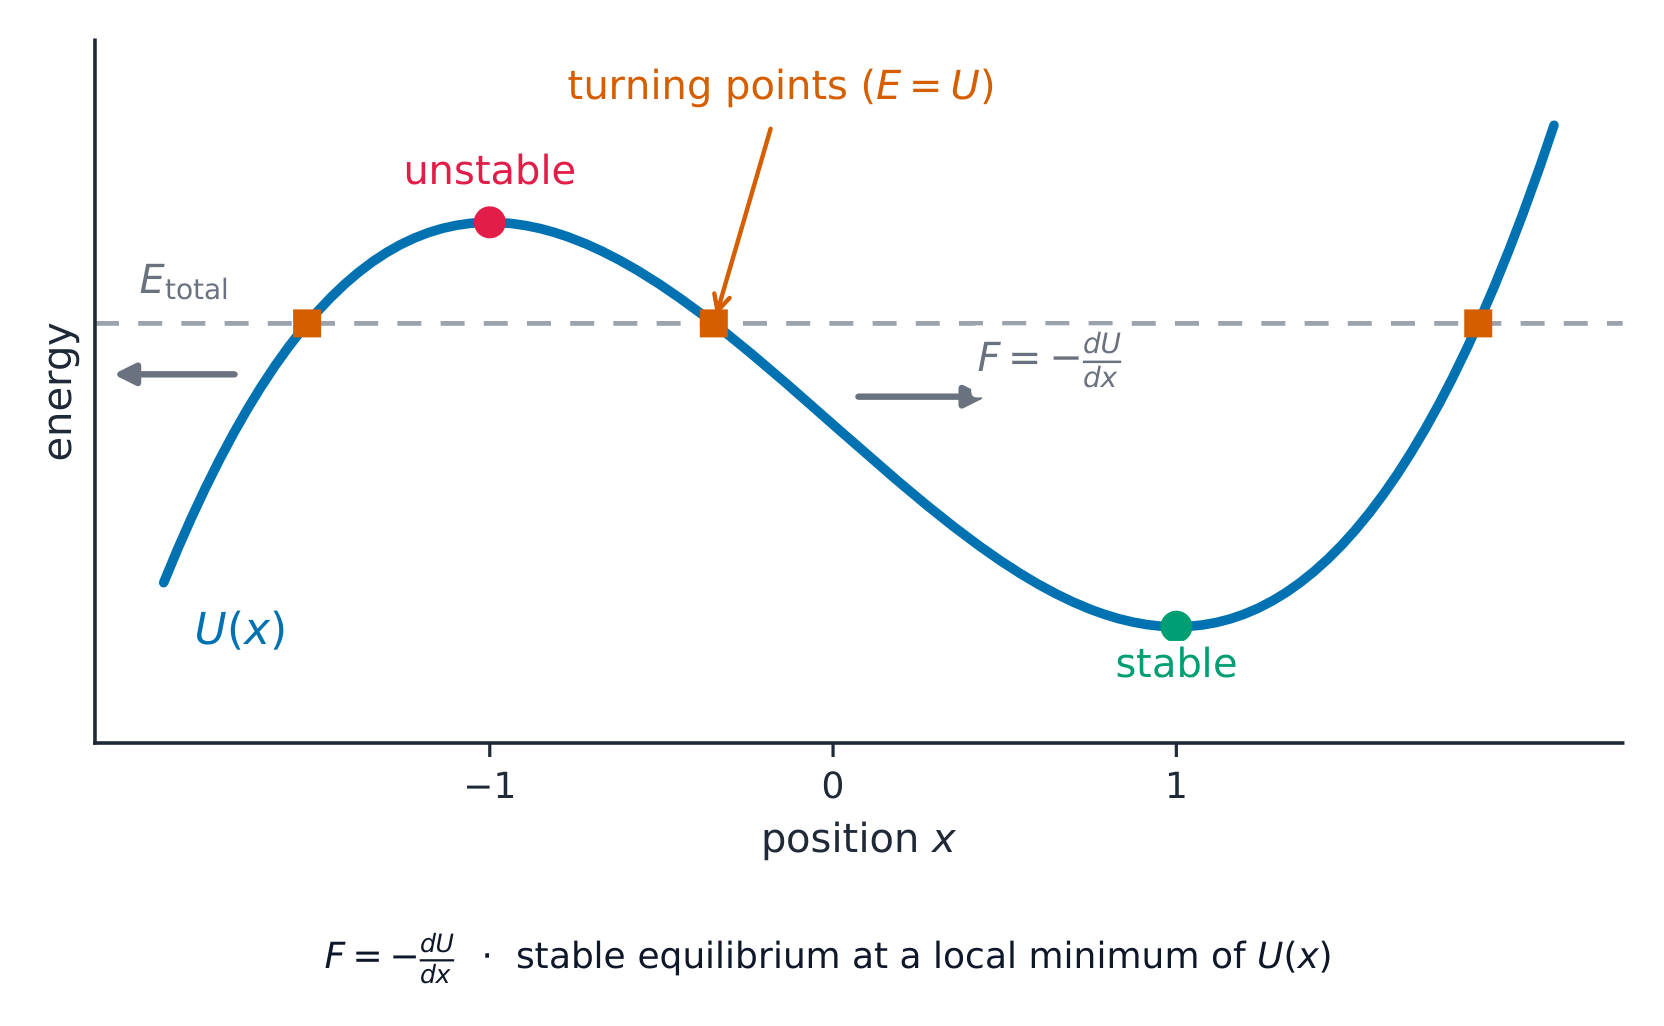
Syllabus · المنهج
EnglishLearning Objective 3.3.A: Describe the potential energy of a system.
- 3.3.A.1 A system composed of two or more objects has potential energy if the objects within that system only interact with each other through conservative forces.
- 3.3.A.2 Potential energy is a scalar quantity associated with the position of objects within a system.
- 3.3.A.3 The definition of zero potential energy for a given system is a decision made by the observer considering the situation to simplify or otherwise assist in analysis.
- 3.3.A.4 The relationship between conservative forces exerted on a system and the system's potential energy is
- Equation: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
- 3.3.A.5 The conservative forces exerted on a system in a single dimension can be determined using the slope of the system's potential energy with respect to position in that dimension; these forces point in the direction of decreasing potential energy.
- Equation: $F_x = -\dfrac{dU(x)}{dx}$
- 3.3.A.6 Graphs of a system's potential energy as a function of its position can be useful in determining physical properties of that system.
- 3.3.A.6.i Stable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object opposite to the direction of the small displacement, accelerating the object back toward the equilibrium position.
- 3.3.A.6.ii Unstable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object in the same direction as the small displacement, accelerating the object away from the equilibrium position.
- 3.3.A.6.iii In a given dimension, stable equilibrium positions exist at locations where the potential energy as a function of position in that dimension has a local minimum.
- 3.3.A.6.iv In a given dimension, unstable equilibrium positions occur at locations where the potential energy as a function of position in that dimension has a local maximum.
- 3.3.A.7 The potential energy of common physical systems can be described using the physical properties of that system.
- 3.3.A.7.i The elastic potential energy of an ideal spring is given by the following equation, where $\Delta x$ is the distance the spring has been stretched or compressed from its equilibrium length.
- Equation: $U_s = \dfrac{1}{2}k(\Delta x)^2$
- 3.3.A.7.ii The general form for the gravitational potential energy of a system consisting of two approximately spherical distributions of mass (e.g., moons, planets, or stars) is given by the equation
- Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
- 3.3.A.7.iii Because the gravitational field near the surface of a planet is nearly constant, the change in gravitational potential energy in a system consisting of an object with mass $m$ and a planet with gravitational field of magnitude $g$ when the object is near the surface of the planet may be approximated by the equation
- Equation: $\Delta U_g = mg\Delta y$
- 3.3.A.7.i The elastic potential energy of an ideal spring is given by the following equation, where $\Delta x$ is the distance the spring has been stretched or compressed from its equilibrium length.
- 3.3.A.8 The total potential energy of a system containing more than two objects is the sum of the potential energy of each pair of objects within the system.
العربيةهدف التعلم 3.3.A: وصف طاقة الوضع لنظام ما.
- 3.3.A.1 يمتلك نظام مكون من جسمين أو أكثر طاقة وضع إذا كانت الأجسام داخل ذلك النظام تتفاعل مع بعضها البعض فقط عبر قوى محتفظة.
- 3.3.A.2 طاقة الوضع هي كمية قياسية مرتبطة بموضع الأجسام داخل النظام.
- 3.3.A.3 تعريف صفر طاقة الوضع لنظام معين هو قرار يتخذه المراقب بناءً على الحالة لتبسيط التحليل أو لمساعدة أخرى في التحليل.
- 3.3.A.4 العلاقة بين القوى المحافظة المؤثرة على نظام وطاقة الوضع للنظام هي
- المعادلة: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
- 3.3.A.5 يمكن تحديد القوى المحافظة المؤثرة على نظام في بُعد واحد باستخدام ميل طاقة الوضع للنظام بالنسبة للموضع في ذلك البُعد؛ هذه القوى تشير في اتجاه تناقص طاقة الوضع.
- المعادلة: $F_x = -\dfrac{dU(x)}{dx}$
- 3.3.A.6 يمكن أن تكون الرسوم البيانية لطاقة الوضع لنظام بدلالة موضعه مفيدة في تحديد الخصائص الفيزيائية لذلك النظام.
- 3.3.A.6.i التوازن المستقر هو موقع يؤدي فيه انحراف صغير في موضع الجسم إلى قوة مؤثرة على الجسم في عكس اتجاه الانحراف الصغير، مما يُسرع الجسم عائداً نحو موضع التوازن.
- 3.3.A.6.ii التوازن غير المستقر هو موقع يؤدي فيه انحراف صغير في موضع الجسم إلى قوة مؤثرة على الجسم في نفس اتجاه الانحراف الصغير، مما يُسرع الجسم مبتعداً عن موضع التوازن.
- 3.3.A.6.iii في بُعد معين، توجد مواقع التوازن المستقر عند المواقع التي يكون فيها طاقة الوضع كدالة للموضع في ذلك البُعد لها حد أدنى محلي.
- 3.3.A.6.iv في بُعد معين، تحدث مواقع التوازن غير المستقر عند المواقع التي يكون فيها طاقة الوضع كدالة للموضع في ذلك البُعد لها حد أعلى محلي.
- 3.3.A.7 يمكن وصف طاقة الوضع لأنظمة فيزيائية شائعة باستخدام الخصائص الفيزيائية لذلك النظام.
- 3.3.A.7.i تُعطى طاقة الوضع المرنة لنابض مثالي بالمعادلة التالية، حيث $\Delta x$ هي المسافة التي تم فيها مد النابض أو ضغطه من طوله المتزن.
- معادلة: $U_s = \dfrac{1}{2}k(\Delta x)^2$
- 3.3.A.7.ii الصورة العامة لطاقة الوضع الجاذبية لنظام يتكون من توزيعين كتليين تقريباً كرويين (مثل الأقمار أو الكواكب أو النجوم) تُعطى بالمعادلة
- معادلة: $U_g = -G\dfrac{m_1 m_2}{r}$
- 3.3.A.7.iii نظراً لحقل الجاذبية القريب من سطح الكوكب شبه ثابت، فإن التغير في طاقة الوضع الجاذبية في نظام يتكون من جسم كتلته $m$ وكوكب له حقل جاذبية مقداره $g$ عندما يكون الجسم قريباً من سطح الكوكب يمكن تقريبه بالمعادلة
- معادلة: $\Delta U_g = mg\Delta y$
- 3.3.A.7.i تُعطى طاقة الوضع المرنة لنابض مثالي بالمعادلة التالية، حيث $\Delta x$ هي المسافة التي تم فيها مد النابض أو ضغطه من طوله المتزن.
- 3.3.A.8 الطاقة势能 الكلية لنظام يحتوي على أكثر من جسمين هي مجموع طاقة الوضع لكل زوج من الأجسام داخل النظام.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishPotential energy 势能 is energy a system stores by the positions of its parts – it exists only for conservative forces 保守力, whose work is path independent. It is defined through work:
$$\Delta U=-\int_a^b\vec{F}\cdot d\vec{r},$$and you are free to choose where $U=0$ – only changes in $U$ matter, so pick the zero that makes the problem simplest. The standard results:
- Gravity near a surface: $\Delta U_g=mg\,\Delta y$.
- Gravity in general: $U_g=-\dfrac{Gm_1m_2}{r}$ (zero at infinite separation).
- Spring: $U_s=\tfrac12k(\Delta x)^2$, with $\Delta x$ measured from natural length.
For systems of several objects, add the potential energy of each pair. Turning the definition around, a conservative force is minus the derivative 导数 of its potential energy:
$$F_x=-\frac{dU}{dx}.$$The force points "downhill" on the $U(x)$ curve. Equilibrium sits where the slope is zero: a minimum is a stable equilibrium 稳定平衡 (displaced, the force pushes back), a maximum is an unstable equilibrium 不稳定平衡 (displaced, the force pushes away).
Worked example. Given $U(x)=2x^3-6x$ (joules), the force is $F=-\dfrac{dU}{dx}=6-6x^2$. Equilibria sit at $F=0$: $x=\pm1$. Since $\dfrac{d^2U}{dx^2}=12x$ is positive at $x=+1$ (a minimum – stable) and negative at $x=-1$ (a maximum – unstable), the two points behave oppositely.
العربيةالطاقة الكامنة هي طاقة يخزنها نظام بسبب مواقع أجزائه – وجودها فقط للقوى المحفوظة، والتي يكون شغلها مستقلاً عن المسار. يتم تعريفها من خلال الشغل:
$$\Delta U=-\int_a^b\vec{F}\cdot d\vec{r},$$وهنا لديك حرية اختيار مكان $U=0$ – فقط التغيرات في $U$ مهمة، لذا اختر الصفر الذي يجعل المسألة أبسط. النتائج القياسية:
- الجاذبية بالقرب من سطح: $\Delta U_g=mg\,\Delta y$.
- الجاذبية بشكل عام: $U_g=-\dfrac{Gm_1m_2}{r}$ (صفر عند الانفصال اللانهائي).
- نابض: $U_s=\tfrac12k(\Delta x)^2$، مع $\Delta x$ مقاسة من الطول الطبيعي.
بالنسبة لأنظمة متعددة الأجسام، أضف الطاقة الكامنة لكل زوج. بعكس التعريف، القوة المحفوظة تساوي سالب المشتق لطاقتها الكامنة:
$$F_x=-\frac{dU}{dx}.$$القوة تتجه "أسفل التلال" على منحنى $U(x)$. التوازن يقع حيث يكون الميل صفراً: الحد الأدنى هو توازن مستقر (عند إزاحته، تدفعه القوة للعودة)، والحد الأعلى هو توازن غير مستقر (عند إزاحته، تدفعه القوة للابتعاد).
على منحنى الطاقة الكامنة تتجه القوة لأسفل و E = U يحدد نقاط الانعطاف مثال محلول. معطى $U(x)=2x^3-6x$ (جول)، القوة هي $F=-\dfrac{dU}{dx}=6-6x^2$. مواقع التوازن تقع عند $F=0$: $x=\pm1$. بما أن $\dfrac{d^2U}{dx^2}=12x$ موجبة عند $x=+1$ (حد أدنى – مستقر) وسالبة عند $x=-1$ (حد أعلى – غير مستقر)، فإن النقطتين تتصرفان بعكس بعضهما البعض.
Explore · استكشفStore elastic potential energy in a spring · خزّن طاقة جهد مرنة في نابض
Stretching a spring stores elastic potential energy $\tfrac12 kx^2$ — the area under the force-extension line. Release it and that energy becomes kinetic. · تمديد نابض يخزن طاقة كامنة مرنة $\tfrac12 kx^2$ — وهي المساحة تحت منحنى القوة والامتداد. عند تحريره تتحول تلك الطاقة إلى طاقة حركية.
Vocabulary · مفردات Train · تدريبEnglish العربية Potential energy/pəˈtenʃl ˈenədʒi/ الطاقة الكامنة conservative forces/kənˈsɜːvətɪv ˈfɔːsɪz/ القوات المحافظة derivative/dɪˈrɪvətɪv/ المشتقة stable equilibrium/ˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ توازن مستقر unstable equilibrium/ʌnˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ توازن غير مستقر Mechanical energy/mɪˈkænɪkl ˈenədʒi/ الطاقة الميكانيكية nonconservative forces/ˌnɒŋkənˈsɜːvətɪv ˈfɔːsɪz/ قوات غير محافظة thermal energy/ˈθɜːml ˈenədʒi/ طاقة حرارية turning points/ˈtɜːnɪŋ pɔɪnts/ نقاط الانعطاف 3.4
Conservation of Energy · حفظ الطاقة
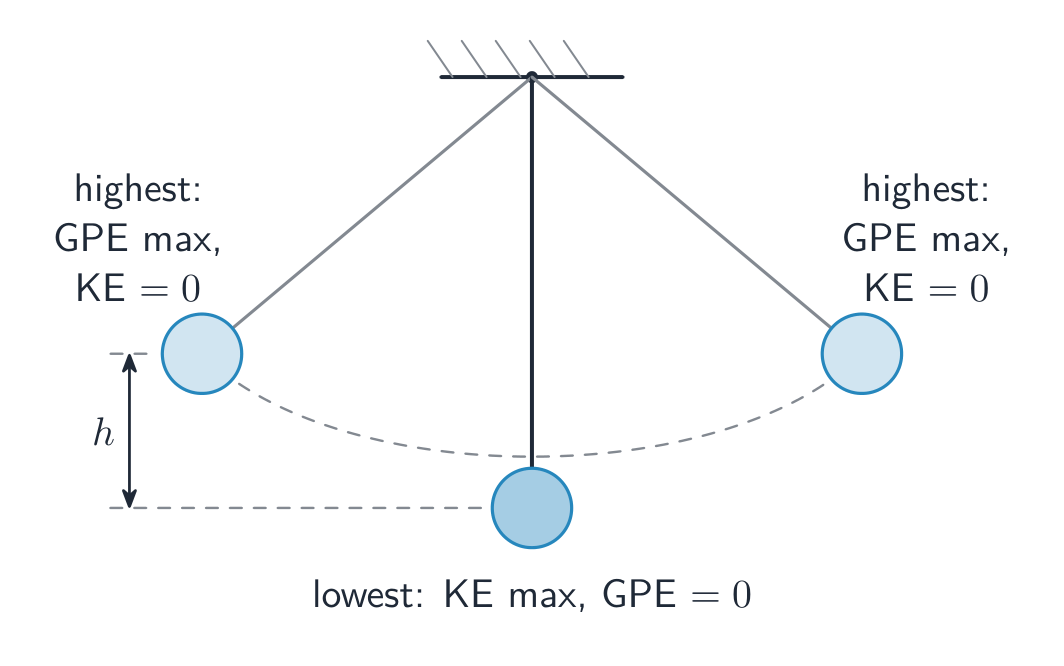
Syllabus · المنهج
EnglishLearning Objective 3.4.A: Describe the energies present in a system.
- 3.4.A.1 A system composed of only a single object can only have kinetic energy.
- 3.4.A.2 A system that contains objects that interact via conservative forces or that can change its shape reversibly may have both kinetic and potential energies.
Learning Objective 3.4.B: Describe the behavior of a system using conservation of mechanical energy principles.
- 3.4.B.1 Mechanical energy is the sum of a system's kinetic and potential energies.
- 3.4.B.2 Any change to a type of energy within a system must be balanced by an equivalent change of other types of energies within the system or by a transfer of energy between the system and its surroundings.
- 3.4.B.3 A system may be selected so that the total energy of that system is constant.
- 3.4.B.4 If the total energy of a system changes, that change will be equivalent to the energy transferred into or out of the system.
Learning Objective 3.4.C: Describe how the selection of a system determines whether the energy of that system changes.
- 3.4.C.1 Energy is conserved in all interactions.
- 3.4.C.2 If the work done on a selected system is zero and there are no nonconservative interactions within the system, the total mechanical energy of the system is constant.
- 3.4.C.3 If the work done on a selected system is nonzero, energy is transferred between the system and the environment.
Boundary statement: AP Physics C: Mechanics expects students to know that mechanical energy can be dissipated as thermal energy or sound by nonconservative forces.
العربيةهدف التعلم 3.4.A: وصف الطاقات الموجودة في نظام ما.
- 3.4.A.1 النظام المكون من جسم واحد فقط يمكن أن يمتلك طاقة حركية فقط.
- 3.4.A.2 النظام الذي يحتوي على أجسام تتفاعل عبر قوى محتفظة أو يمكنه تغيير شكله بشكل عكسي قد يمتلك كلًا من الطاقة الحركية وطاقة الوضع.
هدف التعلم 3.4.B: وصف سلوك نظام باستخدام مبادئ حفظ الطاقة الميكانيكية.
- 3.4.B.1 الطاقة الميكانيكية هي مجموع طاقات الحركة والطاقة الكامنة للنظام.
- 3.4.B.2 أي تغيير في نوع من أنواع الطاقة داخل نظام ما يجب أن يكون مقابلاً لتغير مساوٍ في أنواع أخرى من الطاقة داخل النظام، أو بتحويل طاقة بين النظام ومحيطه.
- 3.4.B.3 يمكن اختيار نظام بحيث تكون الطاقة الكلية لذلك النظام ثابتة.
- 3.4.B.4 إذا تغيرت الطاقة الكلية لنظام ما، فإن هذا التغير سيكون مساوياً للطاقة المنقولة إلى النظام أو منه.
هدف التعلم 3.4.C: صف كيف يحدد اختيار النظام ما إذا كانت طاقة ذلك النظام تتغير.
- 3.4.C.1 تُحفظ الطاقة في جميع التفاعلات.
- 3.4.C.2 إذا كان الشغل المبذول على نظام مختار يساوي صفرًا ولم تكن هناك تفاعلات غير محافظية داخل النظام، فإن الطاقة الميكانيكية الكلية للنظام تكون ثابتة.
- 3.4.C.3 إذا كان الشغل المبذول على نظام مختار لا يساوي صفرًا، فإن الطاقة تنتقل بين النظام والبيئة المحيطة.
بيان الحدود: يتوقع امتحان AP Physics C: Mechanics من الطلاب معرفة أن الطاقة الميكانيكية يمكن تبديدها على شكل طاقة حرارية أو صوت بواسطة قوى غير محافظة.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishEnergy conservation: KE ⇄ PE Energy is conserved in all interactions – the question is only where it goes. Mechanical energy 机械能 is the sum $E=K+U$. If the external work on a system is zero and nothing inside it acts through nonconservative forces 非保守力, then
$$K_1+U_1=K_2+U_2.$$When friction or drag act, they convert mechanical energy into thermal energy 热能 ($\Delta E_{\text{mech}}=-F_fd$), and the balance must include that term. If external work is done, the system's total energy changes by exactly the energy transferred: $W_{\text{ext}}=\Delta E_{\text{sys}}$. Choosing the system is choosing the bookkeeping – a single object can only have kinetic energy; include the Earth or the spring and the system can store potential energy too.
A potential-energy graph is a complete motion map: the horizontal line at height $E$ is the total energy, the gap $E-U(x)$ is the kinetic energy at each $x$, and the crossings $E=U$ are the turning points 转折点 where the object momentarily stops and reverses.
Worked example. A $2.0\ \text{kg}$ block slides down a ramp from rest at height $1.5\ \text{m}$, arriving at the bottom at $4.0\ \text{m/s}$. Energy accounting: $mgh=29.4\ \text{J}$ available; $\tfrac12mv^2=16\ \text{J}$ arrives as kinetic energy; so friction converted $29.4-16=13\ \text{J}$ into thermal energy along the way.
العربيةحفظ الطاقة: KE ⇄ PE الطاقة محفوظة في جميع التفاعلات – السؤال هو فقط أين تذهب. الطاقة الميكانيكية هي المجموع $E=K+U$. إذا كان الشغل الخارجي على النظام صفراً ولا يوجد ما بداخله يعمل عبر قوى غير محفوظة، فإن
$$K_1+U_1=K_2+U_2.$$عندما يعمل الاحتكاك أو المقاومة، يحول الطاقة الميكانيكية إلى طاقة حرارية ($\Delta E_{\text{mech}}=-F_fd$)، ويجب أن يتضمن الرصيد هذا الحد. إذا تم بذل شغل خارجي، يتغير الطاقة الكلية للنظام بدقة مقدار الطاقة المنقولة: $W_{\text{ext}}=\Delta E_{\text{sys}}$. اختيار النظام هو اختيار المحاسبة – جسم واحد يمكنه فقط امتلاك طاقة حركية؛ اشمل الأرض أو النابض ليتمكن النظام من تخزين الطاقة الكامنة أيضاً.
البندول يستبدل الطاقة الكامنة الجاذبية بالطاقة الحركية والعكس رسم طاقة الوضع هو خريطة حركة كاملة: الخط الأفقي عند الارتفاع $E$ يمثل الطاقة الكلية، والفجوة $E-U(x)$ تمثل الطاقة الحركية في كل $x$، والنقاط التي تتقاطع فيها $E=U$ هي نقاط الانعطاف حيث يتوقف الجسم لحظيًا ثم يعكس اتجاهه.
مثال محلول. كتلة $2.0\ \text{kg}$ تنزلق على منحدر من السكون عند ارتفاع $1.5\ \text{m}$، وتصل إلى القاع بسرعة $4.0\ \text{m/s}$. حساب الطاقة: $mgh=29.4\ \text{J}$ متاحة؛ $\tfrac12mv^2=16\ \text{J}$ تصل كطاقة حركية؛ لذا حول الاحتكاك $29.4-16=13\ \text{J}$ إلى طاقة حرارية خلال الطريق.
يعمل قطار التسلق على تبديل الطاقة ذهابًا وإيابًا: الأعلى (أكثر طاقة وضع) في القمة، الأسرع (أكثر طاقة حركية) في القاع Explore · استكشفWatch energy convert as an object falls · راقب تحول الطاقة أثناء سقوط جسم
With no friction, mechanical energy is conserved: as an object falls, gravitational potential energy turns into kinetic energy while the total stays fixed. · بدون احتكاك، تحفظ الطاقة الميكانيكية: أثناء سقوط الجسم، تتحول الطاقة الجهدية الجاذبية إلى طاقة حركية بينما تبقى المجموع ثابتاً.
3.5
Power · القدرة
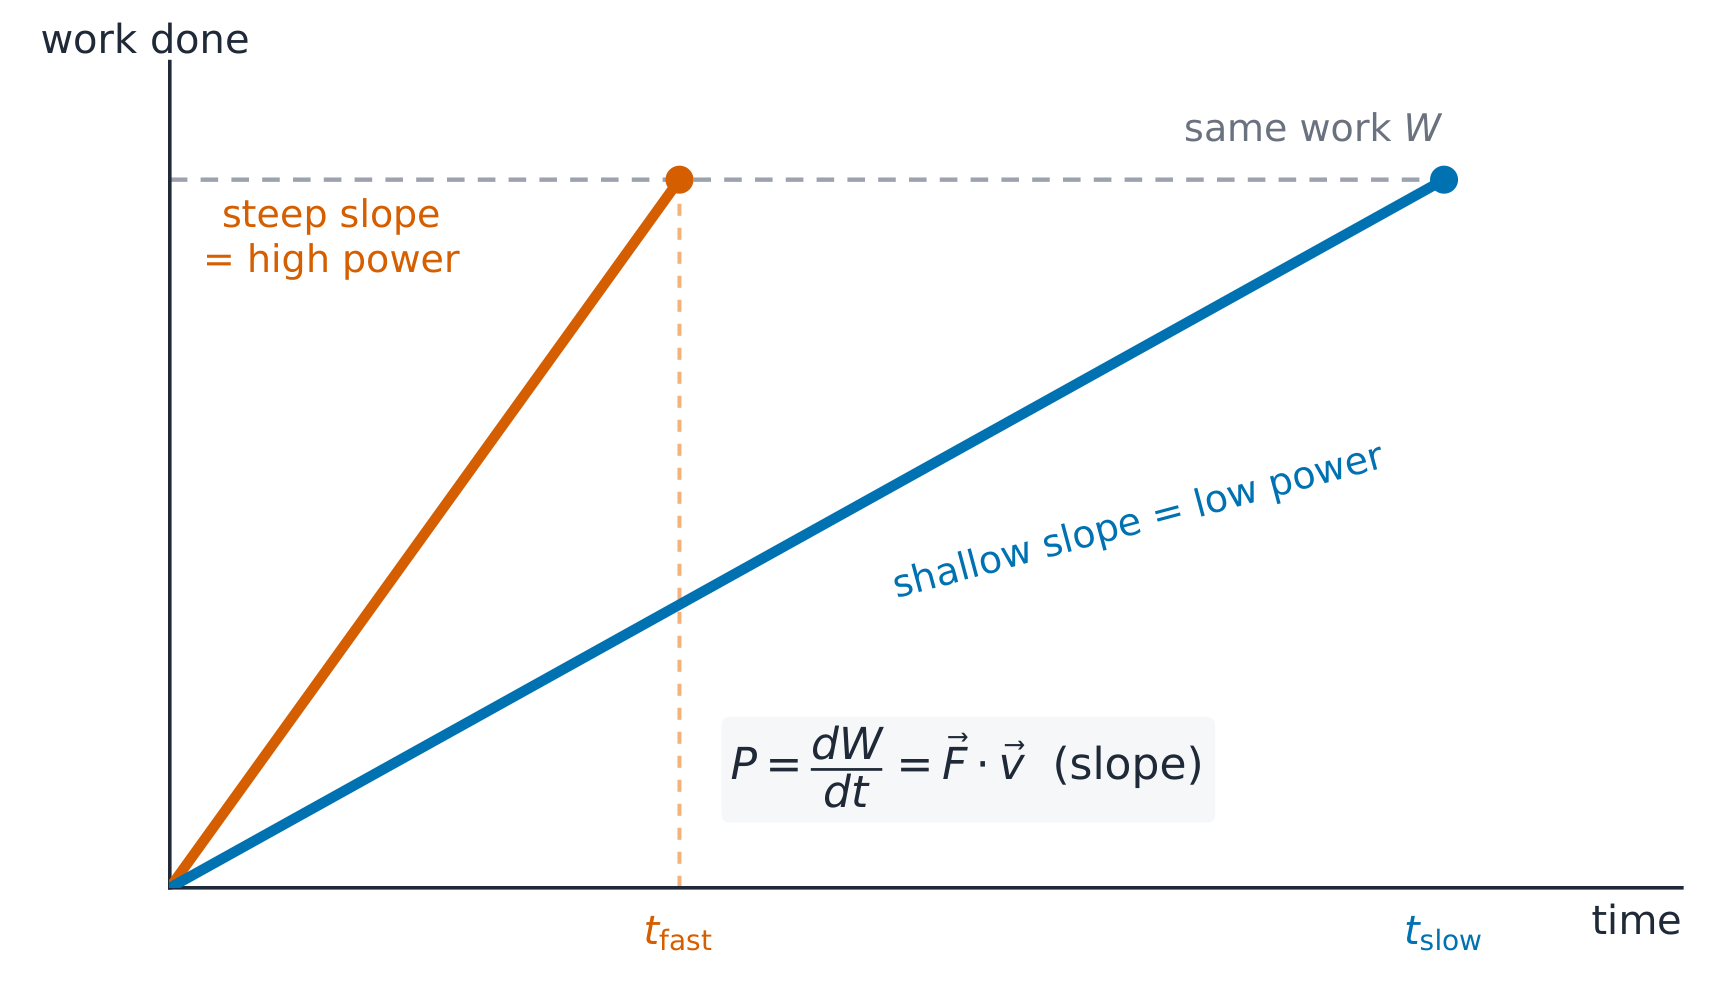
Syllabus · المنهج
EnglishLearning Objective 3.5.A: Describe the transfer of energy into, out of, or within a system in terms of power.
- 3.5.A.1 Power is the rate at which energy changes with respect to time, either by transfer into or out of a system or by conversion from one type to another within a system.
- 3.5.A.2 Average power is the amount of energy being transferred or converted, divided by the time it took for that transfer or conversion to occur.
- Equation: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
- 3.5.A.3 Because work is the change in energy of an object or system due to a force, average power is the total work done, divided by the time during which that work was done.
- Equation: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
- 3.5.A.4 The instantaneous power delivered to an object by a force is given by the equation
- Equation: $P_{\text{inst}} = \dfrac{dW}{dt}$
- 3.5.A.5 The instantaneous power delivered to an object by the component of a constant force parallel to the object's velocity can be described with the derived equation
- Equation: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$
العربيةهدف التعلم 3.5.A: صف انتقال الطاقة إلى داخل النظام، أو خارجه، أو داخله بدلالة القدرة.
- 3.5.A.1 القدرة هي معدل تغير الطاقة بالنسبة للزمن، سواء كان ذلك عن طريق نقلها إلى النظام أو منه، أو بتحويلها من نوع إلى آخر داخل النظام.
- 3.5.A.2 القدرة المتوسطة هي كمية الطاقة المنتقلة أو المحولة، مقسومة على الزمن المستغرق لحدوث هذا النقل أو التحويل.
- المعادلة: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
- 3.5.A.3 نظرًا لأن الشغل هو تغير طاقة جسم أو نظام نتيجة لقوة، فإن القدرة المتوسطة تساوي إجمالي الشغل المبذول مقسومًا على الزمن الذي استغرقه تنفيذ ذلك الشغل.
- المعادلة: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
- 3.5.A.4 القدرة اللحظية الموصلة إلى جسم بواسطة قوة تُعطى بالمعادلة
- المعادلة: $P_{\text{inst}} = \dfrac{dW}{dt}$
- 3.5.A.5 يمكن وصف القدرة اللحظية الموصلة إلى جسم بواسطة مركبة قوة ثابتة موازية لسرعة الجسم بالمعادلة المستنتجة
- المعادلة: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishPower 功率 is the rate of energy transfer, in watts 瓦特 (W):
$$P_{\text{avg}}=\frac{\Delta E}{\Delta t}=\frac{W}{\Delta t},\qquad P_{\text{inst}}=\frac{dW}{dt}=\vec{F}\cdot\vec{v}.$$It measures how fast work is done, not how much. The dot product matters: only the force component along the velocity delivers power.
Worked example. A block released from rest at the top of a frictionless $3.0\ \text{m}$-high ramp reaches the bottom at $v=\sqrt{2gh}=7.7\ \text{m/s}$ (from $mgh=\tfrac12mv^2$). A motor that then drives it at a steady $7.7\ \text{m/s}$ against a $20\ \text{N}$ resistance delivers $P=Fv=20(7.7)\approx150\ \text{W}$.
Worked example. A $1200\ \text{kg}$ car climbs a hill that rises $1.0\ \text{m}$ for every $20\ \text{m}$ of road, at a steady $15\ \text{m/s}$. The engine must supply gravity's power drain: $P=mg\,v\sin\theta=1200(9.8)(15)\big(\tfrac{1}{20}\big)\approx8.8\ \text{kW}$ – before adding air resistance.
Exam skill. Energy FRQs reward the accounting sentence: name your system, state which forces do work on it, and write the balance ($W_{\text{ext}}=\Delta K+\Delta U+\Delta E_{\text{thermal}}$) before plugging in numbers. "Friction is present, so mechanical energy is not conserved" is a scored statement.
العربيةالقدرة هي معدل نقل الطاقة، بوحدة واط (W):
$$P_{\text{avg}}=\frac{\Delta E}{\Delta t}=\frac{W}{\Delta t},\qquad P_{\text{inst}}=\frac{dW}{dt}=\vec{F}\cdot\vec{v}.$$إنها تقيس مدى سرعة انجام الشغل، وليس كميته. الضرب النقطي مهم: فقط مركبة القوة الموازية للسرعة توفر القدرة.
القدرة هي ميل رسم بياني الشغل–الزمن: نفس العمل في وقت أقل يعني قدرة أكبر مثال محلول. كتلة أُطلقت من السكون عند قمة منحدر أملس ارتفاعه $3.0\ \text{m}$، وصلت إلى القاع بسرعة $v=\sqrt{2gh}=7.7\ \text{m/s}$ (من $mgh=\tfrac12mv^2$). محرك يقودها بعد ذلك بسرعة ثابتة $7.7\ \text{m/s}$ ضد مقاومة مقدارها $20\ \text{N}$، ويوفر قدرة $P=Fv=20(7.7)\approx150\ \text{W}$.
مثال محلول. سيارة وزنها $1200\ \text{kg}$ تصعد تلة ترتفع $1.0\ \text{m}$ لكل $20\ \text{m}$ من الطريق، بسرعة ثابتة $15\ \text{m/s}$. يجب أن يزود المحرك القدرة المفقودة بسبب الجاذبية: $P=mg\,v\sin\theta=1200(9.8)(15)\big(\tfrac{1}{20}\big)\approx8.8\ \text{kW}$ – قبل إضافة مقاومة الهواء.
مهارة الامتحان. أسئلة FRQ الخاصة بالطاقة تكافئ جملة الحساب: حدد نظامك، واذكر القوى التي تقوم بشغل عليه، واكتب معادلة التوازن ($W_{\text{ext}}=\Delta K+\Delta U+\Delta E_{\text{thermal}}$) قبل التعويض بالأرقام. عبارة "وجود احتكاك يعني أن الطاقة الميكانيكية غير محفوظة" تُحسب كنقاط.
Vocabulary · مفردات Train · تدريبEnglish العربية Power/ˈpaʊə/ القدرة watts/wɒts/ وات 3.5
Exam tips · نصائح للامتحان
English- Use the work–energy theorem $W_{net}=\Delta KE$ and compute work as $W=\int \vec F\cdot d\vec r$ for a variable force.
- Read work off a force–position graph as the area under the curve.
- Power is $P=\tfrac{dW}{dt}=\vec F\cdot\vec v$; watch instantaneous vs average.
- Split forces into conservative (define a potential energy) and non-conservative (dissipate energy).
- Choose energy methods over kinematics when the force varies or the path is complex.
العربية- استخدم مبرهنة الشغل-الطاقة $W_{net}=\Delta KE$ واحسب الشغل كـ↫F·dx$W=\int \vec F\cdot d\vec r$ لقوة متغيرة.
- اقرأ الشغل من رسم بياني للقوة-الموضع كمساحة تحت المنحنى.
- القدرة هي $P=\tfrac{dW}{dt}=\vec F\cdot\vec v$؛ انتبه بين الفورية والمتوسطة.
- افصل القوى إلى محتفظة (عرّف طاقة وضع لها) وغير محتفظة (تبذير الطاقة).
- اختر طرق الطاقة بدلاً من الديناميكا عندما تتغير القوة أو يكون المسار معقدًا.
- 3.1.A.1 An object's translational kinetic energy is given by the equation
-
4
Linear Momentum · الزخم الخطي
Watch lesson · شاهد الدرس4.1
Linear Momentum · الزخم الخطي
Syllabus · المنهج
EnglishLearning Objective 4.1.A: Describe the linear momentum of an object or system.
- 4.1.A.1 Linear momentum is defined by the equation $\vec{p} = m\vec{v}$.
- 4.1.A.2 Momentum is a vector quantity and has the same direction as the velocity.
- 4.1.A.3 Momentum can be used to analyze collisions and explosions.
- 4.1.A.3.i A collision is a model for an interaction where the forces exerted between the involved objects in the system are much larger than the net external force exerted on those objects during the interaction.
- 4.1.A.3.ii As only the initial and final states of a collision are analyzed, the object model may be used to analyze collisions.
- 4.1.A.3.iii An explosion is a model for an interaction in which forces internal to the system move objects within that system apart.
العربيةهدف التعلم 4.1.A: صف الزخم الخطي لجسم أو نظام.
- 4.1.A.1 يُعرَّف الزخم الخطي بالمعادلة $\vec{p} = m\vec{v}$.
- 4.1.A.2 الزخم كمية متجهة ولها نفس اتجاه السرعة.
- 4.1.A.3 يمكن استخدام الزخم لتحليل الاصطدامات والانفجارات.
- 4.1.A.3.i الاصطدام هو نموذج لتفاعل تكون فيه القوى المؤثرة بين الأجسام المشاركة في النظام أكبر بكثير من محصلة القوى الخارجية المؤثرة على تلك الأجسام أثناء التفاعل.
- 4.1.A.3.ii بما أنه يتم تحليل حالة البداية والنهاية فقط للاصطدام، يمكن استخدام نموذج الجسم النقطي لتحليل الاصطدامات.
- 4.1.A.3.iii الانفجار هو نموذج لتفاعل تتحرك فيه القوى الداخلية للنظام الأجسام الموجودة داخله مبتعدة عن بعضها البعض.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishLinear momentum 动量 is mass times velocity:
$$\vec{p}=m\vec{v}.$$It is a vector 矢量 pointing along the velocity, and it is the quantity for analysing collisions 碰撞 and explosions 爆炸. A collection of objects can be treated as one system moving with the velocity of its center of mass 质心:
$$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$so the system's total momentum is its total mass times $\vec{v}_{\text{cm}}$ – one object's worth of bookkeeping for any number of parts.
العربيةكمية التحرك الخطية هي حاصل ضرب الكتلة في السرعة:
$$\vec{p}=m\vec{v}.$$وهي متجه يشير في اتجاه السرعة، وهي الكمية الأساسية لتحليل التصادمات والانفجارات. يمكن اعتبار مجموعة من الأجسام كنظام واحد يتحرك بسرعة مركز كتلته:
$$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$لذلك تكون كمية التحرك الكلية للنظام هي كتلته الكلية مضروبة في $\vec{v}_{\text{cm}}$ – سجل واحد يكفي لأي عدد من الأجزاء.
4.2
Change in Momentum and Impulse · التغير في الزخم والدفع
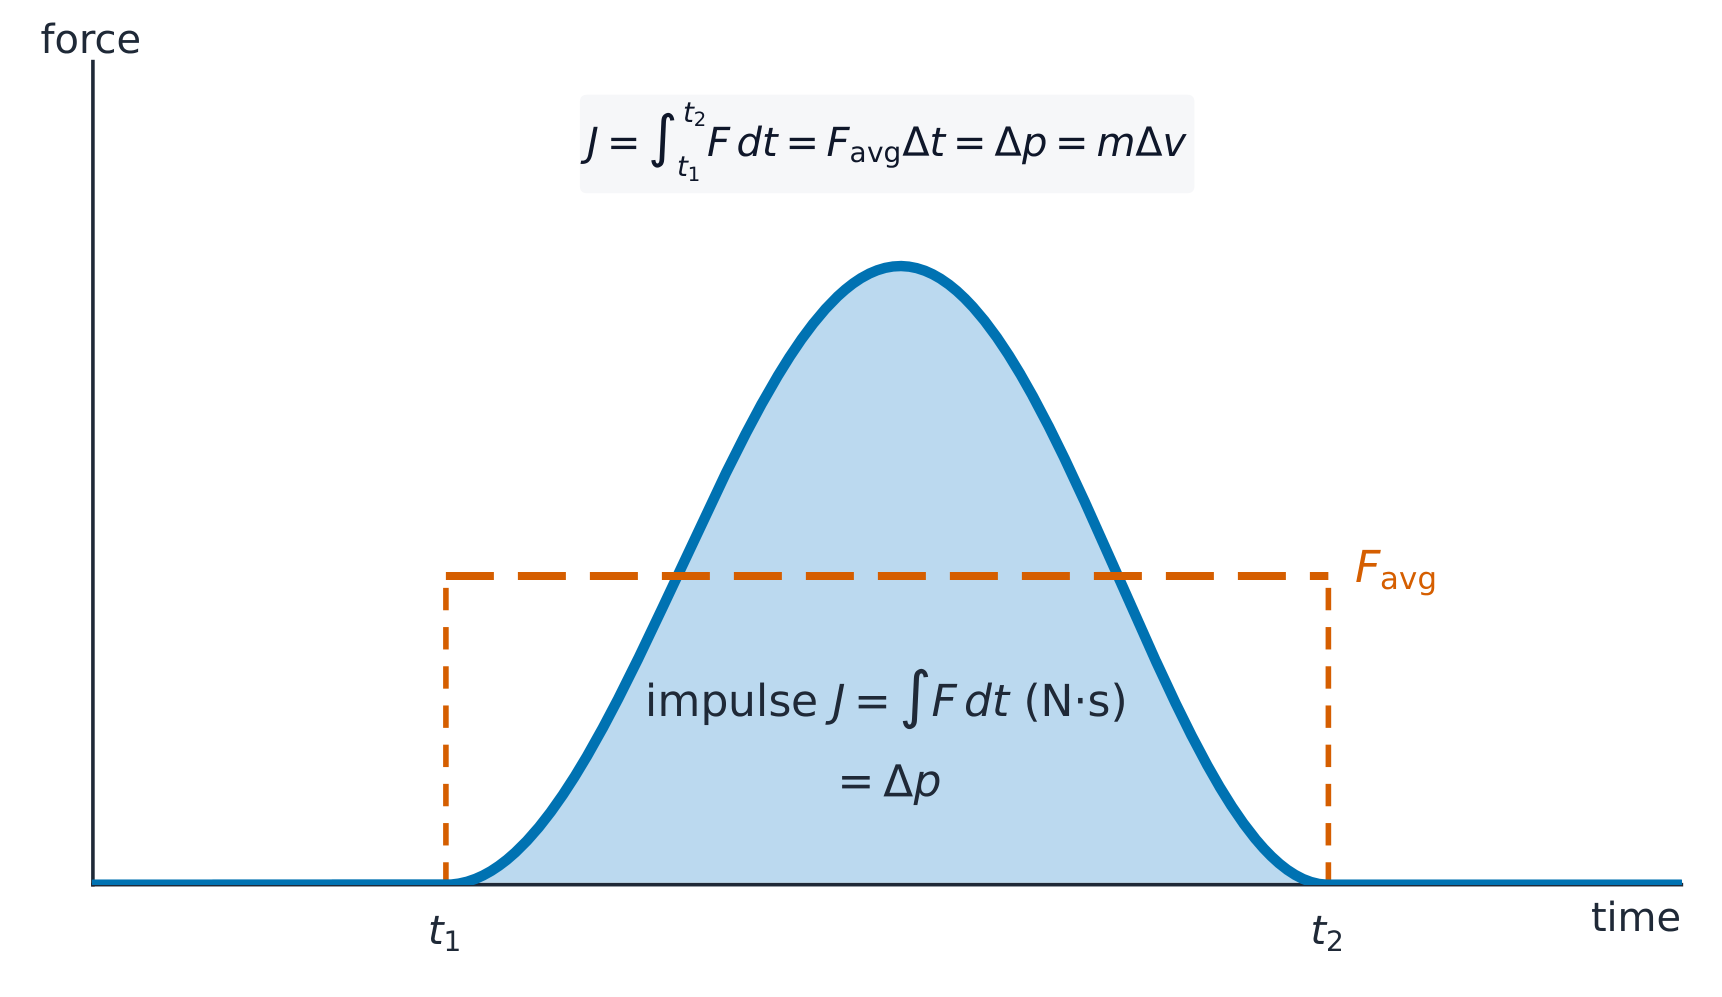
Syllabus · المنهج
EnglishLearning Objective 4.2.A: Describe the impulse delivered to an object or system.
- 4.2.A.1 The rate of change of a system's momentum is equal to the net external force exerted on that system.
- Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
- 4.2.A.2 Impulse is defined as the integral of a force exerted on an object or system over a time interval.
- Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
- 4.2.A.3 Impulse is a vector quantity and has the same direction as the net force exerted on the system.
- 4.2.A.4 The impulse delivered to a system by a net external force is equal to the area under the curve of a graph of the net external force exerted on the system as a function of time.
- 4.2.A.5 The net external force exerted on a system is equal to the slope of a graph of the momentum of the system as a function of time.
Learning Objective 4.2.B: Describe the relationship between the impulse exerted on an object or system and the change in momentum of the object or system.
- 4.2.B.1 Change in momentum is the difference between a system's final momentum and its initial momentum.
- Equation: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
- 4.2.B.2 The impulse–momentum theorem relates the impulse delivered to an object and the object's change in momentum.
- 4.2.B.2.i The impulse exerted on an object is equal to the object's change in momentum.
- Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
- 4.2.B.2.ii Newton's second law of motion is a direct result of the impulse–momentum theorem applied to systems with constant mass.
- Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
- 4.2.B.2.iii The impulse–momentum theorem also describes the behavior of a system in which the velocity is constant but the mass changes with respect to time.
- Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$
- 4.2.B.2.i The impulse exerted on an object is equal to the object's change in momentum.
العربيةهدف التعلم 4.2.A: صف الدفع المقدم لجسم أو نظام.
- 4.2.A.1 معدل تغير زخم النظام يساوي محصلة القوى الخارجية المؤثرة على ذلك النظام.
- المعادلة: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
- 4.2.A.2 يُعرف الزخم القسري بأنه تكامل قوة مؤثرة على جسم أو نظام خلال فترة زمنية.
- المعادلة: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
- 4.2.A.3 الدفع كمية متجهة ولها نفس اتجاه محصلة القوى المؤثرة على النظام.
- 4.2.A.4 الدفع المقدم لنظام بواسطة محصلة قوى خارجية يساوي المساحة تحت منحنى بياني لمحصلة القوى الخارجية المؤثرة على النظام كدالة للزمن.
- 4.2.A.5 محصلة القوى الخارجية المؤثرة على نظام تساوي ميل بيانية لزخم该系统 كدالة للزمن.
هدف التعلم 4.2.B: وصف العلاقة بين الزخم القسري المؤثر على جسم أو نظام والتغير في زخم الجسم أو النظام.
- 4.2.B.1 التغير في الزخم هو الفرق بين الزخم النهائي للنظام وزخمه الابتدائي.
- المعادلة: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
- 4.2.B.2 يربط مبرهنة الزخم القسري–الزخم بين الزخم القسري المُقدَّم لجسم وتغير زخم ذلك الجسم.
- 4.2.B.2.i الزخم القسري المؤثر على جسم يساوي التغير في زخم ذلك الجسم.
- معادلة: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
- 4.2.B.2.ii قانون نيوتن الثاني للحركة هو نتيجة مباشرة لمبرهنة الزخم القسري–الزخم المطبقة على الأنظمة ذات الكتلة الثابتة.
- معادلة: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
- 4.2.B.2.iii تصف مبرهنة الزخم القسري–الزخم أيضًا سلوك نظام تكون فيه السرعة ثابتة ولكن تتغير الكتلة بالنسبة للزمن.
- معادلة: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$
- 4.2.B.2.i الزخم القسري المؤثر على جسم يساوي التغير في زخم ذلك الجسم.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishNewton's second law is really a statement about momentum:
$$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$which reduces to $m\vec{a}$ when the mass is constant – and handles a changing mass when it is not (the special case $\vec{F}=\dfrac{dm}{dt}\vec{v}$ holds only when the velocity is constant, e.g. a chain piling onto a scale or sand landing on a belt moving at fixed speed; a rocket does not fit, since it accelerates). The impulse 冲量 delivered by a force is its time integral, and the impulse–momentum theorem 冲量-动量定理 says it equals the change in momentum:
$$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$Impulse is a vector along the net force. Read it off graphs both ways:
- On a force–time graph, impulse is the area under the curve.
- On a momentum–time graph, the net force is the slope 斜率 at each instant.
Spreading the same $\Delta p$ over a longer time lowers the force – that is why airbags, crumple zones, and soft landings work, and why you bend your knees when you land.
Worked example. A time-varying force $F(t)=10t\ \text{N}$ acts on a $2.0\ \text{kg}$ object for $2.0\ \text{s}$. The impulse is $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$, so the speed changes by $\Delta v=J/m=10\ \text{m/s}$.
العربيةقانون نيوتن الثاني هو في الواقع بيان حول كمية التحرك:
$$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$والتي تختزل إلى $m\vec{a}$ عندما تكون الكتلة ثابتة – وتتعامل مع تغير الكتلة عندما لا تكون ثابتة (الحالة الخاصة $\vec{F}=\dfrac{dm}{dt}\vec{v}$ صحيحة فقط عندما تكون السرعة ثابتة، مثل سلسلة تتراكم على ميزان أو رمل يسقط على حزام يتحرك بسرعة ثابتة؛ الصاروخ لا ينطبق عليه هذا لأن تسارعه). الدفع الذي تقدمه قوة هو تكاملها الزمني، ومبرهنة الدفع-كمية التحرك تقول إنه يساوي التغير في كمية التحرك:
$$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$الدفع هو متجه في اتجاه محصلة القوى. اقرؤه من الرسوم البيانية بطريقتين:
- على الرسم البياني للقوة-الزمن، الدفع هو المساحة تحت المنحنى.
- على الرسم البياني لكمية التحرك-الزمن، القوة المحصلة هي الميل عند كل لحظة.
الدفع هو المساحة تحت منحنى القوة–الزمن، مساوية لمتوسط القوة مضروبًا في زمن التلامس توزيع نفس $\Delta p$ على فترة زمنية أطول يقلل القوة – وهذا هو سبب عمل وسائد الهواء، ومناطق الاندماج، والهبوط الناعم، ولماذا نثني ركبينا عند الهبوط.
مثال محلول. قوة متغيرة مع الزمن $F(t)=10t\ \text{N}$ تؤثر على جسم كتلته $2.0\ \text{kg}$ لمدة $2.0\ \text{s}$. الدفع هو $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$، لذا تتغير السرعة بمقدار $\Delta v=J/m=10\ \text{m/s}$.
Vocabulary · مفردات Train · تدريبEnglish العربية Linear momentum/ˈlɪnɪə məʊˈmentəm/ الزخم الخطي vector/ˈvektə/ شعاعية collisions/kəˈlɪʒnz/ التصادمات explosions/ekˈspləʊʒnz/ الانفجارات center of mass/ˈsentə ɒv mæs/ مركز الكتلة impulse/ˈɪmpʌls/ انفعال impulse–momentum theorem/ˈɪmpʌls məʊˈmentəm ˈθɪərəm/ نظرية الدفع–الزخم slope/sləʊp/ الميل conserved/kənˈsɜːvd/ محفوظة kinetic energy/kɪˈnetɪk ˈenədʒi/ الطاقة الحركية elastic collision/ɪˈlæstɪk kəˈlɪʒn/ اصطدام مرن inelastic collision/ɪnɪˈlæstɪk kəˈlɪʒn/ اصطدام غير مرن deformation/ˌdiːfɔːˈmeɪʃn/ التشوه perfectly inelastic collision/ˈpɜːfektlɪ ɪnɪˈlæstɪk kəˈlɪʒn/ اصطدام غير مرن تماماً 4.3
Conservation of Linear Momentum · حفظ الزخم الخطي
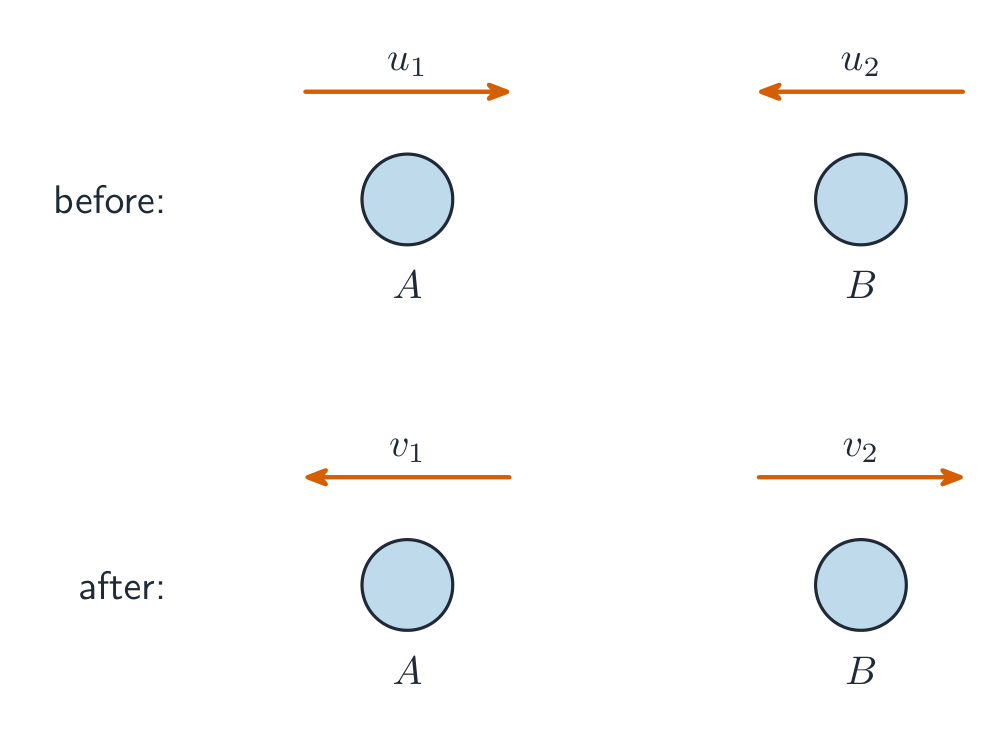
Syllabus · المنهج
Learning Objective Essential Knowledge 4.3.A
Describe the behavior of a system using conservation of linear momentum.- 4.3.A.1 A collection of objects with individual momenta can be described as one system with one center-of-mass velocity.
- 4.3.A.1.i For a collection of objects, the velocity of a system's center of mass can be calculated using the equation
- Equation: $\vec{v}_{\text{cm}} = \dfrac{\sum \vec{p}_i}{\sum m_i} = \dfrac{\sum (m_i \vec{v}_i)}{\sum m_i}$
- 4.3.A.1.ii The velocity of a system's center of mass is constant in the absence of a net external force.
- 4.3.A.1.i For a collection of objects, the velocity of a system's center of mass can be calculated using the equation
- 4.3.A.2 The total momentum of a system is the sum of the momenta of the system's constituent parts.
- 4.3.A.3 In the absence of net external forces, any change to the momentum of an object within a system must be balanced by an equivalent and opposite change of momentum elsewhere within the system. Any change to the momentum of a system is due to a transfer of momentum between the system and its surroundings.
- 4.3.A.3.i The impulse exerted by one object on a second object is equal and opposite to the impulse exerted by the second object on the first. This is a direct result of Newton's third law.
- 4.3.A.3.ii A system may be selected so that the total momentum of that system is constant.
- 4.3.A.3.iii If the total momentum of a system changes, that change will be equivalent to the impulse exerted on the system.
- Equation: $\vec{J} = \Delta\vec{p}$
- 4.3.A.4 Correct application of conservation of momentum can be used to determine the velocity of a system immediately before and immediately after collisions or explosions.
Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze collisions and interactions in one or two dimensions. Three-dimensional collisions may be analyzed qualitatively.
4.3.B
Describe how the selection of a system determines whether the momentum of that system changes.- 4.3.B.1 Momentum is conserved in all interactions.
- 4.3.B.2 If the net external force on the selected system is zero, the total momentum of the system is constant.
- 4.3.B.3 If the net external force on the selected system is nonzero, momentum is transferred between the system and the environment.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishInternal forces come in Newton's-third-law pairs, so they cancel inside any system: they can shuffle momentum between parts but never change the total. Momentum only enters or leaves a system through a net external force ($\vec{J}=\Delta\vec{p}$). So, with zero net external force, total momentum is conserved 守恒:
$$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$Momentum is conserved in every collision, however violent – choose the system large enough that the collision forces are internal. Apply conservation separately along each axis; AP asks for quantitative work in one or two dimensions.
Worked example (explosion). A $6.0\ \text{kg}$ shell at rest splits into a $2.0\ \text{kg}$ piece moving at $9.0\ \text{m/s}$ east and a $4.0\ \text{kg}$ piece. Total momentum stays zero, so the heavy piece moves west at $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. The kinetic energy came from stored (chemical or spring) energy – momentum conservation does not require kinetic-energy conservation.
العربيةالقوى الداخلية تأتي في أزواج قانون نيوتن الثالث، لذا تلغي بعضها داخل أي نظام: يمكنها تغيير كمية التحرك بين الأجزاء لكنها لا تغير الكمية الكلية. لا تدخل كمية التحرك النظام ولا تتركه إلا عبر قوة خارجية محصلة ($\vec{J}=\Delta\vec{p}$). لذا، مع عدم وجود قوة خارجية محصلة، تكون كمية التحرك الكلية محفوظة:
$$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$كمية التحرك محفوظة في كل تصادم، بغض عن عنفه – اختر نظامًا كبيرًا بما يكفي لتكون قوى التصادم داخلية. طبق الحفظ بشكل منفصل على كل محور؛ يطلب امتحان AP عملاً كمياً بعدد واحد أو اثنين من الأبعاد.
اصطدام أمامي: الزخم الكلي قبل الاصطدام يساوي الزخم الكلي بعده مثال محلول (انفجار). قذيفة كتلتها $6.0\ \text{kg}$ كانت ساكنة تنقسم إلى قطعة كتلتها $2.0\ \text{kg}$ تتحرك بسرعة $9.0\ \text{m/s}$ نحو الشرق وقطعة كتلتها $4.0\ \text{kg}$. يبقى الزخم الكلي صفراً، لذا تتحرك القطعة الثقيلة غرباً بسرعة $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. جاءت الطاقة الحركية من طاقة مخزنة (كيميائية أو زنبركية) – حفظ الزخم لا يتطلب حفظ الطاقة الحركية.
Explore · استكشفCollide two carts and conserve momentum · اصطدم بعربة أخرى واحفظ الزخم
In any collision the total momentum $\sum mv$ before equals the total after. Set the masses and speeds and check the momentum bookkeeping. · في أي تصادم، يكون الزخم الكلي $\sum mv$ قبل التصادم مساويًا له بعد التصادم. حدد الكتل والسرعات وتحقق من حسابات الزخم.
4.4
Elastic and Inelastic Collisions · التصادمات المرنة وغير المرنة
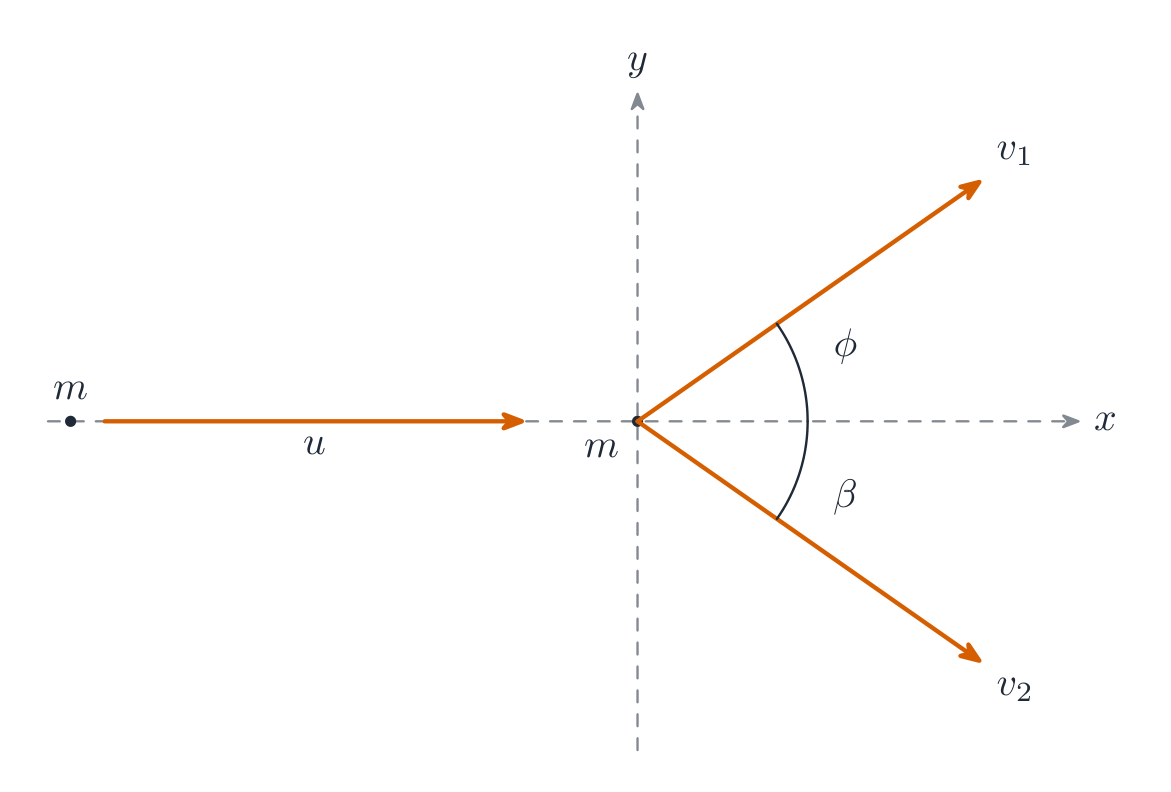
Syllabus · المنهج
EnglishLearning Objective 4.4.A: Describe whether an interaction between objects is elastic or inelastic.
- 4.4.A.1 An elastic collision between objects is one in which the initial kinetic energy of the system is equal to the final kinetic energy of the system.
- 4.4.A.2 In an elastic collision, the final kinetic energies of each of the objects within the system may be different from their initial kinetic energies.
- 4.4.A.3 An inelastic collision between objects is one in which the total kinetic energy of the system decreases.
- 4.4.A.4 In an inelastic collision, some of the initial kinetic energy is not restored to kinetic energy but is transformed by nonconservative forces into other forms of energy.
- 4.4.A.5 In a perfectly inelastic collision, the objects stick together and move with the same velocity after the collision.
العربيةالهدف التعليمي 4.4.A: صف ما إذا كان التفاعل بين الأجسام مرناً أم غير مرن.
- 4.4.A.1 التصادم المرن بين الأجسام هو الذي تكون فيه الطاقة الحركية الأولية للنظام مساوية للطاقة الحركية النهائية للنظام.
- 4.4.A.2 في التصادم المرن، قد تختلف الطاقة الحركية النهائية لكل من الأجسام داخل النظام عن طاقتها الحركية الأولية.
- 4.4.A.3 التصادم غير المرن بين الأجسام هو الذي تنخفض فيه الطاقة الحركية الكلية للنظام.
- 4.4.A.4 في التصادم غير المرن، لا تُستعاد بعض الطاقة الحركية الأولية كطاقة حركية، بل تتحول بواسطة قوى غير محتفظة إلى أشكال أخرى من الطاقة.
- 4.4.A.5 في التصادم غير المرن تماماً، تتصل الأجسام ببعضها وتتحرك بنفس السرعة بعد التصادم.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishConservation of momentum in a collision All collisions conserve momentum; they differ in what happens to the kinetic energy 动能:
type momentum kinetic energy elastic collision 弹性碰撞 conserved total conserved (individual shares may change) inelastic collision 非弹性碰撞 conserved decreases – some becomes heat, sound, deformation 形变 perfectly inelastic collision 完全非弹性碰撞 conserved largest possible loss – the objects stick and share one velocity Strategy: always write momentum conservation first; add the kinetic-energy equation only when the problem says "elastic". Two useful elastic facts: equal masses in a 1D elastic collision simply exchange velocities, and in the center-of-mass frame each object just reverses its velocity.
Worked example. A $1000\ \text{kg}$ car at $20\ \text{m/s}$ strikes a stationary $1500\ \text{kg}$ car and they lock together – perfectly inelastic. Momentum: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. Kinetic energy falls from $2.0\times10^5\ \text{J}$ to $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: about $60\%$ is lost, even though momentum is exactly conserved.
Worked example (2D). A puck moving east at $4.0\ \text{m/s}$ strikes an identical puck at rest; after the glancing hit, one moves at $2.0\ \text{m/s}$ at $60^\circ$ north of east. Conserve each axis: east–west, $m(4.0)=m(2.0)\cos60^\circ+mv_x$, so $v_x=3.0\ \text{m/s}$; north–south, $0=m(2.0)\sin60^\circ-mv_y$, so $v_y=1.7\ \text{m/s}$. The second puck moves at $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$, about $30^\circ$ south of east.
Exam skill. On FRQs, justify with the condition, not the slogan: "the net external force on the two-puck system is zero during the collision, so its total momentum is constant." If asked whether the collision is elastic, compute the kinetic energy before and after and compare – never assume.
العربيةحفظ الزخم في اصطدام جميع التصادمات تحفظ كمية التحرك؛ تختلف فيما يحدث لـ الطاقة الحركية:
النوع كمية التحرك الطاقة الحركية تصادم مرن محفوظة محفوظة كلياً (قد تتغير الحصص الفردية) تصادم غير مرن محفوظة تنخفض – جزء منها يتحول إلى حرارة وصوت وتشوه تصادم غير مرن تماماً محفوظة أكبر خسارة ممكنة – تتشبث الأجسام وتشترك في سرعة واحدة استراتيجية: اكتب دائمًا معادلة حفظ العزم؛ أضف معادلة الطاقة الحركية فقط عندما تقول المسألة "مرن". حقيتان مفيدتان عن التصادمات المرنة: كتلتان متساويتان في تصادم مرن 1D تبدلان سرعاتهما ببساطة، وفي إطار مركز الكتلة كل جسم يعكس سرعته فقط.
مثال محلول. سيارة وزنها $1000\ \text{kg}$ تتحرك بسرعة $20\ \text{m/s}$ تصدم سيارة ساكنة وزنها $1500\ \text{kg}$ وتتشبكان – تصادم غير مرن تماماً. كمية التحرك: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. تنخفض الطاقة الحركية من $2.0\times10^5\ \text{J}$ إلى $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: حوالي $60\%$ مفقودة، رغم أن كمية التحرك محفوظة بدقة.
مثال محلول (2D). قرص يتحرك نحو الشرق بسرعة $4.0\ \text{m/s}$ يصطدم بقرص مماثل في السكون؛ بعد الاصطدام المائل، يتحرك أحدهما بسرعة $2.0\ \text{m/s}$ بزاوية $60^\circ$ شمالًا من الشرق. نحفظ المحور لكل محور: شرق-غرب، $m(4.0)=m(2.0)\cos60^\circ+mv_x$، إذن $v_x=3.0\ \text{m/s}$؛ شمال-جنوب، $0=m(2.0)\sin60^\circ-mv_y$، إذن $v_y=1.7\ \text{m/s}$. يتحرك القرص الثاني بسرعة $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$، تقريبًا $30^\circ$ جنوبًا من الشرق.
تصادم جانبي، مُحلّل على طول محورين متعامدين مهارة الامتحان. في الأسئلة المقالية (FRQs)، برر باستخدام الشرط، لا الشعار: "القوة الخارجية المحصلة على نظام القرصين تساوي صفرًا أثناء الاصطدام، لذا فإن زخمه الكلي ثابت." إذا سُئل عما إذا كان الاصطدام مرناً، احسب الطاقة الحركية قبل وبعد الاصطدام وقارن بينهما – ولا تفترض ذلك أبدًا.
يعرض مجسم نيوتن مرور الزخم والطاقة الحركية خلال اصطدام شبه مرن Explore · استكشفCompare elastic and inelastic collisions · قارن بين التصادم المرن وغير المرن
Momentum is always conserved, but kinetic energy is only conserved in an elastic collision. In an inelastic one the carts stick and some energy becomes heat. · يُحفظ الزخم دائمًا، لكن الطاقة الحركية تُحفظ فقط في التصادم المرن. أما في التصادم غير المرن، فتلتصق العربات ببعضها وتتحول بعض الطاقة إلى حرارة.
4.4
Exam tips · نصائح للامتحان
English- Impulse equals the momentum change: $\vec J=\int \vec F\,dt=\Delta\vec p$, and it is the area under a force–time graph.
- Momentum is conserved whenever the net external force is zero — always the go-to for collisions.
- Distinguish elastic (kinetic energy conserved) from inelastic (kinetic energy decreases) collisions; in a perfectly inelastic collision the objects stick and move with one velocity.
- Apply conservation to each component (x and y) separately in 2-D.
- Connect to center of mass: total momentum $=M\vec v_{cm}$.
العربية- الاندفاع يساوي التغير في الزخم: $\vec J=\int \vec F\,dt=\Delta\vec p$، وهو المساحة تحت منحنى القوة–الزمن.
- يُحفظ الزخم كلما كانت القوة الخارجية المحصلة تساوي صفراً – وهي دائماً الحل الأمثل للاصطدامات.
- ميّز بين الاصطدامات المرونة (حيث تُحفظ الطاقة الحركية) والاصطدامات غير المرنة (حيث تنخفض الطاقة الحركية)؛ وفي الاصطدام غير المرن تماماً تلتصق الأجسام وتتحرك بسرعة واحدة.
- طبق مبدأ الحفظ على كل مركبة (x و y) بشكل منفصل في 2-D.
- ربط مركز الكتلة: الزخم الكلي $=M\vec v_{cm}$.
-
5
Torque and Rotational Dynamics · العزم والديناميكا الدورانية
Watch lesson · شاهد الدرس5.1
Rotational Kinematics
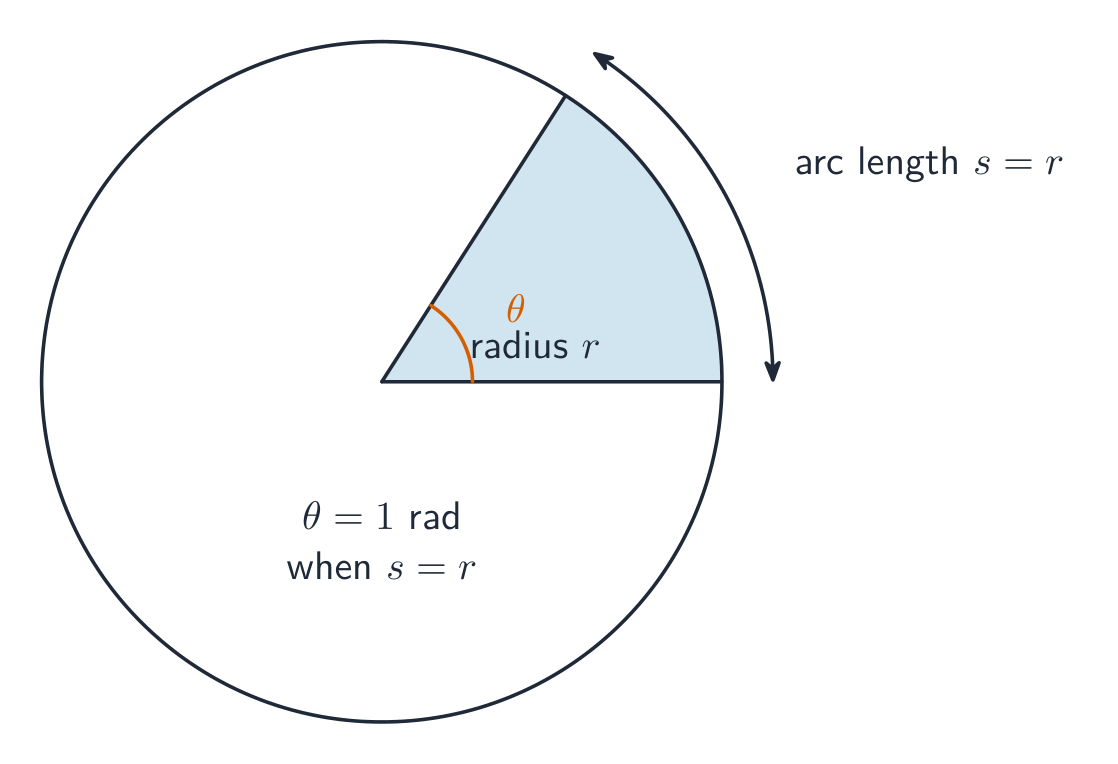
Syllabus · المنهج
EnglishLearning Objective 5.1.A: Describe the rotation of a system with respect to time using angular displacement, angular velocity, and angular acceleration.
- 5.1.A.1 Angular displacement is the measurement of the angle, in radians, through which a point on a rigid system rotates about a specified axis.
- Equation: $\Delta\theta = \theta - \theta_0$
- 5.1.A.1.i A rigid system is one that holds its shape but in which different points on the system move in different directions during rotation. A rigid system cannot be modeled as an object.
- 5.1.A.1.ii One direction of angular displacement about an axis of rotation—clockwise or counterclockwise—is typically indicated as mathematically positive, with the other direction becoming mathematically negative.
- 5.1.A.1.iii If the rotation of a system about an axis may be well described using the motion of the system's center of mass, the system may be treated as a single object. For example, the rotation of Earth about its axis may be considered negligible when considering the revolution of Earth about the center of mass of the Earth–Sun system.
- 5.1.A.2 Angular velocity is the rate at which angular position changes with respect to time.
- Equation: $\omega = \dfrac{d\theta}{dt}$
- 5.1.A.3 Angular acceleration is the rate at which angular velocity changes with respect to time.
- Equation: $\alpha = \dfrac{d\omega}{dt}$
- 5.1.A.4 Angular displacement, angular velocity, and angular acceleration around one axis are analogous to linear displacement, velocity, and acceleration in one dimension and demonstrate the same mathematical relationships.
- 5.1.A.4.i For constant angular acceleration, the mathematical relationships between angular displacement, angular velocity, and angular acceleration can be described with the following equations:
- $\omega = \omega_0 + \alpha t$
- $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
- $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
- 5.1.A.4.ii Graphs of angular displacement, angular velocity, and angular acceleration as functions of time can be used to find the relationships between those quantities.
- 5.1.A.4.i For constant angular acceleration, the mathematical relationships between angular displacement, angular velocity, and angular acceleration can be described with the following equations:
Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of said vectors will not be assessed on the exam.
Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.
العربيةالهدف التعليمي 5.1.A: صف دوران نظام بالنسبة للزمن باستخدام الإزاحة الزاوية والسرعة الزاوية والتسارع الزاوي.
- 5.1.A.1 الإزاحة الزاوية هي قياس الزاوية بالراديان التي يدور حولها نقطة على نظام صلب حول محور معين.
- المعادلة: $\Delta\theta = \theta - \theta_0$
- 5.1.A.1.i النظام الصلب هو نظام يحافظ على شكله ولكن نقاط مختلفة عليه تتحرك في اتجاهات مختلفة أثناء الدوران. لا يمكن نمذجة النظام الصلب كجسم واحد.
- 5.1.A.1.ii عادةً ما يُشار إلى أحد اتجاهي الإزاحة الزاوية حول محور الدوران—سواء كان عقارب الساعة أو عكس عقارب الساعة—كمقدار رياضي موجب، بينما يصبح الاتجاه الآخر سالباً رياضياً.
- 5.1.A.1.iii إذا كان دوران النظام حول محور يمكن وصفه جيداً باستخدام حركة مركز كتلته، يمكن التعامل معه كجسم واحد. على سبيل المثال، يمكن اعتبار دوران الأرض حول محورها مهملاً عند النظر في revolution الأرض حول مركز كتل نظام الأرض-الشمس.
- 5.1.A.2 السرعة الزاوية هي المعدل الذي يتغير به الموضع الزاوي بالنسبة للزمن.
- المعادلة: $\omega = \dfrac{d\theta}{dt}$
- 5.1.A.3 التسارع الزاوي هو المعدل الذي تتغير به السرعة الزاوية بالنسبة للزمن.
- المعادلة: $\alpha = \dfrac{d\omega}{dt}$
- 5.1.A.4 الإزاحة الزاوية والسرعة الزاوية والتسارع الزاوي حول محور واحد مماثلة للإزاحة الخطية والسرعة والتسارع في بُعد واحد وتظهر نفس العلاقات الرياضية.
- 5.1.A.4.i بالنسبة للتسارع الزاوي الثابت، يمكن وصف العلاقات الرياضية بين الإزاحة الزاوية والسرعة الزاوية والتسارع الزاوي بالمعادلات التالية:
- $\omega = \omega_0 + \alpha t$
- $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
- $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
- 5.1.A.4.ii يمكن استخدام رسوم بيانية للإزاحة الزاوية والسرعة الزاوية والتسارع الزاوي بدلالة الزمن لإيجاد العلاقات بين تلك الكميات.
- 5.1.A.4.i بالنسبة للتسارع الزاوي الثابت، يمكن وصف العلاقات الرياضية بين الإزاحة الزاوية والسرعة الزاوية والتسارع الزاوي بالمعادلات التالية:
بيان الحدود: يتوقع امتحان AP Physics C: Mechanics من الطلاب القدرة على التعامل الرياضي مع مقادير الإزاحة الزاوية والسرعة الزاوية والتسارع الزاوي باستخدام قواعد المتجهات. ومع ذلك، لن يتم تقييم اتجاهات تلك المتجهات في الامتحان.
تقتصر وصفات اتجاهات كميات الحركة الدورانية لنقطة أو جسم صلب على الاتجاهين عقارب الساعة وعكس عقارب الساعة بالنسبة لمحور دوران محدد.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Rotation mirrors linear motion with angular quantities, defined as derivatives:
$$\omega=\frac{d\theta}{dt},\qquad \alpha=\frac{d\omega}{dt}=\frac{d^2\theta}{dt^2}.$$Here $\theta$ is angular displacement 角位移 in radians 弧度, $\omega$ the angular velocity 角速度, and $\alpha$ the angular acceleration 角加速度. (AP works with their magnitudes and signs; the 3D vector directions are not assessed.) For constant $\alpha$, the kinematic equations are the linear ones re-lettered:
$$\omega=\omega_0+\alpha t,\qquad \Delta\theta=\omega_0t+\tfrac12\alpha t^2,\qquad \omega^2=\omega_0^2+2\alpha\,\Delta\theta.$$One radian is the angle whose arc length equals the radius Worked example. A fan blade slows from $30\ \text{rad/s}$ to rest with $\alpha=-6.0\ \text{rad/s}^2$: it takes $t=5.0\ \text{s}$ and turns through $\Delta\theta=\dfrac{0-30^2}{2(-6.0)}=75\ \text{rad}$ – about $12$ revolutions.
Vocabulary · مفردات Train · تدريبEnglish العربية angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ الإزاحة الزاوية radians/ˈreɪdɪənz/ راديان angular velocity/ˈæŋɡjʊlə vəˈlɒsɪti/ السرعة الزاوية angular acceleration/ˈæŋɡjʊlə əkˌseləˈreɪʃn/ التسارع الزاوي 5.2
Connecting Linear and Rotational Motion
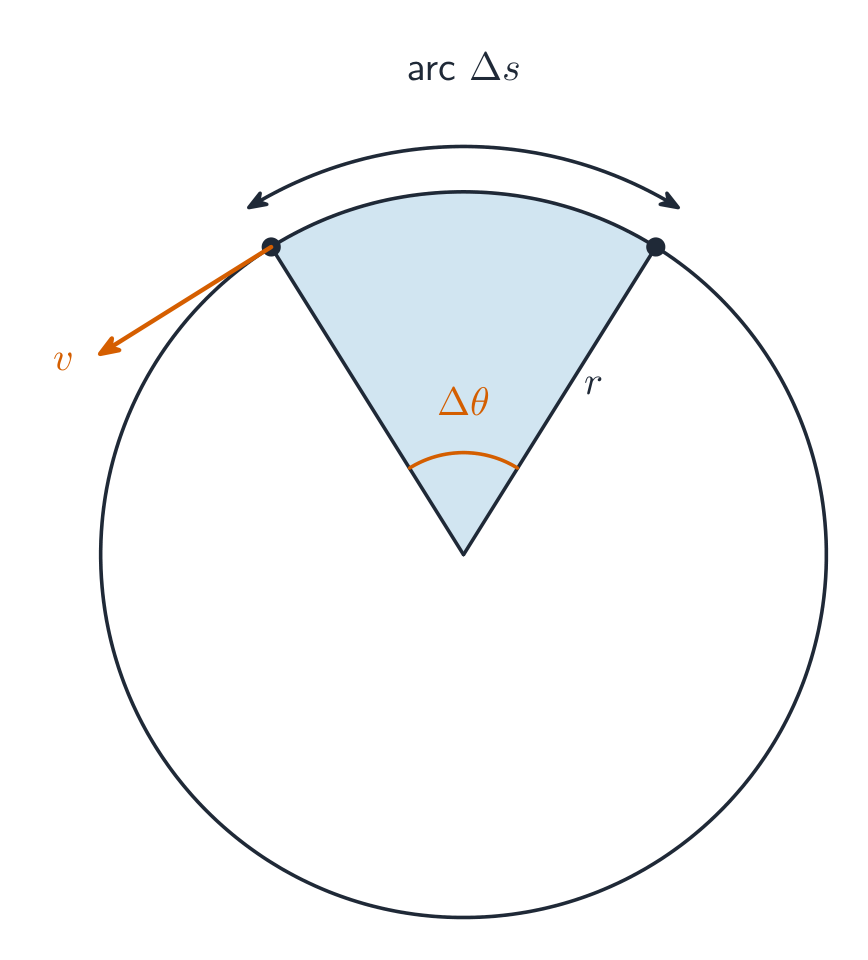
Syllabus · المنهج
EnglishLearning Objective 5.2.A: Describe the linear motion of a point on a rotating rigid system that corresponds to the rotational motion of that point, and vice versa.
- 5.2.A.1 For a point at a distance $r$ from a fixed axis of rotation, the linear distance $s$ traveled by the point as the system rotates through an angle $\Delta\theta$ is given by the equation $\Delta s = r\Delta\theta$.
- 5.2.A.2 Derived relationships of linear velocity and of the tangential component of acceleration to their respective angular quantities are given by the following equations:
- $s = r\theta$
- $v = r\omega$
- $a_T = r\alpha$
- 5.2.A.3 For a rigid system, all points within that system have the same angular velocity and angular acceleration.
Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of the vectors will not be assessed on the exam.
Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.
العربيةالهدف التعليمي 5.2.A: صف الحركة الخطية لنقطة على نظام صلب دوار تقابل الحركة الدورانية لتلك النقطة، والعكس صحيح.
- 5.2.A.1 بالنسبة لنقطة على مسافة $r$ من محور دوران ثابت، تُعطى المسافة الخطية $s$ المقطوعة بواسطة النقطة عندما يدور النظام بزاوية $\Delta\theta$ بالمعادلة $\Delta s = r\Delta\theta$.
- 5.2.A.2 تُعطى العلاقات المشتقة للسرعة الخطية والمكون المماسي للتسارع لكمياتها الزاوية المقابلة بالمعادلات التالية:
- $s = r\theta$
- $v = r\omega$
- $a_T = r\alpha$
- 5.2.A.3 بالنسبة للنظام الصلب، جميع النقاط داخل ذلك النظام لها نفس السرعة الزاوية والتسارع الزاوي.
بيان الحدود: يتوقع امتحان AP Physics C: Mechanics من الطلاب القدرة على التعامل الرياضي مع مقادير الإزاحة الزاوية والسرعة الزاوية والتسارع الزاوي باستخدام قواعد المتجهات. ومع ذلك، لن يتم تقييم اتجاهات المتجهات في الامتحان.
تقتصر وصفات اتجاهات كميات الحركة الدورانية لنقطة أو جسم صلب على الاتجاهين عقارب الساعة وعكس عقارب الساعة بالنسبة لمحور دوران محدد.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
A point at radius $r$ from the axis moves along its arc with
$$s=r\theta,\qquad v=r\omega,\qquad a_t=r\alpha,$$so points farther out move faster. A rotating point generally has two acceleration components at once: the tangential acceleration 切向加速度 $a_t=r\alpha$ (speeding up along the arc) and the centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}=r\omega^2$ (turning, towards the axis). They are perpendicular, so $a=\sqrt{a_t^2+a_c^2}$.
As the radius turns through an angle, a point moves along an arc at speed v Vocabulary · مفردات Train · تدريبEnglish العربية tangential acceleration/tænˈdʒenʃl əkˌseləˈreɪʃn/ التسارع المماسي centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ التسارع المركزي 5.3
Torque
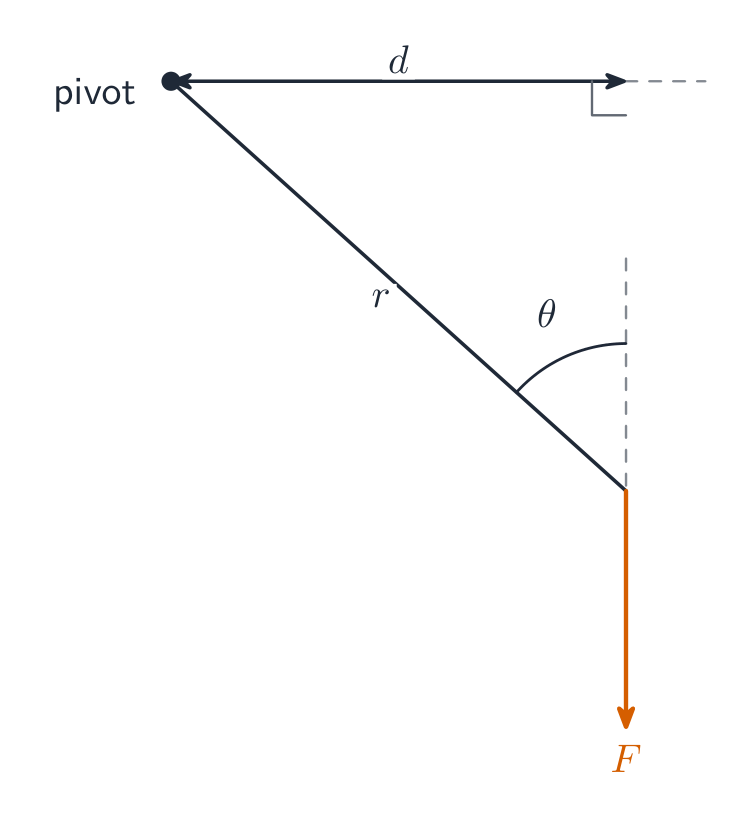
Syllabus · المنهج
EnglishLearning Objective 5.3.A: Identify the torques exerted on a rigid system.
- 5.3.A.1 Torque results only from the force component perpendicular to the position vector from the axis of rotation to the point of application of the force.
- 5.3.A.2 The lever arm is the perpendicular distance from the axis of rotation to the line of action of the exerted force.
Learning Objective 5.3.B: Describe the torques exerted on a rigid system.
- 5.3.B.1 Torques can be described using force diagrams.
- 5.3.B.1.i Force diagrams are similar to free-body diagrams and are used to analyze the torques exerted on a rigid system.
- 5.3.B.1.ii Similar to free-body diagrams, force diagrams represent the relative magnitude and direction of the forces exerted on a rigid system. Force diagrams also depict the location at which those forces are exerted relative to the axis of rotation.
- 5.3.B.2 The torque exerted on a rigid system about a chosen pivot point by a given force is described by $\vec{\tau} = \vec{r} \times \vec{F}$.
- 5.3.B.2.i The cross-product between two vectors, $\vec{A}$ and $\vec{B}$, results in a vector quantity of magnitude $\vec{A} \times \vec{B} = AB\sin\theta$.
- 5.3.B.2.ii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ is perpendicular to both vectors $\vec{A}$ and $\vec{B}$ and therefore is normal to the plane defined by vectors $\vec{A}$ and $\vec{B}$.
- 5.3.B.2.iii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ can be qualitatively determined by applying the appropriate right-hand rule.
العربيةالهدف التعليمي 5.3.A: حدد عزوم القوى المؤثرة على نظام صلب.
- 5.3.A.1 ينتج العزم فقط من مركبة القوة العمودية على متجه الموضع من محور الدوران إلى نقطة تطبيق القوة.
- 5.3.A.2 ذراع العزم هو المسافة العمودية من محور الدوران إلى خط عمل القوة المؤثرة.
الهدف التعليمي 5.3.B: وصف العزوم المؤثرة على نظام صلب.
- 5.3.B.1 يمكن وصف العزوم باستخدام مخططات القوة.
- 5.3.B.1.i تشبه مخططات القوة مخططات الجسم الحر وتُستخدم لتحليل العزوم المؤثرة على نظام صلب.
- 5.3.B.1.ii مثل مخططات الجسم الحر، تمثل مخططات القوة المقدار والاتجاه النسبيين للقوى المؤثرة على نظام صلب. كما تصور مخططات القوة الموقع الذي تُطبق فيه تلك القوى بالنسبة لمحور الدوران.
- 5.3.B.2 يُوصف عزم القوة المؤثر على نظام صلب حول نقطة ارتكاز مختارة بواسطة قوة معينة بالمعادلة $\vec{\tau} = \vec{r} \times \vec{F}$.
- 5.3.B.2.i حاصل الضرب الاتجاهي بين متجهين، $\vec{A}$ و$\vec{B}$، ينتج عنه كمية متجهة مقدارها $\vec{A} \times \vec{B} = AB\sin\theta$.
- 5.3.B.2.ii اتجاه المتجه الناتج عن الضرب الاتجاهي للمتجهين $\vec{A}$ و$\vec{B}$ يكون عمودياً على كل من المتجهين $\vec{A}$ و$\vec{B}$، وبالتالي يكون طبيعياً للمستوى المحدد بالمتجهين $\vec{A}$ و$\vec{B}$.
- 5.3.B.2.iii يمكن تحديد اتجاه المتجه الناتج عن الضرب الاتجاهي للمتجهين $\vec{A}$ و$\vec{B}$ بشكل نوعي بتطبيق قاعدة اليد اليمنى المناسبة.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
The principle of moments (torque) Torque 力矩 is the turning effect of a force – the rotational cause, as force is the translational cause. It is a vector product 矢量积:
$$\vec{\tau}=\vec{r}\times\vec{F},\qquad \tau=rF\sin\theta=F\,r_\perp,$$where $r_\perp$, the moment arm 力臂, is the perpendicular distance from the axis to the force's line of action. More force, applied farther from the axis, more perpendicular: more torque. A force pointing straight at (or away from) the axis has zero torque. In a plane, give counterclockwise and clockwise torques opposite signs and add.
As a vector product, $\vec\tau=\vec r\times\vec F$ points perpendicular to the plane of $\vec r$ and $\vec F$, with its direction fixed by the right-hand rule 右手定则: curl your right fingers from $\vec r$ toward $\vec F$ and your thumb points along $\vec\tau$ – out of the page for a counterclockwise turn, into it for a clockwise one. The same rule gives the direction of angular momentum $\vec L=\vec r\times\vec p$.
The torque of a force depends on the perpendicular distance from the axis 
A gear train: torques and rotational inertia couple through the gear ratio Explore · استكشفBalance torques on a beam · وازن العزوم على عارضة
Torque is force times perpendicular distance, $\tau=Fd$. The beam is in rotational equilibrium when the torques on each side are equal. · العزم هو حاصل ضرب القوة في المسافة العمودية، $\tau=Fd$. تكون العارضة في اتزان دوراني عندما تتساوى العزوم على كلا الجانبين.
Vocabulary · مفردات Train · تدريبEnglish العربية Torque/tɔːk/ العزم vector product/ˈvektə ˈprɒdʌkt/ الجداء الاتجاهي moment arm/ˈməʊmənt ɑːm/ ذراع العزم right-hand rule/raɪt hænd ruːl/ قاعدة اليد اليمنى 5.4
Rotational Inertia
Syllabus · المنهج
EnglishLearning Objective 5.4.A: Describe the rotational inertia of a rigid system relative to a given axis of rotation.
- 5.4.A.1 Rotational inertia measures a rigid system's resistance to changes in rotation and is related to the mass of the system and the distribution of that mass relative to the axis of rotation.
- 5.4.A.2 The rotational inertia of an object rotating a perpendicular distance $r$ from an axis is described by the equation $I = mr^2$.
- 5.4.A.3 The total rotational inertia of a collection of objects about an axis is the sum of the rotational inertias of each object about that axis.
- Equation: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
- 5.4.A.4 For a solid that can be considered as a collection of differential masses, $dm$, the solid's rotational inertia can be calculated using the equation $I = \int r^2\, dm$, where $r$ is the perpendicular distance from $dm$ to the axis of rotation.
Learning Objective 5.4.B: Describe the rotational inertia of a rigid system rotating about an axis that does not pass through the system's center of mass.
- 5.4.B.1 A rigid system's rotational inertia in a given plane is at a minimum when the rotational axis passes through the system's center of mass.
- 5.4.B.2 The parallel axis theorem uses the following equation to relate the rotational inertia of a rigid system about any axis that is parallel to an axis through its center of mass:
- Equation: $I' = I_{\text{cm}} + Md^2$
Boundary statement: AP Physics C: Mechanics only expects students to use calculus in the derivations of the rotational inertia of thin rods of uniform or nonuniform density about an arbitrary axis perpendicular to the rod, as well as derivations of the rotational inertia of a thin cylindrical shell, disk, or rigid bodies that can be considered to be made up of coaxial rings or shells about an axis that passes through their centers (e.g., annular rings).
Students should have a qualitative understanding of the factors that affect rotational inertia; for example, how rotational inertia is greater when mass is farther from the axis of rotation, which is why a hoop has more rotational inertia than a solid puck of the same mass and radius.
العربيةالهدف التعليمي 5.4.A: وصف القصور الذاتي الدوراني لنظام صلب بالنسبة لمحور دوران محدد.
- 5.4.A.1 يقيس القصور الذاتي الدوراني مقاومة النظام الصلب للتغيرات في الدوران وهو مرتبط بكتلة النظام وتوزيع هذه الكتلة بالنسبة لمحور الدوران.
- 5.4.A.2 يُوصف العزم القصور الذاتي لجسم يدور على مسافة عمودية $r$ من محور الدوران بالمعادلة $I = mr^2$.
- 5.4.A.3 العزم القصور الذاتي الكلي لمجموعة من الأجسام حول محور ما هو مجموع عزوم قصورها الذاتية لكل جسم حول ذلك المحور.
- المعادلة: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
- 5.4.A.4 بالنسبة لجسم صلب يمكن اعتباره مجموعة من الكتل التفاضلية، $dm$، يمكن حساب العزم القصور الذاتي للجسم الصلب باستخدام المعادلة $I = \int r^2\, dm$، حيث $r$ هو المسافة العمودية من $dm$ إلى محور الدوران.
الهدف التعليمي 5.4.B: وصف القصور الذاتي الدوراني لنظام صلب يدور حول محور لا يمر عبر مركز كتلته.
- 5.4.B.1 يكون القصور الذاتي الدوراني للنظام الصلب في مستوى معين في أدنى حد له عندما يمر محور الدوران عبر مركز كتلته.
- 5.4.B.2 يستخدم قانون المحور الموازي المعادلة التالية لربط القصور الذاتي الدوراني لنظام صلب حول أي محور موازٍ لمحور يمر عبر مركز كتلته:
- المعادلة: $I' = I_{\text{cm}} + Md^2$
بيان الحدود: يتوقع امتحان AP Physics C: Mechanics من الطلاب استخدام التفاضل والتكامل فقط في اشتقاق العزم القصور الذاتي لأعمدة رقيقة ذات كثافة منتظمة أو غير منتظمة حول محور عشوائي عمودي على العمود، وكذلك اشتقاق العزم القصور الذاتي لقشرة أسطوانية رقيقة، أو قرص، أو أجسام صلبة يمكن اعتبارها مكونة من حلقات أو قشور متماثلة المحور حول محور يمر بمراكزها (مثل الحلقات الدائرية).
يجب أن يمتلك الطلاب فهماً نوعياً للعوامل التي تؤثر على العزم القصور الذاتي؛ على سبيل المثال، كيف يكون العزم القصور الذاتي أكبر عندما تكون الكتلة أبعد عن محور الدوران، وهو السبب في أن الحلقة لها عزم قصور ذاتي أكبر من القرص الصلب ذي نفس الكتلة ونصف القطر.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Rotational inertia 转动惯量 $I$ measures resistance to angular acceleration – the rotational analog of mass, but it depends on where the mass sits. For point masses, $I=\sum m_ir_i^2$; for a continuous body,
$$I=\int r^2\,dm.$$Mass far from the axis dominates, because of the $r^2$.
Worked example (rod). A uniform rod (mass $M$, length $L$) about its centre: with linear density 线密度 $\lambda=M/L$, $dm=\lambda\,dx$, so $I=\displaystyle\int_{-L/2}^{L/2}x^2\,\frac{M}{L}\,dx=\frac{1}{12}ML^2$. AP also expects nonuniform rods: if $\lambda(x)=cx$ on $[0,L]$, first find $M=\int_0^L cx\,dx=\tfrac12cL^2$, then $I=\int_0^L x^2(cx)\,dx=\tfrac14cL^4=\tfrac12ML^2$ about the light end.
Worked example (disk from rings). A solid disk is a nest of rings: a ring at radius $r$ of width $dr$ has $dm=\dfrac{M}{\pi R^2}\,2\pi r\,dr$, so
$$I=\int_0^R r^2\,dm=\frac{2M}{R^2}\int_0^R r^3\,dr=\tfrac12MR^2.$$The same coaxial-shell method handles cylindrical shells and annular rings.
The parallel-axis theorem 平行轴定理 shifts any known $I$ to a parallel axis a distance $d$ away:
$$I'=I_{\text{cm}}+Md^2.$$For the rod about one end: $I=\tfrac1{12}ML^2+M\big(\tfrac{L}{2}\big)^2=\tfrac13ML^2$.
Vocabulary · مفردات Train · تدريبEnglish العربية Rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ العزم القصور الذاتي linear density/ˈlɪnɪə ˈdensɪti/ الكثافة الخطية parallel-axis theorem/ˈpærəlel ˈæksɪs ˈθɪərəm/ نظرية المحور الموازي 5.5
Rotational Equilibrium
Syllabus · المنهج
EnglishLearning Objective 5.5.A: Describe the conditions under which a system's angular velocity remains constant.
- 5.5.A.1 A system may exhibit rotational equilibrium (constant angular velocity) without being in translational equilibrium, and vice versa.
- 5.5.A.1.i Free-body and force diagrams describe the nature of the forces and torques exerted on an object or rigid system.
- 5.5.A.1.ii Rotational equilibrium is a configuration of torques such that the net torque exerted on the system is zero.
- Equation: $\sum \tau_i = 0$
- 5.5.A.1.iii The rotational analog of Newton's first law is that a system will have a constant angular velocity only if the net torque exerted on the system is zero.
- 5.5.A.2 A rotational corollary to Newton's second law states that if the torques exerted on a rigid system are not balanced, the system's angular velocity must be changing.
Boundary statement: AP Physics C: Mechanics does not expect students to simultaneously analyze rotation in multiple planes.
العربيةالهدف التعليمي 5.5.A: وصف الظروف التي تظل فيها سرعة زاوية النظام ثابتة.
- 5.5.A.1 قد يظهر النظام توازناً دورانياً (سرعة زاوية ثابتة) دون أن يكون في حالة توازن انتقالي، والعكس صحيح.
- 5.5.A.1.i تصف مخططات الجسم الحر ومخططات القوة طبيعة القوى والعزوم المؤثرة على جسم أو نظام صلب.
- 5.5.A.1.ii التوازن الدوراني هو ترتيب للعزوم بحيث يكون صافي العزم المؤثر على النظام مساوياً للصفر.
- معادلة: $\sum \tau_i = 0$
- 5.5.A.1.iii النظير الدوراني لقانون نيوتن الأول ينص على أن النظام سيحافظ على سرعة زاوية ثابتة فقط إذا كان صافي العزم المؤثر عليه مساوياً للصفر.
- 5.5.A.2 ينص نظير دوراني لقانون نيوتن الثاني على أنه إذا كانت العزوم المؤثرة على نظام صلب غير متوازنة، يجب أن تتغير سرعة زاوية النظام.
بيان الحدود: لا يتوقع امتحان AP Physics C: Mechanics من الطلاب تحليل الدوران في مستويات متعددة في آنٍ واحد.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Newton's first law has a rotational form: with zero net torque, angular velocity is constant – an object in rotational equilibrium 转动平衡 either does not rotate or rotates steadily. Full static equilibrium 静平衡 needs both $\sum F=0$ and $\sum\tau=0$ (about any axis). The standard move for beams and ladders: put the axis at the point where an unknown force acts, so that force drops out of the torque equation.
At balance the clockwise and anticlockwise torques about the axis are equal Worked example. A uniform $20\ \text{kg}$ beam, $4.0\ \text{m}$ long, is pivoted at its left end and held horizontal by a vertical rope at its right end. A $40\ \text{kg}$ child sits $1.0\ \text{m}$ from the pivot. Torques about the pivot: $T(4.0)=20g(2.0)+40g(1.0)$, so $T=\dfrac{392+392}{4.0}=196\ \text{N}$. Then vertical force balance gives the pivot's upward push: $F_p=(60)(9.8)-196=392\ \text{N}$. Choosing the pivot as the axis removed $F_p$ from the torque equation entirely.
A beam balance: rotational equilibrium when clockwise and anticlockwise torques match Explore · استكشفFind the balance point · أوجد نقطة التوازن.
For rotational equilibrium the total clockwise torque equals the total anticlockwise torque. Move the forces and distances until the beam balances. · من أجل الاتزان الدوراني، يجب أن يساوي مجموع عزوم الاتجاه عقاربياً مجموع عزوم الاتجاه المعاكس لعقارب الساعة. حوّل القوى والمسافات حتى تتوازن العارضة.
Vocabulary · مفردات Train · تدريبEnglish العربية rotational equilibrium/rəʊˈteɪʃənl ˌiːkwɪˈlɪbrɪəm/ التوازن الدوراني static equilibrium/ˈstætɪk ˌiːkwɪˈlɪbrɪəm/ التوازن الساكن 5.6
Newton's Second Law in Rotational Form
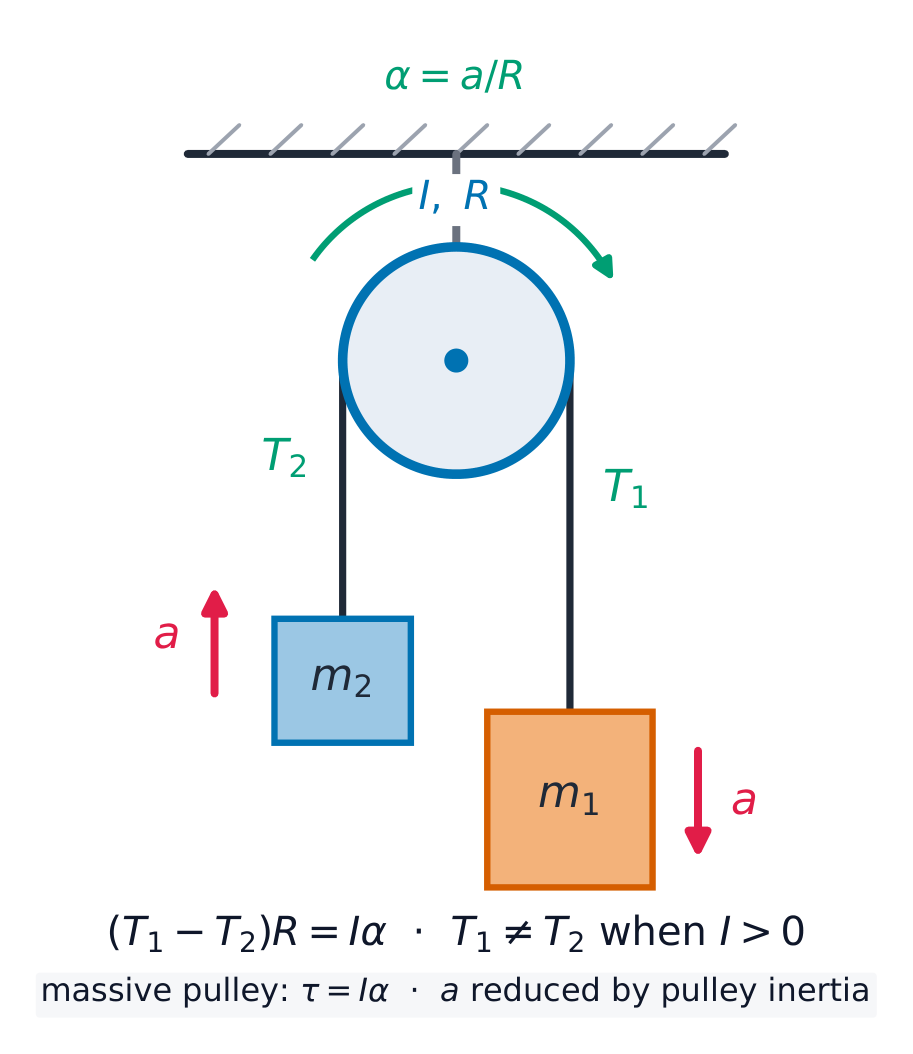
Syllabus · المنهج
EnglishLearning Objective 5.6.A: Describe the conditions under which a system's angular velocity changes.
- 5.6.A.1 Angular velocity changes when the net torque exerted on the object or system is not equal to zero.
- 5.6.A.2 The rate at which the angular velocity of a rigid system changes is directly proportional to the net torque exerted on the rigid system and is in the same direction. The angular acceleration of the rigid system is inversely proportional to the rotational inertia of the rigid system.
- Equation: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
- 5.6.A.3 To fully describe a rotating rigid system, linear and rotational analyses may need to be performed independently.
العربيةالهدف التعليمي 5.6.A: وصف الظروف التي تتغير فيها سرعة زاوية النظام.
- 5.6.A.1 تتغير السرعة الزاوية عندما لا يساوي صافي العزم المؤثر على الجسم أو النظام الصفر.
- 5.6.A.2 معدل تغير السرعة الزاوية لنظام صلب يتناسب طردياً مع صافي العزم المؤثر على النظام الصلب ويكون في نفس الاتجاه. يتناسب التسارع الزاوي للنظام الصلب عكسياً مع القصور الذاتي الدوراني للنظام الصلب.
- المعادلة: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
- 5.6.A.3 لوصف نظام صلب دوار بشكل كامل، قد يلزم إجراء تحليلين خطي ودوراني بشكل مستقل.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
A net torque produces angular acceleration in proportion to the rotational inertia:
$$\alpha=\frac{\sum\tau}{I}\qquad\Big(\text{more generally }\sum\vec{\tau}=\frac{d\vec{L}}{dt}\Big).$$Solve rotational dynamics exactly like translational dynamics, with $\tau\leftrightarrow F$, $I\leftrightarrow m$, $\alpha\leftrightarrow a$ – free-body diagram, equations, solve.
A massive pulley: the two tensions differ because the pulley needs net torque Worked example (massive pulley). Masses $m_1=4.0\ \text{kg}$ and $m_2=2.0\ \text{kg}$ hang from a rope over a pulley 滑轮 of rotational inertia $I=0.50\ \text{kg}\cdot\text{m}^2$ and radius $R=0.20\ \text{m}$. Three Newton's-law equations, one per body:
$$m_1g-T_1=m_1a,\qquad T_2-m_2g=m_2a,\qquad (T_1-T_2)R=I\alpha=\frac{Ia}{R}.$$Adding them (with $I/R^2=12.5\ \text{kg}$): $a=\dfrac{(m_1-m_2)g}{m_1+m_2+I/R^2}=\dfrac{19.6}{18.5}=1.1\ \text{m/s}^2$. Then $T_1=m_1(g-a)=35\ \text{N}$ and $T_2=m_2(g+a)=22\ \text{N}$. The tensions must differ – otherwise nothing would spin the pulley. (If a problem says the pulley is light, then $I\approx0$ and the tensions become equal again.)
Exam skill. Rotational FRQs score the setup: separate free-body diagrams for each mass and the pulley, the string constraint $a=R\alpha$ stated, and the sign convention consistent. The single most common error is assuming one tension throughout a rope that passes over a massive pulley.
Vocabulary · مفردات Train · تدريبEnglish العربية pulley/ˈpʊli/ بكرة 5.6
Exam tips
- Use the rotational analogues: $\theta,\omega=\tfrac{d\theta}{dt},\alpha=\tfrac{d\omega}{dt}$, with the constant-$\alpha$ equations mirroring linear kinematics.
- Convert between linear and angular with $v=r\omega$ and $a_t=r\alpha$ (plus centripetal $a_c=\tfrac{v^2}{r}=\omega^2 r$).
- Keep radians throughout and fix a positive sense of rotation.
- Relate torque to angular acceleration through $\tau=I\alpha$.
- Draw the rotation axis — the moment arm is the perpendicular distance to it.
- 5.1.A.1 Angular displacement is the measurement of the angle, in radians, through which a point on a rigid system rotates about a specified axis.
-
6
Energy and Momentum of Rotating Systems · الطاقة والزخم للأنظمة الدوارة
Watch lesson · شاهد الدرس6.1
Rotational Kinetic Energy
Syllabus · المنهج
EnglishLearning Objective 6.1.A: Describe the rotational kinetic energy of a rigid system in terms of the rotational inertia and angular velocity of that rigid system.
- 6.1.A.1 The rotational kinetic energy of an object or rigid system is related to the rotational inertia and angular velocity of the rigid system and is given by the equation $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
- Equation: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
- 6.1.A.1.i The rotational inertia of an object about a fixed axis can be used to show that the rotational kinetic energy of that object is equivalent to its translational kinetic energy, which is its total kinetic energy.
- 6.1.A.1.ii The total kinetic energy of a rigid system is the sum of its rotational kinetic energy due to its rotation about its center of mass and the translational kinetic energy due to the linear motion of its center of mass.
- 6.1.A.2 A rigid system can have rotational kinetic energy while its center of mass is at rest due to the individual points within the rigid system having linear speed and, therefore, kinetic energy.
- 6.1.A.3 Rotational kinetic energy is a scalar quantity.
العربيةالهدف التعليمي 6.1.A: وصف الطاقة الحركية الدورانية لنظام صبل بدلالة القصور الذاتي الدوراني والسرعة الزاوية لذلك النظام الصلب.
- 6.1.A.1 ترتبط الطاقة الحركية الدورانية لجسم أو نظام صلب بالقصور الذاتي الدوراني والسرعة الزاوية للنظام الصلب وتُعطى بالمعادلة $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
- المعادلة: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
- 6.1.A.1.i يمكن استخدام القصور الذاتي الدوراني لجسم حول محور ثابت لإظهار أن الطاقة الحركية الدورانية لذلك الجسم تكافئ طاقتها الحركية الانتقالية، وهي طاقتها الحركية الكلية.
- 6.1.A.1.ii الطاقة الحركية الكلية لنظام صبل هي مجموع طاقتها الحركية الدورانية الناتجة عن دورانها حول مركز كتلتها والطاقة الحركية الانتقالية الناتجة عن الحركة الخطية لمركز كتلتها.
- 6.1.A.2 يمكن أن يمتلك النظام الصلب طاقة حركية دورانية بينما يكون مركز كتلته ساكناً بسبب امتلاك النقاط الفردية داخل النظام الصلب سرعة خطية وبالتالي طاقة حركية.
- 6.1.A.3 الطاقة الحركية الدورانية كمية قياسية.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
A spinning body has rotational kinetic energy 转动动能
$$K_{\text{rot}}=\tfrac12 I\omega^2,$$the rotational twin of $\tfrac12mv^2$, with the rotational inertia 转动惯量 $I$ playing the role of mass. A body that both moves and spins carries both terms:
$$K=\tfrac12 mv_{\text{cm}}^2+\tfrac12 I\omega^2.$$Worked example. A uniform cylinder ($I=\tfrac12mr^2$) rolls at speed $v$. Its kinetic energy is $K=\tfrac12mv^2+\tfrac12\big(\tfrac12mr^2\big)\big(\tfrac{v}{r}\big)^2=\tfrac34mv^2$ – one third of it is rotational. The same ball of energy bookkeeping decides every rolling problem.
Vocabulary · مفردات Train · تدريبEnglish العربية rotational kinetic energy/rəʊˈteɪʃənl kɪˈnetɪk ˈenədʒi/ الطاقة الحركية الدورانية rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ القصور الذاتي الدوراني 6.2
Torque and Work
Syllabus · المنهج
EnglishLearning Objective 6.2.A: Describe the work done on a rigid system by a given torque or collection of torques.
- 6.2.A.1 A torque can transfer energy into or out of an object or rigid system if the torque is exerted over an angular displacement.
- 6.2.A.2 The amount of work done on a rigid system by a torque is related to the magnitude of that torque and the angular displacement through which the rigid system rotates during the interval in which that torque is exerted.
- Equation: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
- 6.2.A.3 Work done on a rigid system by a given torque can be found from the area under the curve of a graph of the torque as a function of angular position.
العربيةهدف التعلم 6.2.A: وصف الشغل المبذول على نظام صلب بواسطة عزم معطى أو مجموعة من العزوم.
- 6.2.A.1 يمكن للعزم نقل الطاقة إلى جسم أو نظام صلب أو إخراجها إذا تم تطبيق العزم خلال إزاحة زاوية.
- 6.2.A.2 يرتبط مقدار الشغل المبذول على نظام صلب بعزم معين بمقدار ذلك العزم والإزاحة الزاوية التي يدور خلالها النظام الصب خلال الفترة التي يُطبق فيها العزم.
- المعادلة: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
- 6.2.A.3 يمكن إيجاد الشغل المبذول على نظام صلب بواسطة عزم قوة معين من خلال مساحة تحت منحنى رسم بياني لعزم القوة بدلالة الموضع الزاوي.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
A torque 力矩 acting through an angular displacement 角位移 does work, and power is torque times angular velocity:
$$W=\int_{\theta_1}^{\theta_2}\tau\,d\theta,\qquad P=\tau\omega.$$These are the rotational forms of $W=\int F\,dx$ and $P=Fv$ – the whole translational energy toolkit carries over with $F\to\tau$, $x\to\theta$, $v\to\omega$.
Worked example. A motor applies a constant $8.0\ \text{N}\cdot\text{m}$ torque to a flywheel for $5.0$ full turns: $W=\tau\,\Delta\theta=8.0(5.0)(2\pi)=250\ \text{J}$, which appears as rotational kinetic energy if friction is negligible.
Explore · استكشفBalance torques on a beam · وازن العزوم على عارضة
Torque is force times perpendicular distance, $\tau=Fd$. Equal torques on each side keep the beam in rotational equilibrium. · العزم هو القوة مضروبة في المسافة العمودية، $\tau=Fd$. العزوم المتساوية على كلا الجانبين تحافظ على العارضة في توازن دوراني.
Vocabulary · مفردات Train · تدريبEnglish العربية torque/tɔːk/ العزم angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ الإزاحة الزاوية 6.3
Angular Momentum and Angular Impulse
Syllabus · المنهج
EnglishLearning Objective 6.3.A: Describe the angular momentum of an object or rigid system.
- 6.3.A.1 The magnitude of the angular momentum of a rigid system about a specific axis can be described with the equation $L = I\omega$.
- Equation: $L = I\omega$
- 6.3.A.2 The angular momentum of an object about a given point is $\vec{L} = \vec{r} \times \vec{p}$.
- Equation: $\vec{L} = \vec{r} \times \vec{p}$
- 6.3.A.2.i The selection of the axis about which an object is considered to rotate influences the determination of the angular momentum of that object.
- 6.3.A.2.ii The measured angular momentum of an object traveling in a straight line depends on the distance between the reference point and the object, the mass of the object, the speed of the object, and the angle between the radial distance and the velocity of the object.
Learning Objective 6.3.B: Describe the angular impulse delivered to an object or rigid system by a torque.
- 6.3.B.1 Angular impulse is defined as the product of the torque exerted on an object or rigid system and the time interval during which the torque is exerted.
- Equation: $\text{angular impulse} = \displaystyle\int \tau \, dt$
- 6.3.B.2 Angular impulse has the same direction as the torque imparting it.
- 6.3.B.3 The angular impulse delivered to an object or rigid system by a torque can be found from the area under the curve of a graph of the torque as a function of time.
Learning Objective 6.3.C: Relate the change in angular momentum of an object or rigid system to the angular impulse given to that object or rigid system.
- 6.3.C.1 The magnitude of the change in angular momentum can be described by comparing the magnitudes of the final and initial momenta of the object or rigid system.
- Equation: $\Delta L = L - L_0$
- 6.3.C.2 A rotational form of the impulse–momentum theorem relates the angular impulse delivered to an object or rigid system and the change in angular momentum of that object or rigid system.
- 6.3.C.2.i The angular impulse exerted on an object or rigid system is equal to the change in angular momentum of that object or rigid system.
- Equation: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
- 6.3.C.2.ii The rotational form of the impulse–momentum theorem is a direct result of Newton's second law of motion for cases in which rotational inertia is constant.
- Equation: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
- 6.3.C.2.i The angular impulse exerted on an object or rigid system is equal to the change in angular momentum of that object or rigid system.
- 6.3.C.3 The net torque exerted on an object or rigid system is equal to the slope of the graph of the angular momentum of an object as a function of time.
- 6.3.C.4 The angular impulse delivered to an object or rigid system is equal to the area under the curve of a graph of the net external torque exerted on an object as a function of time.
العربيةهدف التعلم 6.3.A: وصف الزخم الزاوي لجسم أو نظام صلب.
- 6.3.A.1 يمكن وصف مقدار الزخم الزاوي لنظام صلب حول محور محدد بالمعادلة $L = I\omega$.
- المعادلة: $L = I\omega$
- 6.3.A.2 الزخم الزاوي لجسم حول نقطة معينة هو $\vec{L} = \vec{r} \times \vec{p}$.
- المعادلة: $\vec{L} = \vec{r} \times \vec{p}$
- 6.3.A.2.i يؤثر اختيار المحور الذي يُعتبر الجسم يدور حوله على تحديد الزخم الزاوي لذلك الجسم.
- 6.3.A.2.ii يعتمد الزخم الزاوي المقاس لجسم يتحرك في خط مستقيم على المسافة بين نقطة المرجع والجسم، وكتلة الجسم، وسرعة الجسم، والزاوية بين المسافة الشعاعية وسرعة الجسم.
هدف التعلم 6.3.B: وصف الدفع الزاوي المُقدَّم لجسم أو نظام صلب بواسطة عزم.
- 6.3.B.1 يُعرَّف الدفع الزاوي بأنه حاصل ضرب العزم المؤثر على جسم أو نظام صلب في فترة زمنية يتم فيها تطبيق العزم.
- المعادلة: $\text{angular impulse} = \displaystyle\int \tau \, dt$
- 6.3.B.2 للزخم القسري الزاوي نفس اتجاه عزم القوة الذي أُتيح به.
- 6.3.B.3 يمكن إيجاد الدفع الزاوي المُقدَّم لجسم أو نظام صلب بواسطة عزم من خلال المساحة تحت منحنى رسم بياني للعزم بدلالة الزمن.
هدف التعلم 6.3.C: ربط التغير في الزخم الزاوي لجسم أو نظام صلب بالدفع الزاوي المُقدَّم لذلك الجسم أو النظام الصب.
- 6.3.C.1 يمكن وصف مقدار التغير في الزخم الزاوي بمقارنة مقادير الزخم النهائي والأولي للجسم أو النظام الصلب.
- المعادلة: $\Delta L = L - L_0$
- 6.3.C.2 يوجد شكل دوار لقانون الدفع–الزخم يربط بين الدفع الزاوي المُقدَّم لجسم أو نظام صلب والتغير في الزخم الزاوي لذلك الجسم أو النظام الصب.
- 6.3.C.2.i يساوي الدفع الزاوي المؤثر على جسم أو نظام صلب التغير في الزخم الزاوي لذلك الجسم أو النظام الصب.
- معادلة: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
- 6.3.C.2.ii الصيغة الدورانية لمبرهنة الزخم القسري–الزخم هي نتيجة مباشرة لقانون نيوتن الثاني للحركة في الحالات التي يكون فيها العزم القصور الذاتي ثابتاً.
- معادلة: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
- 6.3.C.2.i يساوي الدفع الزاوي المؤثر على جسم أو نظام صلب التغير في الزخم الزاوي لذلك الجسم أو النظام الصب.
- 6.3.C.3 عزم القوة المحصل المؤثر على جسم أو نظام صلب يساوي ميل الرسم البياني للزخم الزاوي لجسم بدلالة الزمن.
- 6.3.C.4 الزخم القسري الزاوي المُقدَّم لجسم أو نظام صلب يساوي مساحة تحت منحنى رسم بياني لعزم القوة الخارجي المحصل المؤثر على جسم بدلالة الزمن.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Angular momentum 角动量 for a particle is
$$\vec{L}=\vec{r}\times\vec{p},\qquad |L|=mvr\sin\theta,$$so even a particle moving in a straight line has angular momentum about any point not on that line ($L=mv\,d$, with $d$ the perpendicular distance). For a rigid body spinning about a fixed axis, $L=I\omega$. Newton's second law in rotational form is
$$\vec{\tau}_{\text{net}}=\frac{d\vec{L}}{dt}\quad(=I\alpha\ \text{when }I\text{ is constant}),$$and a net torque acting over time delivers an angular impulse 角冲量 $\int\tau\,dt=\Delta L$ – the rotational impulse–momentum theorem.
Vocabulary · مفردات Train · تدريبEnglish العربية Angular momentum/ˈæŋɡjʊlə məʊˈmentəm/ زخم الزاوية angular impulse/ˈæŋɡjʊlə ˈɪmpʌls/ الدفع الزاوي 6.4
Conservation of Angular Momentum
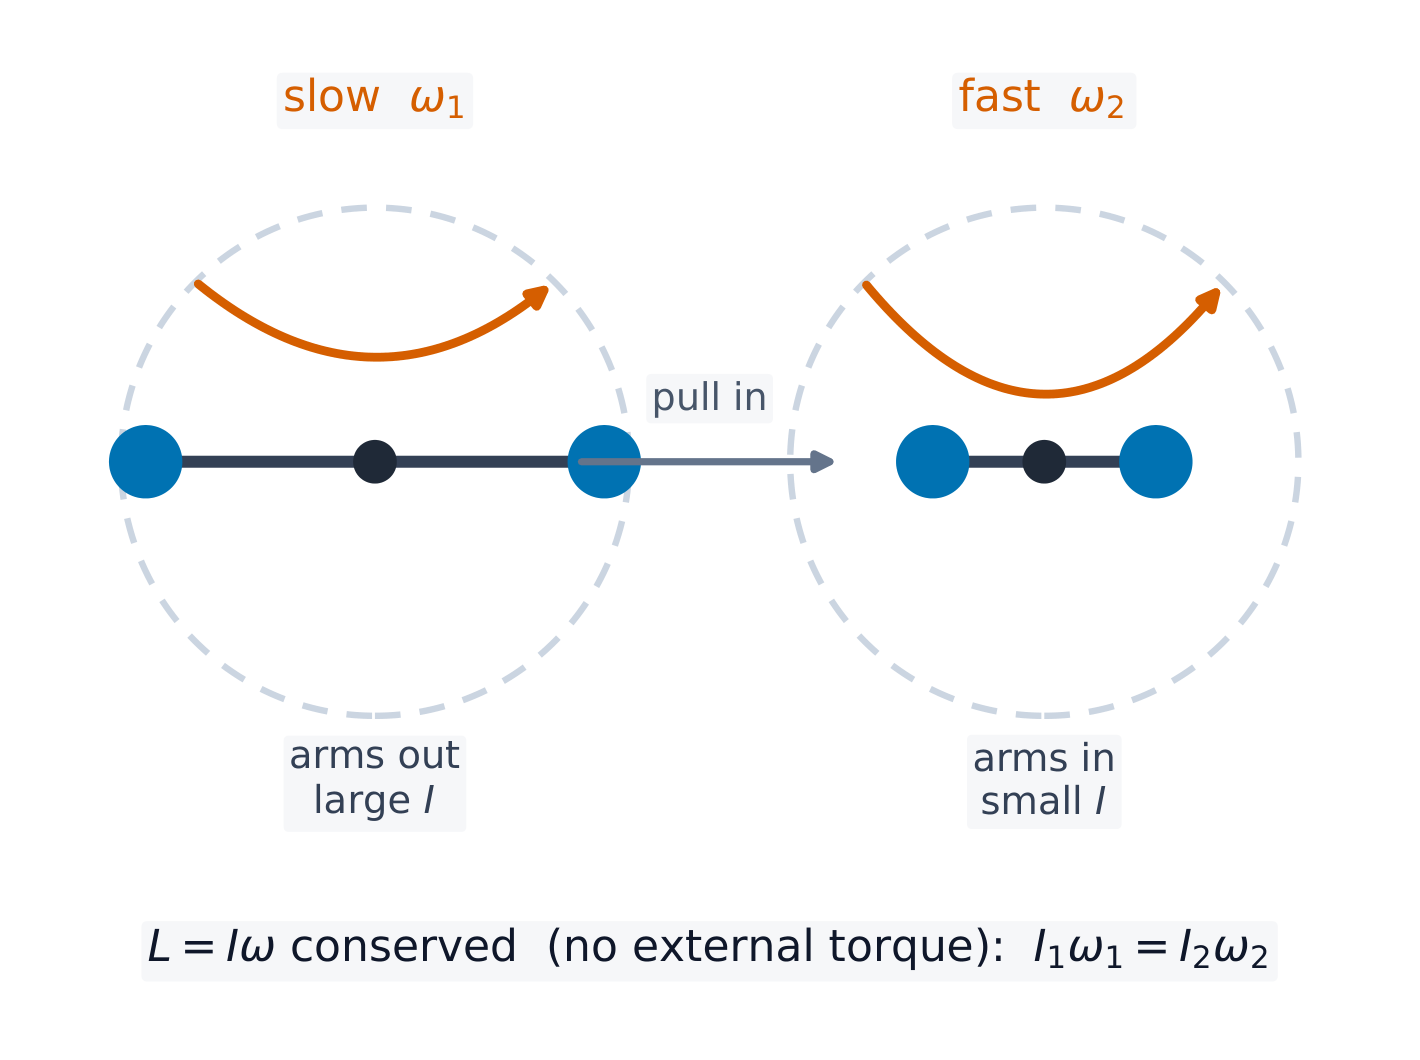
Syllabus · المنهج
EnglishLearning Objective 6.4.A: Describe the behavior of a system using conservation of angular momentum.
- 6.4.A.1 The total angular momentum of a system about a rotational axis is the sum of the angular momenta of the system's constituent parts about that rotational axis.
- 6.4.A.2 Any change to a system's angular momentum must be due to an interaction between the system and its surroundings.
- 6.4.A.2.i The angular impulse exerted by one object or system on a second object or system is equal and opposite to the angular impulse exerted by the second object or system on the first. This is a direct result of Newton's third law.
- 6.4.A.2.ii A system may be selected so that the total angular momentum of that system is constant.
- 6.4.A.2.iii The angular speed of a nonrigid system may change without the angular momentum of the system changing if the system changes shape by moving mass closer to or farther from the rotational axis.
- 6.4.A.2.iv If the total angular momentum of a system changes, that change will be equivalent to the angular impulse exerted on the system.
Learning Objective 6.4.B: Describe how the selection of a system determines whether the angular momentum of that system changes.
- 6.4.B.1 Angular momentum is conserved in all interactions.
- 6.4.B.2 If the net external torque exerted on a selected object or rigid system is zero, the total angular momentum of that system is constant.
- 6.4.B.3 If the net external torque exerted on a selected object or rigid system is nonzero, angular momentum is transferred between the system and the environment.
العربيةهدف التعلم 6.4.A: وصف سلوك نظام باستخدام مبدأ حفظ الزخم الزاوي.
- 6.4.A.1 الزخم الزاوي الكلي لنظام حول محور دوران هو مجموع الزخم الزاوي لمكونات ذلك النظام حول محور الدوران ذلك.
- 6.4.A.2 أي تغيير في الزخم الزاوي للنظام يجب أن يكون بسبب تفاعل بين النظام ومحيطه.
- 6.4.A.2.i الدفع الزاوي الذي يبذله جسم أو نظام على جسم أو نظام آخر يساوي في المقدار وعكس في الاتجاه الدفع الزاوي الذي يبذله الجسم أو النظام الثاني على الأول. وهذا نتيجة مباشرة لقانون نيوتن الثالث.
- 6.4.A.2.ii يمكن اختيار نظام بحيث يكون الزخم الزاوي الكلي لذلك النظام ثابتاً.
- 6.4.A.2.iii قد يتغير السرعة الزاوية لنظام غير صلب دون أن يتغير عزم الزاوية للنظام إذا تغير شكل النظام عن طريق تحريك كتل أقرب إلى أو أبعد من محور الدوران.
- 6.4.A.2.iv إذا تغير الزخم الزاوي الكلي لنظام،那么这个变化将等于施加于该系统的角冲量。
هدف التعلم 6.4.B: وصف كيفية تحديد اختيار النظام مما إذا كان الزخم الزاوي لذلك النظام سيتغير.
- 6.4.B.1 يُحفظ الزخم الزاوي في جميع التفاعلات.
- 6.4.B.2 إذا كان العزم الخارجي الصافي المؤثر على جسم أو نظام صلب مختار يساوي صفراً، فإن الزخم الزاوي الكلي لذلك النظام يكون ثابتاً.
- 6.4.B.3 إذا كان العزم الخارجي الصافي المؤثر على جسم أو نظام صلب مختار لا يساوي صفراً، فإن الزخم الزاوي ينتقل بين النظام والمحيط.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Angular momentum: pull in, spin faster With zero net external torque, total angular momentum is conserved 守恒:
$$L_{\text{before}}=L_{\text{after}},\qquad I_1\omega_1=I_2\omega_2\ \text{(one rigid body reshaping)}.$$If $I$ shrinks, $\omega$ grows – a spinning skater speeds up pulling her arms in. The rule survives collisions and shape changes, which is what makes it so useful: pick the axis so that every external force (gravity, the pivot force) exerts no torque about it.
Worked example. A skater spins at $2.0\ \text{rev/s}$ with $I_1=4.0\ \text{kg}\cdot\text{m}^2$. Pulling in her arms drops it to $I_2=1.6\ \text{kg}\cdot\text{m}^2$: $\omega_2=\dfrac{4.0}{1.6}(2.0)=5.0\ \text{rev/s}$. Her kinetic energy rises – the extra energy is the work her muscles do pulling her arms inward.
Pulling mass inward lowers I, so ω rises to conserve L = Iω 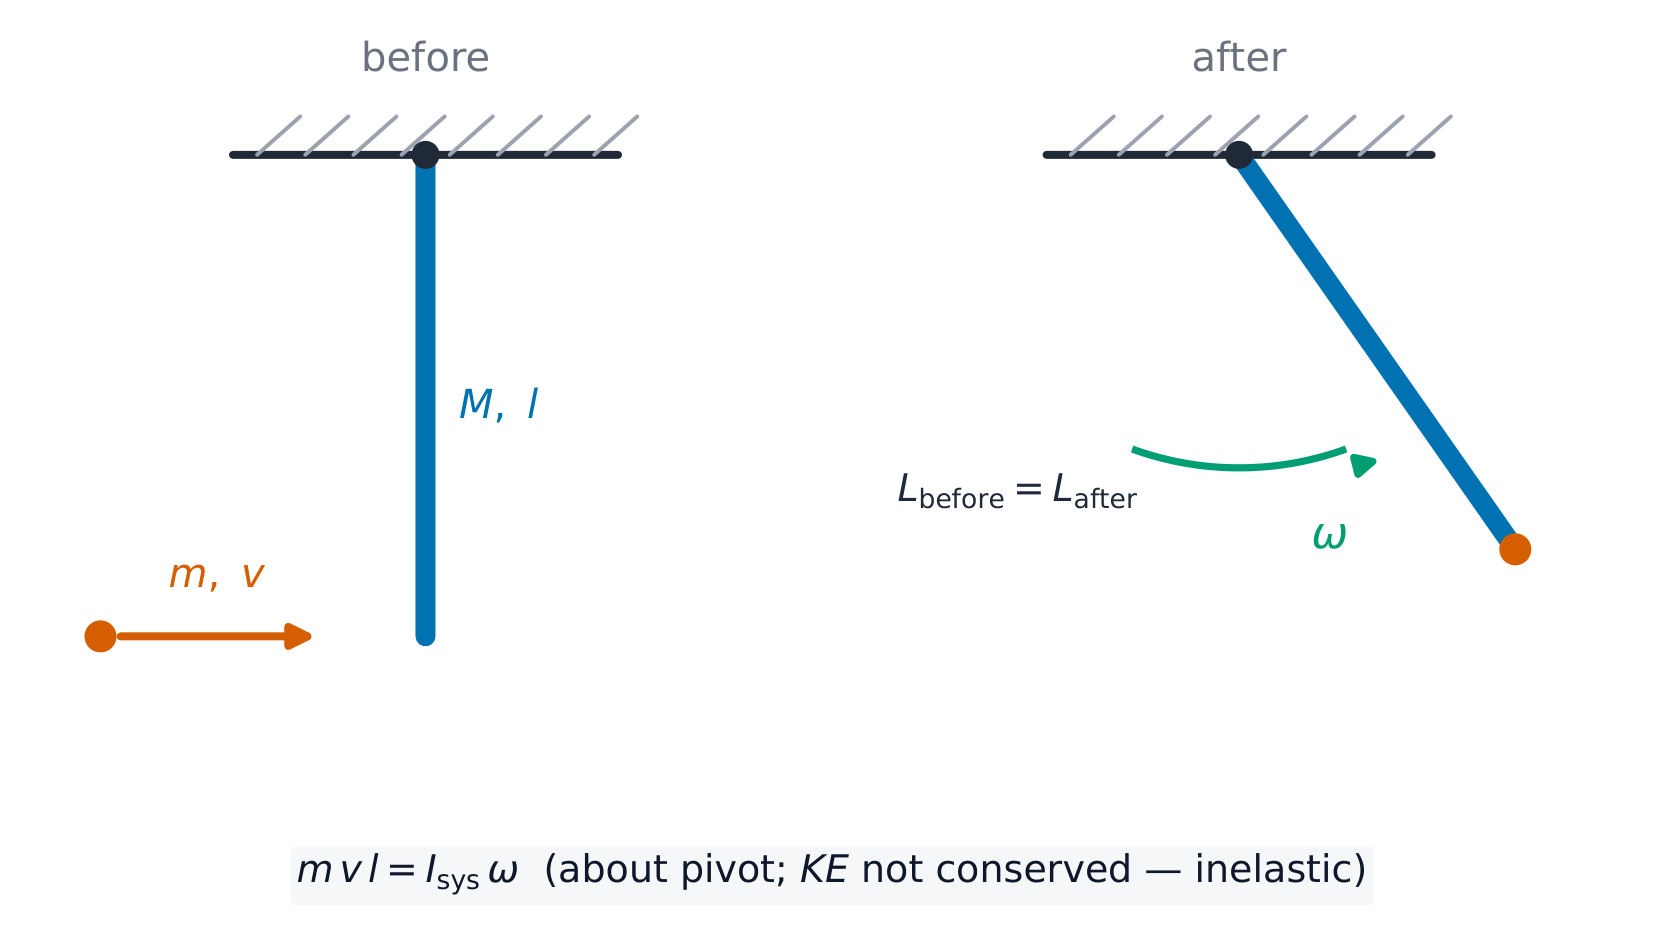
Angular momentum about the pivot is conserved as the bullet embeds in the rod Worked example (rotational collision). A $0.020\ \text{kg}$ bullet at $300\ \text{m/s}$ strikes the tip of a uniform rod ($M=1.5\ \text{kg}$, length $l=0.60\ \text{m}$) hanging from a pivot, and embeds. About the pivot, gravity and the pivot force exert no torque during the strike, so $L$ is conserved: $L=mvl=0.020(300)(0.60)=3.6\ \text{kg}\cdot\text{m}^2/\text{s}$. Afterwards $I=\tfrac13Ml^2+ml^2=0.18+0.0072=0.187\ \text{kg}\cdot\text{m}^2$, so $\omega=\dfrac{3.6}{0.187}\approx19\ \text{rad/s}$. (Linear momentum is not conserved here – the pivot pushes on the rod – and kinetic energy certainly is not: check both before claiming them.)
Figure skating and angular momentum: a skater who pulls their arms in during a spin lowers their rotational inertia, so they spin faster Vocabulary · مفردات Train · تدريبEnglish العربية conserved/kənˈsɜːvd/ محفوظة 6.5
Rolling
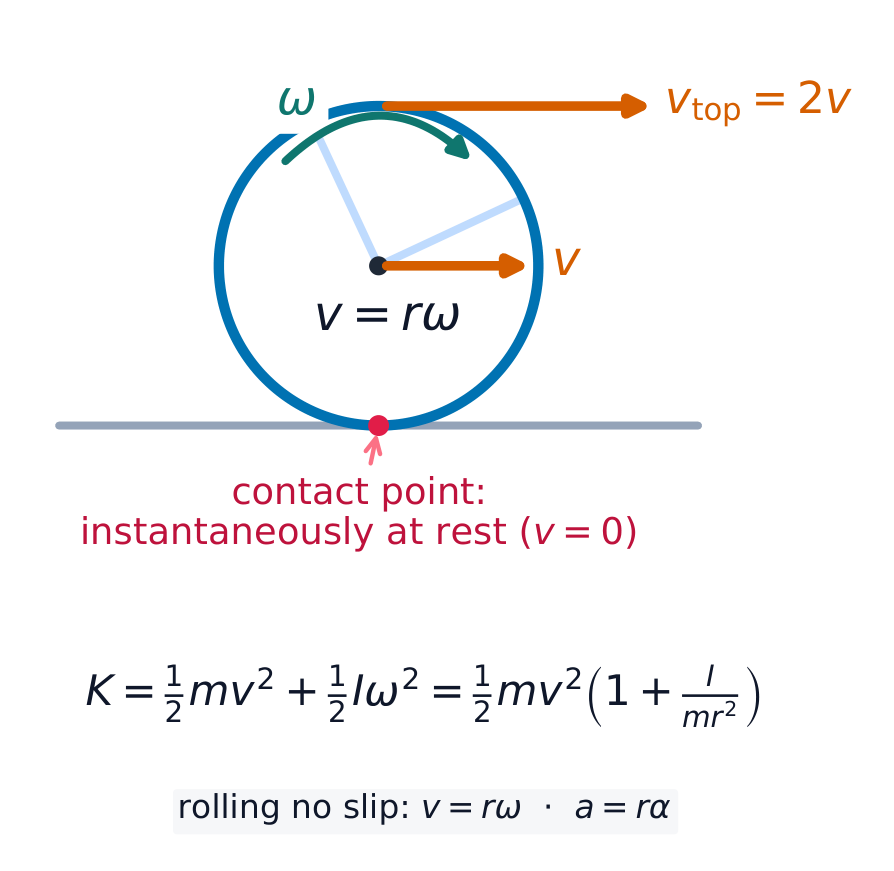
Syllabus · المنهج
EnglishLearning Objective 6.5.A: Describe the kinetic energy of a system that has translational and rotational motion.
- 6.5.A.1 The total kinetic energy of a system is the sum of the system's translational and rotational kinetic energies.
- Equation: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$
Learning Objective 6.5.B: Describe the motion of a system that is rolling without slipping.
- 6.5.B.1 While rolling without slipping, the translational motion of a system's center of mass is related to the rotational motion of the system itself with the following equations:
- Equation: $\Delta x_{\text{cm}} = r\Delta\theta$
- Equation: $v_{\text{cm}} = r\omega$
- Equation: $a_{\text{cm}} = r\alpha$
- 6.5.B.2 For ideal cases, rolling without slipping implies that the frictional force does not dissipate any energy from the rolling system.
Learning Objective 6.5.C: Describe the motion of a system that is rolling while slipping.
- 6.5.C.1 When slipping, the motion of a system's center of mass and the system's rotational motion cannot be directly related.
- 6.5.C.2 When a rotating system is slipping relative to another surface, the point of application of the force of kinetic friction exerted on the system moves with respect to the surface, so the force of kinetic friction will dissipate energy from the system.
Boundary statement: Rolling friction is beyond the scope of AP Physics C: Mechanics.
العربيةهدف التعلم 6.5.A: وصف الطاقة الحركية لنظام يمتلك حركة انتقالية ودوارة.
- 6.5.A.1 الطاقة الحركية الكلية لنظام هي مجموع طاقته الحركية الانتقالية ودوره.
- المعادلة: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$
هدف التعلم 6.5.B: وصف حركة نظام يتم تدحرجها دون انزلاق.
- 6.5.B.1 أثناء التدحرج دون انزلاق، يرتبط الحركة الانتقالية لمركز كتلة النظام بالحركة الدوورية للنظام نفسه بالمعادلات التالية:
- المعادلة: $\Delta x_{\text{cm}} = r\Delta\theta$
- المعادلة: $v_{\text{cm}} = r\omega$
- المعادلة: $a_{\text{cm}} = r\alpha$
- 6.5.B.2 بالنسبة للحالات المثالية، يعني الدوران دون انزلاق أن قوة الاحتكاك لا تبذيل أي طاقة من نظام الدوران.
الهدف التعليمي 6.5.C: وصف حركة نظام يدور مع انزلاق.
- 6.5.C.1 عند الانزلاق، لا يمكن ربط حركة مركز كتلة النظام والحركة الدوارية للنظام مباشرةً.
- 6.5.C.2 عندما يدور نظام وينزلق بالنسبة لسطح آخر، يتحرك نقطة تطبيق قوة الاحتكاك الحركي المؤثرة على النظام بالنسبة للسطح، لذا فإن قوة الاحتكاك الحركي ستبذيل طاقة من النظام.
عبارة حدودية: الاحتكاك في التدحرج خارج نطاق AP Physics C: Mechanics.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Rolling without slipping Rolling without slipping 无滑滚动 ties translation to rotation: the contact point is momentarily at rest, so
$$\Delta x_{\text{cm}}=r\,\Delta\theta,\qquad v_{\text{cm}}=r\omega,\qquad a_{\text{cm}}=r\alpha.$$In rolling without slipping the contact point is at rest, so v = rω Static friction supplies the torque that keeps the spin matched to the motion, but at a point that is not sliding – so for pure rolling, friction does no work, and energy conservation is safe to use. (Rolling friction is beyond the AP course.)
Racing shapes down an incline shows the energy split. With $I=\beta mr^2$, energy conservation gives
$$a_{\text{cm}}=\frac{g\sin\theta}{1+\beta}:$$a sphere ($\beta=\tfrac25$) beats a disk 圆盘 ($\beta=\tfrac12$), which beats a hoop 圆环 ($\beta=1$) – mass and radius cancel completely. More of the hoop's energy is locked in rotation, so its center moves slower.
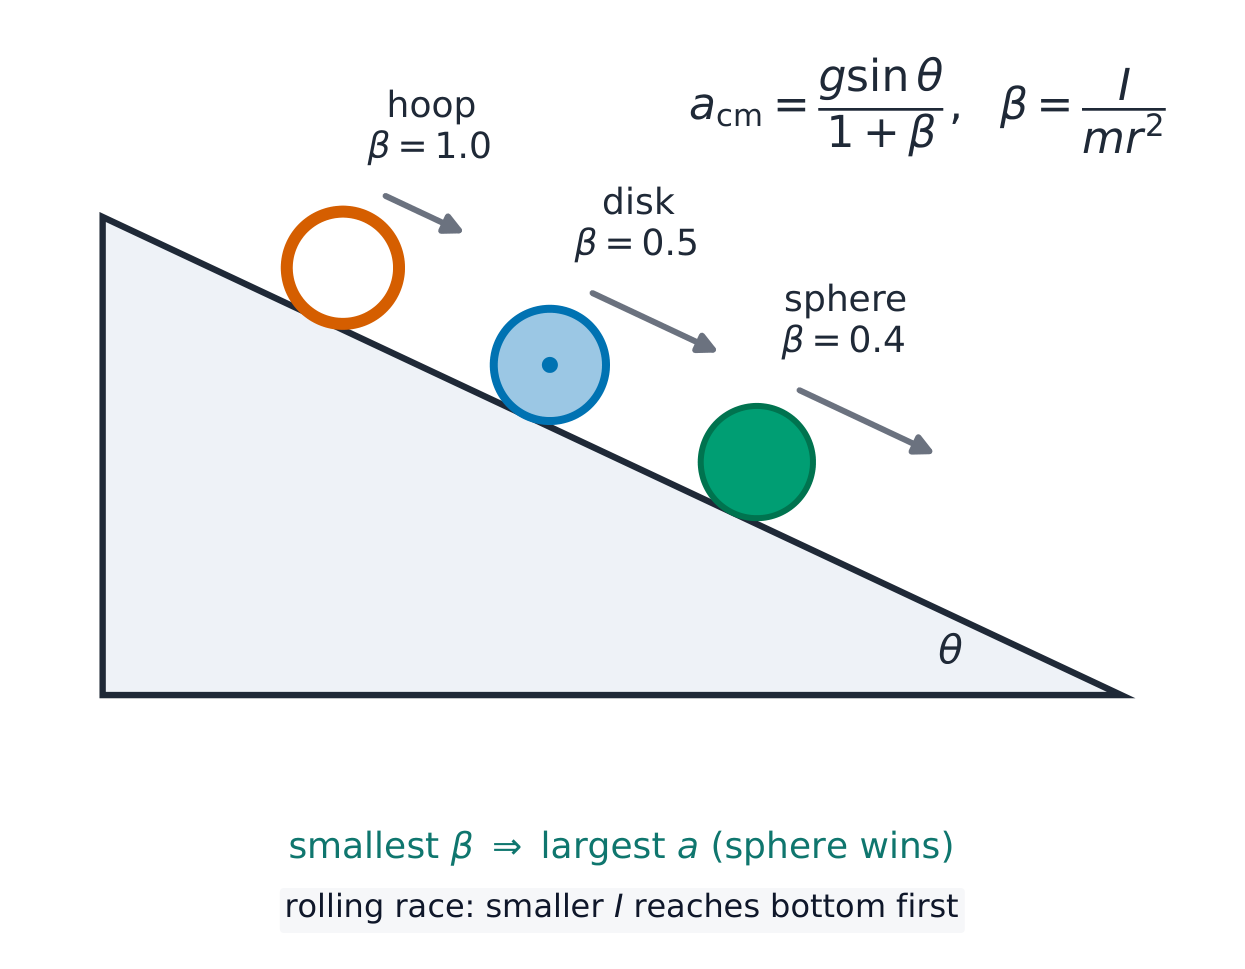
Rolling race: the shape with the smallest I/mr² reaches the bottom first Worked example. A solid sphere rolls from rest down a $30^\circ$ incline: $a=\dfrac{g\sin30^\circ}{1+\tfrac25}=\dfrac{9.8(0.50)}{1.4}=3.5\ \text{m/s}^2$, versus $4.9\ \text{m/s}^2$ for a frictionless slider – rolling objects always lose the race against sliding ones.
Vocabulary · مفردات Train · تدريبEnglish العربية Rolling without slipping/ˈrəʊlɪŋ wɪˈðaʊt ˈslɪpɪŋ/ دوران بدون انزلاق disk/dɪsk/ قرص hoop/huːp/ حلقة 6.6
Motion of Orbiting Satellites
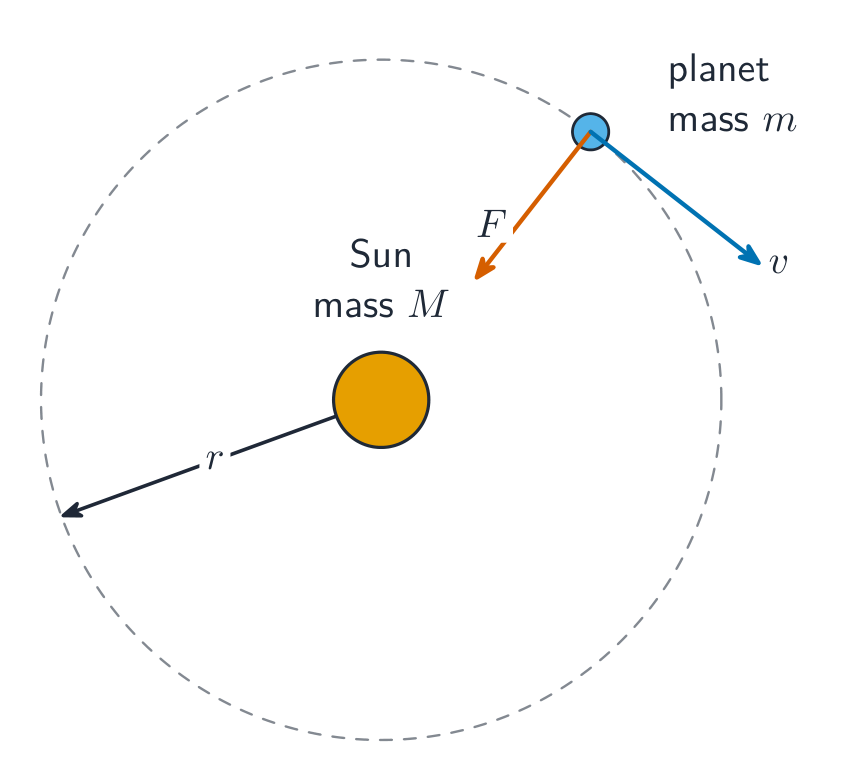
Syllabus · المنهج
EnglishLearning Objective 6.6.A: Describe the motions of a system consisting of two objects or systems interacting only via gravitational forces.
- 6.6.A.1 In a system consisting only of a massive central object and an orbiting satellite with mass that is negligible in comparison to the central object's mass, the motion of the central object itself is negligible.
- 6.6.A.2 The motion of satellites in orbits is constrained by conservation laws.
- 6.6.A.2.i In circular orbits, the system's total mechanical energy, the system's gravitational potential energy, and the satellite's angular momentum and kinetic energy are constant.
- 6.6.A.2.ii In elliptical orbits, the system's total mechanical energy and the satellite's angular momentum are constant, but the system's gravitational potential energy and the satellite's kinetic energy can each change.
- 6.6.A.2.iii The gravitational potential energy of a system consisting of a satellite and a massive central object is defined to be zero when the satellite is an infinite distance from the central object.
- Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
- 6.6.A.3 The total energy of a system consisting of a satellite orbiting a central object in a circular path can be written in terms of the gravitational potential energy of that system or the kinetic energy of the satellite.
- Equation: $K = -\dfrac{1}{2}U$
- Equation: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
- 6.6.A.4 The escape velocity of a satellite is the satellite's velocity such that the mechanical energy of the satellite–central-object system is equal to zero.
- 6.6.A.4.i When the only force exerted on a satellite is gravity from a central object, a satellite that reaches escape velocity will move away from the central body until its speed reaches zero at an infinite distance from the central body.
- 6.6.A.4.ii The escape velocity of a satellite from a central body of mass $M$ can be derived using conservation of energy laws.
- Equation: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$
العربيةالهدف التعليمي 6.6.A: صف حركات نظام يتكون من جسمين أو نظامين يتفاعلان فقط عبر القوى الجاذبة.
- 6.6.A.1 في نظام يتكون فقط من جسم مركزي ضخم وقمر صناعي يدور كتلته مهملة مقارنة بكتلة الجسم المركزي، تكون حركة الجسم المركزي نفسه مهملة.
- 6.6.A.2 تُقيد حركة الأقمار الصناعية في مداراتها بقوانين الحفظ.
- 6.6.A.2.i في المدارات الدائرية، تكون الطاقة الميكاني الكلية للنظام، وطاقة الجاذبية الكامنة للنظام، وعزم الزاوية للقمر الصناعي وطاقة حركته ثابتة.
- 6.6.A.2.ii في المدارات الإهليلجية، تكون الطاقة الميكاني الكلية للنظام وعزم الزاوية للقمر الصناعي ثابتين، لكن طاقة الجاذبية الكامنة للنظام وطاقة حركته يمكن أن تتغير كل منهما.
- 6.6.A.2.iii تُعرف طاقة الجاذبية الكامنة لنظام يتكون من قمر صناعي وجسم مركزي ضخم بأنها صفر عندما يكون القمر الصناعي على مسافة لا نهائية عن الجسم المركزي.
- معادلة: $U_g = -G\dfrac{m_1 m_2}{r}$
- 6.6.A.3 يمكن كتابة الطاقة الكلية لنظام يتكون من قمر صناعي يدور حول جسم مركزي في مسار دائري بدلالة الطاقة الكامنة الجاذبة لذلك النظام أو الطاقة الحركية للقمر الصناعي.
- المعادلة: $K = -\dfrac{1}{2}U$
- المعادلة: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
- 6.6.A.4 سرعة الهروب للقمر الصناعي هي السرعة التي تكون عندها الطاقة الميكانيكية لنظام القمر الصناعي-الجسم المركزي مساوية للصفر.
- 6.6.A.4.i عندما يكون الجسم الوحيد المؤثر على قمر صناعي هو الجاذبية من جسم مركزي، فإن القمر الصناعي الذي يصل إلى سرعة الهروب سيبتعد عن الجسم المركزي حتى تصل سرعته إلى الصفر على مسافة لا نهائية من الجسم المركزي.
- 6.6.A.4.ii يمكن اشتقاق سرعة الهروب لقمر صناعي من جسم مركزي كتلته $M$ باستخدام قوانين حفظ الطاقة.
- معادلة: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
Orbital motion (Kepler's 2nd law) Gravity supplies the centripetal force 向心力 for a satellite 卫星 in a circular orbit:
$$\frac{GMm}{r^2}=\frac{mv^2}{r}\quad\Rightarrow\quad v=\sqrt{\frac{GM}{r}}$$– larger orbits are slower. With gravitational potential energy 引力势能 $U_g=-\dfrac{GMm}{r}$, a circular orbit obeys $K=-\tfrac12U$, so the total mechanical energy 总机械能 is
$$E=K+U=\frac{U}{2}=-\frac{GMm}{2r},$$negative because the satellite is bound. To escape from radius $r$, total energy must reach zero, giving the escape velocity 逃逸速度
$$v_{\text{esc}}=\sqrt{\frac{2GM}{r}}.$$Gravity provides the centripetal force that keeps a satellite in orbit In an elliptical orbit 椭圆轨道, $E$ and $L$ are fixed: gravity points at the focus, so it exerts no torque about it. Conserved $L$ means the satellite sweeps equal areas in equal times – Kepler's second law 开普勒第二定律 – and therefore moves fastest at closest approach, slowest at the far point. Energy conservation connects speeds at the two ends.
Worked example. For a satellite at $r=7.0\times10^{6}\ \text{m}$ around Earth ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$): orbital speed $v=\sqrt{GM/r}=7.6\times10^{3}\ \text{m/s}$, while escaping from that radius needs $v_{\text{esc}}=\sqrt{2GM/r}=1.1\times10^{4}\ \text{m/s}$ – exactly $\sqrt2$ times the circular speed.
Exam skill. Orbit FRQs are energy-and-angular-momentum problems in disguise: write $E=\tfrac12mv^2-\dfrac{GMm}{r}$ and $L=mvr\sin\theta$ at the two points of interest and solve the pair – never assume the orbit formulae for circles apply to an ellipse.
Explore · استكشفCompare orbits at different radii · قارن المدارات عند نصف قطر مختلف
An orbiting satellite is in free fall, gravity supplying the centripetal force. A larger orbit means a slower speed and longer period (Kepler's third law). · قمر صناعي يدور في سقوط حر، الجاذبية توفر القوة المركزية. المدار الأكبر يعني سرعة أبطأ ودورة أطول (قانون كبلر الثالث).
Vocabulary · مفردات Train · تدريبEnglish العربية centripetal force/senˈtrɪpɪtl fɔːs/ قوة مركزية satellite/ˈsætəlaɪt/ قمر اصطناعي gravitational potential energy/ˌɡrævɪˈteɪʃənl pəˈtenʃl ˈenədʒi/ الطاقة الكامنة الجاذبية total mechanical energy/ˈtəʊtl mɪˈkænɪkl ˈenədʒi/ إجمالي الطاقة الميكانيكية escape velocity/eˈskeɪp vəˈlɒsɪti/ سرعة الهروب elliptical orbit/ɪˈlɪptɪkl ˈɔːbɪt/ مدار إهليلجي Kepler's second law/ˈkepləz ˈsekənd lɔː/ قانون كبلر الثاني 6.6
Exam tips
- Compute the moment of inertia $I=\int r^2\,dm$ and shift axes with the parallel-axis theorem $I=I_{cm}+Md^2$.
- Rotational kinetic energy is $\tfrac12 I\omega^2$; a rolling body has both translational and rotational KE.
- Conserve angular momentum $L=I\omega$ when net external torque is zero (a spinning skater pulling in).
- Use energy conservation for rolling-without-slipping problems ($v=r\omega$ ties the two motions).
- Know standard $I$ values (hoop, disk, rod, sphere) and where the axis is.
- 6.1.A.1 The rotational kinetic energy of an object or rigid system is related to the rotational inertia and angular velocity of the rigid system and is given by the equation $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
-
7
Oscillations · التذبذبات
Watch lesson · شاهد الدرس7.1
Defining Simple Harmonic Motion · تعريف الحركة التوافقية البسيطة
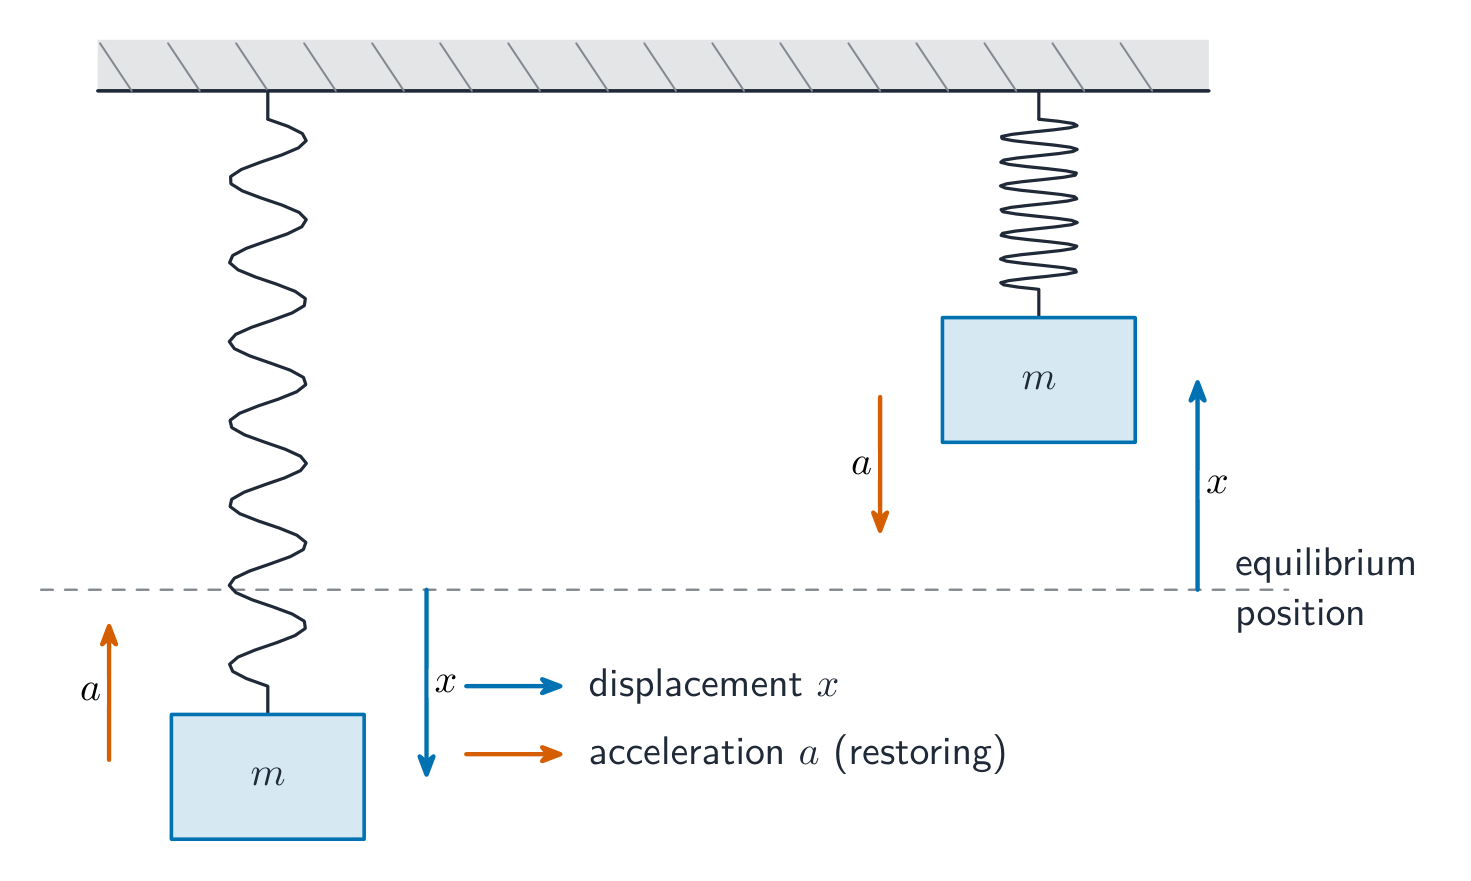
Syllabus · المنهج
EnglishLearning Objective 7.1.A: Describe simple harmonic motion.
- 7.1.A.1 Simple harmonic motion is a special case of periodic motion.
- 7.1.A.2 SHM results when the magnitude of the restoring force exerted on an object is proportional to that object's displacement from its equilibrium position.
- Derived equation: $ma_x = -k\Delta x$
- 7.1.A.2.i A restoring force is a force that is exerted in a direction opposite to the object's displacement from an equilibrium position.
- 7.1.A.2.ii An equilibrium position is a location at which the net force exerted on an object or system is zero.
العربيةالهدف التعليمي 7.1.A: وصف الحركة التوافقية البسيطة.
- 7.1.A.1 الحركة التوافقية البسيطة حالة خاصة من الحركة الدورية.
- 7.1.A.2 تنشأ الحركة التوافقية البسيطة عندما يكون مقدار قوة الاستعادة المؤثرة على جسم متناسبًا مع إزاحته عن موضع اتزان.
- معادلة مستنتجة: $ma_x = -k\Delta x$
- 7.1.A.2.i قوة الاستعادة هي قوة تؤثر في اتجاه معاكس لإزاحة الجسم عن موضع اتزان.
- 7.1.A.2.ii موضع الاتزان هو موقع يكون فيه محصلة القوى المؤثرة على جسم أو نظام تساوي صفرًا.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishSimple harmonic motion Simple harmonic motion 简谐运动 (SHM) is a special case of periodic motion 周期运动. It appears whenever two things are true: there is an equilibrium 平衡位置 position where the net force is zero, and displacing the object produces a restoring force 回复力 – a force pointing back toward equilibrium – whose magnitude is proportional to the displacement:
$$F=-k\,\Delta x.$$Newton's second law then gives the defining differential equation 微分方程:
$$\frac{d^2x}{dt^2}=-\frac{k}{m}\,x=-\omega^2 x,\qquad \omega=\sqrt{\frac{k}{m}}.$$Its solution is sinusoidal, $x(t)=A\cos(\omega t+\phi)$. You do not need to prove this solution – you need to recognise the equation: any system whose motion obeys "$\ddot{x}=-\omega^2x$" is a simple harmonic oscillator, whatever it is made of. (A mass hanging on a vertical spring works the same way: gravity only shifts the equilibrium point; the oscillation about it is unchanged.)
العربيةالحركة التوافقية البسيطة الحركة التوافقية البسيطة (SHM) هي حالة خاصة من الحركة الدورية. تظهر.annotations شيئين صحيحين: وجود موضع توازن تكون فيه محصلة القوى صفرًا، وإزاحة الجسم تنتج قوة إرجاعية – قوة تتجه نحو التوازن – مقدارها يتناسب طرديًا مع الإزاحة:
$$F=-k\,\Delta x.$$تعطي قانون نيوتن الثاني بعد ذلك المعادلة التفاضلية المميزة:
$$\frac{d^2x}{dt^2}=-\frac{k}{m}\,x=-\omega^2 x,\qquad \omega=\sqrt{\frac{k}{m}}.$$حلها جيبي، $x(t)=A\cos(\omega t+\phi)$. لا تحتاج لإثبات هذا الحل – بل تحتاج إلى التعرف على المعادلة: أي نظام يتبع حركته "$\ddot{x}=-\omega^2x$" هو مذبوب توافقي بسيط، بغض النظر عن مادته. (كتلة معلقة على ناب عمودي تعمل بنفس الطريقة: الجاذبية تحرك نقطة التوازن فقط؛ الاهتزاز حولها يبقى كما هو.)
في الحركة التوافقية البسيطة، التسارع يُشير دائمًا نحو نقطة الاتزان، عكس الإزاحة 7.2
Frequency and Period of SHM · التردد والدور الزمني للحركة التوافقية البسيطة
Syllabus · المنهج
EnglishLearning Objective 7.2.A: Describe the frequency and period of an object exhibiting SHM.
- 7.2.A.1 The period of SHM is related to the angular frequency, $\omega$, of the object's motion by the following equation:
- Equation: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
- 7.2.A.1.i The period of an object–ideal-spring oscillator is given by the equation
- Equation: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
- 7.2.A.1.ii The period of a simple pendulum displaced by a small angle is given by the equation
- Equation: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$
العربيةالهدف التعليمي 7.2.A: وصف تردد ودور زمني لجسم يظهر حركة توافقية بسيطة.
- 7.2.A.1 ترتبط الدورة (Period) للحركة التوافقية البسيطة بالتردد الزاوي، $\omega$، لحركة الجسم بالمعادلة التالية:
- المعادلة: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
- 7.2.A.1.i تُعطى دورة مذبوب جسم-زنبرك مثالي بالمعادلة
- معادلة: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
- 7.2.A.1.ii تُعطى دورة بندول بسيط مُزاح بزاوية صغيرة بالمعادلة
- معادلة: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishThe angular frequency 角频率 $\omega$ sets the period 周期 and frequency 频率:
$$T=\frac{2\pi}{\omega}=\frac{1}{f}.$$For the two standard systems:
$$T_{\text{spring}}=2\pi\sqrt{\frac{m}{k}},\qquad T_{\text{pendulum}}=2\pi\sqrt{\frac{\ell}{g}}.$$Two classic conceptual traps: the period of SHM never depends on the amplitude 振幅, and each system ignores one obvious variable – the pendulum's period does not involve its mass, and the spring's period does not involve $g$ (a spring–block oscillator keeps perfect time in orbit; a pendulum clock does not).
العربيةالتردد الزاوي $\omega$ يحدد الزمن الدوري والتردد:
$$T=\frac{2\pi}{\omega}=\frac{1}{f}.$$بالنسبة للنظامين القياسيين:
$$T_{\text{spring}}=2\pi\sqrt{\frac{m}{k}},\qquad T_{\text{pendulum}}=2\pi\sqrt{\frac{\ell}{g}}.$$فخمان مفهوميان كلاسيكيان: الزمن الدوري للحركة التوافقية البسيطة لا يعتمد أبدًا على السعة، وكل نظام يتجاهل متغيرًا واضحًا – زمن دور البندول لا يتضمن كتلته، وزمن دور الناب لا يتضمن $g$ (مذبوب ناب-كتلة يحافظ على دقة الوقت في المدار؛ ساعة بندولية لا تفعل ذلك).
Explore · استكشفTime a pendulum's swing · قياس زمن تأرجح البندول
A pendulum's period depends on its length and gravity, not its mass or (small) amplitude: $T=2\pi\sqrt{L/g}$. Lengthen it and each swing takes longer. · دور البندول يعتمد على طوله والجاذبية، وليس كتلته أو سعة اهتزازه الصغيرة: $T=2\pi\sqrt{L/g}$. زِد طوله وستستغرق كل تأرجح وقتًا أطول.
7.3
Representing and Analyzing SHM · تمثيل وتحليل الحركة التوافقية البسيطة
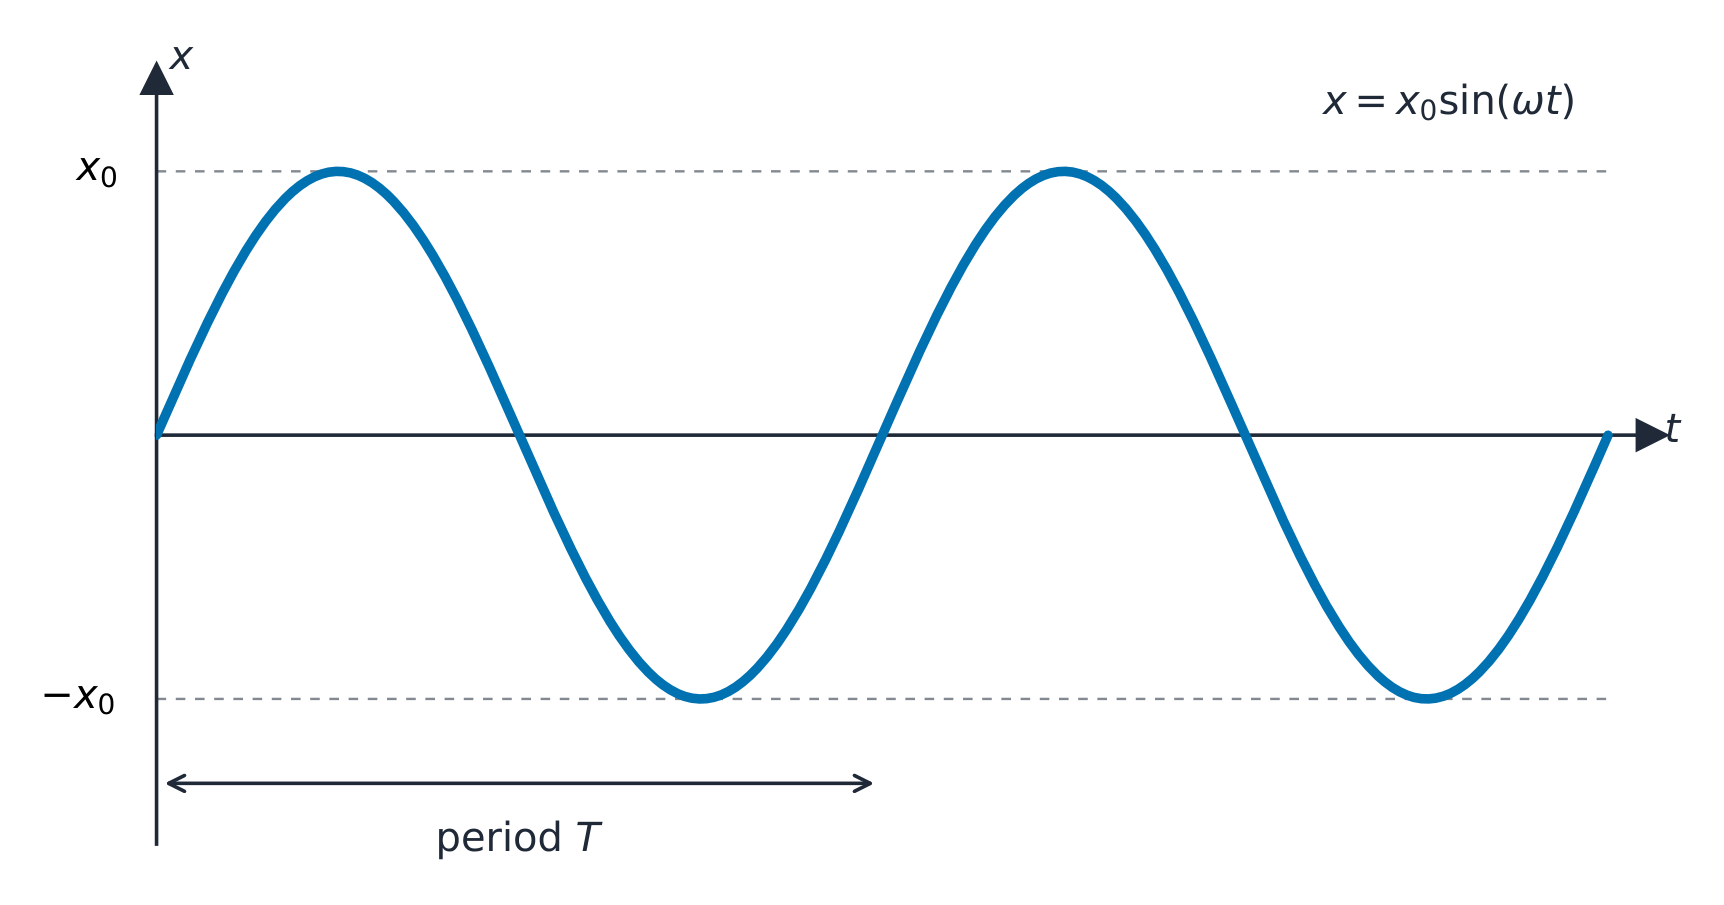
Syllabus · المنهج
EnglishLearning Objective 7.3.A: Describe the displacement, velocity, and acceleration of an object exhibiting SHM.
- 7.3.A.1 For an object exhibiting SHM, the displacement of that object measured from its equilibrium position can be represented by the equations $x = A\cos(2\pi ft)$ or $x = A\sin(2\pi ft)$.
- 7.3.A.1.i Minima, maxima, and zeros of displacement, velocity, and acceleration are features of harmonic motion.
- 7.3.A.1.ii Recognizing the positions or times at which the displacement, velocity, and acceleration for SHM have extrema or zeros can help in qualitatively describing the behavior of the motion.
- 7.3.A.2 The position as a function of time for an object exhibiting SHM is a solution of the second-order differential equation derived from the application of Newton's second law.
- Derived equation: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
- 7.3.A.3 Characteristics of SHM, such as velocity and acceleration, can be determined by or derived from the equation $x = A\cos(\omega t + \phi).$
- 7.3.A.3.i The acceleration of an object exhibiting SHM is related to the object's angular frequency and position.
- Derived equation: $a = -\omega^2 x$
- 7.3.A.3.ii It can be shown that the maximum velocity and acceleration of an object exhibiting SHM are related to the angular frequency of the object's motion.
- Derived equations: $v_{\max} = A\omega$
- $a_{\max} = A\omega^2$
- 7.3.A.3.i The acceleration of an object exhibiting SHM is related to the object's angular frequency and position.
- 7.3.A.4 In the presence of a sinusoidal external force, a system may exhibit resonance.
- 7.3.A.4.i Resonance occurs when an external force is exerted at the natural frequency of an oscillating system.
- 7.3.A.4.ii Resonance increases the amplitude of oscillating motion.
- 7.3.A.4.iii The natural frequency of a system is the frequency at which the system will oscillate when it is displaced from its equilibrium position.
- 7.3.A.5 Changing the amplitude of a system exhibiting SHM will not change its period.
- 7.3.A.6 Properties of SHM can be determined and analyzed using graphical representations.
Boundary statement: AP Physics C: Mechanics only expects students to know the solution to the second-order differential equation that describes SHM, as well as be able to identify SHM. AP Physics C: Mechanics does not expect students to mathematically prove that the solution is correct.
العربيةالهدف التعليمي 7.3.A: وصف إزاحة وسرعة وتسارع جسم يظهر حركة توافقية بسيطة.
- 7.3.A.1 بالنسبة لجسم يظهر حركة توافقية بسيطة، يمكن تمثيل إزاحته مقاسة من موضع اتزان بالمعادلات $x = A\cos(2\pi ft)$ أو $x = A\sin(2\pi ft)$.
- 7.3.A.1.i القيم الدنيا والعظمى والأصفار للإزاحة والسرعة والتسارع هي خصائص للحركة التوافقية.
- 7.3.A.1.ii التعرف على المواقع أو الأوقات التي يكون فيها الإزاحة والسرعة والتسارع للحركة التوافقية البسيطة عند قيمها القصوى أو أصفارها يساعد في وصف سلوك الحركة بشكل نوعي.
- 7.3.A.2 الموقع كدالة للزمن لجسم يظهر حركة توافقية بسيطة هو حل للمعادلة التفاضلية من الرتبة الثانية المشتقة من تطبيق قانون نيوتن الثاني.
- معادلة مستنتجة: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
- 7.3.A.3 يمكن تحديد خصائص الحركة التوافقية البسيطة، مثل السرعة والتسارع، أو اشتقاقها من المعادلة $x = A\cos(\omega t + \phi).$
- 7.3.A.3.i ترتبط تسارع جسم يظهر حركة توافقية بسيطة بالتردد الزاوي وموقعه.
- معادلة مشتقة: $a = -\omega^2 x$
- 7.3.A.3.ii يمكن إثبات أن أقصى سرعة وأقصى تسارع لجسم يظهر حركة توافقية بسيطة مرتبطان بالتردد الزاوي لحركة الجسم.
- معادلات مستنتجة: $v_{\max} = A\omega$
- $a_{\max} = A\omega^2$
- 7.3.A.3.i ترتبط تسارع جسم يظهر حركة توافقية بسيطة بالتردد الزاوي وموقعه.
- 7.3.A.4 في وجود قوة خارجية جيبية، قد يظهر النظام ظاهرة الرنين.
- 7.3.A.4.i يحدث الرنين عندما تُؤثر قوة خارجية عند التردد الطبيعي لنظام متذبذب.
- 7.3.A.4.ii يزيد الرنين من سعة الحركة المتذبذبة.
- 7.3.A.4.iii التردد الطبيعي للنظام هو التردد الذي سيتذبذب به النظام عند إزاحته من موضع توازنه.
- 7.3.A.5 تغيير سعة نظام يظهر حركة توافقية بسيطة لن يغير دوره.
- 7.3.A.6 يمكن تحديد خصائص الحركة التوافقية البسيطة وتحليلها باستخدام تمثيلات بيانية.
عبارة حدودية: تتوقع AP Physics C: Mechanics من الطلاب فقط معرفة حل المعادلة التفاضلية من الرتبة الثانية التي تصف الحركة التوافقية البسيطة، بالإضافة إلى القدرة على التعرف عليها. لا تتوقع AP Physics C: Mechanics من الطلاب الإثبات الرياضي لصحة الحل.
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishDifferentiate $x(t)=A\cos(\omega t+\phi)$ twice:
$$v=-A\omega\sin(\omega t+\phi),\qquad a=-A\omega^2\cos(\omega t+\phi)=-\omega^2x.$$So at the ends of the swing ($x=\pm A$) the speed is zero and the acceleration is largest; passing through equilibrium ($x=0$) the acceleration is zero and the speed is largest, $v_{\max}=A\omega$. The amplitude $A$ and the phase constant 相位常数 $\phi$ come from the initial conditions: where the object starts and how fast it is moving. Eliminating $t$ (or using energy, below) gives speed as a function of position:
$$v=\pm\,\omega\sqrt{A^2-x^2}.$$Worked example. A $0.50\ \text{kg}$ mass on a $k=200\ \text{N/m}$ spring: $\omega=\sqrt{k/m}=20\ \text{rad/s}$, $T=2\pi/\omega=0.31\ \text{s}$. With $A=0.10\ \text{m}$: $v_{\max}=A\omega=2.0\ \text{m/s}$ at equilibrium, and at $x=0.050\ \text{m}$ the speed is $v=\omega\sqrt{A^2-x^2}=20\sqrt{0.10^2-0.050^2}=1.7\ \text{m/s}$.
العربيةاشتق $x(t)=A\cos(\omega t+\phi)$ مرتين:
$$v=-A\omega\sin(\omega t+\phi),\qquad a=-A\omega^2\cos(\omega t+\phi)=-\omega^2x.$$إذن عند أطراف الاهتزاز ($x=\pm A$) تكون السرعة صفراً والتسارع أكبر ما يمكن؛ وعند المرور بت-position التوازن ($x=0$) يكون التسارع صفراً والسرعة أكبر ما يمكن، $v_{\max}=A\omega$. تأتي السعة $A$ والثابت الطوري $\phi$ من الشروط الابتدائية: أين يبدأ الجسم وكيف بسرعة يتحرك. بإزالة $t$ (أو باستخدام الطاقة، أدناه) نحصل على السرعة بدلالة الموقع:
$$v=\pm\,\omega\sqrt{A^2-x^2}.$$تتغير الإزاحة جيبيًا مع الزمن في الحركة التوافقية البسيطة مثال محلول. كتلة $0.50\ \text{kg}$ على ناب $k=200\ \text{N/m}$: $\omega=\sqrt{k/m}=20\ \text{rad/s}$، $T=2\pi/\omega=0.31\ \text{s}$. مع $A=0.10\ \text{m}$: $v_{\max}=A\omega=2.0\ \text{m/s}$ عند التوازن، وعند $x=0.050\ \text{m}$ تكون السرعة $v=\omega\sqrt{A^2-x^2}=20\sqrt{0.10^2-0.050^2}=1.7\ \text{m/s}$.
7.4
Energy of Simple Harmonic Oscillators · طاقة المتذبذبات التوافقية البسيطة
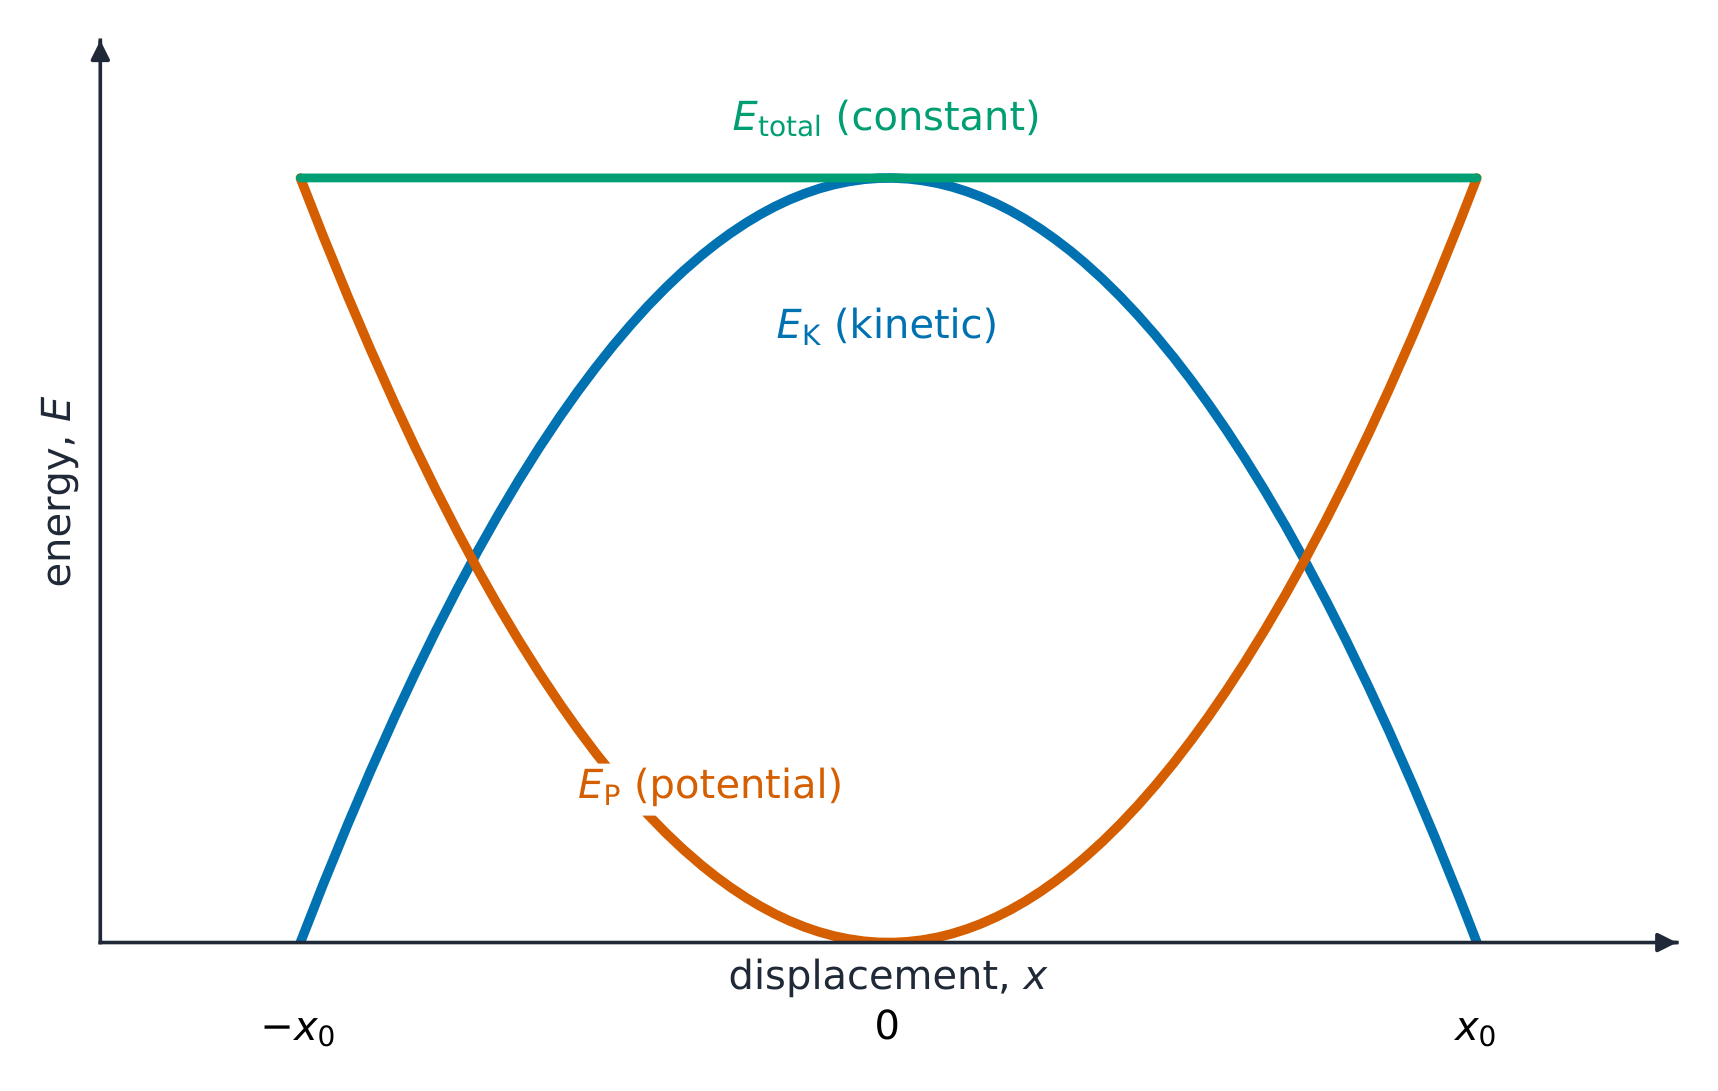
Syllabus · المنهج
EnglishLearning Objective 7.4.A: Describe the mechanical energy of a system exhibiting SHM.
- 7.4.A.1 The total energy of a system exhibiting SHM is the sum of the system's kinetic and potential energies.
- Relevant equation: $E_{\text{total}} = U + K$
- 7.4.A.2 Conservation of energy indicates that the total energy of a system exhibiting SHM is constant.
- 7.4.A.3 The kinetic energy of a system exhibiting SHM is at a maximum when the system's potential energy is at a minimum.
- 7.4.A.4 The potential energy of a system exhibiting SHM is at a maximum when the system's kinetic energy is at a minimum.
- 7.4.A.4.i The minimum kinetic energy of a system exhibiting SHM is zero.
- 7.4.A.4.ii Changing the amplitude of a system exhibiting SHM will change the maximum potential energy of the system and, therefore, the total energy of the system.
- Relevant equation for a spring–object system: $E_{\text{total}} = \dfrac{1}{2}kA^2$
العربيةالهدف التعليمي 7.4.A: وصف الطاقة الميكانيكية لنظام يظهر حركة توافقية بسيطة.
- 7.4.A.1 الطاقة الكلية لنظام يظهر حركة توافقية بسيطة هي مجموع طاقته الحركية وطاقة وضعه.
- المعادلة ذات الصلة: $E_{\text{total}} = U + K$
- 7.4.A.2 يشير حفظ الطاقة إلى أن الطاقة الكلية لنظام يظهر حركة توافقية بسيطة ثابتة.
- 7.4.A.3 تكون الطاقة الحركية لنظام يظهر حركة توافقية بسيطة في أقصى قيمة لها عندما تكون طاقة وضعه في أدنى قيمة لها.
- 7.4.A.4 تكون طاقة الوضع لنظام يظهر حركة توافقية بسيطة في أقصى قيمة لها عندما تكون الطاقة الحركية للنظام في أدنى قيمة لها.
- 7.4.A.4.i تكون الطاقة الحركية الدنيا لنظام يظهر حركة توافقية بسيطة مساوية للصفر.
- 7.4.A.4.ii تغيير سعة نظام يظهر حركة توافقية بسيطة سيغير طاقة الوضع القصوى للنظام، وبالتالي الطاقة الكلية للنظام.
- المعادلة ذات الصلة لنظام زنبرك-جسم: $E_{\text{total}} = \dfrac{1}{2}kA^2$
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishThe total energy of the oscillator is the sum $E=U+K$, and with no friction it is constant – energy just trades back and forth between the spring's potential energy and the mass's kinetic energy:
$$E=\tfrac12kA^2=\tfrac12kx^2+\tfrac12mv^2.$$All potential at the ends (where $K=0$), all kinetic at equilibrium (where $U$ is minimum). Because $E\propto A^2$, doubling the amplitude quadruples the energy.
Worked example. Where is the energy split evenly? Set $\tfrac12kx^2=\tfrac12E=\tfrac14kA^2$, so $x=A/\sqrt2\approx0.71A$ – much closer to the end than to the middle. For the system above ($A=0.10\ \text{m}$): $x=0.071\ \text{m}$.
Left alone, a system oscillates at its own natural frequency 固有频率 (set by $k$ and $m$: $f_0=\frac{1}{2\pi}\sqrt{k/m}$). Drive it with a periodic force at that same frequency and the amplitude grows dramatically – resonance 共振. Each well-timed push adds energy faster than damping removes it, so the driven amplitude peaks sharply when the driving frequency matches $f_0$ (a swing pumped in time, a bridge shaken by wind).
العربيةالطاقة الكلية للمذبوب هي المجموع $E=U+K$، وبغياب الاحتكاك فهي ثابتة – الطاقة تتبادل فقط بين طاقة وضع الناب وطاقة حركة الكتلة:
$$E=\tfrac12kA^2=\tfrac12kx^2+\tfrac12mv^2.$$كل الطاقة عند الأطراف (حيث $K=0$)، وكل الطاقة الحركية عند التوازن (حيث $U$ هو الأدنى). بما أن $E\propto A^2$، فإن مضاعفة السعة يضاعف الطاقة أربعة أضعاف.
تتبادل الطاقة الحركية والكامنة خلال دورة واحدة بينما تظل الطاقة الكلية ثابتة مثال محلول. أين تنقسم الطاقة بالتساوي؟ ضع $\tfrac12kx^2=\tfrac12E=\tfrac14kA^2$، إذن $x=A/\sqrt2\approx0.71A$ – أقرب بكثير للنهاية منه للوسط. بالنسبة للنظام أعلاه ($A=0.10\ \text{m}$): $x=0.071\ \text{m}$.
مُتركًا لذاته، يهتز النظام بـتردده الطبيعي (المحدود بـ $k$ و $m$: $f_0=\frac{1}{2\pi}\sqrt{k/m}$). قم بتحريكه بقوة دورية بنفس التردد وتنمو السعة بشكل هائل – الرنين. كل دفعة متزامنة تضيف طاقة أسرع مما يزيله التخميد، لذلك تبلغ سعة المحركة ذروتها بحدة عندما يتطابق تردد المحرك مع $f_0$ (أرجوحة تُدفع بإيقاع، جسر يُهز بواسطة الرياح).
Explore · استكشفTrade kinetic and potential energy in SHM · تبادل الطاقة الحركية والكامنة في الحركة التوافقية البسيطة
In simple harmonic motion, energy sloshes between kinetic (fastest at the centre) and potential (greatest at the extremes) while the total stays constant. · في الحركة التوافقية البسيطة، تتناوب الطاقة بين الطاقة الحركية (الأعلى في المركز) والطاقة الكامنة (الأعلى عند الأطراف) بينما يبقى المجموع ثابتًا.
7.5
Simple and Physical Pendulums · البندولات البسيطة والجسدية
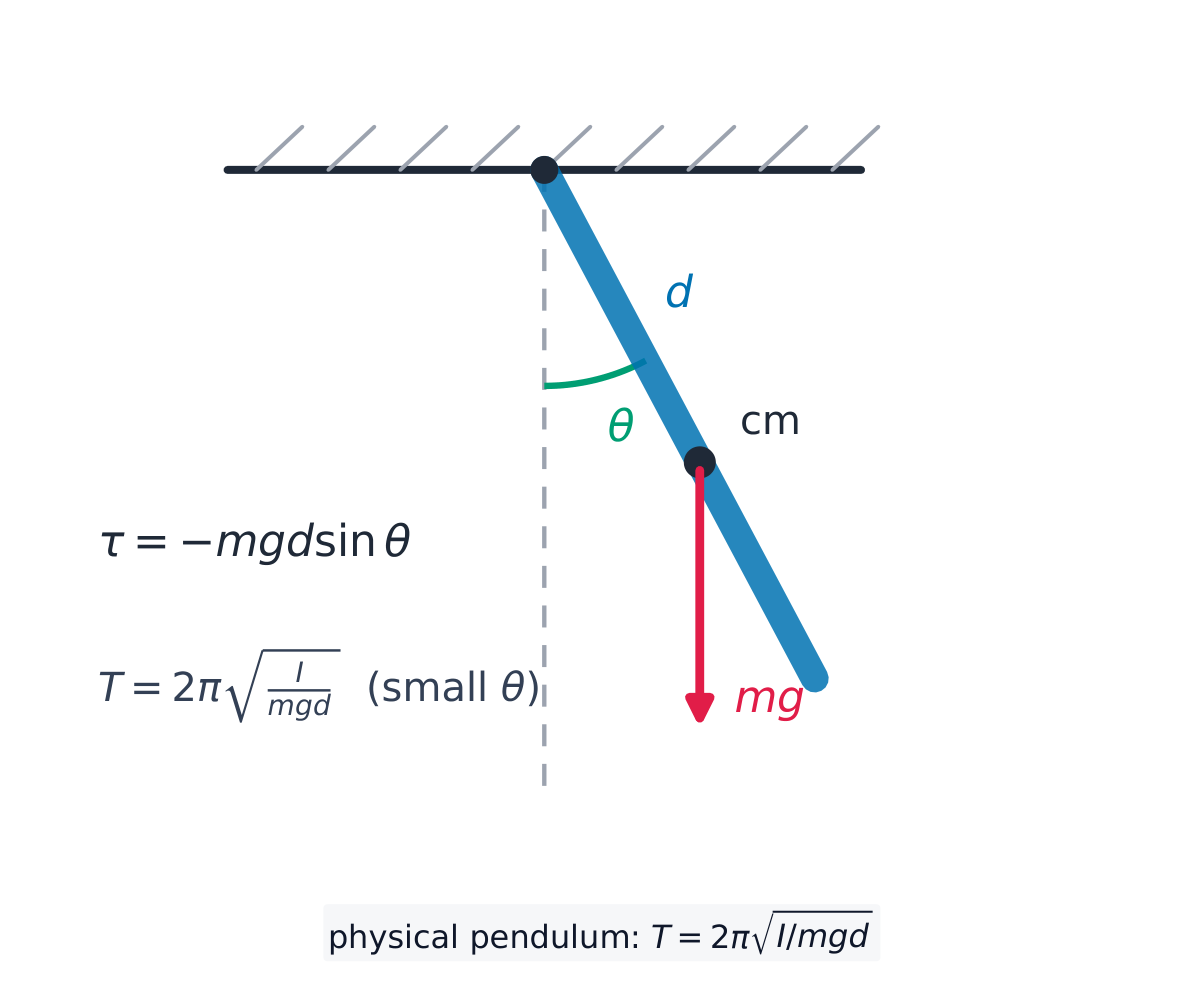
Syllabus · المنهج
EnglishLearning Objective 7.5.A: Describe the properties of a physical pendulum.
- 7.5.A.1 A physical pendulum is a rigid body that undergoes oscillation about a fixed axis.
- 7.5.A.2 For small amplitudes of motion, the period of a physical pendulum is derived from the application of Newton's second law in rotational form.
- Relevant equation: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
- 7.5.A.2.i When displaced from equilibrium, the gravitational force exerted on a physical pendulum's center of mass provides a restoring torque.
- Derived equation: $\tau = -mgd\sin\theta$
- 7.5.A.2.ii For small amplitudes of motion, the small-angle approximation can be applied to the restoring torque.
- Derived equation: $\sin\theta \approx \theta$
- $\tau = -mgd\theta = I\alpha$
- 7.5.A.2.iii The small-angle approximation and Newton's second law in rotational form yield a second-order differential equation that describes SHM:
- Equation: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
- 7.5.A.3 A simple pendulum is a special case of physical pendulums in which the hanging object can be modeled as a point mass at a distance, $l$, from the pivot point.
- Relevant equation: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
- 7.5.A.4 A torsion pendulum is a case of SHM where the restoring torque is proportional to the angular displacement of a rotating system. For example, a horizontal disk that is suspended from a wire attached to its center of mass may undergo rotational oscillations about the wire in the horizontal plane.
- Derived equation: $I\alpha = -k\Delta\theta$
العربيةالهدف التعليمي 7.5.A: صف خصائص البندول الفيزيائي.
- 7.5.A.1 البندول الفيزيائي هو جسم صلب يخضع لتذبذب حول محور ثابت.
- 7.5.A.2 بالنسبة لسعات حركة صغيرة، يتم اشتقاق دورة البندول الفيزيائي من تطبيق قانون نيوتن الثاني بالصيغة الدوورية.
- المعادلة ذات الصلة: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
- 7.5.A.2.i عند الإزاحة من التوازن، توفر القوة الجاذبة المؤثرة على مركز كتلة البندول الفيزي عزم استعادة.
- معادلة مشتقة: $\tau = -mgd\sin\theta$
- 7.5.A.2.ii بالنسبة لسعات حركة صغيرة، يمكن تطبيق تقريب الزوايا الصغيرة على عزم الاستعادة.
- معادلة مشتقة: $\sin\theta \approx \theta$
- $\tau = -mgd\theta = I\alpha$
- 7.5.A.2.iii يؤدي تقريب الزوايا الصغيرة وقانون نيوتن الثاني بالصيغة الدوورية إلى معادلة تفاضلية من الرتبة الثانية تصف الحركة التوافقية البسيطة:
- معادلة: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
- 7.5.A.3 البندول البسيط هو حالة خاصة من البندولات الفيزيائية حيث يمكن نمذجة الجسم المعلق على أنه كتلة نقطية على مسافة، $l$، من نقطة التعليق.
- المعادلة ذات الصلة: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
- 7.5.A.4 البندول اللولبي هو حالة من الحركة التوافقية البسيطة حيث يكون عزم الاستعادة متناسبًا مع الإزاحة الزاوية لنظام دوار. على سبيل المثال، قد تخضع قرص أفقي معلق بسلك متصل بمركز كتلته لتذبذبات دورية حول السلك في المستوى الأفقي.
- معادلة مستنتجة: $I\alpha = -k\Delta\theta$
Source: College Board AP Course and Exam Description · المصدر: وصف دورة وامتحان College Board AP
EnglishEnergy conservation: KE ⇄ PE A physical pendulum 物理摆 is any rigid body swinging about a fixed pivot. Displace it by an angle $\theta$ and gravity, acting at the center of mass a distance $d$ from the pivot, supplies a restoring torque
$$\tau=-mgd\sin\theta.$$For small angles, apply the small-angle approximation 小角度近似 $\sin\theta\approx\theta$ and Newton's second law in rotational form ($\tau=I\alpha$):
$$\frac{d^2\theta}{dt^2}=-\frac{mgd}{I}\,\theta=-\omega^2\theta\quad\Rightarrow\quad T_{\text{phys}}=2\pi\sqrt{\frac{I}{mgd}}.$$This is the same "$\ddot\theta=-\omega^2\theta$" pattern as before – recognising it is the derivation. A simple pendulum 单摆 is the special case of a point mass on a light string: $I=m\ell^2$ and $d=\ell$ give $T=2\pi\sqrt{\ell/g}$.
Worked example. A uniform rod (mass $M$, length $L$) swings from one end: $I=\tfrac13ML^2$, $d=\tfrac{L}{2}$, so
$$T=2\pi\sqrt{\frac{\tfrac13ML^2}{Mg\,\tfrac{L}{2}}}=2\pi\sqrt{\frac{2L}{3g}}$$– shorter than a simple pendulum of length $L$, because the rod's mass sits nearer the pivot.
A torsion pendulum 扭摆 – a disk hanging from a wire that twists – is SHM one more time: the wire's restoring torque is proportional to the twist angle, $I\alpha=-\kappa\,\Delta\theta$, giving $T=2\pi\sqrt{I/\kappa}$.
Exam skill. Every pendulum FRQ wants the same three steps: write the restoring torque about the pivot, apply the small-angle approximation, and match the result to $\ddot\theta=-\omega^2\theta$ to read off $\omega$. State the small-angle step explicitly – it is a scored point, and it is why large-amplitude swings are not simple harmonic.
العربيةحفظ الطاقة: KE ⇄ PE البندول الفيزيائي هو أي جسم صلب يتأرجح حول محور ثابت. إذا إزاحته بزاوية $\theta$، فإن الجاذبية المؤثرة على مركز الثقل على بُعد $d$ عن المحور توفر عزم استعادة
$$\tau=-mgd\sin\theta.$$للزوايا الصغيرة، طبق تقريب الزوايا الصغيرة $\sin\theta\approx\theta$ وقانون نيوتن الثاني بالصيغة الدورانية ($\tau=I\alpha$):
$$\frac{d^2\theta}{dt^2}=-\frac{mgd}{I}\,\theta=-\omega^2\theta\quad\Rightarrow\quad T_{\text{phys}}=2\pi\sqrt{\frac{I}{mgd}}.$$هذا هو نمط "$\ddot\theta=-\omega^2\theta$" نفسه السابق – التعرف عليه هو الاستنتاج. البندول البسيط هو حالة خاصة لكتلة نقطية على خيط خفيف: $I=m\ell^2$ و $d=\ell$ يعطيان $T=2\pi\sqrt{\ell/g}$.
الجاذبية المؤثرة في مركز الثقل توفر عزم الإرجاع للبندول الجسدي مثال محلول. عارضة منتظمة (كتلة $M$، طول $L$) تهتز من أحد طرفيها: $I=\tfrac13ML^2$، $d=\tfrac{L}{2}$، لذا
$$T=2\pi\sqrt{\frac{\tfrac13ML^2}{Mg\,\tfrac{L}{2}}}=2\pi\sqrt{\frac{2L}{3g}}$$– أقصر من بندول بسيط بطول $L$، لأن كتلة العارضة تقع أقرب إلى محور الدوران.
البندول المالتوي – قرص معلق بسلك يلتوي – هو مرة أخرى حركة توافقية بسيطة: عزم الإرجاع للسلك يتناسب مع زاوية الالتواء، $I\alpha=-\kappa\,\Delta\theta$، مما يعطي $T=2\pi\sqrt{I/\kappa}$.
مهارة الامتحان. كل مسألة FRQ عن البندول تريد نفس الخطوات الثلاث: اكتب عزم الإرجاع حول محور الدوران، طبق تقريب الزوايا الصغيرة، واطابق النتيجة مع $\ddot\theta=-\omega^2\theta$ لاستخراج $\omega$. نصّ على خطوة الزوايا الصغيرة صراحةً – فهي نقطة مُدرجة، وهي السبب في أن اهتزازات السعة الكبيرة ليست توافقية بسيطة.
بندول فوكو: بندول طويل وثقيل يكشف اهتزازه البطيء عن دوران الأرض أسفله Vocabulary · مفردات Train · تدريبEnglish العربية Simple harmonic motion/ˈsɪmpl hɑːˈmɒnɪk ˈməʊʃn/ الحركة التوافقية البسيطة periodic motion/ˌpɪərɪˈɒdɪk ˈməʊʃn/ الحركة الدورية equilibrium/ˌiːkwɪˈlɪbrɪəm/ الاتزان restoring force/rɪˈstɔːrɪŋ fɔːs/ القوة المرجعة differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ معادلة تفاضلية angular frequency/ˈæŋɡjʊlə ˈfriːkwənsi/ التردد الزاوي period/ˈpɪərɪəd/ الدور frequency/ˈfriːkwənsi/ التردد amplitude/ˈæmplɪtjuːd/ السعة phase constant/feɪz ˈkɒnstənt/ ثابت الطور natural frequency/ˈnætʃərəl ˈfriːkwənsi/ طبيعي resonance/ˈrezənəns/ الرنين physical pendulum/ˈfɪzɪkl ˈpendjʊləm/ البندول الفيزيائي small-angle approximation/smɔːl ˈæŋɡl əˌprɒksɪˈmeɪʃn/ تقريب الزاوية الصغيرة simple pendulum/ˈsɪmpl ˈpendjʊləm/ البندول البسيط torsion pendulum/ˈtɔːʃn ˈpendjʊləm/ pendulum الدوراني 7.5
Exam tips · نصائح للامتحان
English- Identify SHM from a linear restoring force $F=-kx$, which gives $\tfrac{d^2x}{dt^2}=-\omega^2 x$ with $\omega=\sqrt{k/m}$.
- Write the solution $x=A\cos(\omega t+\phi)$ and get $v,a$ by differentiating; period $T=\tfrac{2\pi}{\omega}$ is amplitude-independent.
- Energy trades between $\tfrac12 kx^2$ and $\tfrac12 mv^2$, with total $\tfrac12 kA^2$.
- For a pendulum, use the small-angle approximation $\sin\theta\approx\theta$ to reach SHM.
- Match phase to the start: released from rest at maximum displacement uses cosine.
العربية- تحديد الحركة التوافقية البسيطة من خلال قوة الاستعادة الخطية $F=-kx$، والتي تؤدي إلى $\tfrac{d^2x}{dt^2}=-\omega^2 x$ عندما يكون $\omega=\sqrt{k/m}$.
- اكتب الحل $x=A\cos(\omega t+\phi)$ واحصل على $v,a$ بالاشتقاق؛ الزمن الدوري $T=\tfrac{2\pi}{\omega}$ مستقل عن السعة.
- تتبادل الطاقة بين $\tfrac12 kx^2$ و $\tfrac12 mv^2$، مع مجموع $\tfrac12 kA^2$.
- للبندول، استخدم تقريب الزوايا الصغيرة $\sin\theta\approx\theta$ للوصول إلى الحركة التوافقية البسيطة.
- طابق الطور مع البداية: الإطلاق من السكون عند أقصى إزاحة يستخدم دالة جيب التمام.