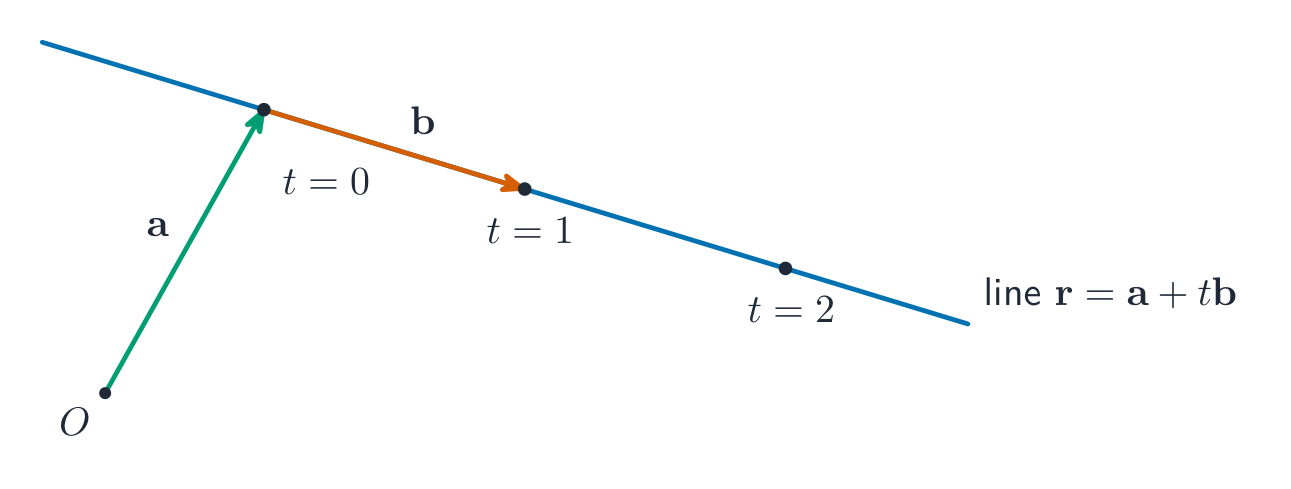
Skip to content · ⁨Bỏ qua nội dung⁩

Functions Involving Parameters, Vectors, and Matrices · ⁨Hàm liên quan đến tham số, vectơ và ma trận⁩

AP Precalculus · ⁨AP Tiền giải tích⁩ · Topic 4 · ⁨Chủ đề 4⁩

Video lesson for this topic · ⁨Bài học video cho chủ đề này⁩ Open the video page · ⁨Mở trang video⁩
8:04

Hàm liên quan đến tham số, vectơ và ma trận

Hãy nhìn vào chuyến tàu lượn này. Ở mọi thời điểm, xe có hai thực tế: nó ở đâu, và nó đang đi về hướng nào. Một phương trình không thể chứa cả hai. Hành tinh này chạy một…

English narration · English + 中文 subtitles burned in · ⁨Giọng đọc tiếng Anh · phụ đề tiếng Anh + 中文 được ghi trực tiếp⁩

4.1

Parametric Functions · ⁨Hàm Tham số⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.1.A: Construct a graph or table of values for a parametric function represented analytically.

  • 4.1.A.1 A parametric function in $\mathbb{R}^2$, the set of all ordered pairs of two real numbers, consists of a set of two parametric equations in which two dependent variables, $x$ and $y$, are dependent on a single independent variable, $t$, called the parameter.
  • 4.1.A.2 Because variables $x$ and $y$ are dependent on the independent variable, $t$, the coordinates $(x_i,\, y_i)$ at time $t_i$ can be written as functions of $t$ and can be expressed as the single parametric function $f(t) = (x(t),\, y(t))$, where in this case $x$ and $y$ are names of two functions.
  • 4.1.A.3 A numerical table of values can be generated for the parametric function $f(t) = (x(t),\, y(t))$ by evaluating $x_i$ and $y_i$ at several values of $t_i$ within the domain.
  • 4.1.A.4 A graph of a parametric function can be sketched by connecting several points from the numerical table of values in order of increasing value of $t$.
  • 4.1.A.5 The domain of the parametric function $f$ is often restricted, which results in start and end points on the graph of $f$.
Tiếng Việt

Mục tiêu học tập 4.1.A: Xây dựng đồ thị hoặc bảng giá trị cho một hàm tham số được biểu diễn phân tích.

  • 4.1.A.1 Một hàm tham số trong $\mathbb{R}^2$, tập hợp tất cả các cặp thứ tự gồm hai số thực, bao gồm một tập hợp hai phương trình tham số trong đó hai biến phụ thuộc, $x$ và $y$, phụ thuộc vào một biến độc lập duy nhất, $t$, gọi là tham số.
  • 4.1.A.2 Vì các biến $x$ và $y$ phụ thuộc vào biến độc lập, $t$, tọa độ $(x_i,\, y_i)$ tại thời điểm $t_i$ có thể được viết dưới dạng hàm của $t$ và có thể được biểu diễn dưới dạng hàm tham số đơn lẻ $f(t) = (x(t),\, y(t))$, trong đó trường hợp này $x$ và $y$ là tên của hai hàm số.
  • 4.1.A.3 Một bảng giá trị số có thể được tạo ra cho hàm tham số $f(t) = (x(t),\, y(t))$ bằng cách tính toán $x_i$ và $y_i$ tại nhiều giá trị khác nhau của $t_i$ nằm trong miền xác định.
  • 4.1.A.4 Đồ thị của một hàm tham số có thể được vẽ nháp bằng cách nối các điểm từ bảng giá trị số theo thứ tự tăng dần của $t$.
  • 4.1.A.5 Miền xác định của hàm tham số $f$ thường bị giới hạn, dẫn đến việc xuất hiện điểm bắt đầu và điểm kết thúc trên đồ thị của $f$.
Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

Unit 4 is part of the course but is not assessed on the AP Precalculus Exam (which covers only Units 1–3); it builds tools used in later courses.

A parametric function 参数函数 describes a curve by giving both coordinates as functions of a third variable, the parameter 参数 $t$: $\big(x(t),\,y(t)\big)$. As $t$ runs through its domain, the point traces a path – and, unlike $y=f(x)$, the path may loop or cross itself.

Tiếng Việt
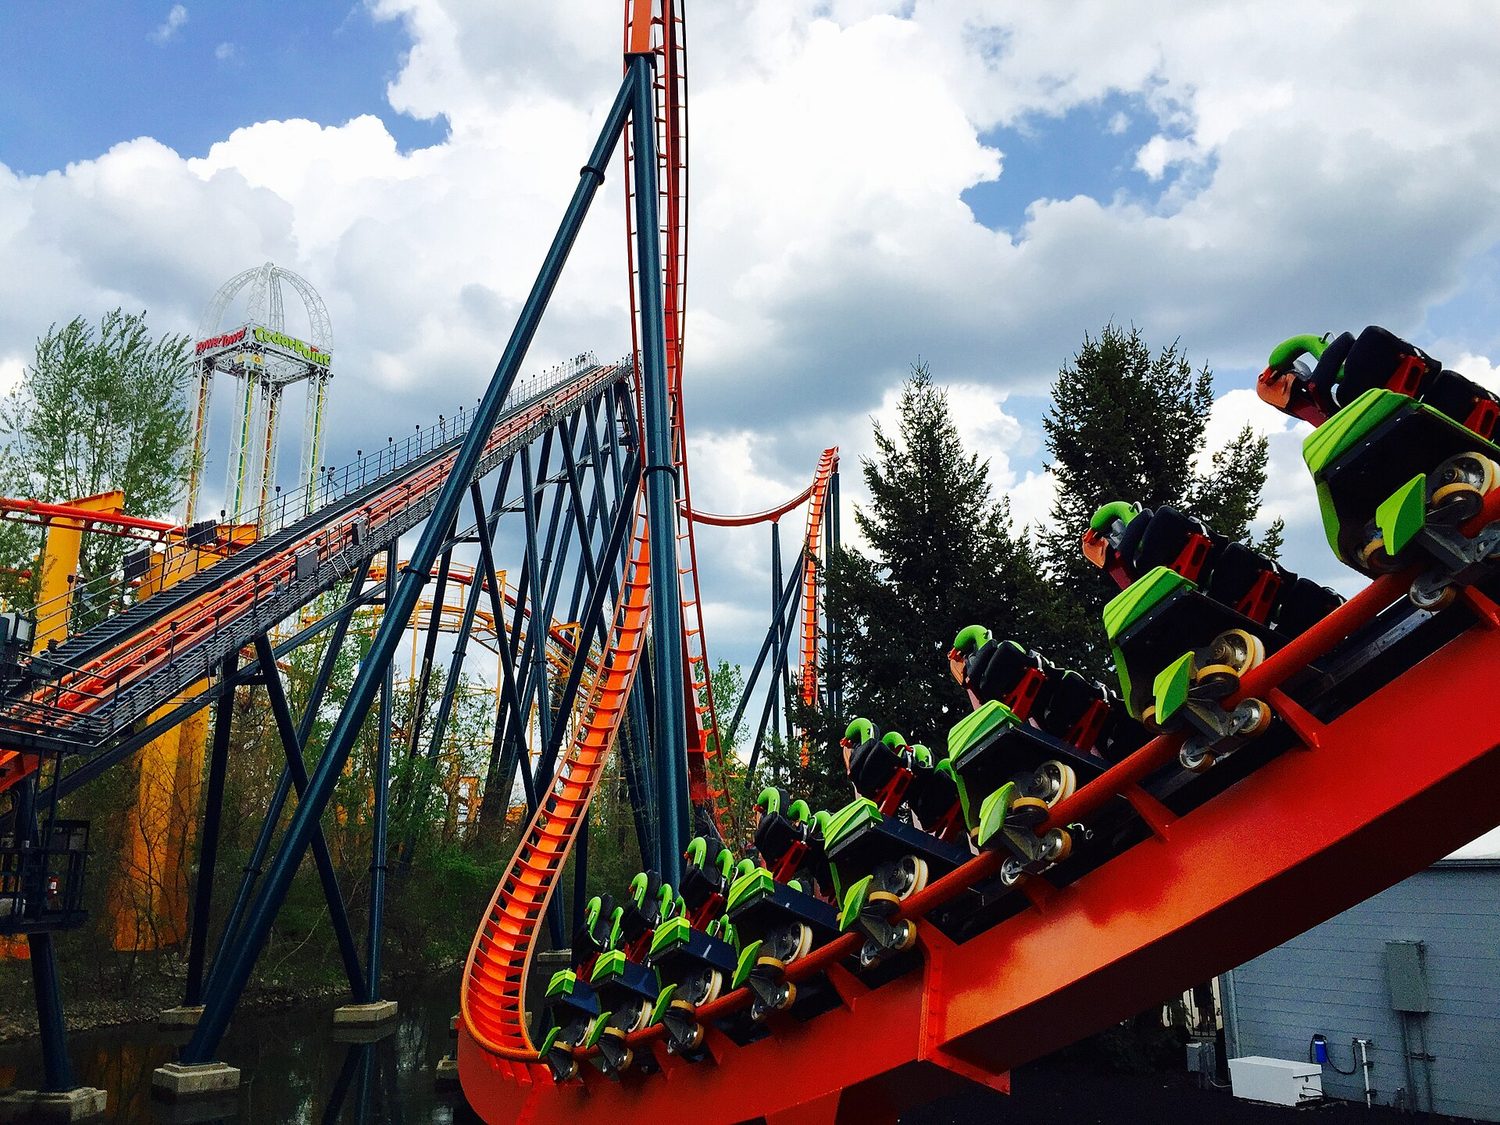
A roller coaster: vectors and parametric motion describe path and velocity together
Một tàu lượn: vector và chuyển động tham số mô tả quỹ đạo và vận tốc cùng lúc

Đơn vị 4 là một phần của khóa học nhưng không được kiểm tra trong Đề thi AP Precalculus (chỉ bao gồm Đơn vị 1–3); đơn vị này xây dựng các công cụ sử dụng trong các khóa học sau.

Một hàm tham số mô tả một đường cong bằng cách đưa cả hai tọa độ thành hàm của một biến thứ ba, gọi là tham số $t$: $\big(x(t),\,y(t)\big)$. Khi $t$ chạy qua miền xác định của nó, điểm sẽ vẽ ra một quỹ đạo – và, khác với $y=f(x)$, quỹ đạo có thể vòng lại hoặc tự cắt chính nó.

Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
English Tiếng Việt
vector/ˈvektə/ vector
magnitude/ˈmæɡnɪtjuːd/ độ lớn
vector-valued function/ˈvektə ˈvæljuːd ˈfʌŋkʃn/ hàm giá trị vector
4.2

Parametric Functions and Planar Motion · ⁨Hàm Tham số và Chuyển động Phẳng⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.2.A: Identify key characteristics of a parametric planar motion function that are related to position.

  • 4.2.A.1 A parametric function given by $f(t) = (x(t),\, y(t))$ can be used to model particle motion in the plane. The graph of this function indicates the position of a particle at time $t$.
  • 4.2.A.2 The horizontal and vertical extrema of a particle's motion can be determined by identifying the maximum and minimum values of the functions $x(t)$ and $y(t)$, respectively.
  • 4.2.A.3 The real zeros of the function $x(t)$ correspond to $y$-intercepts, and the real zeros of $y(t)$ correspond to $x$-intercepts.
Tiếng Việt

Mục tiêu học tập 4.2.A: Xác định các đặc điểm chính của một hàm chuyển động phẳng tham số liên quan đến vị trí.

  • 4.2.A.1 Một hàm tham số cho bởi $f(t) = (x(t),\, y(t))$ có thể được sử dụng để mô hình hóa chuyển động của hạt trong mặt phẳng. Đồ thị của hàm này chỉ ra vị trí của hạt tại thời điểm $t$.
  • 4.2.A.2 Các cực đại và cực tiểu theo phương ngang và phương dọc của chuyển động hạt có thể được xác định bằng cách tìm giá trị lớn nhất và nhỏ nhất của các hàm $x(t)$ và $y(t)$, tương ứng.
  • 4.2.A.3 Các nghiệm thực của hàm $x(t)$ tương ứng với giao điểm với trục $y$, và các nghiệm thực của $y(t)$ tương ứng với giao điểm với trục $x$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

Reading $t$ as time, a parametric function models motion in the plane. $x(t)$ and $y(t)$ give the horizontal and vertical position; the point's direction of travel is the order in which the curve is drawn as $t$ increases (mark it with arrows).

Tiếng Việt

Đoc $t$ là thời gian, một hàm tham số mô tả chuyển động trong mặt phẳng. $x(t)$ và $y(t)$ cho vị trí ngang và dọc; hướng di chuyển của điểm là thứ tự mà đường cong được vẽ khi $t$ tăng (đánh dấu bằng mũi tên).

4.3

Parametric Functions and Rates of Change · ⁨Hàm Tham Số và Tốc Độ Thay Đổi⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.3.A: Identify key characteristics of a parametric planar motion function that are related to direction and rate of change.

  • 4.3.A.1 As the parameter increases, the direction of planar motion of a particle can be analyzed in terms of $x$ and $y$ independently. If $x(t)$ is increasing or decreasing, the direction of motion is to the right or left, respectively. If $y(t)$ is increasing or decreasing, the direction of motion is up or down, respectively.
  • 4.3.A.2 At any given point in the plane, the direction of planar motion may be different for different values of $t$.
  • 4.3.A.3 The same curve in the plane can be parametrized in different ways and can be traversed in different directions with different parametric functions.
  • 4.3.A.4 Over a given interval $[t_1,\, t_2]$ within the domain, the average rate of change can be computed for $x(t)$ and $y(t)$ independently. The ratio of the average rate of change of $y$ to the average rate of change of $x$ gives the slope of the graph between the points on the curve corresponding to $t_1$ and $t_2$, so long as the average rate of change of $x(t) \neq 0$.
Tiếng Việt

Mục tiêu học tập 4.3.A: Xác định các đặc điểm chính của một hàm chuyển động phẳng tham số liên quan đến hướng và tốc độ thay đổi.

  • 4.3.A.1 Khi tham số tăng, hướng chuyển động phẳng của một hạt có thể được phân tích dựa trên $x$ và $y$ độc lập. Nếu $x(t)$ đang tăng hoặc giảm, hướng chuyển động sẽ sang phải hoặc trái tương ứng. Nếu $y(t)$ đang tăng hoặc giảm, hướng chuyển động sẽ lên hoặc xuống tương ứng.
  • 4.3.A.2 Tại bất kỳ điểm nào trong mặt phẳng, hướng chuyển động phẳng có thể khác nhau tùy thuộc vào giá trị của $t$.
  • 4.3.A.3 Cùng một đường cong trong mặt phẳng có thể được tham số hóa theo nhiều cách khác nhau và có thể được traversed (vượt qua) theo các hướng khác nhau với các hàm tham số khác nhau.
  • 4.3.A.4 Trong một khoảng xác định $[t_1,\, t_2]$ nằm trong miền xác định, tốc độ biến đổi trung bình có thể được tính toán riêng biệt cho $x(t)$ và $y(t)$. Tỷ số giữa tốc độ biến đổi trung bình của $y$ và tốc độ biến đổi trung bình của $x$ sẽ cho ra hệ số góc của đồ thị giữa các điểm trên đường cong tương ứng với $t_1$ và $t_2$, miễn là tốc độ biến đổi trung bình của $x(t) \neq 0$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

Over an interval of $t$, the average rate of change of $x$ is $\dfrac{\Delta x}{\Delta t}$ and of $y$ is $\dfrac{\Delta y}{\Delta t}$. Their signs tell you which way the point moves (right/left, up/down); together they describe the motion's speed and direction along the path.

Tiếng Việt

Trên một khoảng $t$, tốc độ thay đổi trung bình của $x$ là $\dfrac{\Delta x}{\Delta t}$ và của $y$ là $\dfrac{\Delta y}{\Delta t}$. Dấu của chúng cho biết điểm di chuyển theo hướng nào (phải/trái, lên/xuống); kết hợp lại, chúng mô tả tốc độ và hướng di chuyển trên quỹ đạo.

4.4

Parametrically Defined Circles and Lines · ⁨Đường Tròn và Đường Thẳng Được Định Nghĩa Tham Số⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.4.A: Express motion around a circle or along a line segment parametrically.

  • 4.4.A.1 A complete counterclockwise revolution around the unit circle that starts and ends at $(1,\, 0)$ and is centered at the origin can be modeled by $(x(t),\, y(t)) = (\cos t,\, \sin t)$ with domain $0 \leq t \leq 2\pi$.
  • 4.4.A.2 Transformations of the parametric function $(x(t),\, y(t)) = (\cos t,\, \sin t)$ can model any circular path traversed in the plane.
  • 4.4.A.3 A linear path along the line segment from the point $(x_1,\, y_1)$ to the point $(x_2,\, y_2)$ can be parametrized many ways, including using an initial position $(x_1,\, y_1)$ and rates of change for $x$ with respect to $t$ and $y$ with respect to $t$.
Tiếng Việt

Mục tiêu học tập 4.4.A: Biểu diễn chuyển động quanh một đường tròn hoặc dọc theo một đoạn thẳng theo dạng tham số.

  • 4.4.A.1 Một vòng quay đầy đủ ngược chiều kim đồng hồ quanh đường tròn đơn vị bắt đầu và kết thúc tại $(1,\, 0)$ và tâm tại gốc tọa độ có thể được mô hình hóa bởi $(x(t),\, y(t)) = (\cos t,\, \sin t)$ với miền xác định $0 \leq t \leq 2\pi$.
  • 4.4.A.2 Các phép biến đổi của hàm tham số $(x(t),\, y(t)) = (\cos t,\, \sin t)$ có thể mô hình hóa mọi quỹ đạo tròn được traversed (vượt qua) trong mặt phẳng.
  • 4.4.A.3 Một đường đi thẳng dọc theo đoạn thẳng từ điểm $(x_1,\, y_1)$ đến điểm $(x_2,\, y_2)$ có thể được tham số hóa theo nhiều cách, bao gồm sử dụng vị trí ban đầu $(x_1,\, y_1)$ và tốc độ thay đổi cho $x$ theo $t$ và $y$ theo $t$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

A circle of radius $R$ centered at $(h,k)$ is $x=h+R\cos t,\ y=k+R\sin t$. A line through $(x_0,y_0)$ with direction $(a,b)$ is $x=x_0+at,\ y=y_0+bt$. Adjusting the coefficients changes the start point, speed, and direction of tracing.

Tiếng Việt

Một đường tròn bán kính $R$ tâm tại $(h,k)$ là $x=h+R\cos t,\ y=k+R\sin t$. Một đường thẳng đi qua $(x_0,y_0)$ với hướng $(a,b)$ là $x=x_0+at,\ y=y_0+bt$. Điều chỉnh các hệ số sẽ thay đổi điểm bắt đầu, tốc độ và hướng quét.

4.5

Implicitly Defined Functions · ⁨Hàm Được Định Nghĩa Ngầm⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.5.A: Construct a graph of an equation involving two variables.

  • 4.5.A.1 An equation involving two variables can implicitly describe one or more functions.
  • 4.5.A.2 An equation involving two variables can be graphed by finding solutions to the equation.
  • 4.5.A.3 Solving for one of the variables in an equation involving two variables can define a function whose graph is part or all of the graph of the equation.

Learning Objective 4.5.B: Determine how the two quantities related in an implicitly defined function vary together.

  • 4.5.B.1 For ordered pairs on the graph of an implicitly defined function that are close together, if the ratio of the change in the two variables is positive, then the two variables simultaneously increase or both decrease; conversely, if the ratio is negative, then as one variable increases, the other decreases.
  • 4.5.B.2 The rate of change of $x$ with respect to $y$ or of $y$ with respect to $x$ can be zero, indicating vertical or horizontal intervals, respectively.
Tiếng Việt

Mục tiêu học tập 4.5.A: Vẽ đồ thị của một phương trình liên quan đến hai biến số.

  • 4.5.A.1 Một phương trình liên quan đến hai biến số có thể mô tả ngầm định một hoặc nhiều hàm số.
  • 4.5.A.2 Một phương trình liên quan đến hai biến số có thể được vẽ bằng cách tìm các nghiệm của phương trình đó.
  • 4.5.A.3 Giải một trong hai biến số trong phương trình liên quan đến hai biến số có thể xác định một hàm số mà đồ thị của nó là một phần hoặc toàn bộ đồ thị của phương trình.

Mục tiêu học tập 4.5.B: Xác định cách hai đại lượng liên quan trong một hàm số được xác định ngầm định biến đổi cùng nhau.

  • 4.5.B.1 Đối với các cặp thứ tự trên đồ thị của một hàm số được xác định ngầm định nằm gần nhau, nếu tỷ lệ giữa sự thay đổi của hai biến số là dương, thì hai biến số đồng thời tăng hoặc cả hai giảm; ngược lại, nếu tỷ lệ là âm, thì khi một biến số tăng, biến số kia giảm.
  • 4.5.B.2 Tốc độ thay đổi của $x$ theo $y$ hoặc của $y$ theo $x$ có thể bằng không, chỉ ra các đoạn thẳng đứng hoặc nằm ngang tương ứng.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

An implicit 隐式 equation relates $x$ and $y$ without solving for either, such as $x^2+y^2=25$. Its graph may fail the vertical-line test (not a function), so it is often split into pieces or described parametrically.

Tiếng Việt

Một phương trình ngầm liên hệ $x$ và $y$ mà không giải ra từng biến, ví dụ như $x^2+y^2=25$. Đồ thị có thể không thỏa mãn thử nghiệm đường thẳng đứng (không phải là hàm), nên thường bị chia thành các phần hoặc được mô tả tham số.

4.6

Conic Sections · ⁨Các Cung Nón⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.6.A: Represent conic sections with horizontal or vertical symmetry analytically.

  • 4.6.A.1 A parabola with vertex $(h,\, k)$ can, if $a \neq 0$, be represented analytically as $x - h = a(y - k)^2$ if it opens left or right, or as $y - k = a(x - h)^2$ if it opens up or down.
  • 4.6.A.2 An ellipse centered at $(h,\, k)$ with horizontal radius $a$ and vertical radius $b$ can be represented analytically as $\dfrac{(x - h)^2}{a^2} + \dfrac{(y - k)^2}{b^2} = 1$. A circle is a special case of an ellipse where $a = b$.
  • 4.6.A.3 A hyperbola centered at $(h,\, k)$ with vertical and horizonal lines of symmetry can be represented algebraically as $\dfrac{(x - h)^2}{a^2} - \dfrac{(y - k)^2}{b^2} = 1$ for a hyperbola opening left and right, or as $\dfrac{(y - k)^2}{b^2} - \dfrac{(x - h)^2}{a^2} = 1$ for a hyperbola opening up and down. The asymptotes are $y - k = \pm \dfrac{b}{a}(x - h)$.
Tiếng Việt

Mục tiêu học tập 4.6.A: Biểu diễn các đường conic có đối xứng ngang hoặc dọc theo phân tích.

  • 4.6.A.1 Một parabol có đỉnh tại $(h,\, k)$, nếu $a \neq 0$, có thể được biểu diễn phân tích như sau: $x - h = a(y - k)^2$ nếu nó mở sang trái hoặc phải, hoặc $y - k = a(x - h)^2$ nếu nó mở lên hoặc xuống.
  • 4.6.A.2 Một elip tâm tại $(h,\, k)$ với bán kính ngang $a$ và bán kính dọc $b$ có thể được biểu diễn phân tích là $\dfrac{(x - h)^2}{a^2} + \dfrac{(y - k)^2}{b^2} = 1$. Một đường tròn là trường hợp đặc biệt của elip khi $a = b$.
  • 4.6.A.3 Một hyperbol tâm tại $(h,\, k)$ với trục đối xứng dọc và ngang có thể được biểu diễn đại số là $\dfrac{(x - h)^2}{a^2} - \dfrac{(y - k)^2}{b^2} = 1$ cho hyperbol mở sang trái và phải, hoặc $\dfrac{(y - k)^2}{b^2} - \dfrac{(x - h)^2}{a^2} = 1$ cho hyperbol mở lên và xuống. Các đường tiệm cận là $y - k = \pm \dfrac{b}{a}(x - h)$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English
Conic sections: one cone, four curves

Conic sections 圆锥曲线 – circles, ellipses, parabolas, and hyperbolas – are the curves from slicing a cone, each given by a quadratic equation in $x$ and $y$. Their standard forms reveal centers, vertices, axes, and asymptotes.

Tiếng Việt
Conic sections: one cone, four curves

Các cung nón – đường tròn, elip, parabol và hyperbol – là các đường cong tạo ra từ việc cắt một hình nón, mỗi loại được cho bởi một phương trình bậc hai trong $x$ và $y$. Các dạng chuẩn của chúng tiết lộ tâm, đỉnh, trục và đường tiệm cận.

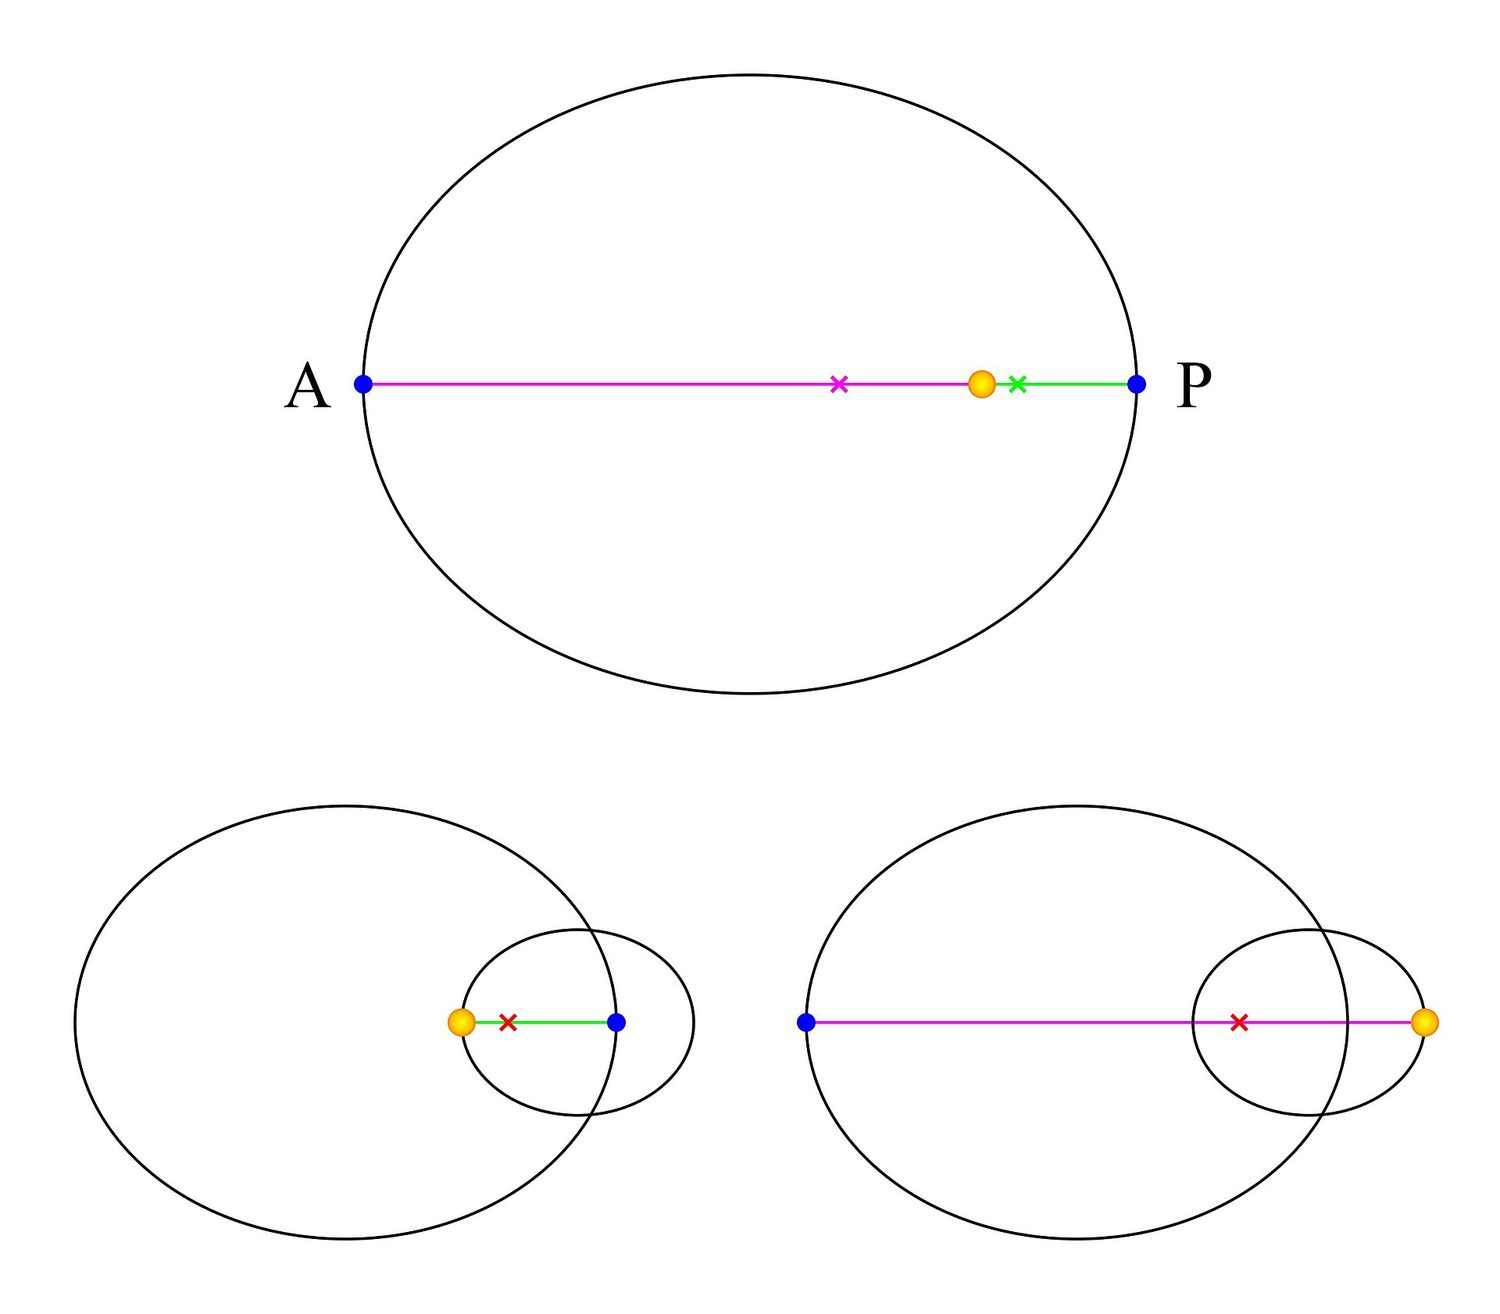
Elliptical orbits: conic sections describe closed paths with two foci — a key parametric model
Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
English Tiếng Việt
parametric function/ˌpærəˈmetrɪk ˈfʌŋkʃn/ hàm tham số
parameter/pəˈræmɪtə/ parameter
implicit/ɪmˈplɪsɪt/ ẩn
Conic sections/ˈkɒnɪk ˈsekʃnz/ Côn tiết
4.7

Parametrizing Implicit Curves · ⁨Tham số hóa Các Đường Cong Ẩm⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.7.A: Represent a curve in the plane parametrically.

  • 4.7.A.1 A parametrization $(x(t),\, y(t))$ for an implicitly defined function will, when $x(t)$ and $y(t)$ are substituted for $x$ and $y$, respectively, satisfy the corresponding equation for every value of $t$ in the domain.
  • 4.7.A.2 If $f$ is a function of $x$, then $y = f(x)$ can be parametrized as $(x(t),\, y(t)) = (t, f(t))$. If $f$ is invertible, its inverse can be parametrized as $(x(t),\, y(t)) = (f(t),\, t)$ for an appropriate interval of $t$.

Learning Objective 4.7.B: Represent conic sections parametrically.

  • 4.7.B.1 A parabola can be parametrized in the same way that any equation that can be solved for $x$ or $y$ can be parametrized. Equations that can be solved for $x$ can be parametrized as $(x(t),\, y(t)) = (f(t),\, t)$ by solving for $x$ and replacing $y$ with $t$. Equations that can be solved for $y$ can be parametrized as $(x(t),\, y(t)) = (t, f(t))$ by solving for $y$ and replacing $x$ with $t$.
  • 4.7.B.2 An ellipse can be parametrized using the trigonometric functions $x(t) = h + a\cos t$ and $y(t) = k + b\sin t$ for $0 \leq t \leq 2\pi$.
  • 4.7.B.3 A hyperbola can be parametrized using trigonometric functions. For a hyperbola that opens left and right, the functions are $x(t) = h + a\sec t$ and $y(t) = k + b\tan t$ for $0 \leq t \leq 2\pi$. For a hyperbola that opens up and down, the functions are $x(t) = h + a\tan t$ and $y(t) = k + b\sec t$ for $0 \leq t \leq 2\pi$.
Tiếng Việt

Mục tiêu học tập 4.7.A: Biểu diễn một đường cong trong mặt phẳng theo tham số.

  • 4.7.A.1 Một hàm tham số hóa $(x(t),\, y(t))$ cho một hàm được xác định ngầm sẽ, khi thay $x(t)$ và $y(t)$ vào vị trí $x$ và $y$, thỏa mãn phương trình tương ứng cho mọi giá trị của $t$ trong miền xác định.
  • 4.7.A.2 Nếu $f$ là hàm số của $x$, thì $y = f(x)$ có thể được tham số hóa thành $(x(t),\, y(t)) = (t, f(t))$. Nếu $f$ khả nghịch, nghịch đảo của nó có thể được tham số hóa thành $(x(t),\, y(t)) = (f(t),\, t)$ cho một khoảng phù hợp của $t$.

Mục tiêu học tập 4.7.B: Biểu diễn các đường conic theo tham số.

  • 4.7.B.1 Một parabol có thể được tham số hóa theo cùng cách mà bất kỳ phương trình nào có thể giải được cho $x$ hoặc $y$. Các phương trình có thể giải được cho $x$ có thể được tham số hóa thành $(x(t),\, y(t)) = (f(t),\, t)$ bằng cách giải cho $x$ và thay $y$ bằng $t$. Các phương trình có thể giải được cho $y$ có thể được tham số hóa thành $(x(t),\, y(t)) = (t, f(t))$ bằng cách giải cho $y$ và thay $x$ bằng $t$.
  • 4.7.B.2 Một elip có thể được tham số hóa sử dụng các hàm lượng giác $x(t) = h + a\cos t$ và $y(t) = k + b\sin t$ cho $0 \leq t \leq 2\pi$.
  • 4.7.B.3 Một hyperbol có thể được tham số hóa sử dụng các hàm lượng giác. Đối với hyperbol mở sang trái và phải, các hàm là $x(t) = h + a\sec t$ và $y(t) = k + b\tan t$ cho $0 \leq t \leq 2\pi$. Đối với hyperbol mở lên và xuống, các hàm là $x(t) = h + a\tan t$ và $y(t) = k + b\sec t$ cho $0 \leq t \leq 2\pi$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

Many implicit curves can be parametrized – rewritten as $\big(x(t),y(t)\big)$ – which makes them easier to graph and to treat as motion. The circle above is the basic example; ellipses use $x=h+A\cos t,\ y=k+B\sin t$.

Tiếng Việt

Nhiều đường cong ẩn có thể được tham số hóa – viết lại dưới dạng $\big(x(t),y(t)\big)$ – giúp dễ dàng vẽ đồ thị và xem xét như một chuyển động. Đường tròn ở trên là ví dụ cơ bản; elip sử dụng $x=h+A\cos t,\ y=k+B\sin t$.

4.8

Vectors · ⁨Véc-tơ⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.8.A: Identify characteristics of a vector.

  • 4.8.A.1 A vector is a directed line segment. When a vector is placed in the plane, the point at the beginning of the line segment is called the tail, and the point at the end of the line segment is called the head. The length of the line segment is the magnitude of the vector.
  • 4.8.A.2 A vector $\overrightarrow{P_1 P_2}$ with two components can be plotted in the $xy$-plane from $P_1 = (x_1, y_1)$ to $P_2 = (x_2, y_2)$. The vector is identified by $a$ and $b$, where $a = x_2 - x_1$ and $b = y_2 - y_1$. The vector can be expressed as $\langle a,\, b \rangle$. A zero vector $\langle 0,\, 0 \rangle$ is the trivial case when $P_1 = P_2$.
  • 4.8.A.3 The direction of the vector is parallel to the line segment from the origin to the point with coordinates $(a,\, b)$. The magnitude of the vector is the square root of the sum of the squares of the components.
  • 4.8.A.4 For a vector represented geometrically in the plane, the components of the vector can be found using trigonometry.

Learning Objective 4.8.B: Determine sums and products involving vectors.

  • 4.8.B.1 The multiplication of a constant and a vector results in a new vector whose components are found by multiplying the constant by each of the components of the original vector. The new vector is parallel to the original vector.
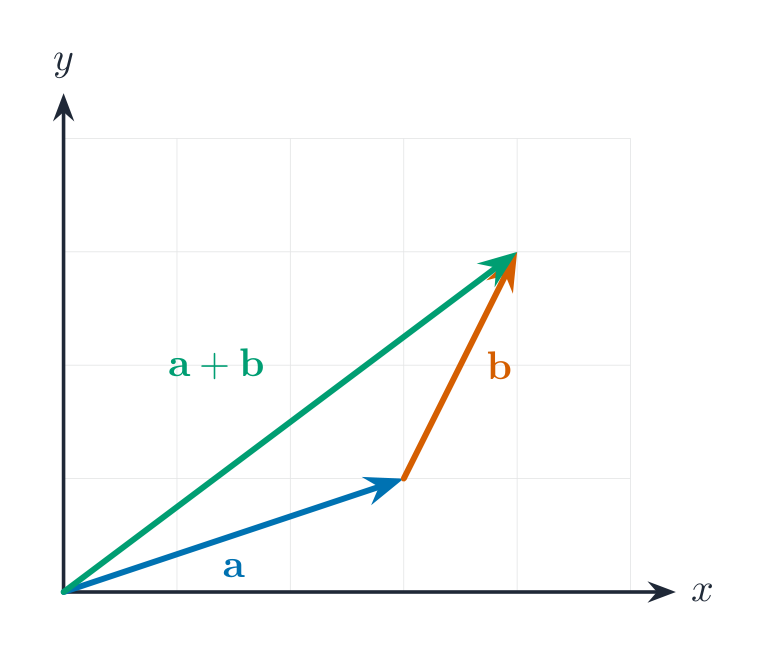
  • 4.8.B.2 The sum of two vectors in $\mathbb{R}^2$ is a new vector whose components are found by adding the corresponding components of the original vectors. The new vector can be represented graphically as a vector whose tail corresponds to the tail of the first vector and whose head corresponds to the head of the second vector when the second vector's tail is located at the first vector's head.
  • 4.8.B.3 The dot product of two vectors is the sum of the products of their corresponding components. That is, $\langle a_1,\, b_1 \rangle \cdot \langle a_2,\, b_2 \rangle = a_1 a_2 + b_1 b_2$.

Learning Objective 4.8.C: Determine a unit vector for a given vector.

  • 4.8.C.1 A unit vector is a vector of magnitude $1$. A unit vector in the same direction as a given nonzero vector can be found by scalar multiplying the vector by the reciprocal of its magnitude.
  • 4.8.C.2 The vector $\langle a,\, b \rangle$ can be expressed as $a\vec{i} + b\vec{j}$ in $\mathbb{R}^2$, where $\vec{i}$ and $\vec{j}$ are unit vectors in the $x$ and $y$ directions, respectively. That is, $\vec{i} = \langle 1,\, 0 \rangle$ and $\vec{j} = \langle 0,\, 1 \rangle$.

Learning Objective 4.8.D: Determine angle measures between vectors and magnitudes of vectors involved in vector addition.

  • 4.8.D.1 The dot product is geometrically equivalent to the product of the magnitudes of the two vectors and the cosine of the angle between them. Therefore, if the dot product of two nonzero vectors is zero, then the vectors are perpendicular.
  • 4.8.D.2 The Law of Sines and Law of Cosines can be used to determine side lengths and angle measures of triangles formed by vector addition.
Tiếng Việt

Mục tiêu học tập 4.8.A: Xác định các đặc điểm của một vectơ.

  • 4.8.A.1 Một vectơ là một đoạn thẳng có hướng. Khi đặt một vectơ trong mặt phẳng, điểm đầu của đoạn thẳng gọi là đuôi, và điểm cuối của đoạn thẳng gọi là đầu. Độ dài của đoạn thẳng là độ lớn (hay模) của vectơ.
  • 4.8.A.2 Một vectơ $\overrightarrow{P_1 P_2}$ với hai thành phần có thể được vẽ trên mặt phẳng $xy$ từ $P_1 = (x_1, y_1)$ đến $P_2 = (x_2, y_2)$. Vectơ được xác định bởi $a$ và $b$, trong đó $a = x_2 - x_1$ và $b = y_2 - y_1$. Vectơ có thể được biểu diễn dưới dạng $\langle a,\, b \rangle$. Vectơ không $\langle 0,\, 0 \rangle$ là trường hợp tầm thường khi $P_1 = P_2$.
  • 4.8.A.3 Hướng của vectơ song song với đoạn thẳng nối gốc tọa độ đến điểm có tọa độ $(a,\, b)$. Độ lớn của vectơ là căn bậc hai của tổng bình phương các thành phần.
  • 4.8.A.4 Đối với một vectơ được biểu diễn hình học trong mặt phẳng, các thành phần của vectơ có thể được tìm thấy bằng lượng giác.

Mục tiêu học tập 4.8.B: Xác định tổng và tích liên quan đến các vectơ.

  • 4.8.B.1 Phép nhân một hằng số với một vectơ tạo ra một vectơ mới có các thành phần được tìm bằng cách nhân hằng số đó với từng thành phần của vectơ ban đầu. Vectơ mới song song với vectơ ban đầu.
  • 4.8.B.2 Tổng của hai vectơ trong $\mathbb{R}^2$ là một vectơ mới có các thành phần được tìm bằng cách cộng các thành phần tương ứng của các vectơ ban đầu. Vectơ mới có thể được biểu diễn đồ thị như một vectơ có đuôi trùng với đuôi của vectơ đầu tiên và đầu trùng với đầu của vectơ thứ hai khi đuôi của vectơ thứ hai được đặt tại đầu của vectơ đầu tiên.
  • 4.8.B.3 Tích vô hướng của hai vectơ là tổng các tích của các thành phần tương ứng của chúng. Cụ thể, $\langle a_1,\, b_1 \rangle \cdot \langle a_2,\, b_2 \rangle = a_1 a_2 + b_1 b_2$.

Mục tiêu học tập 4.8.C: Xác định một vectơ đơn vị cho một vectơ đã cho.

  • 4.8.C.1 Một vectơ đơn vị là một vectơ có độ lớn $1$. Một vectơ đơn vị cùng hướng với một vectơ khác không cho trước có thể được tìm bằng cách nhân vô hướng vectơ đó với nghịch đảo của độ lớn của nó.
  • 4.8.C.2 Vector $\langle a,\, b \rangle$ có thể được biểu diễn dưới dạng $a\vec{i} + b\vec{j}$ trong $\mathbb{R}^2$, nơi $\vec{i}$ và $\vec{j}$ là các vector đơn vị theo hướng $x$ và $y$ tương ứng. Điều đó có nghĩa là $\vec{i} = \langle 1,\, 0 \rangle$ và $\vec{j} = \langle 0,\, 1 \rangle$.

Mục tiêu học tập 4.8.D: Xác định số đo góc giữa các vectơ và độ lớn của các vectơ tham gia vào phép cộng vectơ.

  • 4.8.D.1 Tích vô hướng tương đương về mặt hình học với tích của độ lớn hai vectơ và cosin của góc giữa chúng. Do đó, nếu tích vô hướng của hai vectơ khác không bằng 0, thì hai vectơ đó vuông góc.
  • 4.8.D.2 Định lý sin và định lý cos có thể được sử dụng để xác định độ dài các cạnh và số đo các góc của tam giác tạo thành bởi phép cộng vectơ.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English
Resolving a vector into components

A vector 向量 has both magnitude 大小 (length) and direction. Write it by components $\langle a,b\rangle$. Add vectors component-by-component; scale by multiplying each component; the magnitude is $\sqrt{a^2+b^2}$. Vectors model displacements, velocities, and forces.

Tiếng Việt
Resolving a vector into components

Một vector có cả độ lớn (chiều dài) và hướng. Viết nó theo thành phần $\langle a,b\rangle$. Cộng các vector theo từng thành phần; nhân vô hướng bằng cách nhân mỗi thành phần; độ lớn là $\sqrt{a^2+b^2}$. Vector mô tả độ dịch chuyển, vận tốc và lực.

Adding vectors by the triangle law
Explore · ⁨Khám phá⁩

Add two vectors tip to tail · ⁨Cộng hai vector đầu cuối nối đuôi⁩

A vector has magnitude and direction. Adding two vectors places them tip to tail; the resultant runs from the first tail to the last tip. Drag each to see the sum. · ⁨Một vector có độ lớn và hướng. Cộng hai vector bằng cách nối đầu này với đuôi kia; vector tổng hợp chạy từ đuôi đầu tiên đến đầu cuối cùng. Kéo thả từng vector để xem tổng.⁩

4.9

Vector-Valued Functions · ⁨Hàm Giá Trị Vector⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.9.A: Represent planar motion in terms of vector-valued functions.

  • 4.9.A.1 The position of a particle moving in a plane that is given by the parametric function $f(t) = (x(t),\, y(t))$ may be expressed as a vector-valued function, $p(t) = x(t)\vec{i} + y(t)\vec{j}$ or $p(t) = \langle x(t),\, y(t) \rangle$. The magnitude of the position vector at time $t$ gives the distance of the particle from the origin.
  • 4.9.A.2 The vector-valued function $v(t) = \langle x(t),\, y(t) \rangle$ can be used to express the velocity of a particle moving in a plane at different times, $t$. At time $t$, the sign of $x(t)$ indicates if the particle is moving right or left, and the sign of $y(t)$ indicates if the particle is moving up or down. The magnitude of the velocity vector at time $t$ gives the speed of the particle.
Tiếng Việt

Mục tiêu học tập 4.9.A: Biểu diễn chuyển động phẳng dưới dạng hàm giá trị vectơ.

  • 4.9.A.1 Vị trí của một hạt chuyển động trong mặt phẳng được cho bởi hàm tham số $f(t) = (x(t),\, y(t))$ có thể được biểu diễn dưới dạng hàm giá trị vectơ, $p(t) = x(t)\vec{i} + y(t)\vec{j}$ hoặc $p(t) = \langle x(t),\, y(t) \rangle$. Độ lớn của vectơ vị trí tại thời điểm $t$ cho biết khoảng cách của hạt từ gốc tọa độ.
  • 4.9.A.2 Hàm giá trị vectơ $v(t) = \langle x(t),\, y(t) \rangle$ có thể được dùng để biểu diễn vận tốc của một hạt chuyển động trong mặt phẳng ở các thời điểm khác nhau, $t$. Tại thời điểm $t$, dấu của $x(t)$ cho biết hạt đang chuyển động sang phải hay trái, và dấu của $y(t)$ cho biết hạt đang chuyển động lên hay xuống. Độ lớn của vectơ vận tốc tại thời điểm $t$ cho biết tốc độ của hạt.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

A vector-valued function 向量值函数 outputs a vector for each input, e.g. $\vec{r}(t)=\langle x(t),y(t)\rangle$ – the same information as a parametric function, packaged as a moving position vector.

Tiếng Việt

Một hàm giá trị vector trả về một vector cho mỗi đầu vào, ví dụ $\vec{r}(t)=\langle x(t),y(t)\rangle$ – cùng thông tin với hàm tham số, được đóng gói dưới dạng vector vị trí chuyển động.

Một đường thẳng vector: bắt đầu tại a, sau đó trượt đi t lần theo hướng b
4.10

Matrices · ⁨Ma trận⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.10.A: Determine the product of two matrices.

  • 4.10.A.1 An $n \times m$ matrix is an array consisting of $n$ rows and $m$ columns.
  • 4.10.A.2 Two matrices can be multiplied if the number of columns in the first matrix equals the number of rows in the second matrix. The product of the matrices is a new matrix in which the component in the $i$th row and $j$th column is the dot product of the $i$th row of the first matrix and the $j$th column of the second matrix.
Tiếng Việt

Mục tiêu học tập 4.10.A: Xác định tích của hai ma trận.

  • 4.10.A.1 Một ma trận $n \times m$ là một mảng gồm $n$ hàng và $m$ cột.
  • 4.10.A.2 Hai ma trận có thể nhân với nhau nếu số cột của ma trận đầu tiên bằng số hàng của ma trận thứ hai. Tích của các ma trận là một ma trận mới trong đó phần tử ở hàng thứ $i$ và cột thứ $j$ là tích vô hướng của hàng thứ $i$ của ma trận đầu tiên và cột thứ $j$ của ma trận thứ hai.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

A matrix 矩阵 is a rectangular array of numbers. Add matrices of the same size entry-by-entry; multiply a matrix by a compatible one by combining rows with columns. Matrices store and transform data compactly.

Tiếng Việt

Một ma trận là một mảng chữ nhật các số. Cộng các ma trận cùng kích thước theo từng phần tử; nhân ma trận với một ma trận tương thích bằng cách kết hợp các hàng với các cột. Ma trận lưu trữ và biến đổi dữ liệu một cách gọn gàng.

4.11

The Inverse and Determinant of a Matrix · ⁨nghịch Đảo và Định Thức Của Ma Trận⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.11.A: Determine the inverse of a $2 \times 2$ matrix.

  • 4.11.A.1 The identity matrix, $I$, is a square matrix consisting of $1$s on the diagonal from the top left to bottom right and $0$s everywhere else.
  • 4.11.A.2 Multiplying a square matrix by its corresponding identity matrix results in the original square matrix.
  • 4.11.A.3 The product of a square matrix and its inverse, when it exists, is the identity matrix of the same size.
  • 4.11.A.4 The inverse of a $2 \times 2$ matrix, when it exists, can be calculated with or without technology.

Learning Objective 4.11.B: Apply the value of the determinant to invertibility and vectors.

  • 4.11.B.1 The determinant of the matrix $A = \begin{bmatrix} a & b \\ c & d \end{bmatrix}$ is $ad - bc$. The determinant can be calculated with or without technology and is denoted $\det(A)$.
  • 4.11.B.2 If a $2 \times 2$ matrix consists of two column or row vectors from $\mathbb{R}^2$, then the nonzero absolute value of the determinant of the matrix is the area of the parallelogram spanned by the vectors represented in the columns or rows of the matrix. If the determinant equals $0$, then the vectors are parallel.
  • 4.11.B.3 The square matrix $A$ has an inverse if and only if $\det(A) \neq 0$.
Tiếng Việt

Mục tiêu học tập 4.11.A: Xác định nghịch đảo của một ma trận $2 \times 2$.

  • 4.11.A.1 Ma trận đơn vị, $I$, là một ma trận vuông gồm các số $1$ trên đường chéo từ góc trên bên trái xuống góc dưới bên phải và các số $0$ ở mọi nơi khác.
  • 4.11.A.2 Nhân một ma trận vuông với ma trận đơn vị tương ứng sẽ thu được ma trận vuông ban đầu.
  • 4.11.A.3 Tích của một ma trận vuông và nghịch đảo của nó, khi tồn tại, là ma trận đơn vị cùng kích thước.
  • 4.11.A.4 Nghịch đảo của một ma trận $2 \times 2$, khi tồn tại, có thể được tính toán có hoặc không có sự trợ giúp của công cụ kỹ thuật số.

Mục tiêu học tập 4.11.B: Áp dụng giá trị của định thức đối với khả năng nghịch đảo và vector.

  • 4.11.B.1 Định thức của ma trận $A = \begin{bmatrix} a & b \\ c & d \end{bmatrix}$ là $ad - bc$. Định thức có thể được tính toán có hoặc không có sự trợ giúp của công cụ kỹ thuật số và được ký hiệu là $\det(A)$.
  • 4.11.B.2 Nếu một ma trận $2 \times 2$ gồm hai vector cột hoặc vector hàng từ $\mathbb{R}^2$, thì giá trị tuyệt đối khác không của định thức ma trận chính là diện tích của hình bình hành được tạo bởi các vector đại diện trong các cột hoặc hàng của ma trận. Nếu định thức bằng $0$, thì các vector song song.
  • 4.11.B.3 Ma trận vuông $A$ có nghịch đảo khi và chỉ khi $\det(A) \neq 0$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

The determinant 行列式 of a $2\times 2$ matrix $\begin{bmatrix} a & b \\ c & d\end{bmatrix}$ is $ad-bc$. A matrix has an inverse 逆矩阵 exactly when its determinant is nonzero; the inverse undoes the matrix, and it solves matrix equations (like a reciprocal for numbers).

Worked example. For $A=\begin{bmatrix}3 & 1\\ 2 & 4\end{bmatrix}$, the determinant is $ad-bc=(3)(4)-(1)(2)=10$. Since it is nonzero, $A$ is invertible, and $A^{-1}=\dfrac{1}{10}\begin{bmatrix}4 & -1\\ -2 & 3\end{bmatrix}$ (swap the diagonal, negate the off-diagonal, divide by the determinant).

Tiếng Việt

Định thức của một ma trận $2\times 2$ $\begin{bmatrix} a & b \\ c & d\end{bmatrix}$ là $ad-bc$. Một ma trận có nghịch đảo chính xác khi định thức của nó khác không; nghịch đảo hoàn tác lại ma trận, và nó giải các phương trình ma trận (giống như nghịch đảo của số).

Ví dụ tính toán. Đối với $A=\begin{bmatrix}3 & 1\\ 2 & 4\end{bmatrix}$, định thức là $ad-bc=(3)(4)-(1)(2)=10$. Vì nó khác không, $A$ có thể nghịch đảo, và $A^{-1}=\dfrac{1}{10}\begin{bmatrix}4 & -1\\ -2 & 3\end{bmatrix}$ (đổi chỗ đường chéo, đổi dấu ngoài đường chéo, chia cho định thức).

Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
English Tiếng Việt
matrix/ˈmeɪtrɪks/ ma trận
4.12

Linear Transformations and Matrices · ⁨Biến Đổi tuyến Tính Và Ma Trận⁩

Syllabus · ⁨Chương trình⁩
Learning ObjectiveEssential Knowledge

4.12.A
Determine the output vectors of a linear transformation using a $2 \times 2$ matrix.

  • 4.12.A.1 A linear transformation is a function that maps an input vector to an output vector such that each component of the output vector is the sum of constant multiples of the input vector components.
  • 4.12.A.2 A linear transformation will map the zero vector to the zero vector.
  • 4.12.A.3 A single vector in $\mathbb{R}^2$ can be expressed as a $2 \times 1$ matrix. A set of $n$ vectors in $\mathbb{R}^2$ can be expressed as a $2 \times n$ matrix.
  • 4.12.A.4 For a linear transformation, $L$, from $\mathbb{R}^2$ to $\mathbb{R}^2$, there is a unique $2 \times 2$ matrix, $A$, such that $L(\vec{v}) = A\vec{v}$ for vectors in $\mathbb{R}^2$. Conversely, for a given $2 \times 2$ matrix, $A$, the function $L(\vec{v}) = A\vec{v}$ is a linear transformation from $\mathbb{R}^2$ to $\mathbb{R}^2$.
  • 4.12.A.5 Multiplication of a $2 \times 2$ transformation matrix, $A$, and a $2 \times n$ matrix of $n$ input vectors gives a $2 \times n$ matrix of the $n$ output vectors for the linear transformation $L(\vec{v}) = A\vec{v}$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English
A matrix transforms the plane

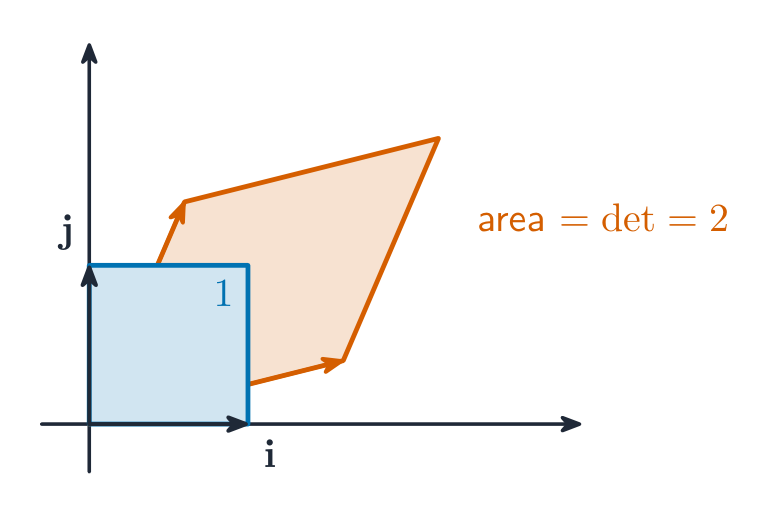
A $2\times 2$ matrix acts as a linear transformation 线性变换 of the plane – rotating, reflecting, stretching, or shearing points – by multiplying each position vector. The determinant measures how the transformation scales area (and its sign tells whether orientation flips).

Worked example. The matrix $\begin{bmatrix}2 & 0\\ 0 & 3\end{bmatrix}$ stretches the plane by $2$ horizontally and $3$ vertically, sending the vector $\begin{bmatrix}1\\1\end{bmatrix}$ to $\begin{bmatrix}2\\3\end{bmatrix}$. Its determinant $2\times3=6$ means every area is multiplied by $6$, so the unit square becomes a $2\times3$ rectangle.

Tiếng Việt
A matrix transforms the plane

Một ma trận $2\times 2$ hoạt động như một biến đổi tuyến tính của mặt phẳng – quay, phản xạ, kéo dãn hoặc xé trượt các điểm – bằng cách nhân mỗi vector vị trí. Định thức đo lường cách biến đổi thay đổi diện tích (và dấu của nó cho biết hướng có bị lật ngược hay không).

Ví dụ tính toán. Ma trận $\begin{bmatrix}2 & 0\\ 0 & 3\end{bmatrix}$ kéo dãn mặt phẳng theo $2$ theo chiều ngang và $3$ theo chiều dọc, đưa vector $\begin{bmatrix}1\\1\end{bmatrix}$ đến $\begin{bmatrix}2\\3\end{bmatrix}$. Định thức $2\times3=6$ của nó có nghĩa là mọi diện tích đều được nhân với $6$, vì vậy hình vuông đơn vị trở thành một hình chữ nhật $2\times3$.

A 2x2 matrix maps the unit square to a parallelogram; the determinant is the area scale
Explore · ⁨Khám phá⁩

Transform the plane with a matrix · ⁨Biến đổi mặt phẳng bằng ma trận⁩

A $2\times2$ matrix maps every point to a new one, so it stretches, rotates or shears the whole grid. Change the entries and watch the unit square transform. · ⁨Một ma trận $2\times2$ biến mỗi điểm thành một điểm mới, do đó nó kéo dãn, quay hoặc xéo toàn bộ lưới tọa độ. Thay đổi các phần tử và quan sát cách hình đơn vị biến đổi.⁩

Vocabulary · ⁨Từ vựng⁩ Train · ⁨Luyện tập⁩
English Tiếng Việt
determinant/dɪˈtɜːmɪnənt/ định thức
inverse/ɪnˈvɜːs/ nghịch
linear transformation/ˈlɪnɪə trænsfɔːˈmeɪʃn/ biến đổi tuyến tính
4.13

Matrices as Functions · ⁨Ma Trận Như Các Hàm⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.13.A: Determine the association between a linear transformation and a matrix.

  • 4.13.A.1 The linear transformation mapping $\langle x,\, y \rangle$ to $\langle a_{11} x + a_{12} y,\, a_{21} x + a_{22} y \rangle$ is associated with the matrix $\begin{bmatrix} a_{11} & a_{12} \\ a_{21} & a_{22} \end{bmatrix}$.
  • 4.13.A.2 The mapping of the unit vectors in a linear transformation provides valuable information for determining the associated matrix.
  • 4.13.A.3 The matrix $\begin{bmatrix} \cos\theta & -\sin\theta \\ \sin\theta & \cos\theta \end{bmatrix}$ is associated with a linear transformation of vectors that rotates every vector an angle $\theta$ counterclockwise about the origin.
  • 4.13.A.4 The absolute value of the determinant of a $2 \times 2$ transformation matrix gives the magnitude of the dilation of regions in $\mathbb{R}^2$ under the transformation.

Learning Objective 4.13.B: Determine the composition of two linear transformations.

  • 4.13.B.1 The composition of two linear transformations is a linear transformation.
  • 4.13.B.2 The matrix associated with the composition of two linear transformations is the product of the matrices associated with each linear transformation.

Learning Objective 4.13.C: Determine the inverse of a linear transformation.

  • 4.13.C.1 Two linear transformations are inverses if their composition maps any vector to itself.
  • 4.13.C.2 If a linear transformation, $L$, is given by $L(\vec{v}) = A\vec{v}$, then its inverse transformation is given by $L^{-1}(\vec{v}) = A^{-1}\vec{v}$, where $A^{-1}$ is the inverse of the matrix $A$.
Tiếng Việt

Mục tiêu học tập 4.13.A: Xác định mối liên hệ giữa một biến đổi tuyến tính và một ma trận.

  • 4.13.A.1 Phép biến đổi tuyến tính ánh xạ từ $\langle x,\, y \rangle$ sang $\langle a_{11} x + a_{12} y,\, a_{21} x + a_{22} y \rangle$ được liên kết với ma trận $\begin{bmatrix} a_{11} & a_{12} \\ a_{21} & a_{22} \end{bmatrix}$.
  • 4.13.A.2 Các ánh xạ của các vectơ đơn vị trong một biến đổi tuyến tính cung cấp thông tin quan trọng để xác định ma trận tương ứng.
  • 4.13.A.3 Ma trận $\begin{bmatrix} \cos\theta & -\sin\theta \\ \sin\theta & \cos\theta \end{bmatrix}$ được gán với một biến đổi tuyến tính của các vectơ quay mỗi vectơ một góc $\theta$ ngược chiều kim đồng hồ quanh gốc tọa độ.
  • 4.13.A.4 Giá trị tuyệt đối của định thức của một ma trận biến đổi tuyến tính, $2 \times 2$, cho biết hệ số co dãn của các vùng trong $\mathbb{R}^2$ dưới phép biến đổi đó.

Mục tiêu học tập 4.13.B: Xác định hợp thành của hai biến đổi tuyến tính.

  • 4.13.B.1 Hợp thành của hai biến đổi tuyến tính là một biến đổi tuyến tính.
  • 4.13.B.2 Ma trận gán với hợp thành của hai biến đổi tuyến tính là tích của các ma trận gán với từng biến đổi tuyến tính.

Mục tiêu học tập 4.13.C: Xác định nghịch đảo của một biến đổi tuyến tính.

  • 4.13.C.1 Hai biến đổi tuyến tính là nghịch đảo của nhau nếu hợp thành của chúng ánh xạ mọi vectơ về chính nó.
  • 4.13.C.2 Nếu một biến đổi tuyến tính, $L$, được cho bởi $L(\vec{v}) = A\vec{v}$, thì biến đổi nghịch đảo của nó được cho bởi $L^{-1}(\vec{v}) = A^{-1}\vec{v}$, trong đó $A^{-1}$ là ma trận nghịch đảo của ma trận $A$.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

Because a matrix maps input vectors to output vectors, it is a function on the plane. Composing transformations corresponds to multiplying their matrices, and the inverse matrix reverses the mapping.

Tiếng Việt

Vì ma trận ánh xạ vector đầu vào sang vector đầu ra, nó là một hàm trên mặt phẳng. Sự tổ hợp các biến đổi tương ứng với việc nhân các ma trận của chúng, và ma trận nghịch đảo đảo ngược phép ánh xạ.

4.14

Matrices Modeling Contexts · ⁨Ma Mô Phỏng Ngữ Cảnh⁩

Syllabus · ⁨Chương trình⁩
English

Learning Objective 4.14.A: Construct a model of a scenario involving transitions between two states using matrices.

  • 4.14.A.1 A contextual scenario can indicate the rate of transitions between states as percent changes. A matrix can be constructed based on these rates to model how states change over discrete intervals.

Learning Objective 4.14.B: Apply matrix models to predict future and past states for $n$ transition steps.

  • 4.14.B.1 The product of a matrix that models transitions between states and a corresponding state vector can predict future states.
  • 4.14.B.2 Repeated multiplication of a matrix that models the transitions between states and corresponding resultant state vectors can predict the steady state, a distribution between states that does not change from one step to the next.
  • 4.14.B.3 The product of the inverse of a matrix that models transitions between states and a corresponding state vector can predict past states.
Tiếng Việt

Mục tiêu học tập 4.14.A: Xây dựng mô hình cho một tình huống bao gồm sự chuyển đổi giữa hai trạng thái bằng ma trận.

  • 4.14.A.1 Một tình huống cụ thể có thể chỉ ra tốc độ chuyển đổi giữa các trạng thái dưới dạng phần trăm thay đổi. Một ma trận có thể được xây dựng dựa trên các tốc độ này để mô hình hóa cách các trạng thái thay đổi theo các khoảng thời gian rời rạc.

Mục tiêu học tập 4.14.B: Áp dụng các mô hình ma trận để dự đoán trạng thái trong tương lai và quá khứ cho $n$ bước chuyển đổi.

  • 4.14.B.1 Tích của một ma trận mô hình hóa sự chuyển đổi giữa các trạng thái và một vectơ trạng thái tương ứng có thể dự đoán các trạng thái trong tương lai.
  • 4.14.B.2 Việc nhân lặp lại một ma trận mô hình hóa sự chuyển đổi giữa các trạng thái và các vectơ trạng thái kết quả tương ứng có thể dự đoán trạng thái ổn định, tức là phân bố giữa các trạng thái không thay đổi từ bước này sang bước tiếp theo.
  • 4.14.B.3 Tích của ma trận nghịch đảo mô hình hóa sự chuyển đổi giữa các trạng thái và một vectơ trạng thái tương ứng có thể dự đoán các trạng thái trong quá khứ.

Source: College Board AP Course and Exam Description · ⁨Nguồn: Mô tả Khóa học và Bài thi College Board AP⁩

English

Matrices model systems that step forward in stages – for example, populations moving between states each year. Repeated multiplication by a transition matrix advances the model one step at a time, so matrix powers predict long-run behavior.

Tiếng Việt

Ma trận mô phỏng các hệ thống tiến bước theo giai đoạn – ví dụ, quần thể di chuyển giữa các trạng thái mỗi năm. Nhân lặp lại với một ma trận chuyển tiếp sẽ tiến mô hình từng bước một, do đó lũy thừa ma trận dự đoán hành vi dài hạn.

4.14

Exam tips · ⁨Mẹo làm bài thi⁩

English
  • A parametric function gives $x(t)$ and $y(t)$ separately — track the direction of motion as $t$ increases.
  • A vector has magnitude and direction; add component-by-component and find magnitude with $\sqrt{a^2+b^2}$.
  • The determinant of a $2\times2$ matrix is $ad-bc$ (mind the minus sign); it scales area under the transformation.
  • A $2\times2$ matrix transforms the plane (rotate, reflect, stretch); an inverse exists only when the determinant is non-zero.
  • Note this unit is not tested on the AP Precalculus Exam (Units 1–3 only), but it underpins later courses.
Tiếng Việt
  • Một hàm tham số cho $x(t)$ và $y(t)$ riêng biệt – hãy theo dõi hướng chuyển động khi $t$ tăng.
  • Một vector có độ lớn và hướng; cộng theo từng thành phần và tìm độ lớn với $\sqrt{a^2+b^2}$.
  • Định thức của một ma trận $2\times2$ là $ad-bc$ (chú ý dấu trừ); nó thay đổi diện tích dưới sự biến đổi.
  • Một ma trận $2\times2$ biến đổi mặt phẳng (quay, phản xạ, kéo dãn); nghịch đảo chỉ tồn tại khi định thức khác không.
  • Lưu ý rằng đơn vị này không được kiểm tra trong Đề thi AP Precalculus (chỉ có Đơn vị 1–3), nhưng nó là nền tảng cho các khóa học sau.

Interactive lessons on this topic · ⁨Bài học tương tác về chủ đề này⁩

Work through it step by step, with instant-check exercises. · ⁨Làm theo từng bước, kèm theo bài tập kiểm tra ngay lập tức.⁩

Past Papers · ⁨Đề thi cũ⁩

More topics in AP Precalculus · ⁨AP Tiền giải tích⁩ · ⁨Nhiều chủ đề hơn trong AP Precalculus · ⁨AP Tiền giải tích⁩⁩

Log in or create account · ⁨Đăng nhập hoặc tạo tài khoản⁩

IGCSE, A-Level & AP